Related Experiment Video
Updated: Apr 18, 2026

Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
Performance Bounds of Quaternion Estimators

Abstract:
The quaternion widely linear (WL) estimator has been recently introduced for optimal second-order modeling of the generality of quaternion data, both second-order circular (proper) and second-order noncircular (improper). Experimental evidence exists of its performance advantage over the conventional strictly linear (SL) as well as the semi-WL (SWL) estimators for improper data. However, rigorous theoretical and practical performance bounds are still missing in the literature, yet this is crucial for the development of quaternion valued learning systems for 3-D and 4-D data. To this end, based on the orthogonality principle, we introduce a rigorous closed-form solution to quantify the degree of performance benefits, in terms of the mean square error, obtained when using the WL models. The cases when the optimal WL estimation can simplify into the SWL or the SL estimation are also discussed.
Related Concept Videos
 01:05
Estimation of the Physical Quantities
 01:23
Quadratic Models
 01:00
Detection of Gross Error: The Q Test
 01:17
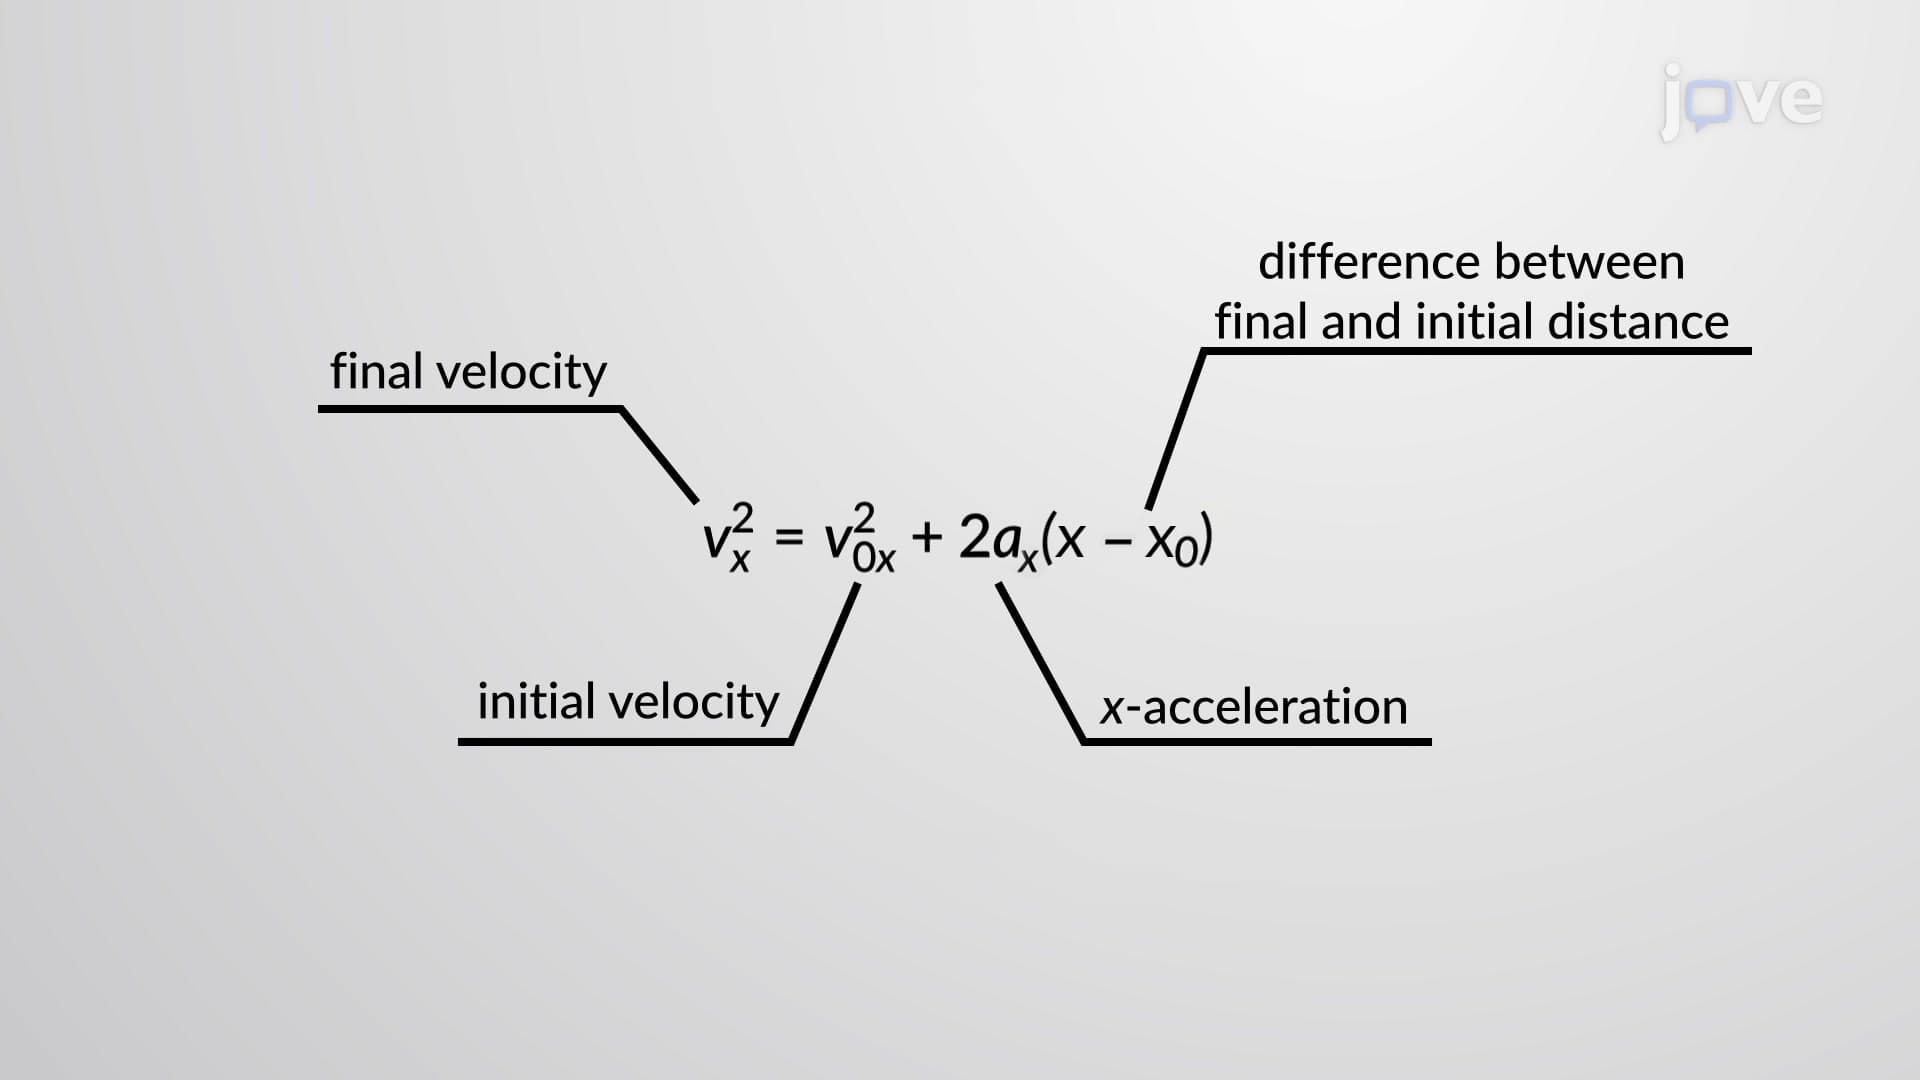
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...