Related Experiment Video
Updated: Apr 17, 2026

Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Template for robust soft-body crawling with reflex-triggered gripping
Dieter W Schuldt1, Jason Rife, Barry Trimmer
1Department of Mechanical Engineering, Tufts University, 024 Anderson Hall Medford, MA 02155, USA.

Abstract:
Caterpillars show a remarkable ability to get around in complex environments (e.g. tree branches). Part of this is attributable to crochets which allow the animal to firmly attach to a wide range of substrates. This introduces an additional challenge to locomotion, however, as the caterpillar needs a way to coordinate the release of the crochets and the activation of muscles to adjust body posture. Typical control models have focused on global coordination through a central pattern generator (CPG). This paper develops an alternative to the CPG, which accomplishes the same task and is robust to a wide range of body properties and control parameter variation. A one-dimensional model is proposed which consists of lumped masses connected by a network of springs, dampers and muscles. Computer simulations of the controller/model system are performed to verify its robustness and to permit comparison between the generated gaits and those observed in real caterpillars (specifically Manduca sexta.).


Related Concept Videos
 01:21
Rigid Body Equilibrium Problems - II
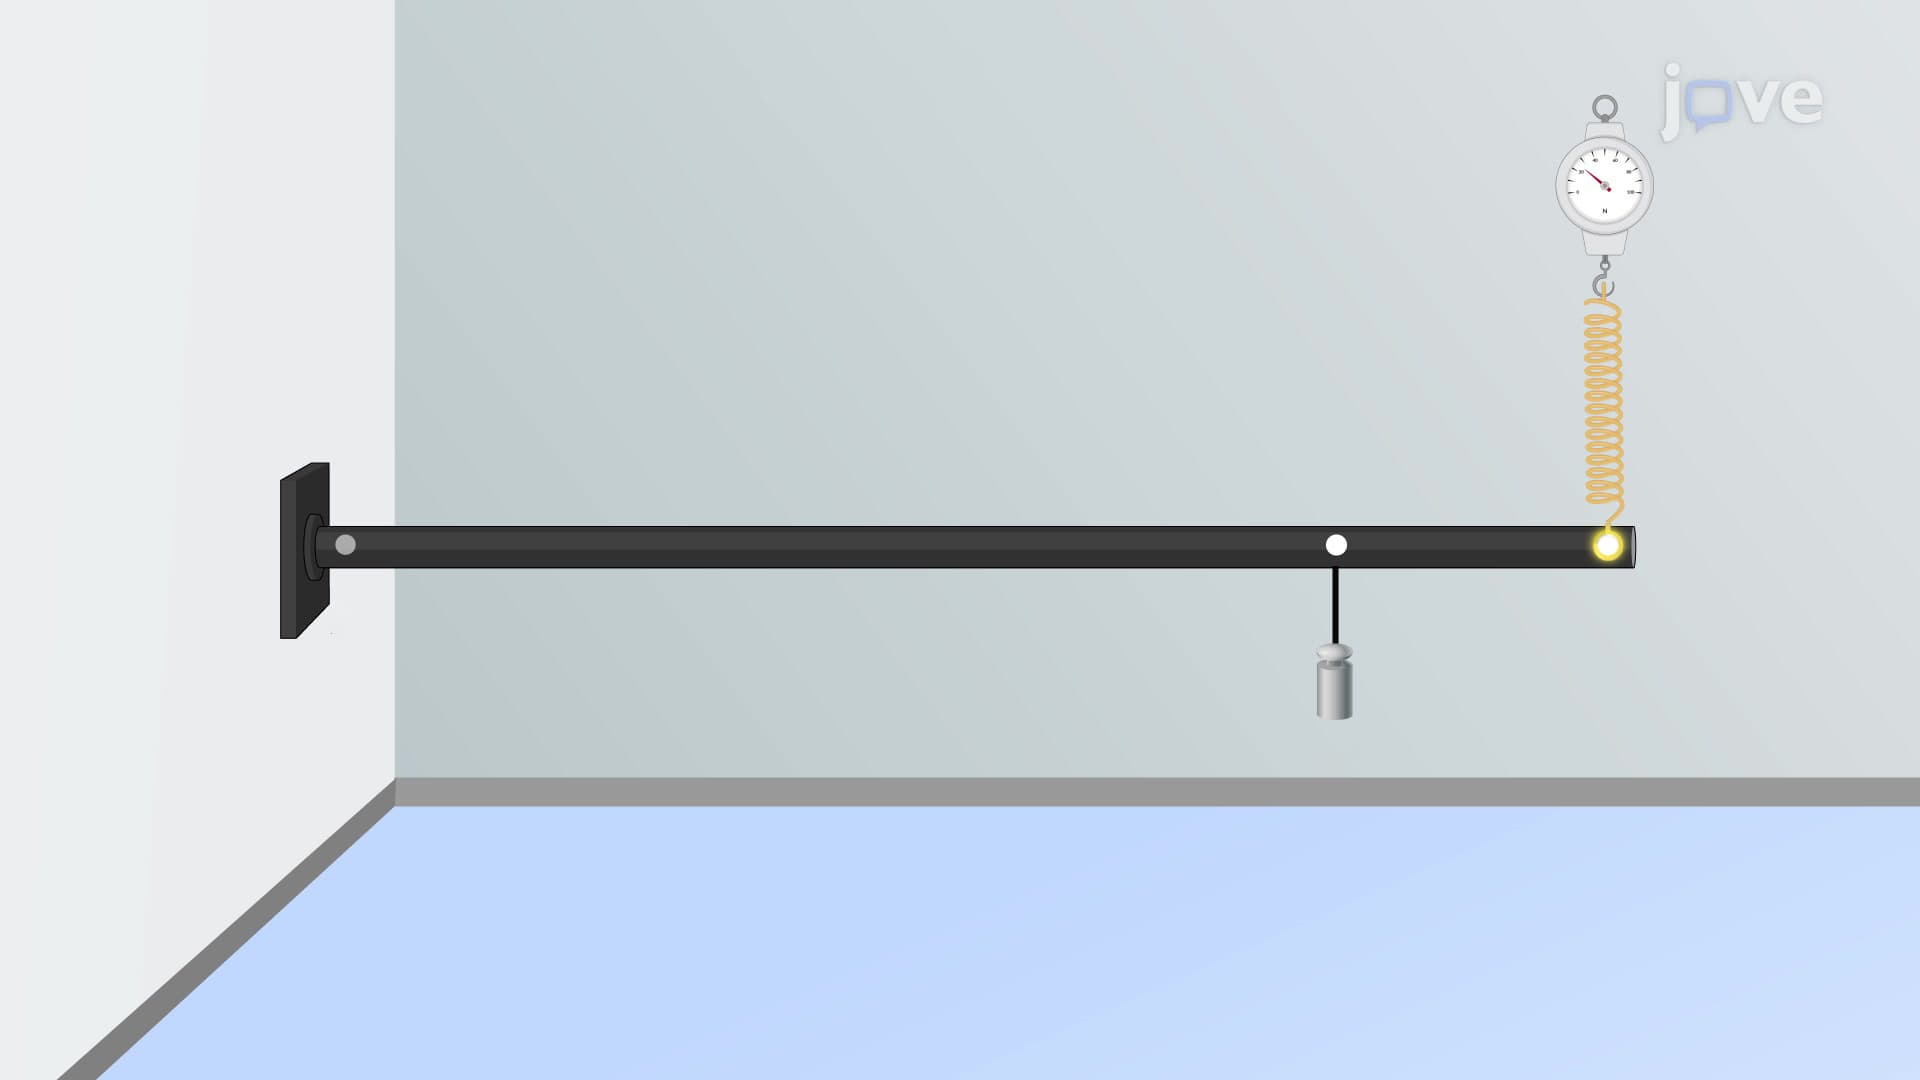
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:07
Frictional Force
 01:17
Rolling Resistance: Problem Solving
 01:08
Reflex Activity
A reflex exam is a diagnostic procedure performed by a healthcare professional to evaluate the functionality of a patient's...
 01:17
Frictional Forces on Screws
A jack with a square-threaded screw is a mechanical device used to lift heavy loads by applying a force at its handle. When the force is applied, the screw turns, raising the load. The screw can...
 01:28
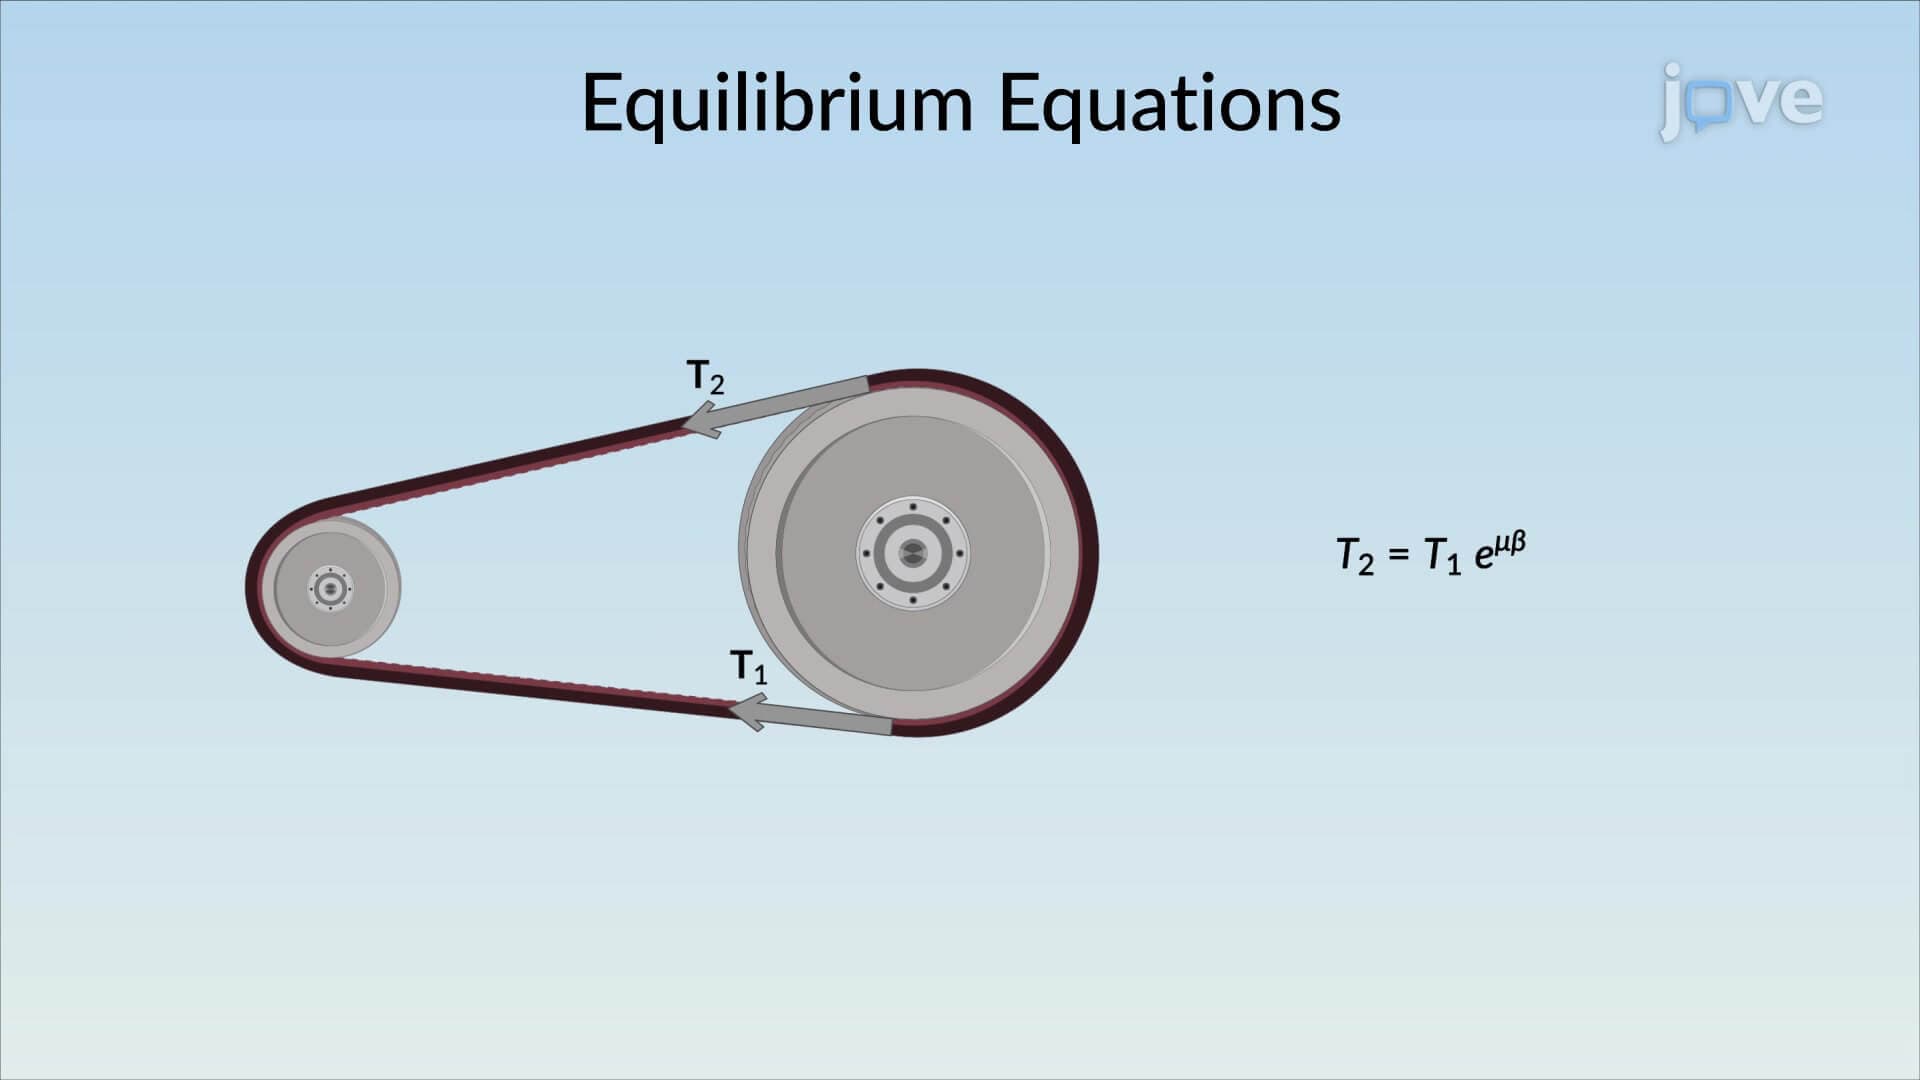
Frictional Forces on Flat Belts