Related Experiment Video
Updated: Apr 17, 2026

Studying the Neural Basis of Adaptive Locomotor Behavior in Insects
Published on: April 13, 2011
Absence of jamming in ant trails: feedback control of self-propulsion and noise
Debasish Chaudhuri1, Apoorva Nagar2
1Indian Institute of Technology Hyderabad, Yeddumailaram 502205, Telengana, India.

Abstract:
We present a model of ant traffic considering individual ants as self-propelled particles undergoing single-file motion on a one-dimensional trail. Recent experiments on unidirectional ant traffic in well-formed natural trails showed that the collective velocity of ants remains approximately unchanged, leading to the absence of jamming even at very high densities [John et al., Phys. Rev. Lett. 102, 108001 (2009)]. Assuming a feedback control mechanism of self-propulsion force generated by each ant using information about the distance from the ant in front, our model captures all the main features observed in the experiment. The distance headway distribution shows a maximum corresponding to separations within clusters. The position of this maximum remains independent of average number density. We find a non-equilibrium first-order transition, with the formation of an infinite cluster at a threshold density where all the ants in the system suddenly become part of a single cluster.
More Related Videos
 08:13
SwarmSight: Real-time Tracking of Insect Antenna Movements and Proboscis Extension Reflex Using a Common Preparation and Conventional Hardware
Published on: December 25, 2017
 10:14
Tactile Conditioning And Movement Analysis Of Antennal Sampling Strategies In Honey Bees Apis mellifera L.
Published on: December 12, 2012
Related Concept Videos
 01:17
Magnetic Damping
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Rolling Resistance: Problem Solving
 01:18
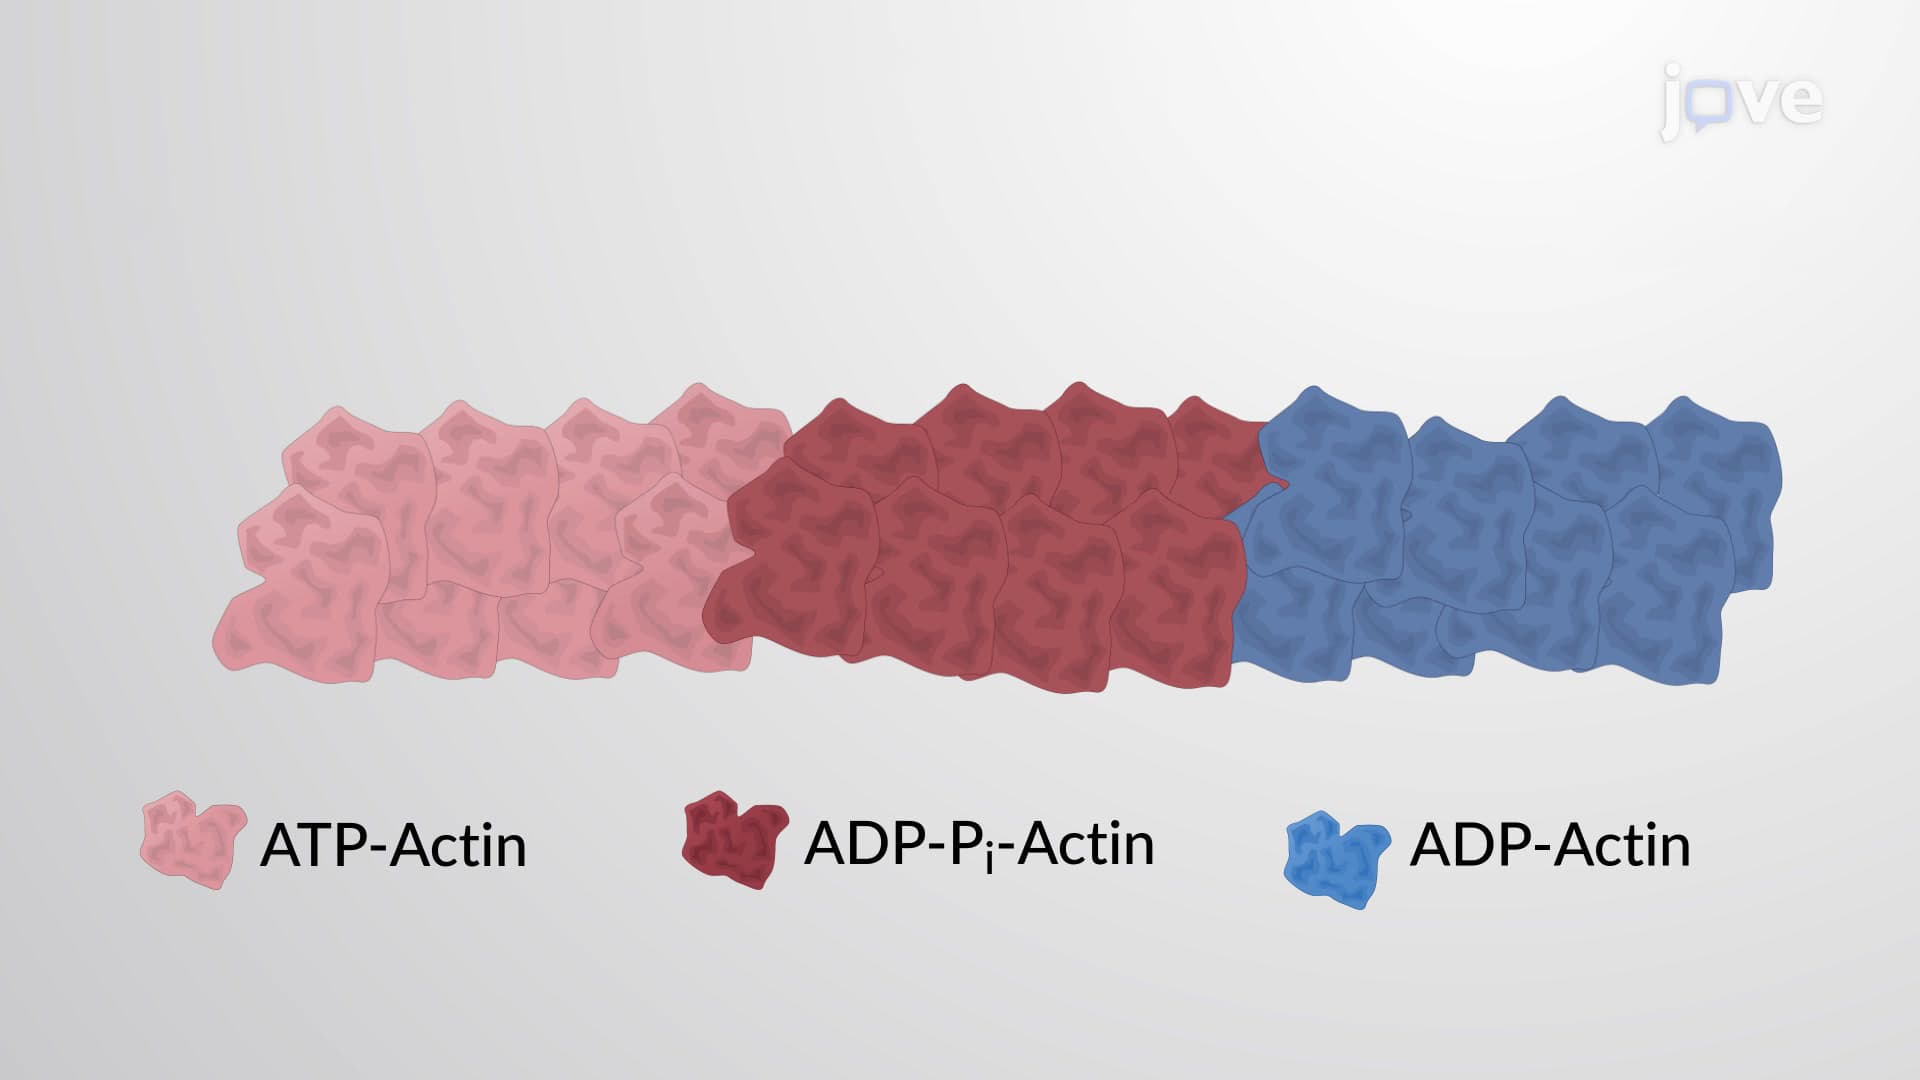
Actin Treadmilling
 01:18
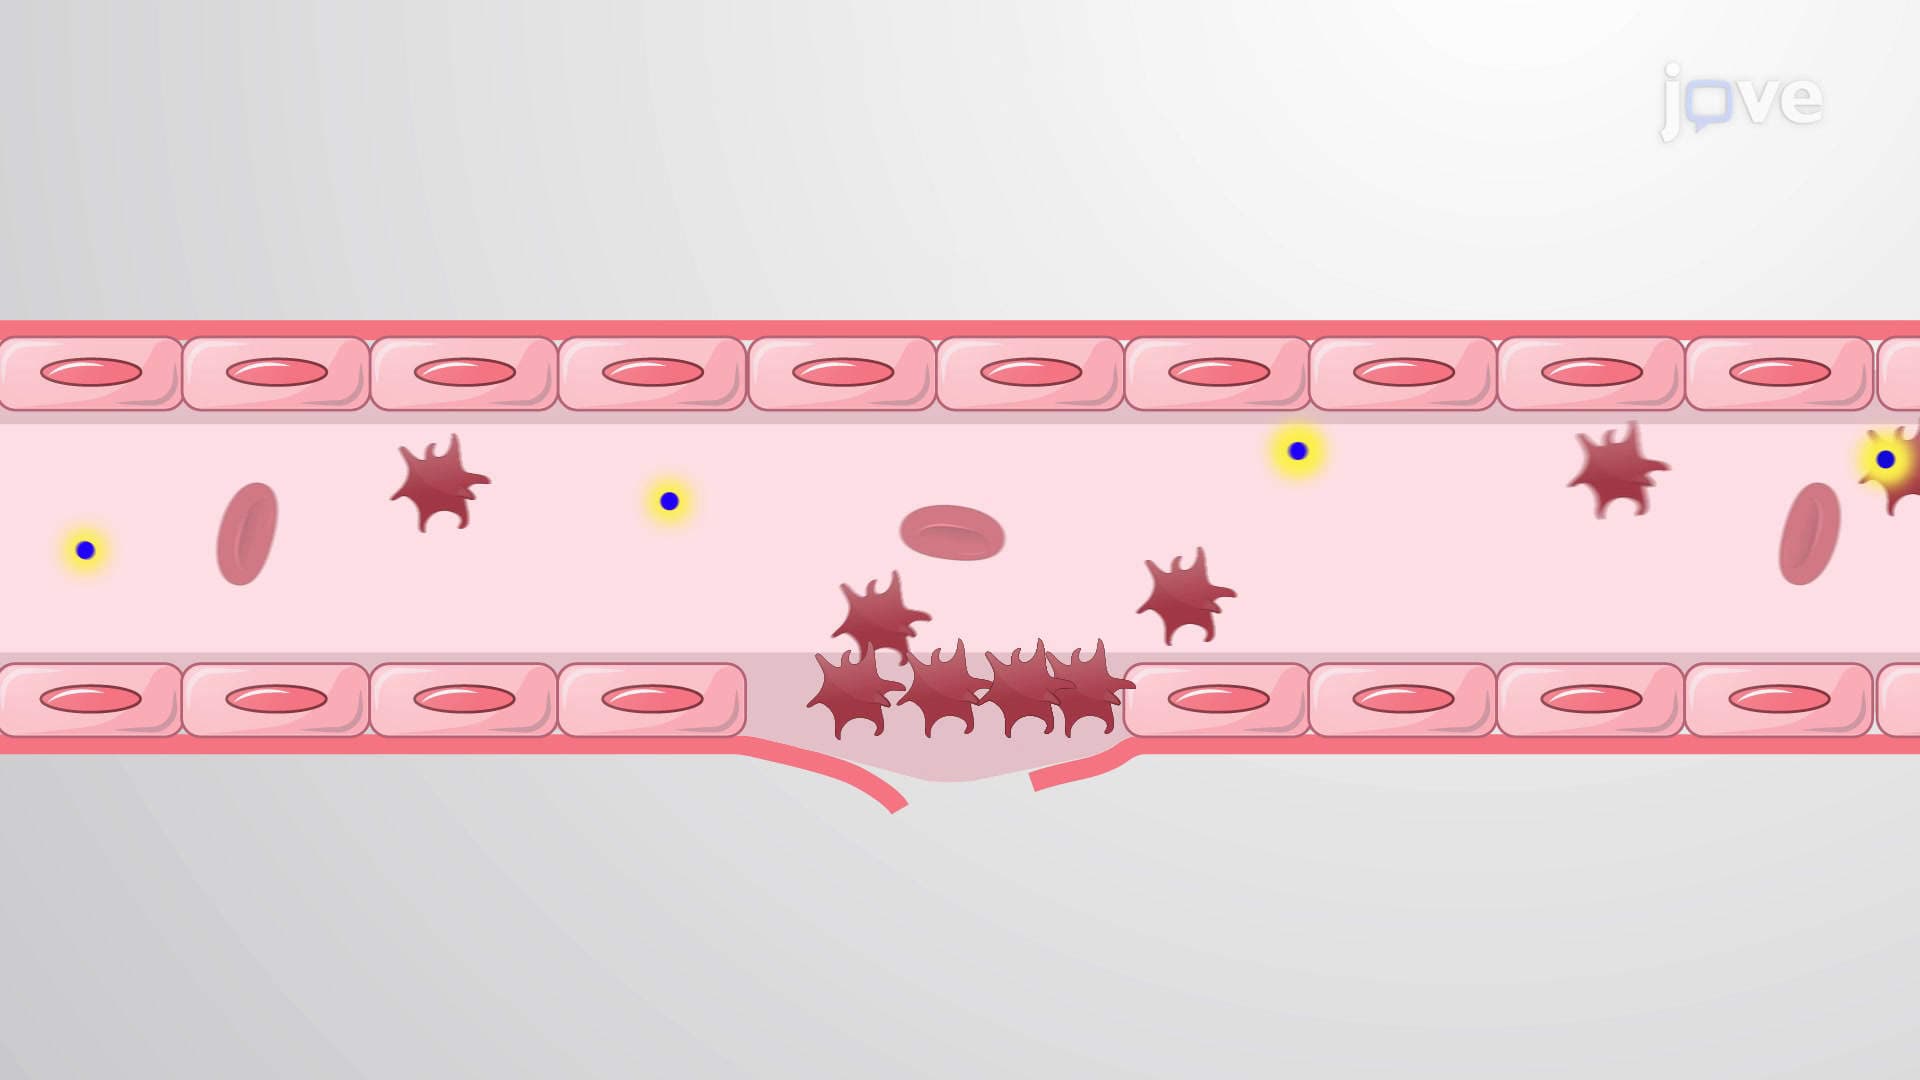
Positive and Negative Feedback Loops
 01:23
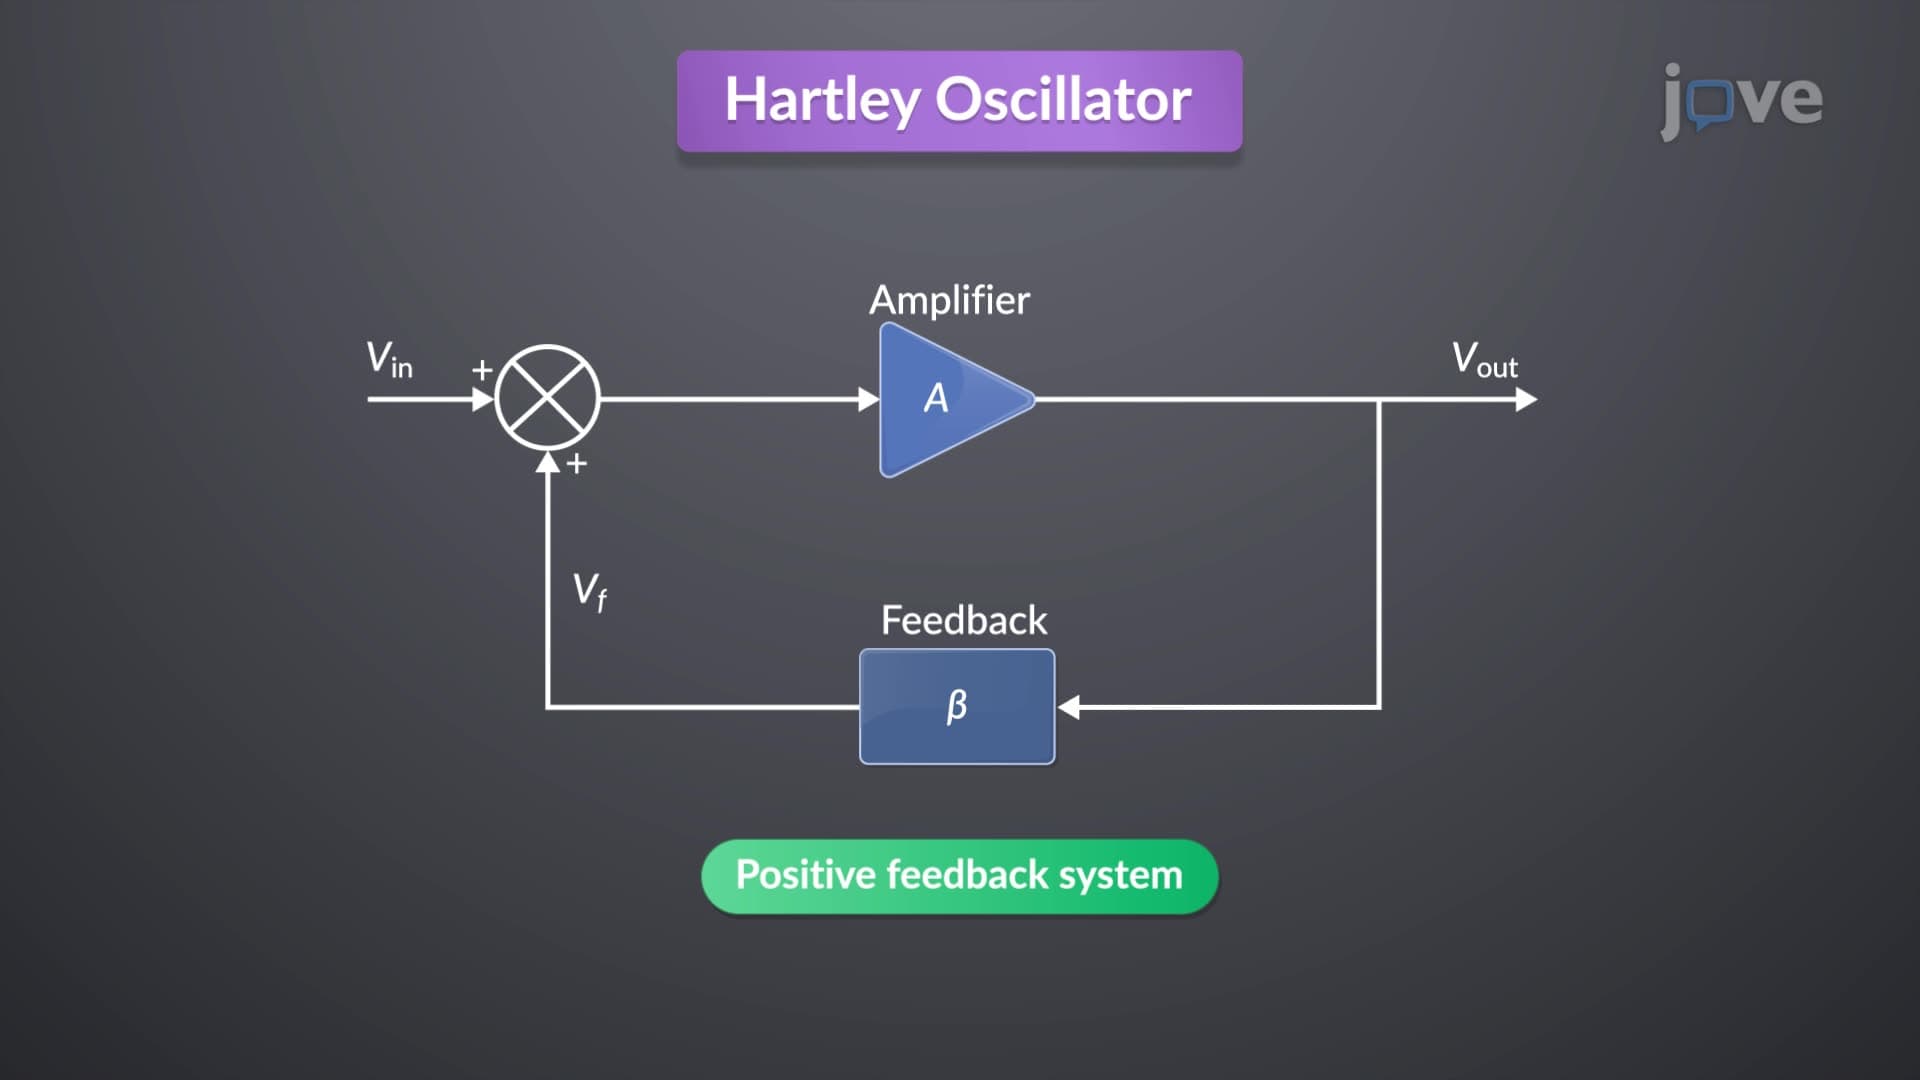
Root Loci for Positive-Feedback Systems
The construction rules for the root locus in positive feedback systems are similar to those in...