Related Experiment Video
Updated: Apr 16, 2026

A Novel Bayesian Change-point Algorithm for Genome-wide Analysis of Diverse ChIPseq Data Types
Published on: December 10, 2012
Bayesian inference for Markov jump processes with informative observations

Abstract:
In this paper we consider the problem of parameter inference for Markov jump process (MJP) representations of stochastic kinetic models. Since transition probabilities are intractable for most processes of interest yet forward simulation is straightforward, Bayesian inference typically proceeds through computationally intensive methods such as (particle) MCMC. Such methods ostensibly require the ability to simulate trajectories from the conditioned jump process. When observations are highly informative, use of the forward simulator is likely to be inefficient and may even preclude an exact (simulation based) analysis. We therefore propose three methods for improving the efficiency of simulating conditioned jump processes. A conditioned hazard is derived based on an approximation to the jump process, and used to generate end-point conditioned trajectories for use inside an importance sampling algorithm. We also adapt a recently proposed sequential Monte Carlo scheme to our problem. Essentially, trajectories are reweighted at a set of intermediate time points, with more weight assigned to trajectories that are consistent with the next observation. We consider two implementations of this approach, based on two continuous approximations of the MJP. We compare these constructs for a simple tractable jump process before using them to perform inference for a Lotka-Volterra system. The best performing construct is used to infer the parameters governing a simple model of motility regulation in Bacillus subtilis.
Related Concept Videos
 01:09
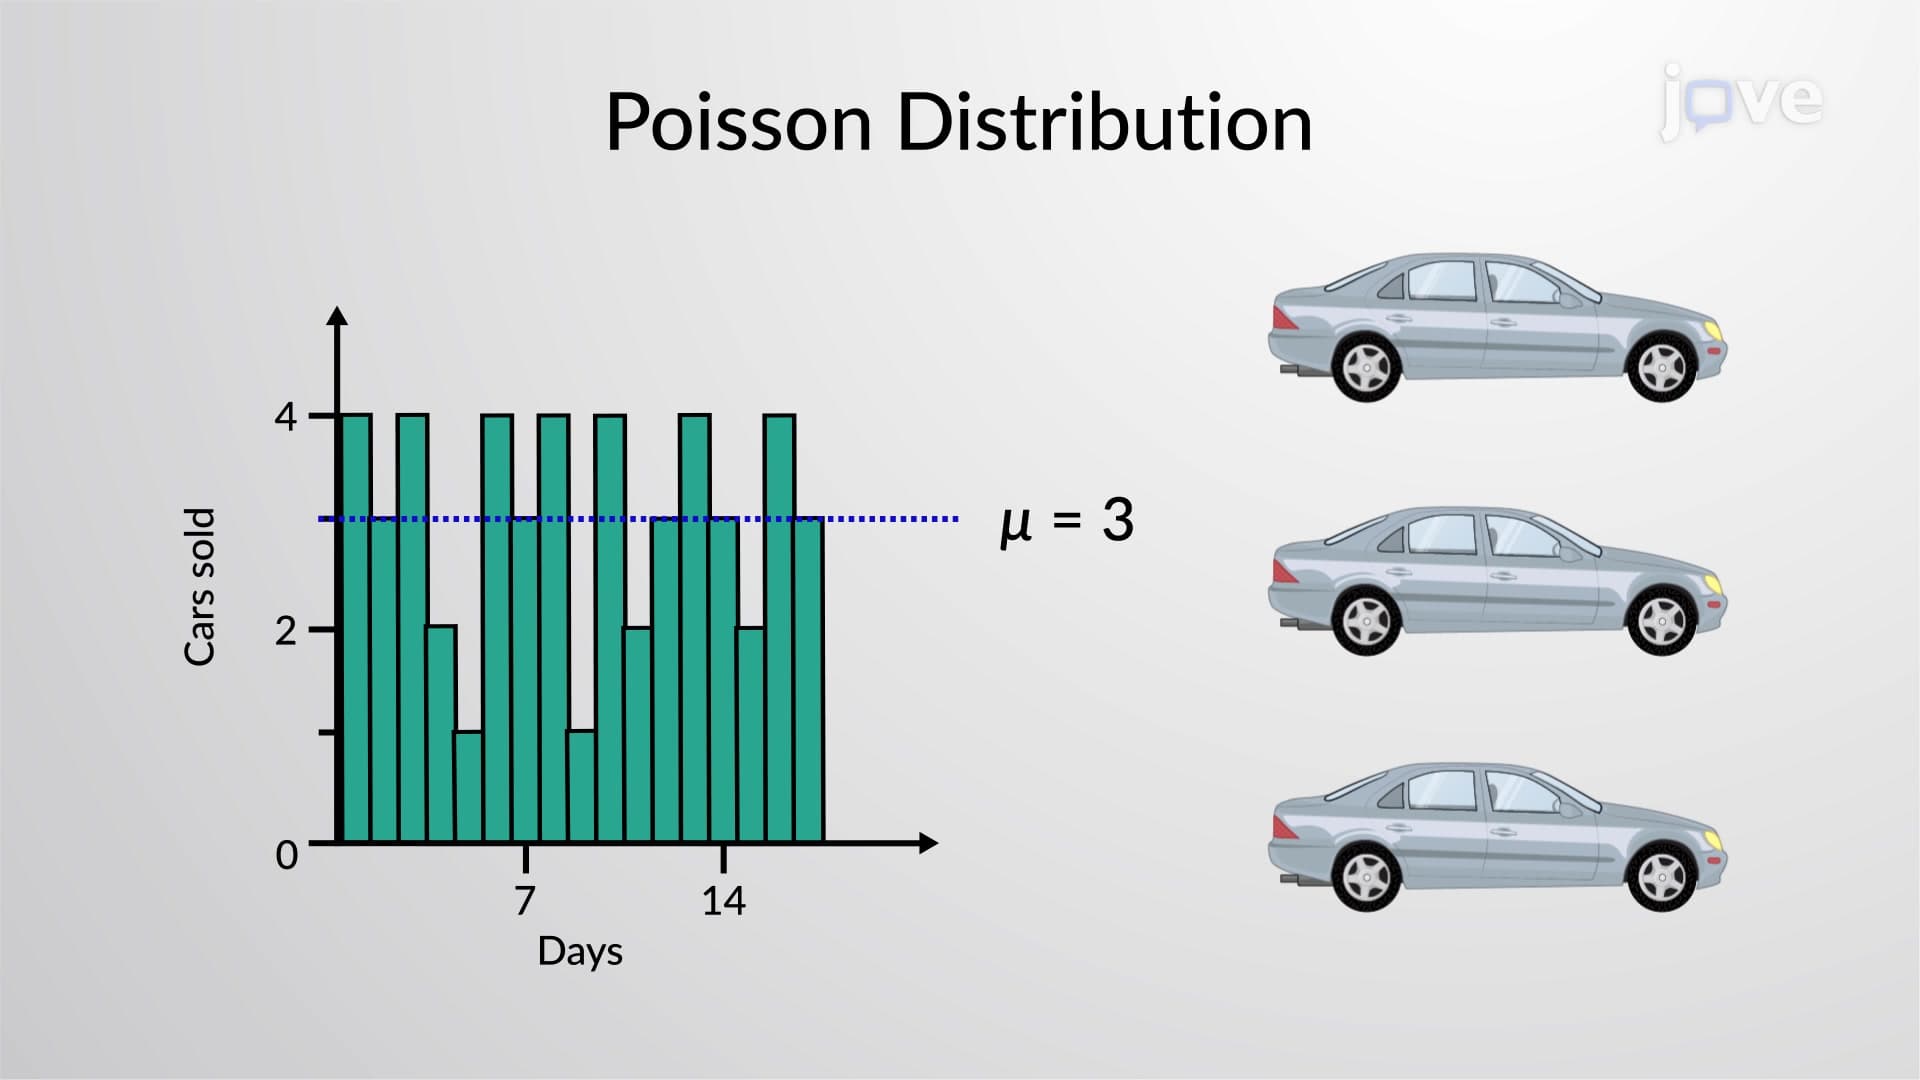
Poisson Probability Distribution
The...
 01:10
Propagation of Uncertainty from Systematic Error
 00:59
Propagation of Uncertainty from Random Error
 01:14
Probability in Statistics
An example of a simple event is a coin toss. The result of a coin toss is either a head or a tail. Here, head and tail are two simple events. These two simple events make up the sample space. Further, the probability of an event occurring falls within the range of 0 to 1. The probability of an...
 01:10
Entropy Change in Reversible Processes
The statement can be further generalized to prove that entropy is a state function. Take a cyclic process between any two points on a p-V diagram.
 01:32
Probability Distributions
A discrete probability distribution is a probability distribution of discrete random variables. It can be categorized into binomial probability distribution and Poisson...