Related Experiment Video
Updated: Apr 16, 2026


Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Revisiting the body-schema concept in the context of whole-body postural-focal dynamics
Pietro Morasso1, Maura Casadio1, Vishwanathan Mohan2
1Robotics, Brain and Cognitive Sciences Department, Istituto Italiano di Tecnologia , Genoa , Italy ; Dipartimento di Informatica, Bioingegneria, Robotica e Ingegneria dei Sistemi (DIBRIS), University of Genoa , Genoa , Italy.

Abstract:
The body-schema concept is revisited in the context of embodied cognition, further developing the theory formulated by Marc Jeannerod that the motor system is part of a simulation network related to action, whose function is not only to shape the motor system for preparing an action (either overt or covert) but also to provide the self with information on the feasibility and the meaning of potential actions. The proposed computational formulation is based on a dynamical system approach, which is linked to an extension of the equilibrium-point hypothesis, called Passive Motor Paradigm: this dynamical system generates goal-oriented, spatio-temporal, sensorimotor patterns, integrating a direct and inverse internal model in a multi-referential framework. The purpose of such computational model is to operate at the same time as a general synergy formation machinery for planning whole-body actions in humanoid robots and/or for predicting coordinated sensory-motor patterns in human movements. In order to illustrate the computational approach, the integration of simultaneous, even partially conflicting tasks will be analyzed in some detail with regard to postural-focal dynamics, which can be defined as the fusion of a focal task, namely reaching a target with the whole-body, and a postural task, namely maintaining overall stability.
More Related Videos
 06:21
Postural Organization of Gait Initiation for Biomechanical Analysis Using Force Platform Recordings
Published on: July 26, 2022
 11:06
A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:28
Major Somatic Sensory Pathways
 01:21
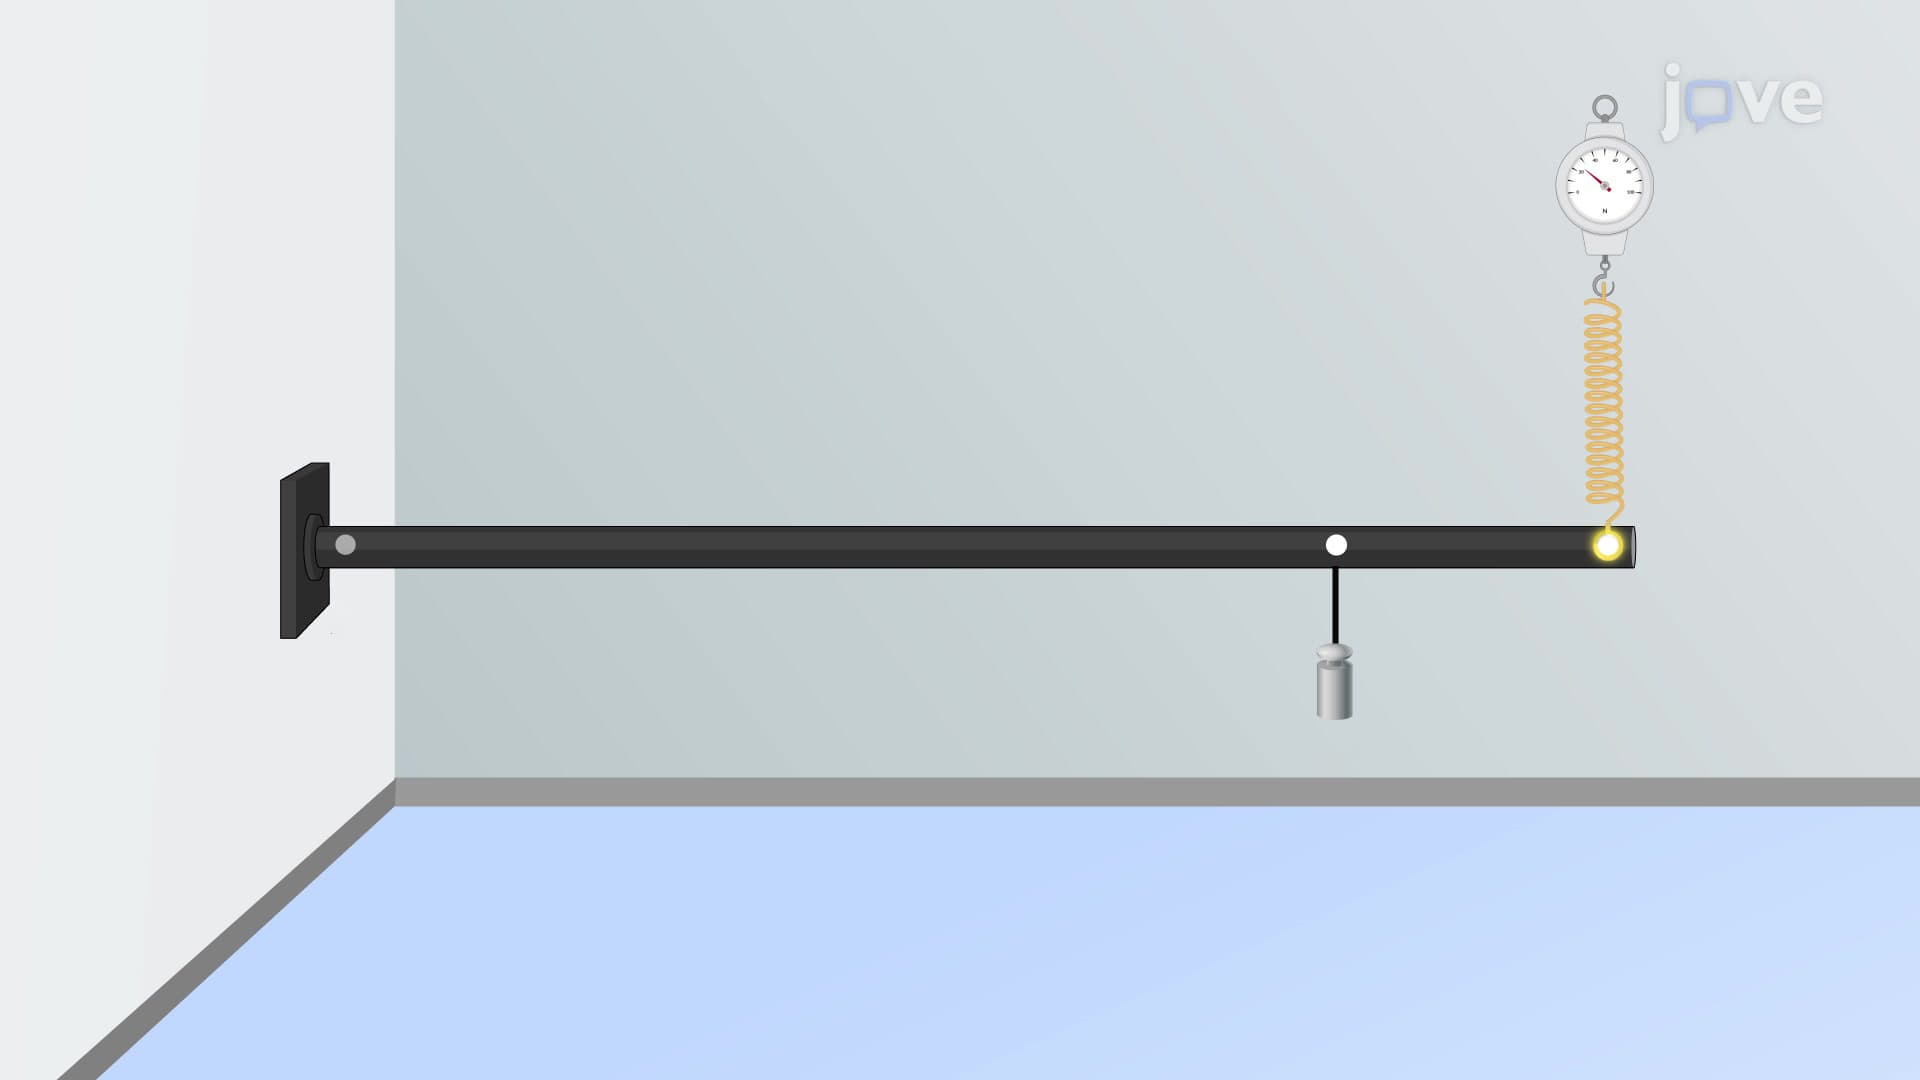
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 00:49
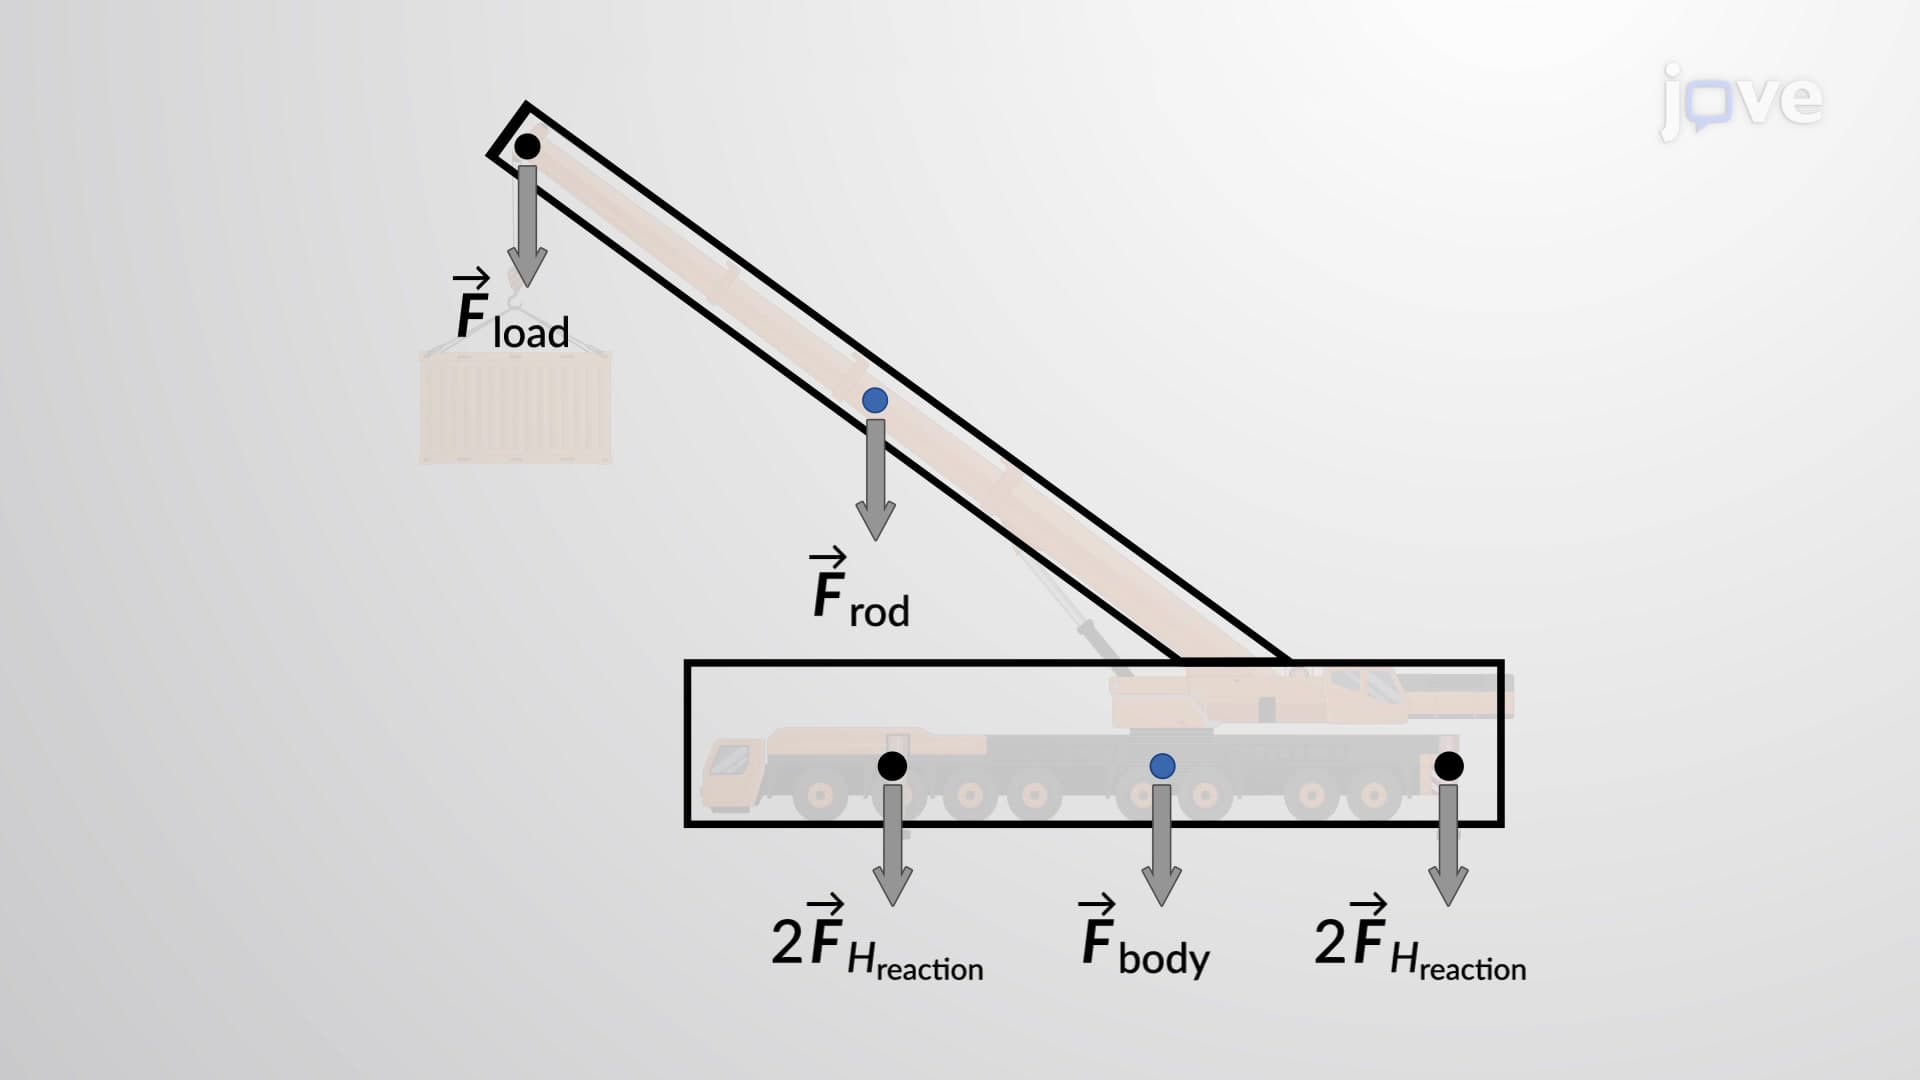
Rigid Body Equilibrium Problems - I
 01:42
Schemas
 01:15
Equilibrium and Balance