Related Experiment Video
Updated: Apr 16, 2026


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Future path and tangent point models in the visual control of locomotion in curve driving
1Cognitive Science Division/Traffic Research Unit, Institute of Behavioural Sciences, University of Helsinki, Helsinki, Finland.

Abstract:
Studying human behavior in the natural context of everyday visual tasks--including locomotor tasks such as driving--can reveal visual strategies or even suggest underlying visual mechanisms. This paper reviews empirical and theoretical work in the past 20 years (1994-2014) on the visual control of steering a vehicle along a winding path-one of the most comprehensively studied forms of visually guided locomotion in humans. The focus is on on-road studies of visual behavior and what they can reveal about the visual strategies in curve driving. Theoretical models and results from simulator studies are discussed where they have direct relevance to the interpretation of on-road data. For the past 20 years, the point of departure in studies of curve driving has been tangent point orientation, and tangent point models (models based on tracking the tangent point) have become established as the default account of how vision is used in curve negotiation. More recent studies have questioned the generality of the tangent point hypothesis, however, arguing that in addition to (or instead of) the tangent point, drivers target visual reference points on their future path. Ecological validity of real-world studies often comes at the cost of methodological challenges that make the data difficult to interpret in terms of underlying mechanisms, and the limitations of existing data and the complementary roles of real-world and laboratory studies are discussed.
More Related Videos

Related Concept Videos
 01:27
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:30
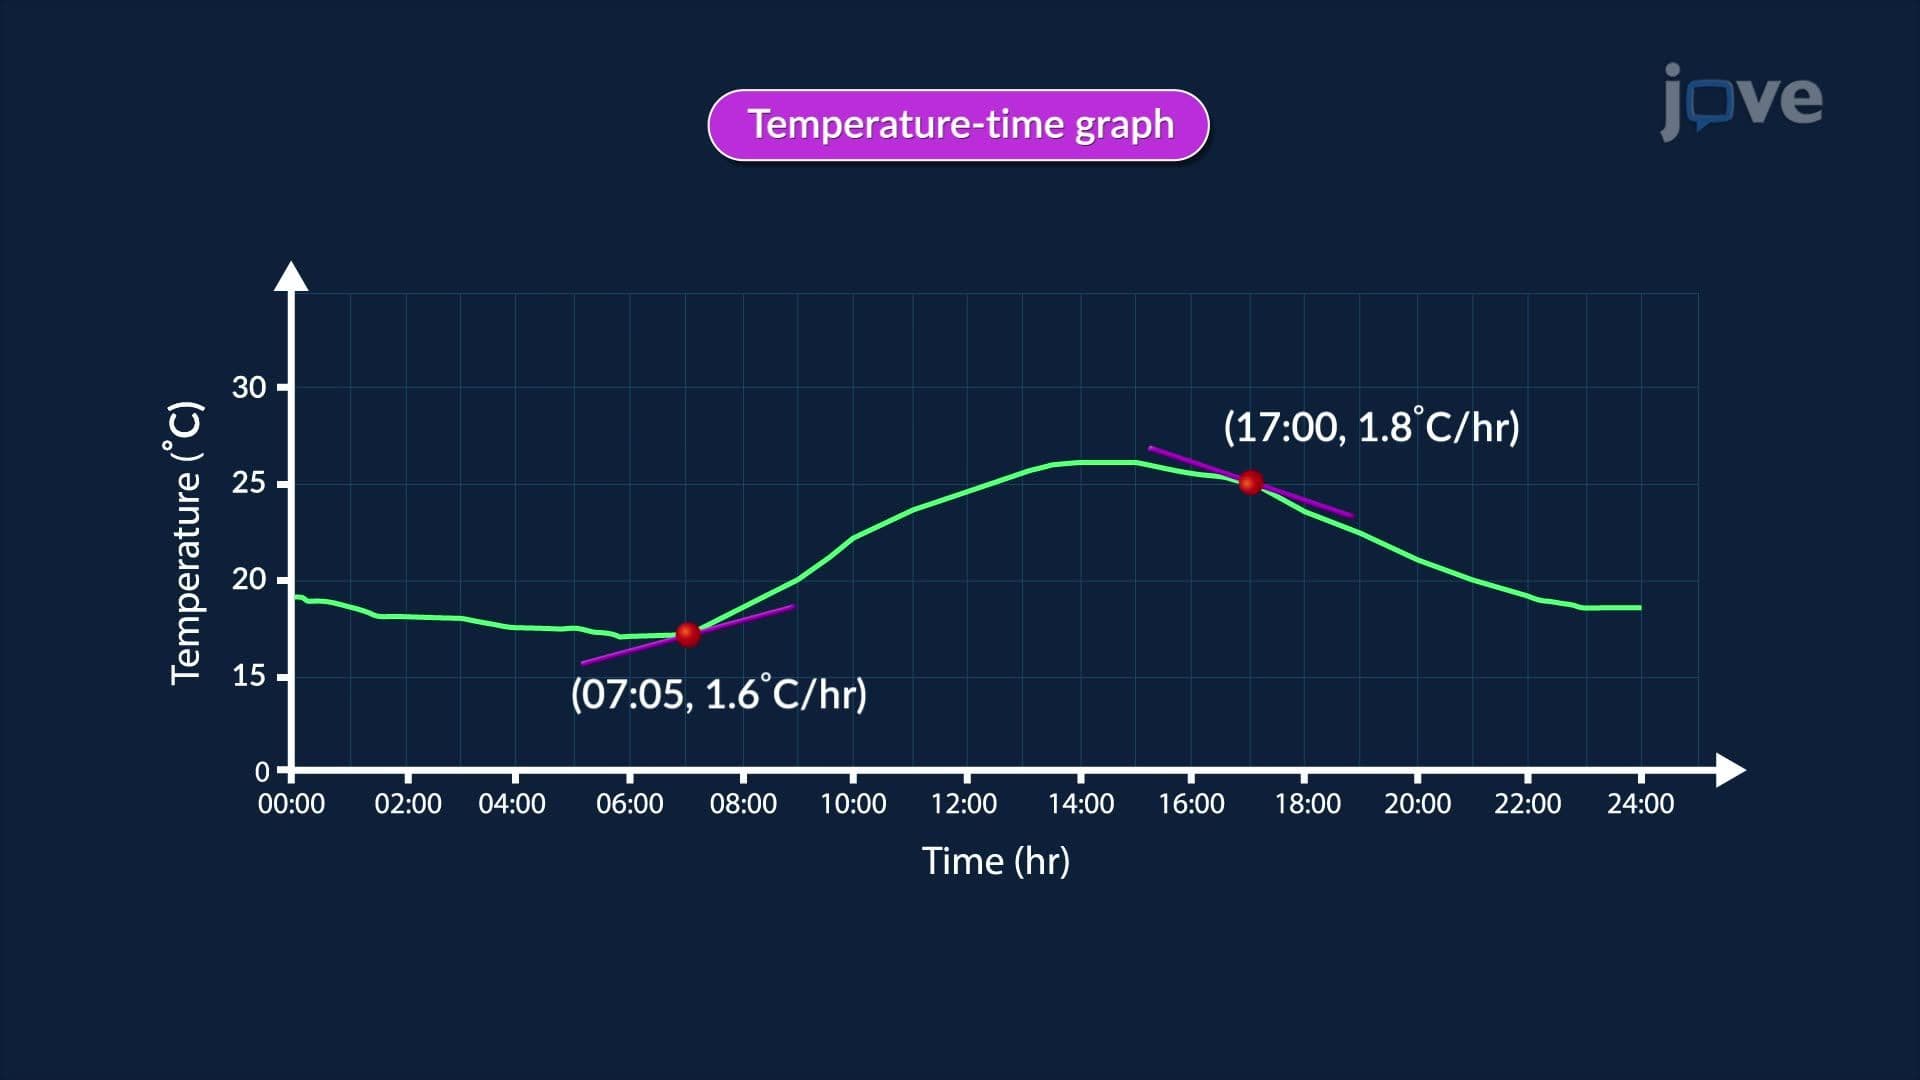
Tangent to a Curve
 01:19
Introduction to Horizontal Curves
 01:19
Root-Locus Method
This system can be represented by a block...
 01:26
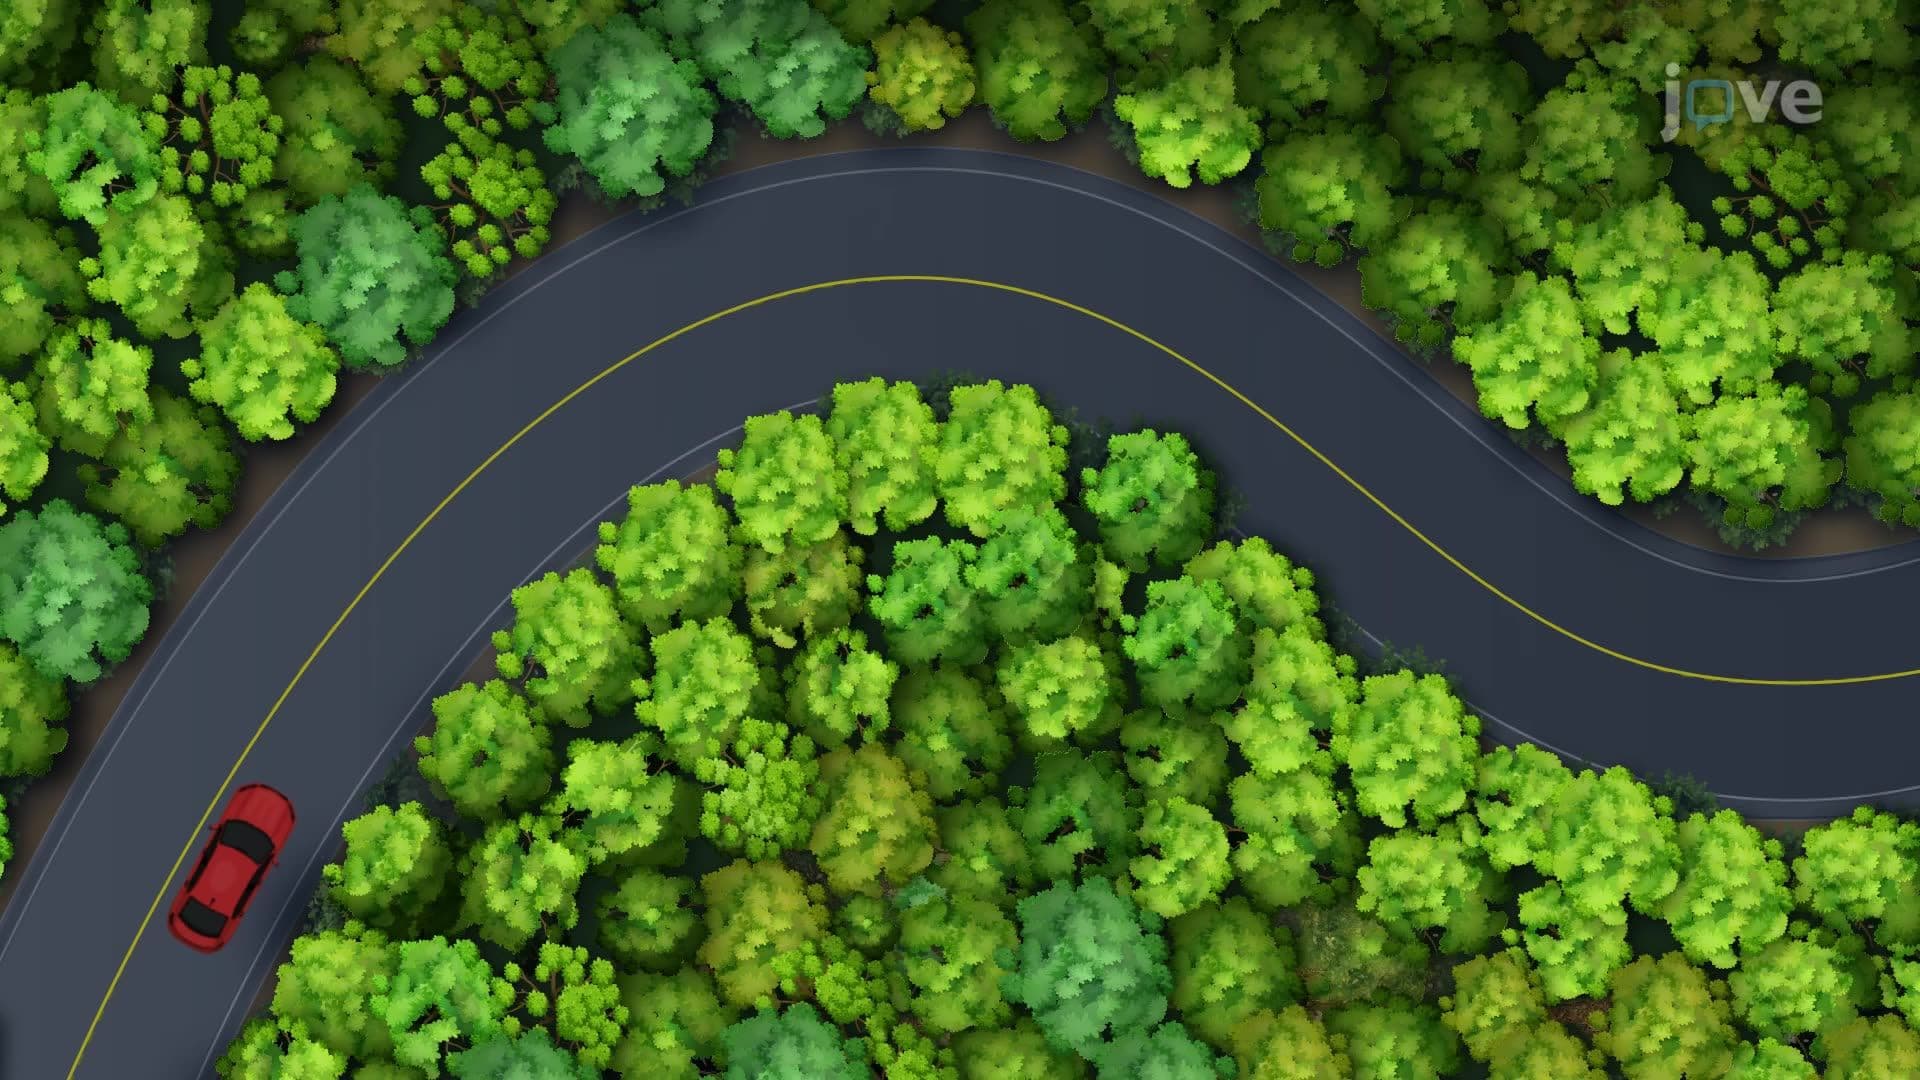
Tangent Line
 01:24
Introduction to Vertical Curves