Probabilistic information on object weight shapes force dynamics in a grip-lift task
Related Experiment Video
Updated: Apr 16, 2026
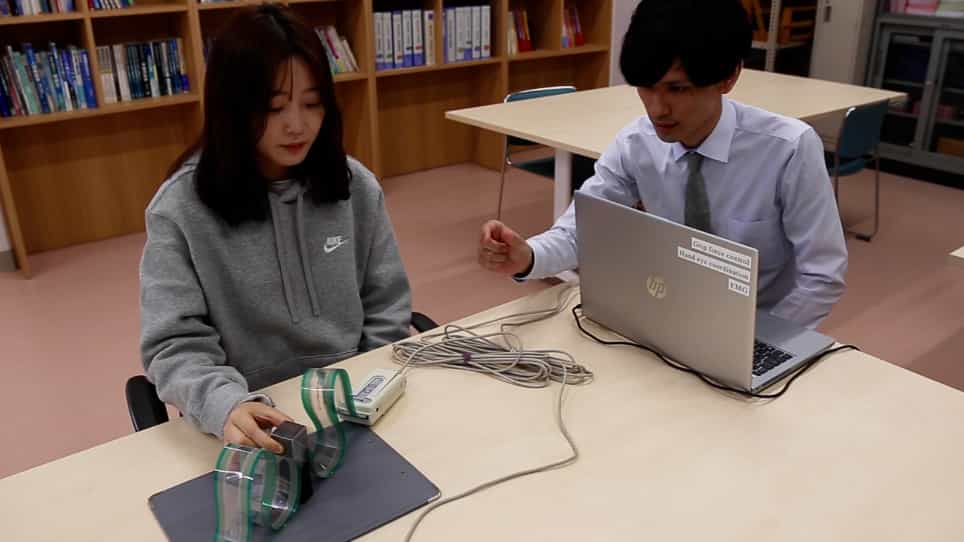
Measurement of Spatial Stability in Precision Grip
Published on: June 4, 2020
Leif Trampenau1, Johann P Kuhtz-Buschbeck, Thilo van Eimeren
1Department of Neurology, Kiel University, Arnold-Heller-Str. 3, 24105, Kiel, Germany.

Abstract:
Advance information, such as object weight, size and texture, modifies predictive scaling of grip forces in a grip-lift task. Here, we examined the influence of probabilistic advance information about object weight. Fifteen healthy volunteers repeatedly grasped and lifted an object equipped with a force transducer between their thumb and index finger. Three clearly distinguishable object weights were used. Prior to each lift, the probabilities for the three object weights were given by a visual cue. We examined the effect of probabilistic pre-cues on grip and lift force dynamics. We expected predictive scaling of grip force parameters to follow predicted values calculated according to probabilistic contingencies of the cues. We observed that probabilistic cues systematically influenced peak grip and load force rates, as an index of predictive motor scaling. However, the effects of probabilistic cues on force rates were nonlinear, and anticipatory adaptations of the motor output generally seemed to overestimate high probabilities and underestimate low probabilities. These findings support the suggestion that anticipatory adaptations and force scaling of the motor system can integrate probabilistic information. However, probabilistic information seems to influence motor programs in a nonlinear fashion.
More Related Videos
 15:00
The Impact of Motor Task Conditions on Goal-Directed Arm Reaching Kinematics and Trunk Compensation in Chronic Stroke Survivors
Published on: May 2, 2021
 07:19
A Modified Lean and Release Technique to Emphasize Response Inhibition and Action Selection in Reactive Balance
Published on: March 19, 2020
Related Concept Videos
 01:30
Machines: Problem Solving II
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:26
Frames: Problem Solving II
 01:17
Rolling Resistance: Problem Solving
 01:05
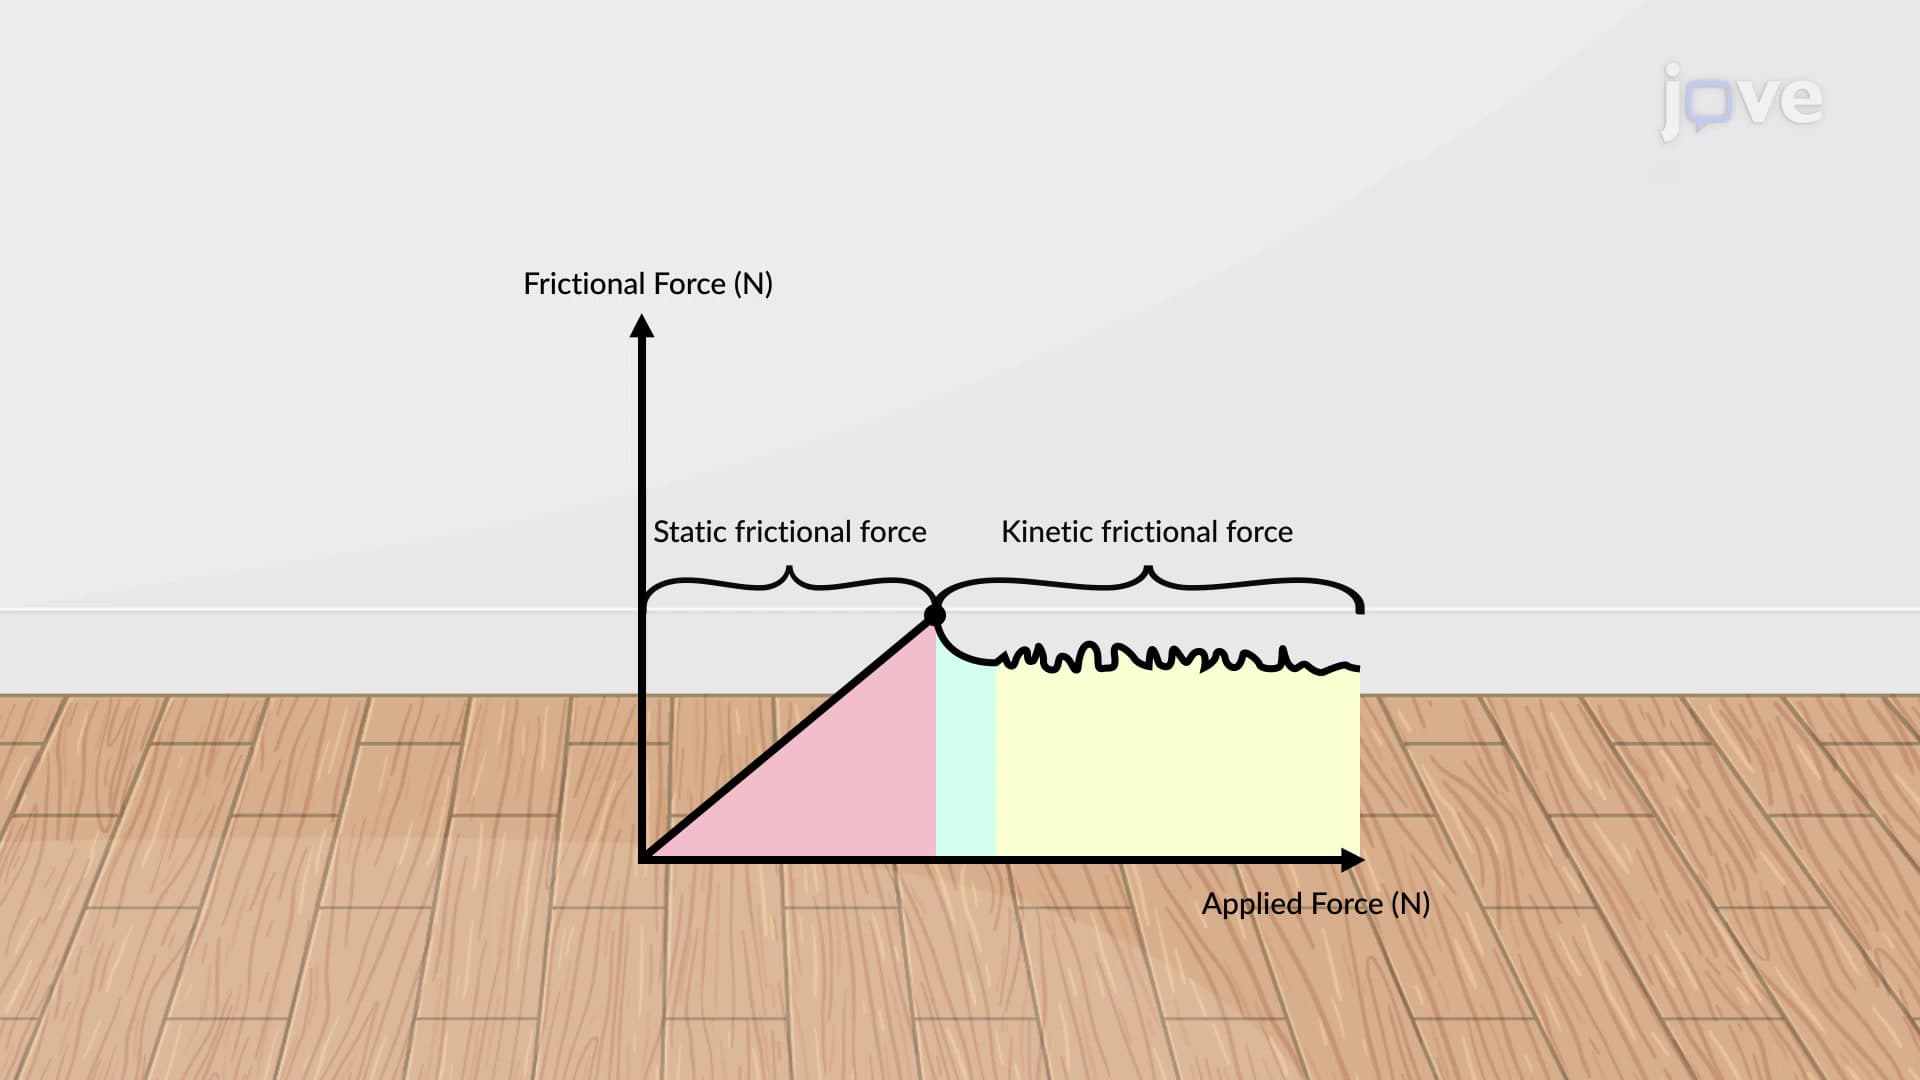
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:30
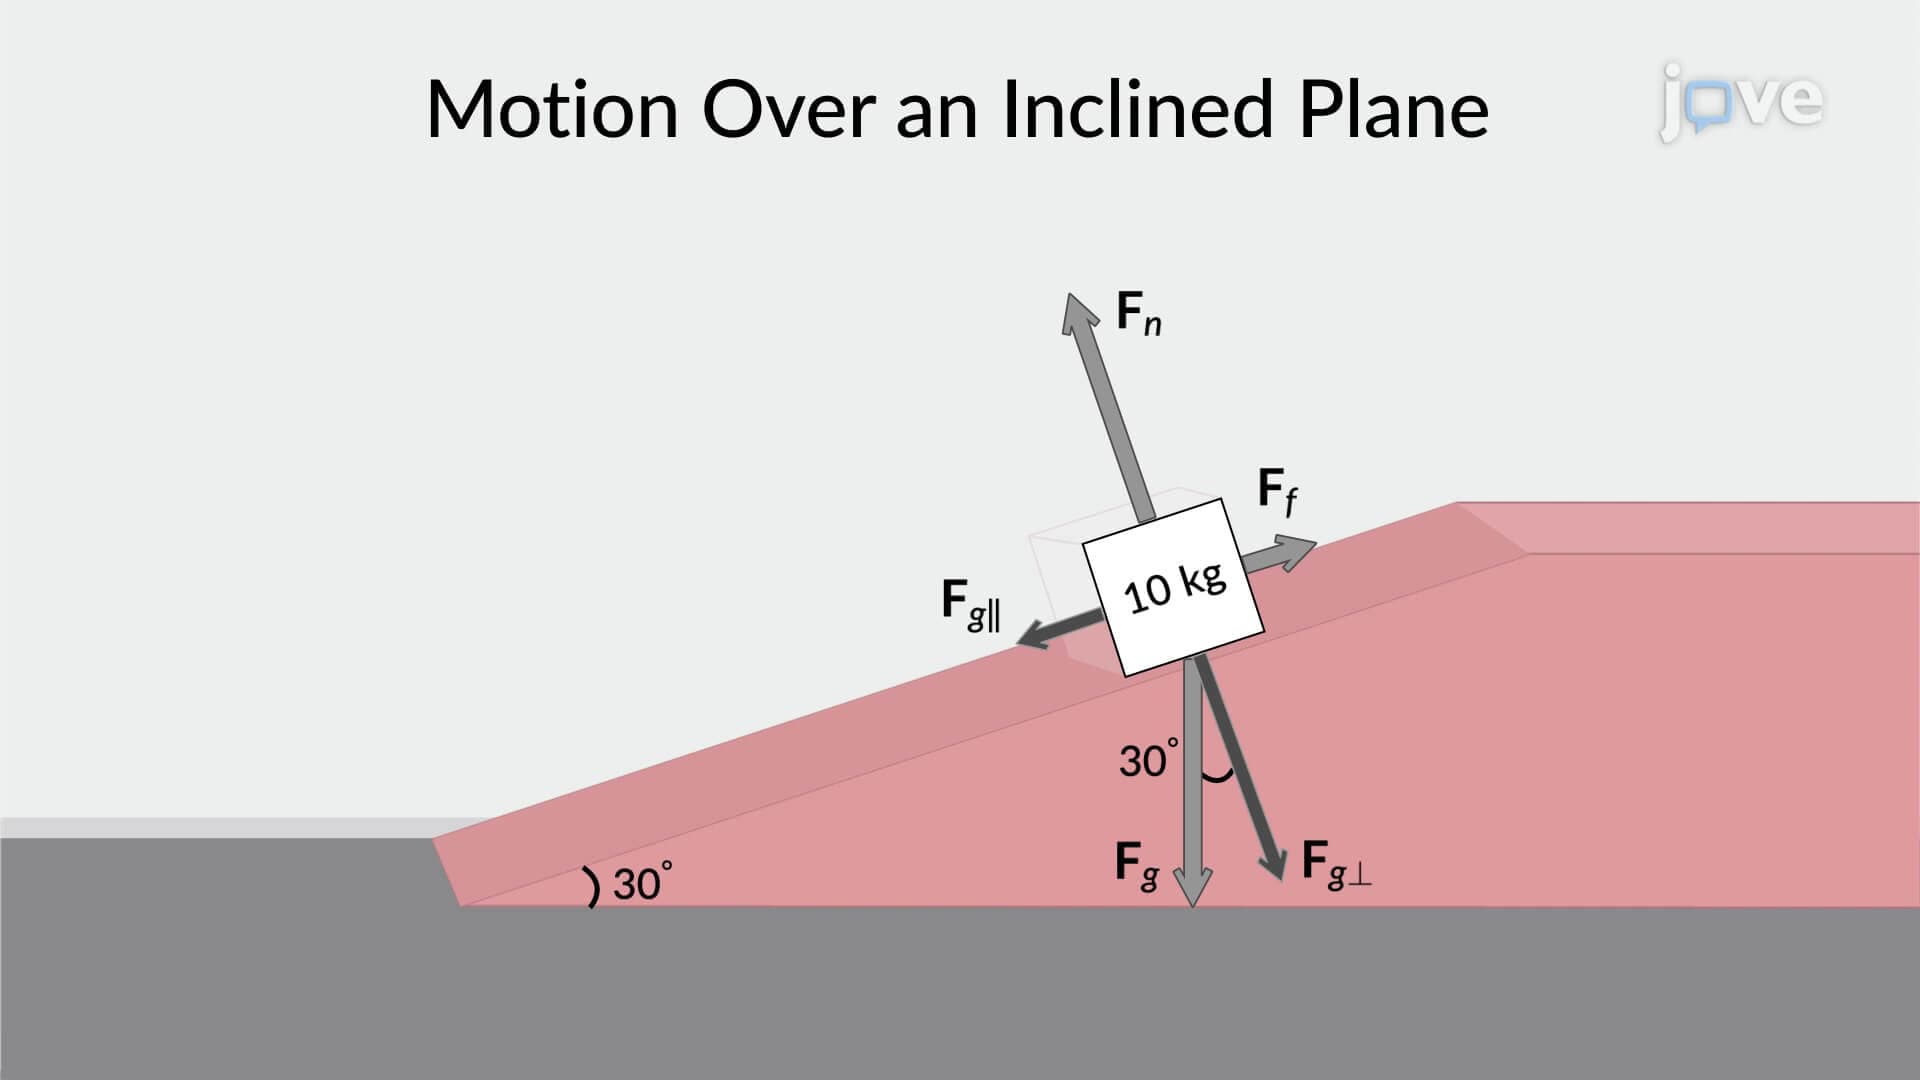
Free-body Diagrams: Problem Solving
For example, consider a block with a mass of 10 kg released on an inclined plane at an angle of 30° to the horizontal, where...