Visual Performance With Small Concave and Convex Displays
Related Experiment Video
Updated: Apr 15, 2026
Development of a Gaze-Contingent Display Framework Designed for Perceptual and Oculomotor Research with Simulated Central Vision Loss
Published on: April 11, 2025
Terhi Mustonen1, Jyrki Kimmel2, Jussi Hakala3
1University of Helsinki, Helsinki, Finland terhi.mustonen@helsinki.fi.

Objective:
In this study, we aim to investigate how users' visual performance with a small flexible display changes based on the direction (i.e., convex, concave) and the magnitude (i.e., low, high) of the display curvature.
Background:
Despite the wide interest in flexible display materials and deformable displays, the potential effects of nonplanar display surfaces on human perception and performance have received little attention. This study is the first to demonstrate how curving affects visual performance with an actual flexible display (4.5-in. active-matrix organic light-emitting diode).
Method:
In a series of three experiments, we compared the performance with a planar display to the performance with concave and convex display surfaces with low and high curvature magnitudes. Two visual search tasks were employed that required the subject to detect target letters based on their contrast (Experiments 1 and 2) and identity (Experiment 3). Performance was measured as the sensitivity of target detection (d') and threshold time of the search, respectively.
Results:
There were similar sensitivities for targets across the curvature variants, but the high-magnitude curvatures resulted in prolonged search times, especially for the convex form. In both of the tasks, performance was dependent on the display location, which was defined as the target's distance from the display center.
Conclusion:
High curvature magnitudes should be avoided, even in small displays, because large local changes in visual stimuli decrease processing speed outside the central display.
Application:
The findings have implications for the development of technologies, applications, and user interfaces for flexible displays and the design of visual display devices.
Related Concept Videos
 01:29
Sight Distance in a Vertical Curve
 01:15
Depth Perception and Spatial Vision
 01:34
Velocity and Position by Graphical Method
 01:24
Convolution: Math, Graphics, and Discrete Signals
To simplify the convolution integral, it is assumed that both the input signal and impulse response are zero for negative time values. The graphical convolution process...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:17
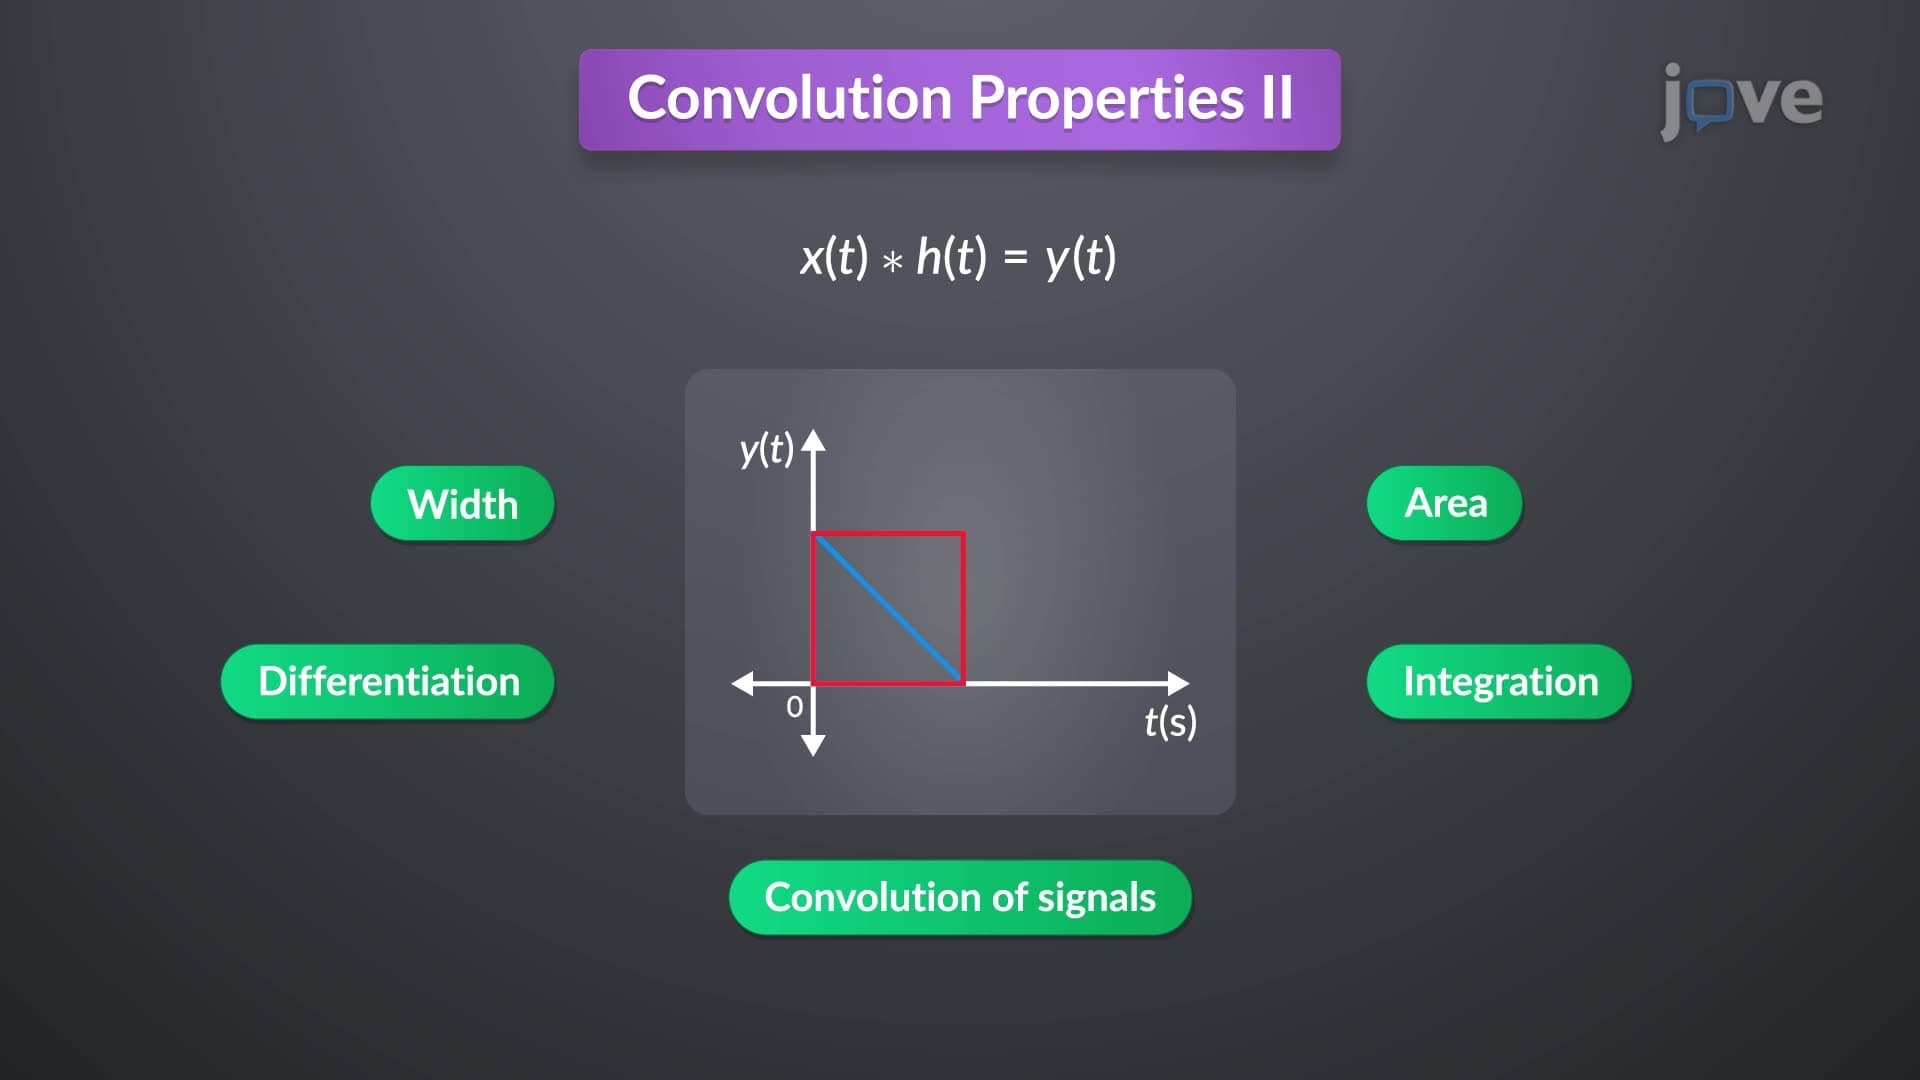
Convolution Properties II
The width property indicates that if the durations of input signals are T1 and T2, then the width of the output response equals the sum of both durations, irrespective of the shapes of the two functions. For instance, convolving two rectangular pulses with durations of 2 seconds and 1 second results in a function with a width of 3 seconds.
The area property asserts that the area under the...