Related Experiment Video
Updated: Apr 14, 2026


Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Lane heading difference: An innovative model for drowsy driving detection using retrospective analysis around curves
Drew M Morris1, June J Pilcher1, Fred S Switzer1
1Department of Psychology, Clemson University, Clemson, SC, USA.

Abstract:
Driving while sleepy is a serious contributor to automobile accidents. Previous research has shown that drowsy drivers produce systematic errors (variability) in vehicle behavior which are detectable using vehicle monitoring technology. The current study developed a new methodological approach using a vehicle heading difference metric to detect drowsy driving more effectively than other more commonly used methods. Twenty participants completed a driving scenario as well as several measures of fatigue in five testing sessions across a night of sleep deprivation. Each simulated highway driving session lasted 20 min, and was analyzed for lateral lane position variability and vehicle heading difference variability with two statistical methods. Fatigue measures monitored reaction time, attention, and oculomotor movement. The results showed that examining lane heading difference using the absolute value of the raw data detected driving variability better across the night than other statistical models. The results from the fatigue measures indicated an increase in reaction time and response lapses, as well as a decrease in oculomotor reactivity across the night. These results suggest that in fatigued drivers the statistical model using the absolute value of lane heading could be an improved metric for drowsy driving detection that could accurately detect detriments in driving ability at lower levels of fatigue.
More Related Videos
Related Concept Videos
 01:29
Sight Distance in a Vertical Curve
 01:19
Introduction to Horizontal Curves
 01:27
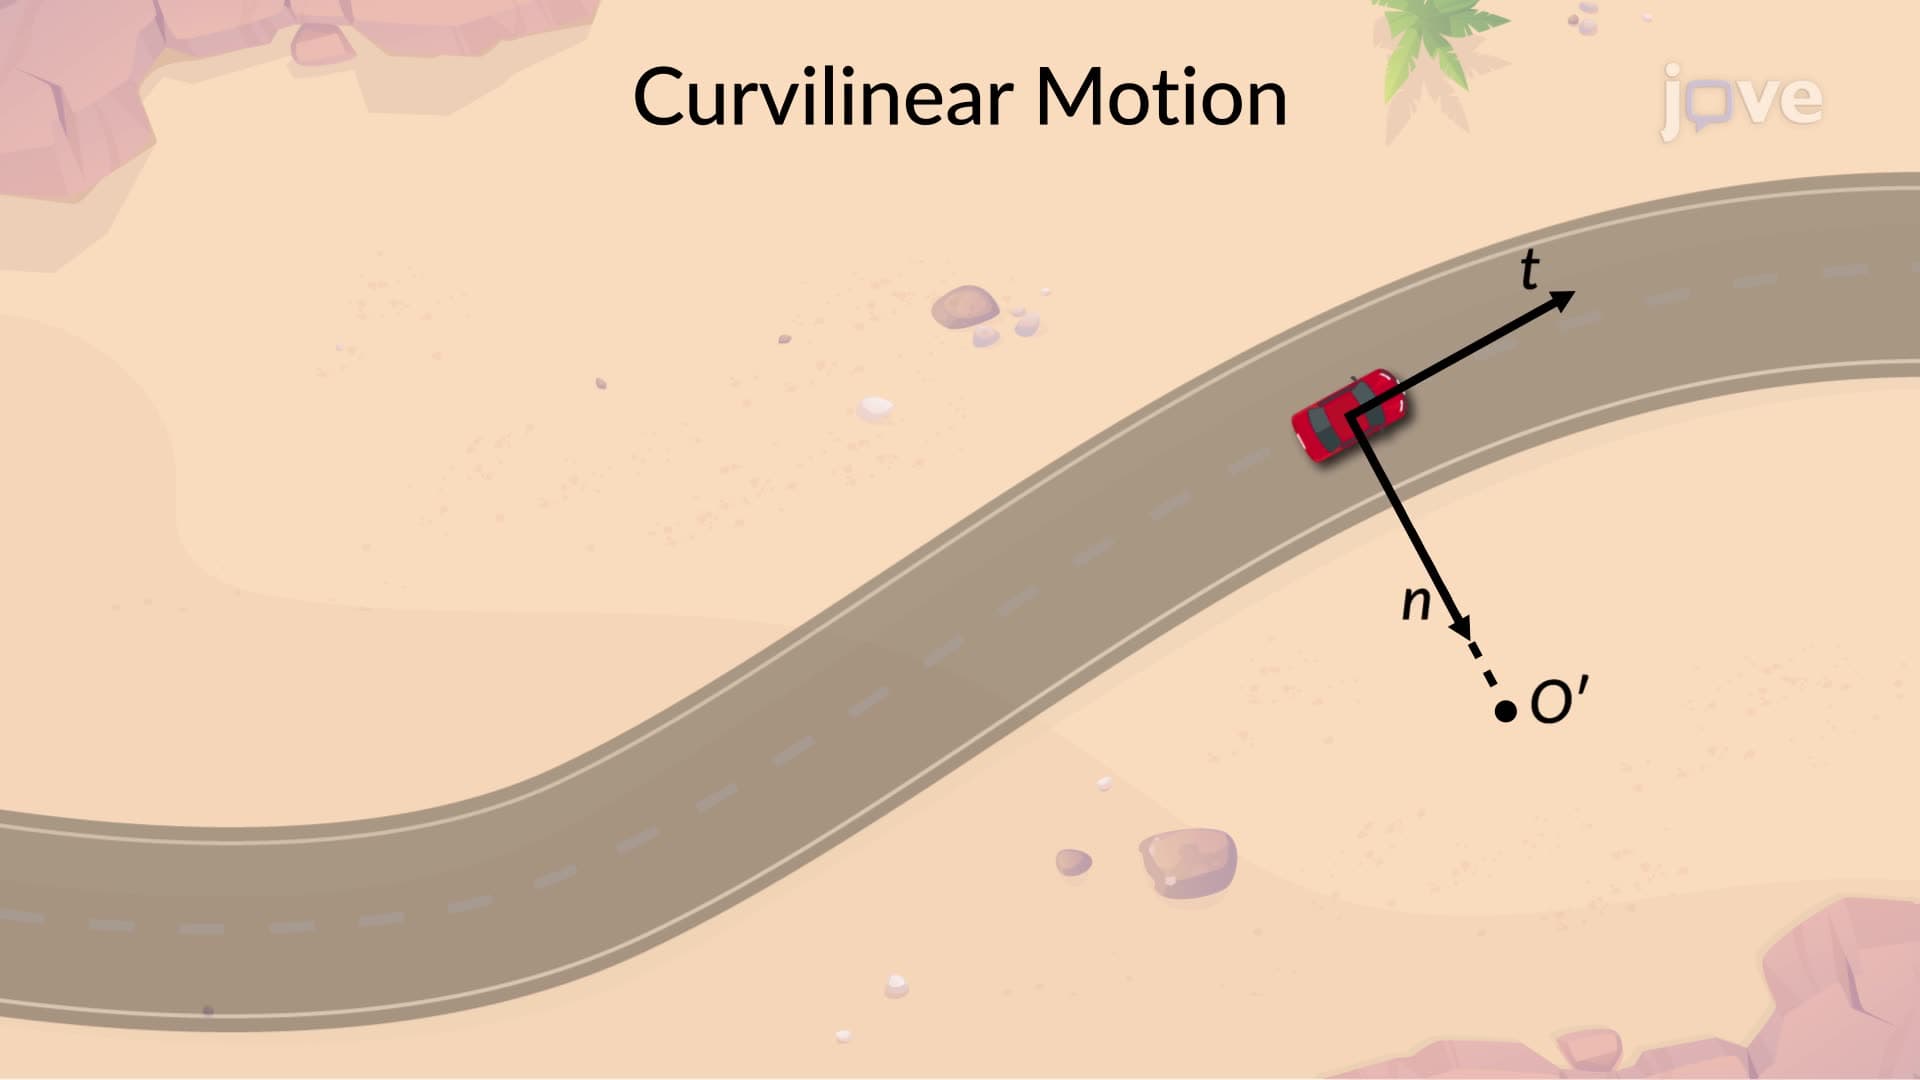
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:24
Introduction to Vertical Curves
 01:20
Elevation of Intermediate Points on Vertical Curves
 01:10
Relative Motion Analysis - Acceleration