A Novel Identification Methodology for the Coordinate Relationship between a 3D Vision System and a Legged Robot
Related Experiment Video
Updated: Apr 14, 2026

Robotized Testing of Camera Positions to Determine Ideal Configuration for Stereo 3D Visualization of Open-Heart Surgery
Published on: August 12, 2021
Xun Chai1, Feng Gao2, Yang Pan3
1State Key Laboratory of Mechanical System and Vibration, Shanghai Jiao Tong University, Shanghai 200240, China. chaixun@sjtu.edu.cn.

Abstract:
Coordinate identification between vision systems and robots is quite a challenging issue in the field of intelligent robotic applications, involving steps such as perceiving the immediate environment, building the terrain map and planning the locomotion automatically. It is now well established that current identification methods have non-negligible limitations such as a difficult feature matching, the requirement of external tools and the intervention of multiple people. In this paper, we propose a novel methodology to identify the geometric parameters of 3D vision systems mounted on robots without involving other people or additional equipment. In particular, our method focuses on legged robots which have complex body structures and excellent locomotion ability compared to their wheeled/tracked counterparts. The parameters can be identified only by moving robots on a relatively flat ground. Concretely, an estimation approach is provided to calculate the ground plane. In addition, the relationship between the robot and the ground is modeled. The parameters are obtained by formulating the identification problem as an optimization problem. The methodology is integrated on a legged robot called "Octopus", which can traverse through rough terrains with high stability after obtaining the identification parameters of its mounted vision system using the proposed method. Diverse experiments in different environments demonstrate our novel method is accurate and robust.
More Related Videos
 05:47
Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
 06:17
Deep-Learning Based Multi-Joint Synchronous Tracking for Objective Quantification of Hindlimb Locomotor Kinematics in Rats
Published on: April 3, 2026
Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:30
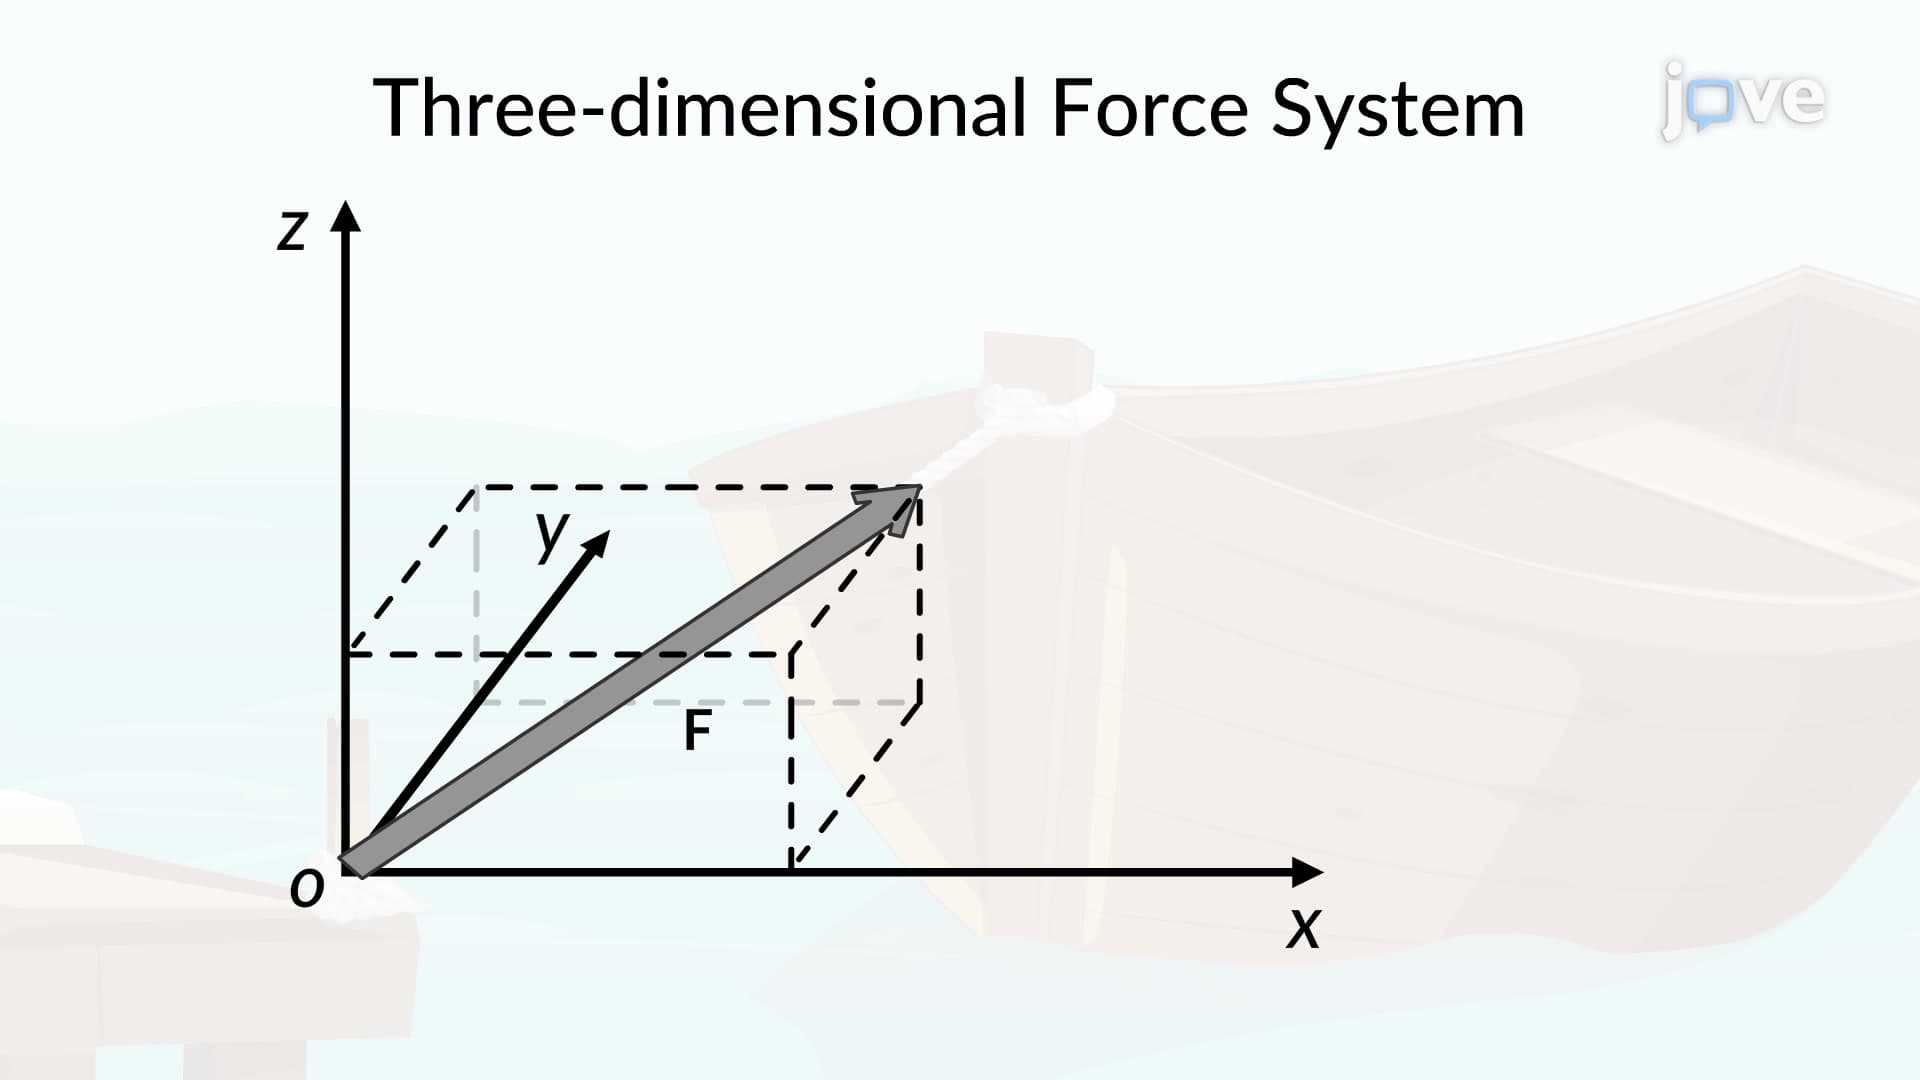
Three-Dimensional Force System
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:30
Equations of Equilibrium in Three Dimensions
According to the vector equations of equilibrium, the vector sum of all the external forces acting on a body must...