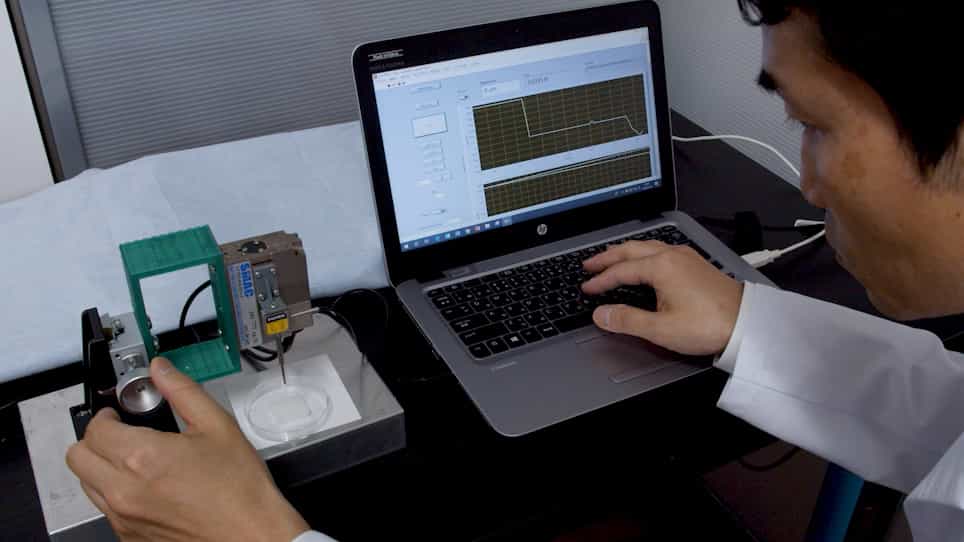
Related Experiment Video
Updated: Apr 12, 2026

A Teleoperated Robotic System-Assisted Percutaneous Transiliac-Transsacral Screw Fixation Technique
Published on: January 6, 2023
Retracting Soft Tissue in Minimally Invasive Hip Arthroplasty Using a Robotic Arm: A Comparison Between a Semiactive
David Putzer1, Sebastian Klug2, Matthias Haselbacher2
1Innsbruck Medical University, Innsbruck, Austria david.putzer@i-med.ac.at.

Background:
All surgical procedures in orthopedics involve the retraction of soft tissue. In this study, the performance of 3 assistants holding the medial retractor during minimally invasive hip arthroplasty was compared with a semiactive retractor holder in a cadaver setup.
Methods:
A total of 40 measurements on 3 cadavers were carried out with each subject (3 human, 1 robot) measuring each cadaver 10 times. The retractor was equipped with a sensor array on both sides, to measure variations of the retracting pressures over a 2-minute interval.
Results:
The semiactive retractor holder showed an almost constant performance compared with the test subjects. There was no significant reduction of the applied pressure and almost no variation during the 2-minute interval and across all measurements.
Conclusions:
The performance of the semiactive retractor holder was more stable than that of a human assistant, making it suitable for intraoperative usage.