Multi-parameter prediction of drivers' lane-changing behaviour with neural network model
Related Experiment Video
Updated: Apr 12, 2026
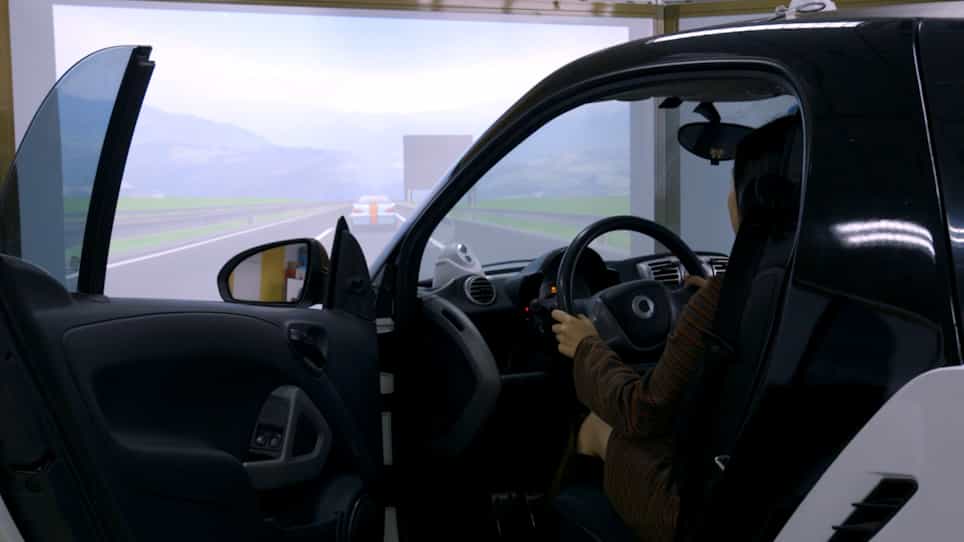
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Jinshuan Peng1, Yingshi Guo2, Rui Fu2
1Chongqing Key Lab of Traffic System & Safety in Mountain Cities, Chongqing Jiaotong University, Chongqing 400074, China.

Abstract:
Accurate prediction of driving behaviour is essential for an active safety system to ensure driver safety. A model for predicting lane-changing behaviour is developed from the results of naturalistic on-road experiment for use in a lane-changing assistance system. Lane changing intent time window is determined via visual characteristics extraction of rearview mirrors. A prediction index system for left lane changes was constructed by considering drivers' visual search behaviours, vehicle operation behaviours, vehicle motion states, and driving conditions. A back-propagation neural network model was developed to predict lane-changing behaviour. The lane-change-intent time window is approximately 5 s long, depending on the subjects. The proposed model can accurately predict drivers' lane changing behaviour for at least 1.5 s in advance. The accuracy and time series characteristics of the model are superior to the use of turn signals in predicting lane-changing behaviour.