Related Experiment Video
Updated: Apr 10, 2026

Design and Characterization Methodology for Efficient Wide Range Tunable MEMS Filters
Published on: February 4, 2018
Long-term stability improvement of tunable optoelectronic oscillator using dynamic feedback compensation

Abstract:
We propose and demonstrate a novel method to improve the long-term stability of the wideband tunable optoelectronic oscillator (OEO) where a dynamic compensation scheme is achieved to offset the parameter variation of the fiber. In our method, a 900 MHz calibration signal transmits in the fiber link of the OEO's feedback loop for establishing a servo system which can extract the time delay of the feedback loop. The time delay varies with the external environment because refractive index and length of the fiber fluctuate with ambient temperature variations. Taking the extracted information as the reference, the wavelength of the tunable laser used in the OEO can be controlled precisely and continually to offset the random delay fluctuation in the fiber. Consequently, the long-term stability of the microwave signal generated by the OEO can be optimized. The experiment results show that Allan deviation achieved in 1000-s averaging time is improved more than two orders of magnitude when the tunable OEO worked at 2.4 GHz.
Related Concept Videos
 01:24
Effects of feedback
Feedback significantly modifies the gain of a control system. The gain of a system without feedback is altered by a factor of one plus GH, where G represents...
 01:30
Oscillations In An LC Circuit
 01:17
Design Example: Underdamped Parallel RLC Circuit
Starting with a fixed...
 01:22
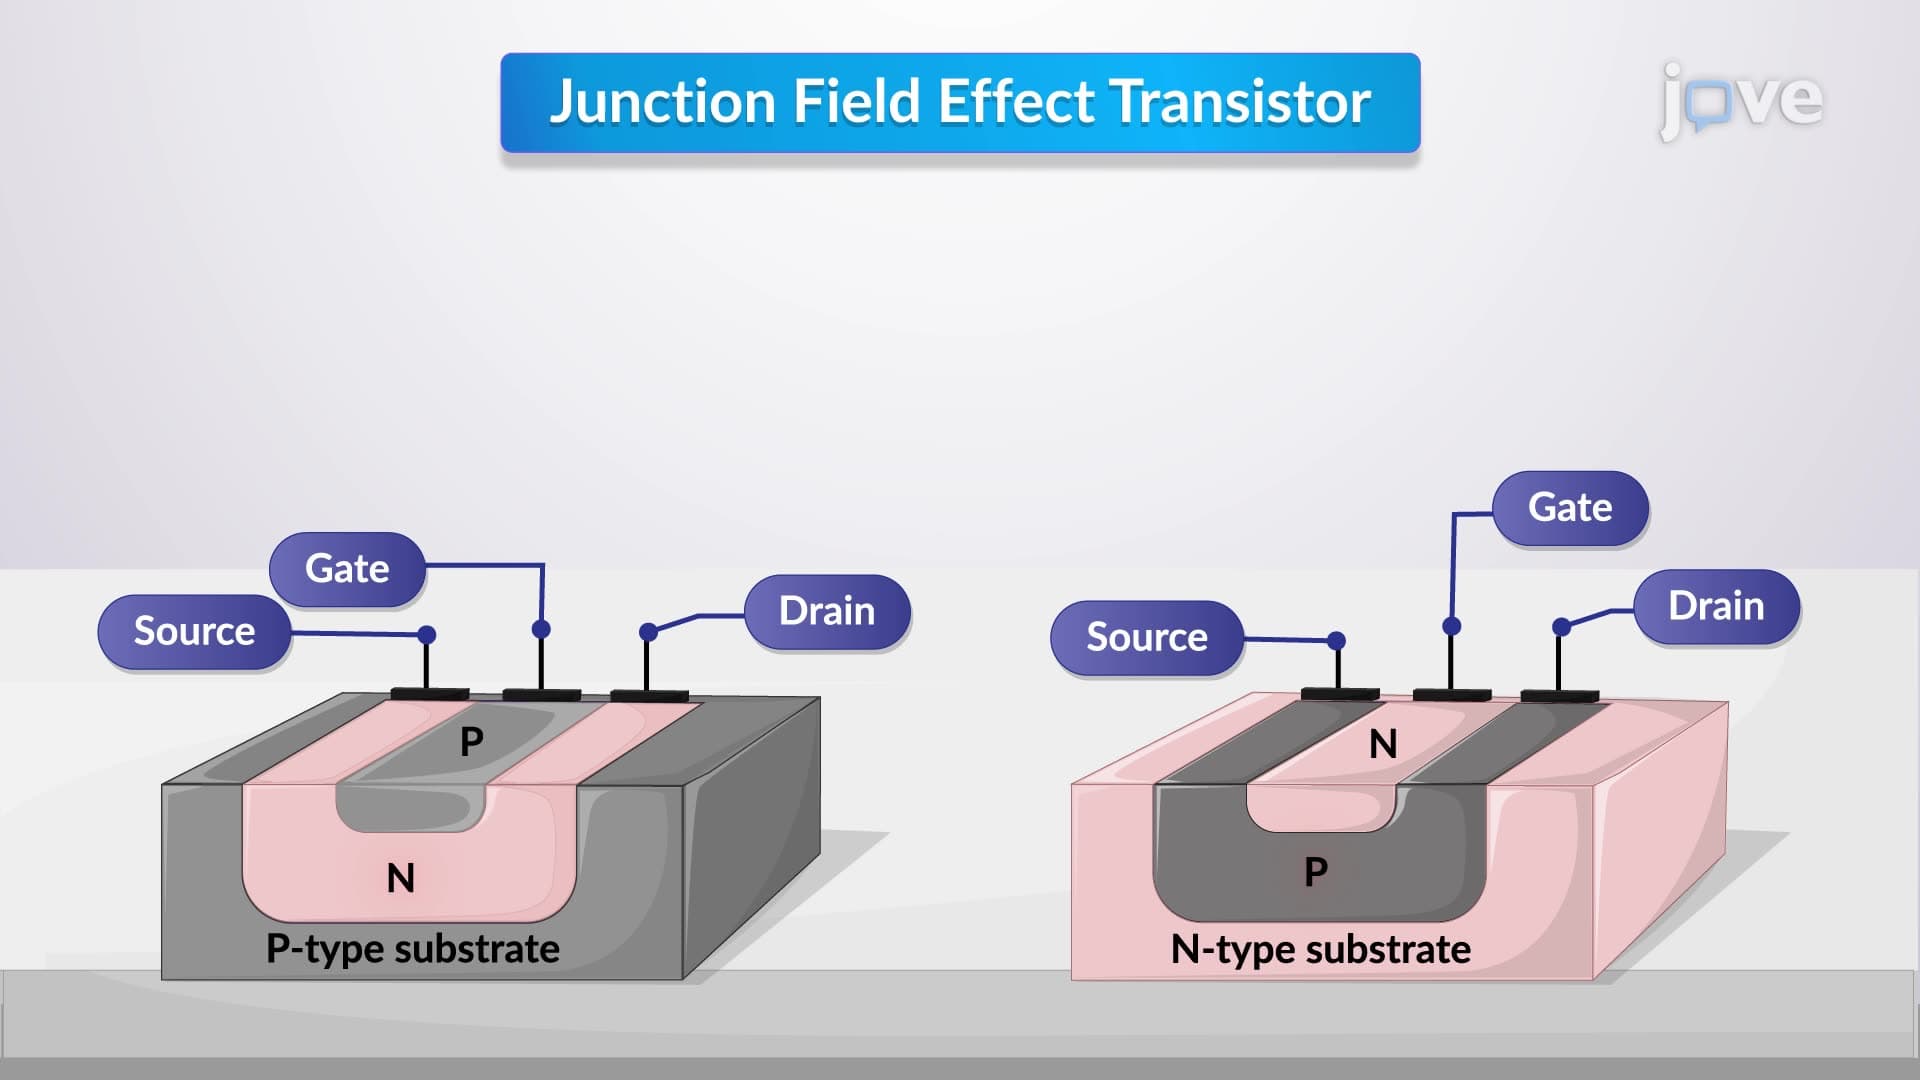
Biasing of FET
In an N-channel JFET, the structure consists of N-type material forming the channel on a P-type substrate, with the...
 01:23
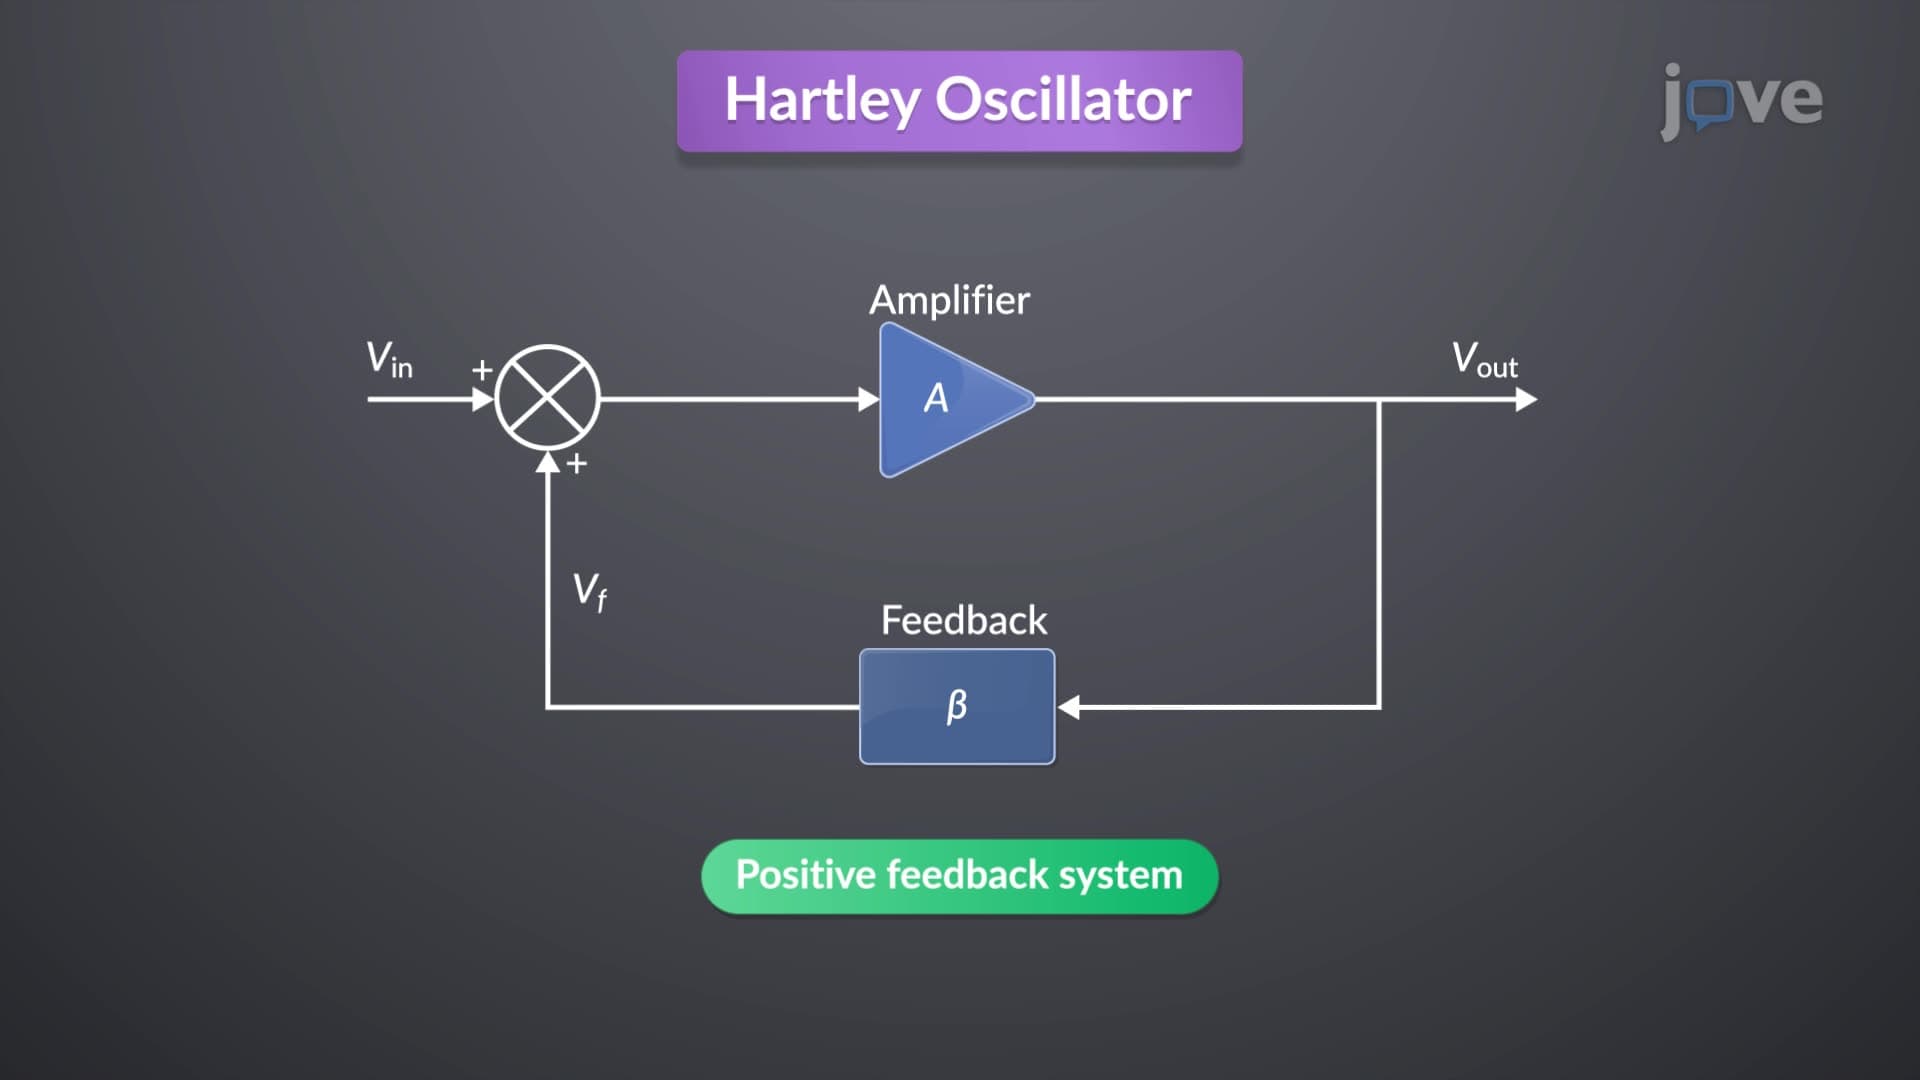
Root Loci for Positive-Feedback Systems
The construction rules for the root locus in positive feedback systems are similar to those in...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...