Related Experiment Video
Updated: Apr 7, 2026

Temporal Ordering of Dynamic Expression Data from Detailed Spatial Expression Maps
Published on: February 9, 2017
Determination of Temporal Order among the Components of an Oscillatory System
Sandra Barragán1, Cristina Rueda1, Miguel A Fernández1
1Departamento de Estadística e Investigación Operativa, Universidad de Valladolid, Valladolid, Spain.

Abstract:
Oscillatory systems in biology are tightly regulated process where the individual components (e.g. genes) express in an orderly manner by virtue of their functions. The temporal order among the components of an oscillatory system may potentially be disrupted for various reasons (e.g. environmental factors). As a result some components of the system may go out of order or even cease to participate in the oscillatory process. In this article, we develop a novel framework to evaluate whether the temporal order is unchanged in different populations (or experimental conditions). We also develop methodology to estimate the order among the components with a suitable notion of "confidence." Using publicly available data on S. pombe, S. cerevisiae and Homo sapiens we discover that the temporal order among the genes cdc18; mik1; hhf1; hta2; fkh2 and klp5 is evolutionarily conserved from yeast to humans.
Related Concept Videos
 01:21
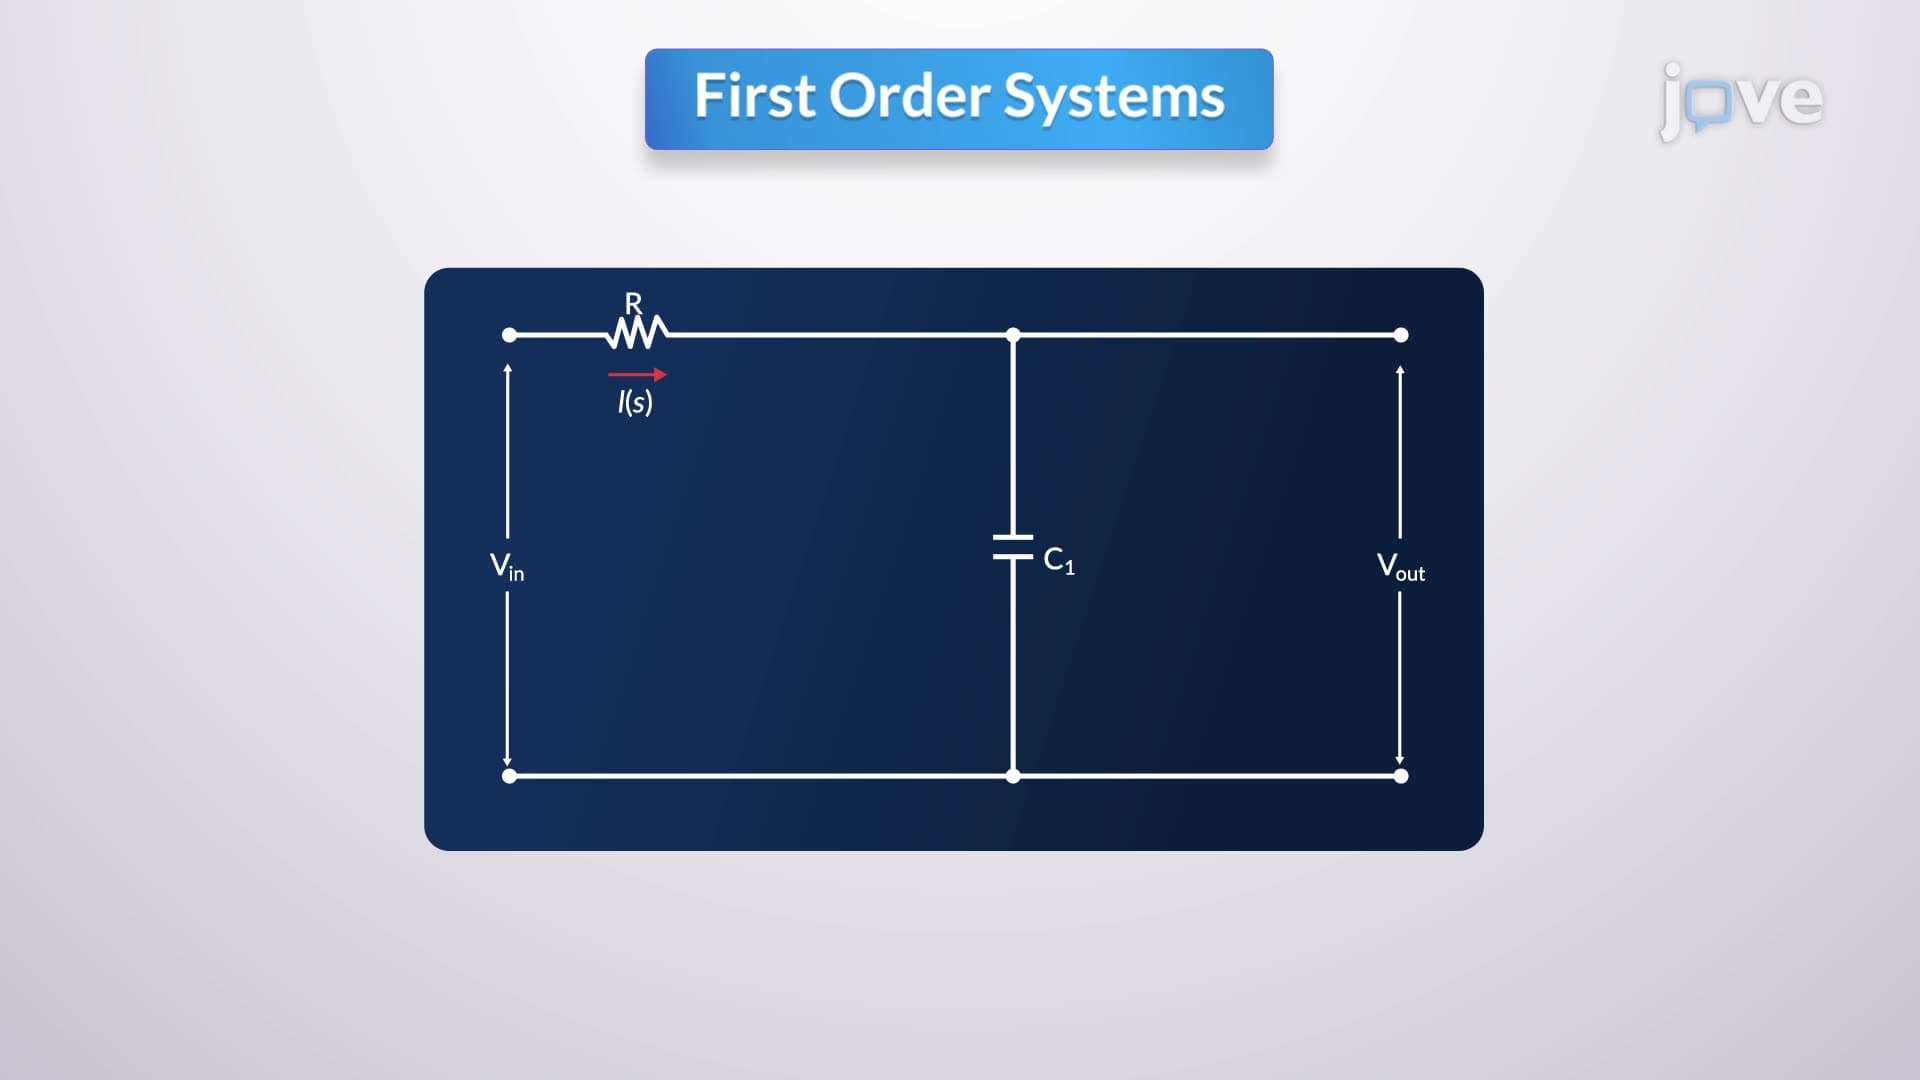
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:18
Second Order systems II
 01:31
Classification of Systems-II
 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:17
Second-Order Circuits
Input signals typically originate from voltage or current sources, with the output often representing voltage across the capacitor and/or current through the inductor. For example, in...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...