Related Experiment Video
Updated: Apr 6, 2026


An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
An Inertial and Optical Sensor Fusion Approach for Six Degree-of-Freedom Pose Estimation
Changyu He1, Peter Kazanzides2, Hasan Tutkun Sen3
1Beijing Engineering Research Center of Mixed Reality and Advanced Display, School of Optoelectronics, Beijing Institute of Technology, Beijing 100081, China. wosipo007@163.com.

Abstract:
Optical tracking provides relatively high accuracy over a large workspace but requires line-of-sight between the camera and the markers, which may be difficult to maintain in actual applications. In contrast, inertial sensing does not require line-of-sight but is subject to drift, which may cause large cumulative errors, especially during the measurement of position. To handle cases where some or all of the markers are occluded, this paper proposes an inertial and optical sensor fusion approach in which the bias of the inertial sensors is estimated when the optical tracker provides full six degree-of-freedom (6-DOF) pose information. As long as the position of at least one marker can be tracked by the optical system, the 3-DOF position can be combined with the orientation estimated from the inertial measurements to recover the full 6-DOF pose information. When all the markers are occluded, the position tracking relies on the inertial sensors that are bias-corrected by the optical tracking system. Experiments are performed with an augmented reality head-mounted display (ARHMD) that integrates an optical tracking system (OTS) and inertial measurement unit (IMU). Experimental results show that under partial occlusion conditions, the root mean square errors (RMSE) of orientation and position are 0.04° and 0.134 mm, and under total occlusion conditions for 1 s, the orientation and position RMSE are 0.022° and 0.22 mm, respectively. Thus, the proposed sensor fusion approach can provide reliable 6-DOF pose under long-term partial occlusion and short-term total occlusion conditions.
Related Concept Videos
 01:03
Inertial Frames of Reference
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:27
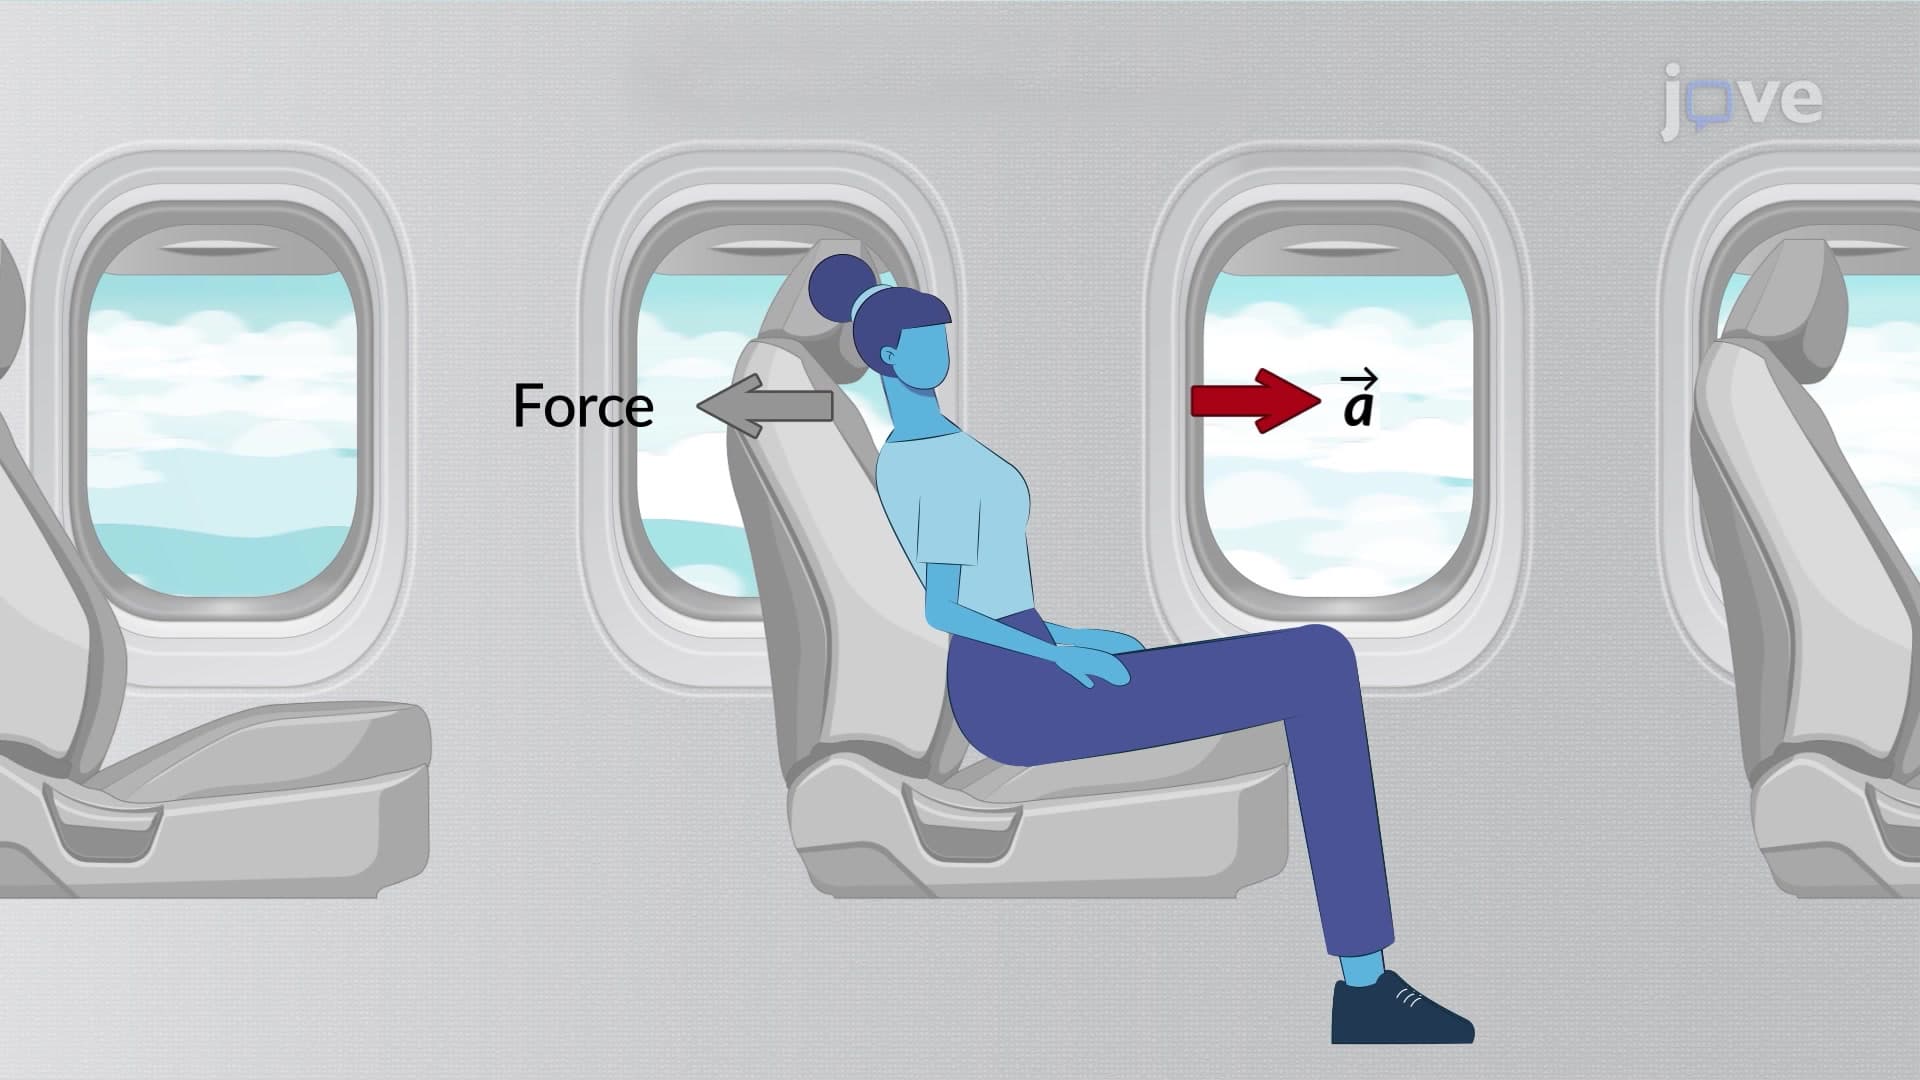
Non-inertial Frames of Reference
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...