Related Experiment Video
Updated: Apr 6, 2026


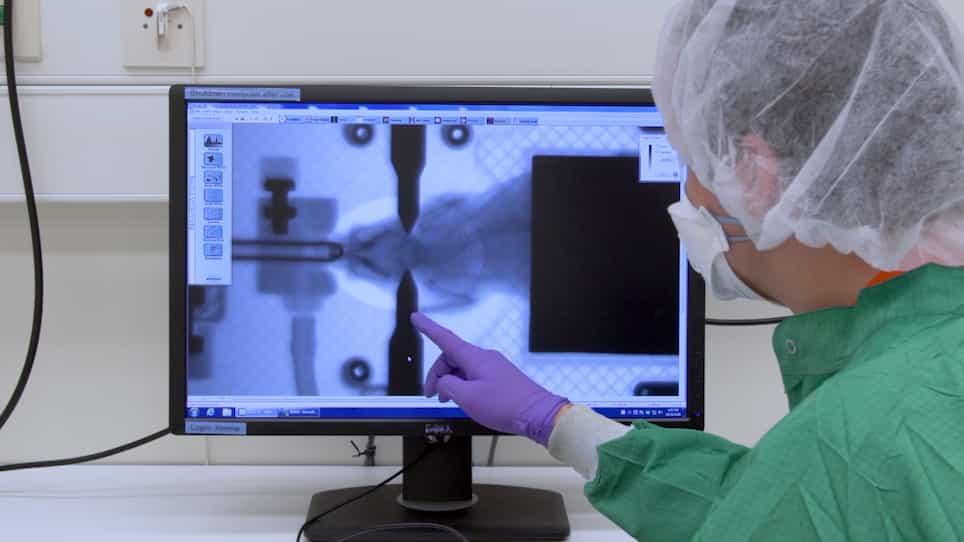
Design and Implementation of a Bespoke Robotic Manipulator for Extra-corporeal Ultrasound
Published on: January 7, 2019
Design, testing and modelling of a novel robotic system for trans-oesophageal ultrasound
Shuangyi Wang1, James Housden1, Davinder Singh2
1Division of Imaging Sciences and Biomedical Engineering, King's College London, UK.

Background:
Trans-oesophageal echocardiography (TOE) has been widely utilized for cardiac disease diagnosis and interventional procedure guidance. However, the TOE operator is required to manually manipulate the probe, often for long periods of time and sometimes in an X-ray environment where there is exposure to ionizing radiation.
Methods:
A novel robotic manipulation system for remote control of commercial TOE probes has been developed and tested. The system has four degrees of freedom (DOFs) and is characterized by a kinematic model. The accuracy of the model and the error propagation were analysed.
Results:
The prototype system was shown to exhibit the required function in terms of the mechanical reliability and range of motion. The forward kinematic model can accurately predict the trajectory of the probe tip movement. The average point-to-point errors were 2.60 mm and 3.55°.
Conclusions:
Robotic assistance provided by the proposed system may improve the TOE operating environment. The proposed forward kinematic model can be further employed for automatic control. Copyright © 2015 John Wiley & Sons, Ltd.
More Related Videos

Related Concept Videos
 01:25
Ultrasound II: Endoscopic Ultrasound and FibroScan
Endoscopic Ultrasound (EUS):
 01:17
Ultrasonography
During an ultrasonography procedure, a handheld device called...