Related Experiment Video
Updated: Apr 5, 2026


Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021
Advancing brain-machine interfaces: moving beyond linear state space models
Adam G Rouse1, Marc H Schieber1
1Department of Neurology, University of Rochester Rochester, NY, USA ; Department of Neurobiology and Anatomy, University of Rochester Rochester, NY, USA ; Department of Biomedical Engineering, University of Rochester Rochester, NY, USA.

Abstract:
Advances in recent years have dramatically improved output control by Brain-Machine Interfaces (BMIs). Such devices nevertheless remain robotic and limited in their movements compared to normal human motor performance. Most current BMIs rely on transforming recorded neural activity to a linear state space composed of a set number of fixed degrees of freedom. Here we consider a variety of ways in which BMI design might be advanced further by applying non-linear dynamics observed in normal motor behavior. We consider (i) the dynamic range and precision of natural movements, (ii) differences between cortical activity and actual body movement, (iii) kinematic and muscular synergies, and (iv) the implications of large neuronal populations. We advance the hypothesis that a given population of recorded neurons may transmit more useful information than can be captured by a single, linear model across all movement phases and contexts. We argue that incorporating these various non-linear characteristics will be an important next step in advancing BMIs to more closely match natural motor performance.

Related Concept Videos
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:21
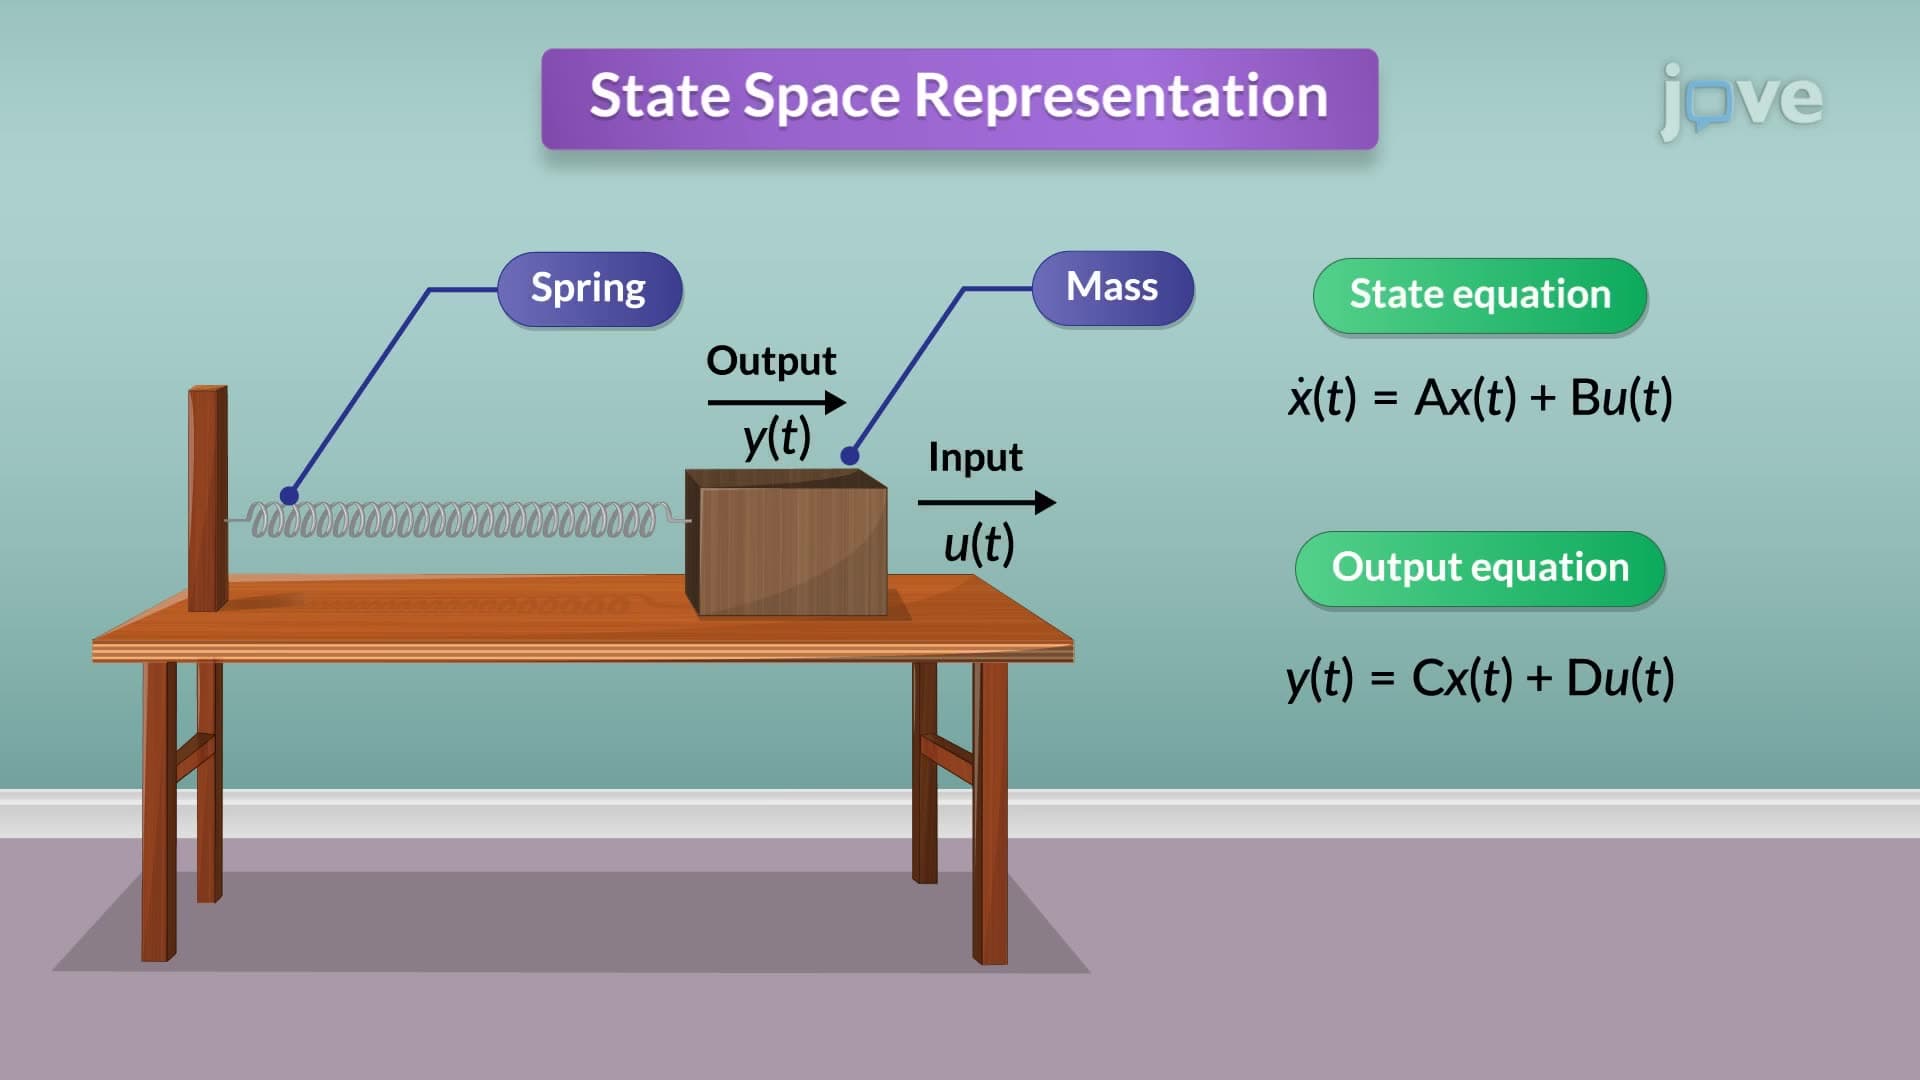
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:23
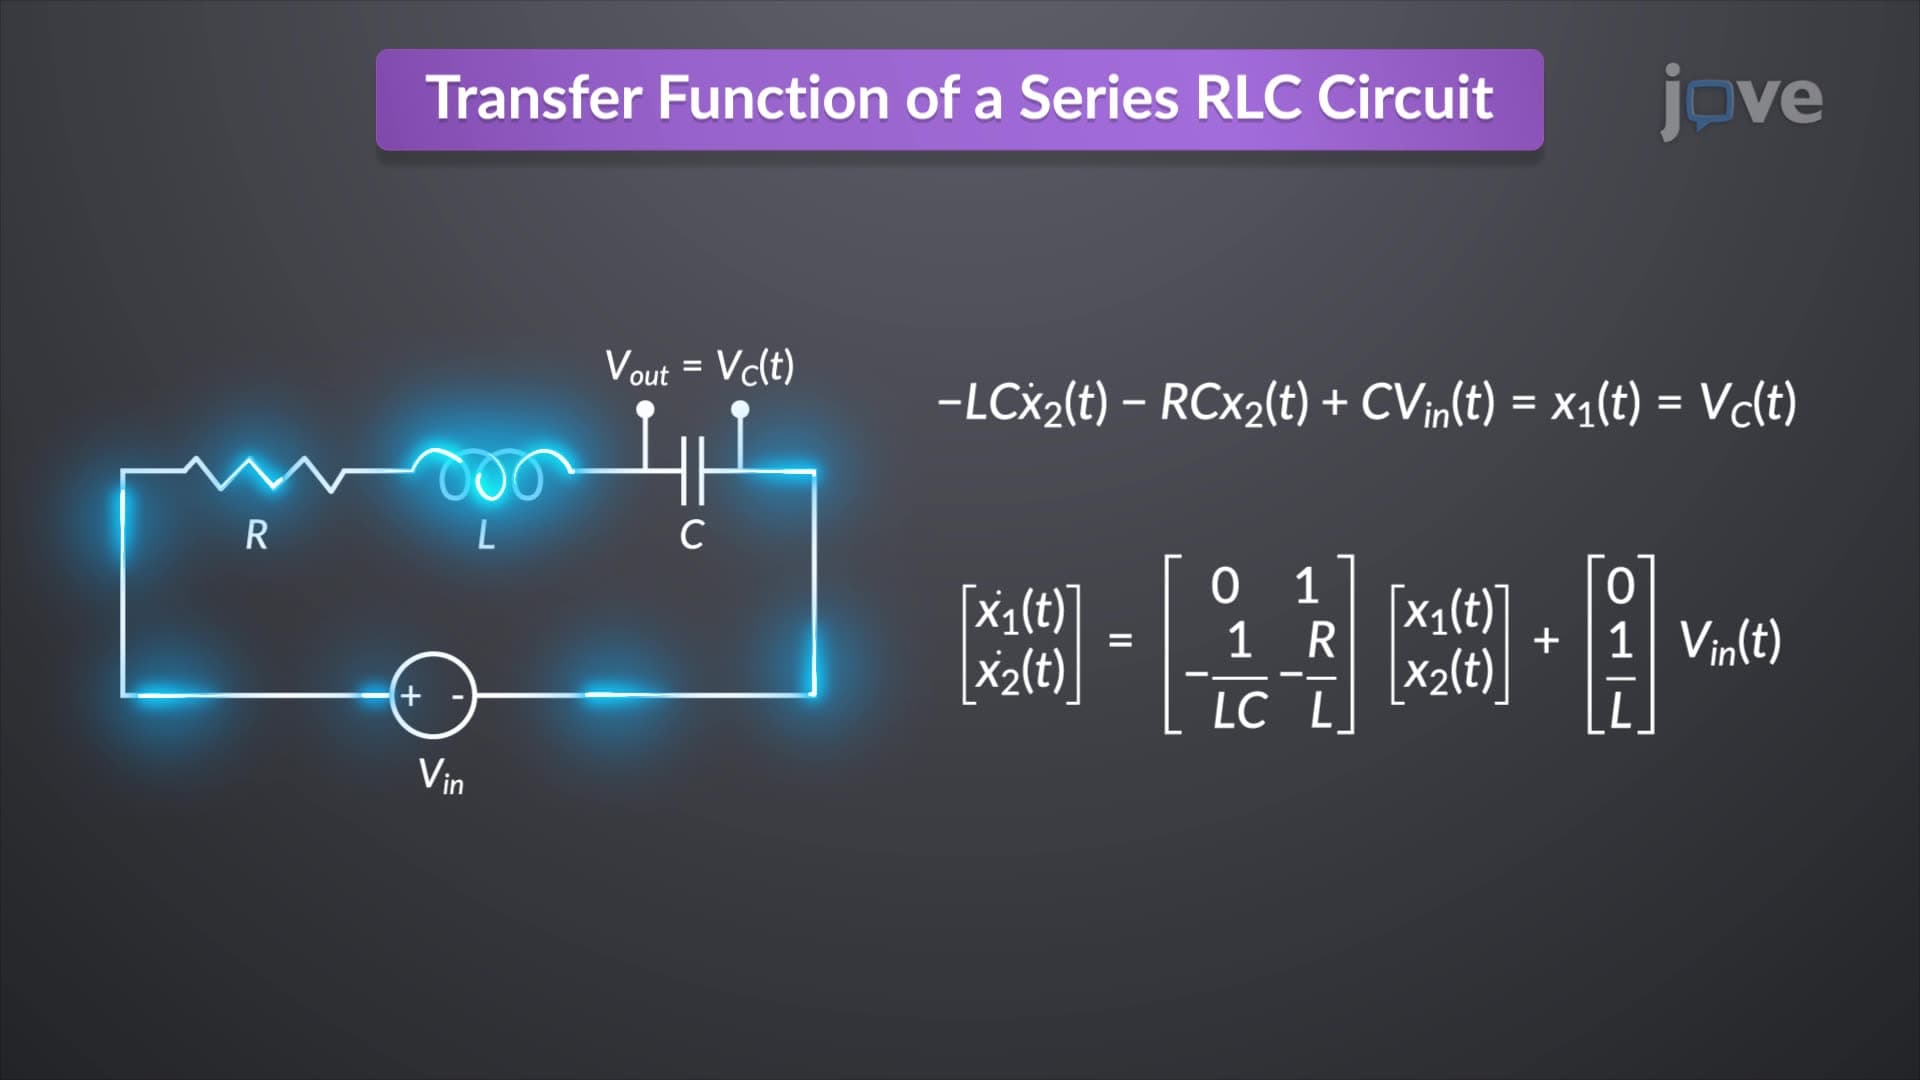
Transfer Function to State Space
In an RLC...
 01:22
Multi-input and Multi-variable systems
In the absence of...