Related Experiment Video
Updated: Apr 4, 2026
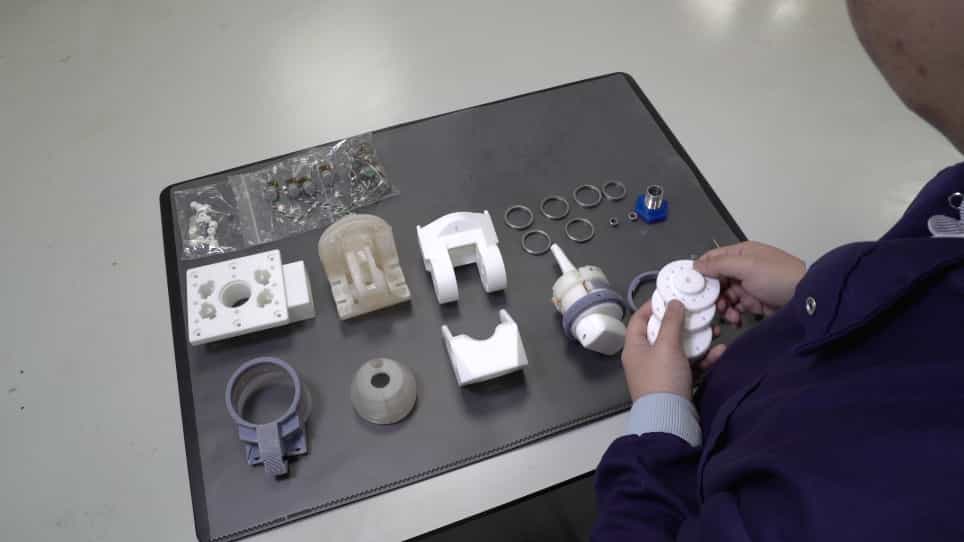
Design and Implementation of a Bespoke Robotic Manipulator for Extra-corporeal Ultrasound
Published on: January 7, 2019
Design, analysis and control of a novel tendon-driven magnetic resonance-guided robotic system for minimally invasive
Shan Jiang1, Jinlong Lou2, Zhiyong Yang2
1Centre for Advanced Mechanisms and Robotics, Tianjin University, Tianjin, China shanjmri@tju.edu.cn.

Abstract:
Biopsy and brachytherapy for small core breast cancer are always difficult medical problems in the field of cancer treatment. This research mainly develops a magnetic resonance imaging-guided high-precision robotic system for breast puncture treatment. First, a 5-degree-of-freedom tendon-based surgical robotic system is introduced in detail. What follows are the kinematic analysis and dynamical modeling of the robotic system, where a mathematic dynamic model is established using the Lagrange method and a lumped parameter tendon model is used to identify the nonlinear gain of the tendon-sheath transmission system. Based on the dynamical models, an adaptive proportional-integral-derivative controller with friction compensation is proposed for accurate position control. Through simulations using different sinusoidal input signals, we observe that the sinusoidal tracking error at 1/2π Hz is 0.41 mm. Finally, the experiments on tendon-sheath transmission and needle insertion performance are conducted, which show that the insertion precision is 0.68 mm in laboratory environment.
More Related Videos
 03:07
Single-Port Robotic-assisted Transaxillary Breast-conserving Surgery: A Prospective, Single-arm, Non-randomized Phase IIa Clinical Trial
Published on: August 19, 2025
 05:57
A Teleoperated Robotic System-Assisted Percutaneous Transiliac-Transsacral Screw Fixation Technique
Published on: January 6, 2023