Spinal and supraspinal mechanisms affecting torque development at different joint angles
Related Experiment Video
Updated: Apr 4, 2026
Quantifying Learning in Young Infants: Tracking Leg Actions During a Discovery-learning Task
Published on: June 1, 2015
Maria Papaiordanidou1, Valérie Mustacchi1, Jean-Damien Stevenot1
1UMR7287, CNRS, Aix-Marseille University, 163 avenue de Luminy, 13288, Marseille, France.

Introduction:
We examined the neural mechanisms responsible for plantar flexion torque changes at different joint positions.
Methods:
Nine subjects performed maximal voluntary contractions (MVC) at 6 ankle-knee angle combinations [3 ankle angles (dorsiflexion, anatomic position, plantar flexion) and 2 knee angles (flexion, full extension)]. Neural mechanisms were determined by V-wave, H-reflex (at rest and during MVC), and electromyography during MVC (RMS), normalized to the muscle compound action potential (V/Msup, Hmax/Mmax, Hsup Msup and RMS/Msup) and voluntary activation (VA), while muscle function was assessed by doublet amplitude.
Results:
MVC and doublet amplitude were significantly lower at plantar flexion (P < 0.01), while VA was significantly lower at dorsiflexion and full knee extension (P < 0.05). V/Msup and RMS/Msup were significantly lower at knee extension (P < 0.01), while Hsup/Msup was not affected by joint angle.
Conclusions:
These results indicate that joint positions leading to muscle lengthening produce reduced neural drive, due mainly to supraspinal mechanisms.

Related Concept Videos
 01:10
Torque
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
 01:19
Net Torque Calculations
 01:15
Torque Free Motion
 01:13
Angle of Twist: Problem Solving
 01:13
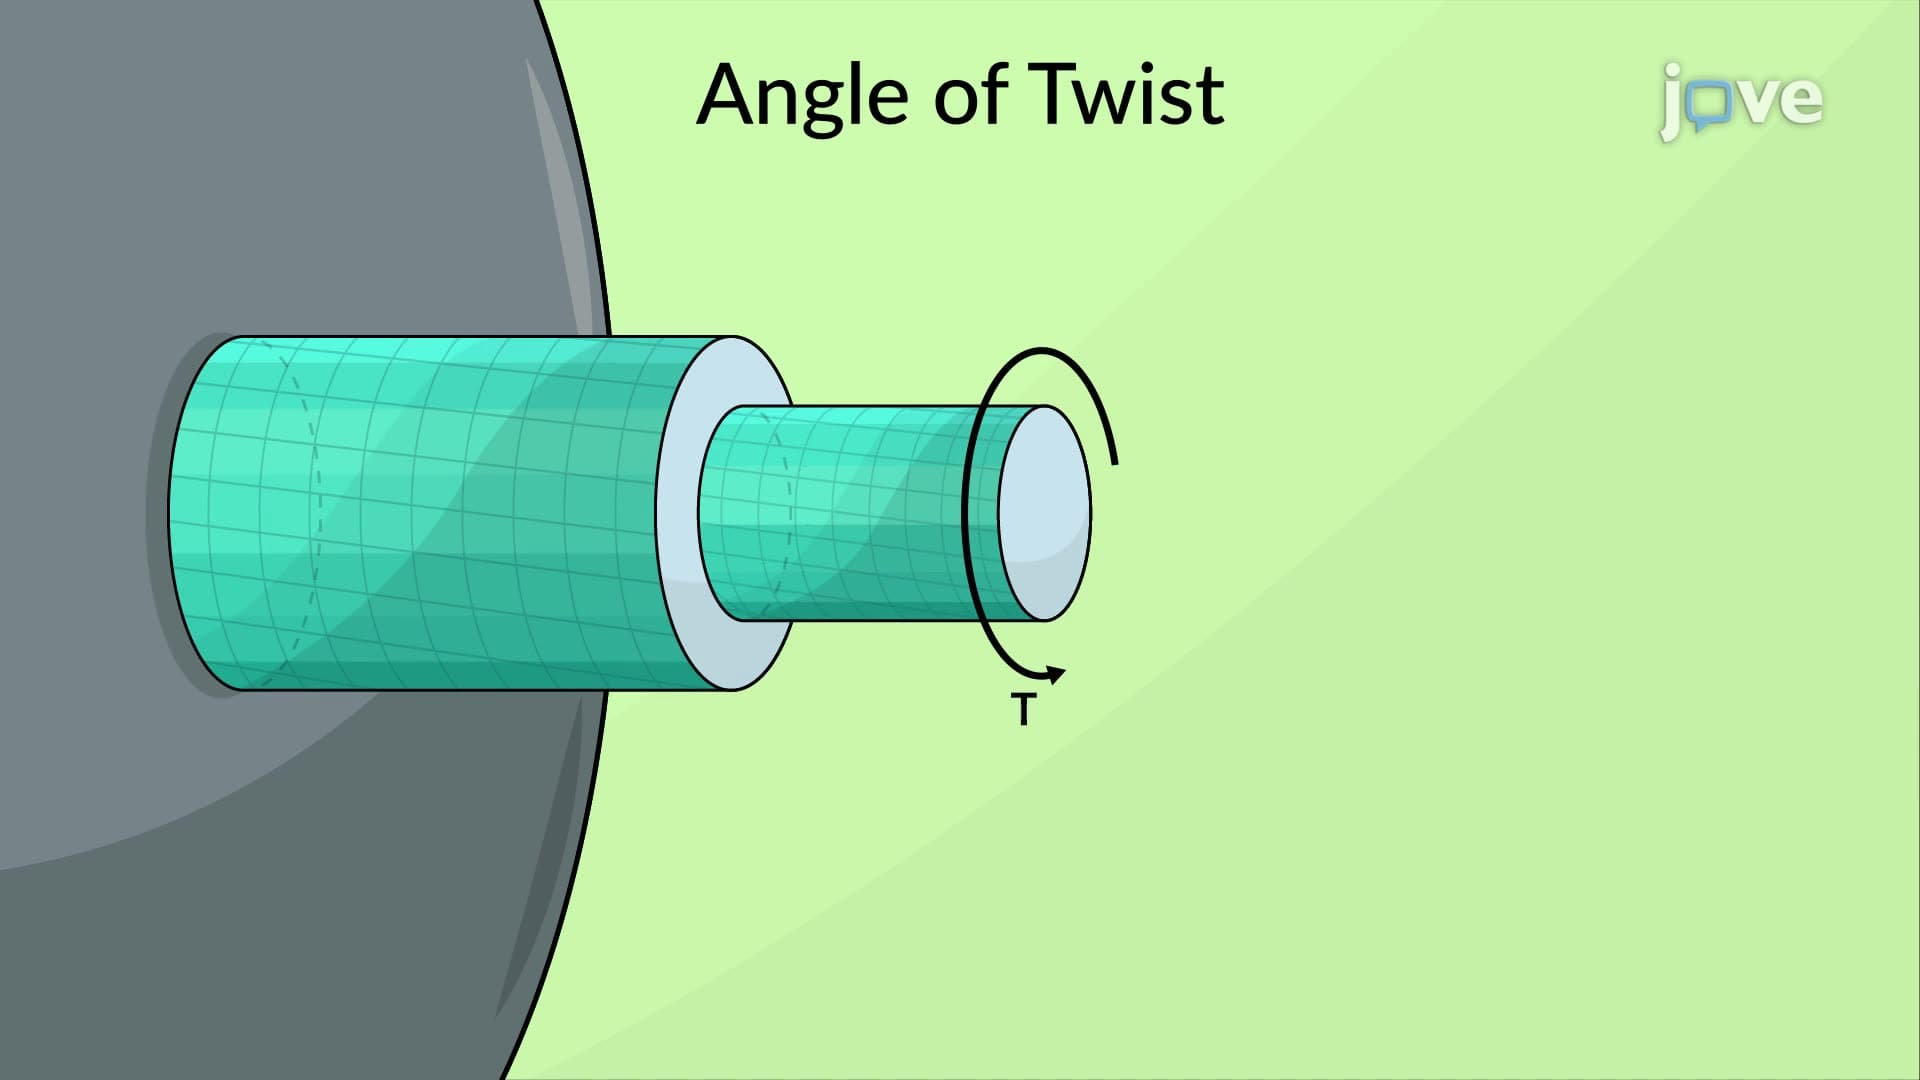
Angle of Twist - Elastic Range
 01:07
Development of the Limb Synovial Joints
The mesenchymal stem cells differentiate into chondrocytes that form the hyaline cartilage, and later the cartilaginous model of the bone. This model further transforms into a bone. This process is known as endochondral ossification.
During development, the limbs...