Related Experiment Video
Updated: Apr 4, 2026
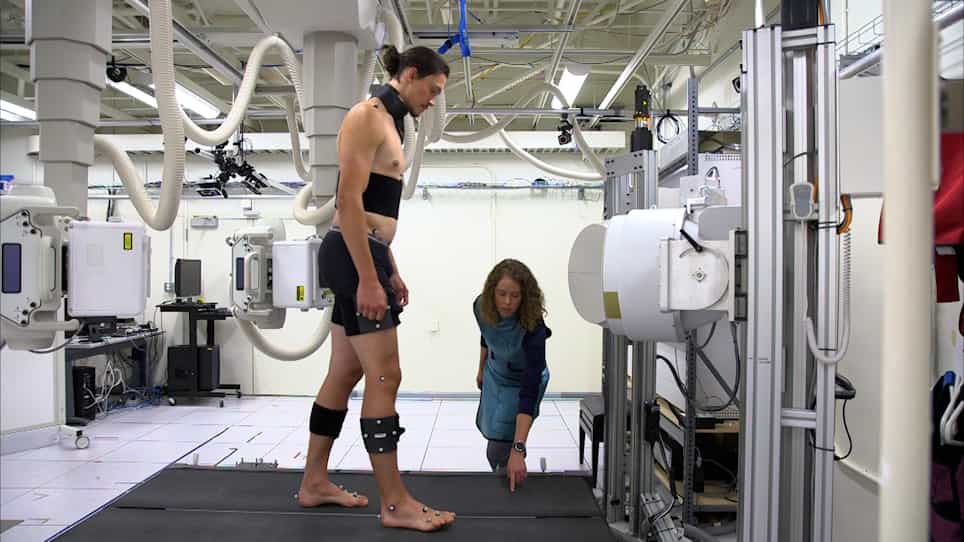
In Vivo Quantification of Hip Arthrokinematics during Dynamic Weight-bearing Activities using Dual Fluoroscopy
Published on: July 2, 2021
Fast Compressive Tracking

Abstract:
It is a challenging task to develop effective and efficient appearance models for robust object tracking due to factors such as pose variation, illumination change, occlusion, and motion blur. Existing online tracking algorithms often update models with samples from observations in recent frames. Despite much success has been demonstrated, numerous issues remain to be addressed. First, while these adaptive appearance models are data-dependent, there does not exist sufficient amount of data for online algorithms to learn at the outset. Second, online tracking algorithms often encounter the drift problems. As a result of self-taught learning, misaligned samples are likely to be added and degrade the appearance models. In this paper, we propose a simple yet effective and efficient tracking algorithm with an appearance model based on features extracted from a multiscale image feature space with data-independent basis. The proposed appearance model employs non-adaptive random projections that preserve the structure of the image feature space of objects. A very sparse measurement matrix is constructed to efficiently extract the features for the appearance model. We compress sample images of the foreground target and the background using the same sparse measurement matrix. The tracking task is formulated as a binary classification via a naive Bayes classifier with online update in the compressed domain. A coarse-to-fine search strategy is adopted to further reduce the computational complexity in the detection procedure. The proposed compressive tracking algorithm runs in real-time and performs favorably against state-of-the-art methods on challenging sequences in terms of efficiency, accuracy and robustness.
More Related Videos
 06:26
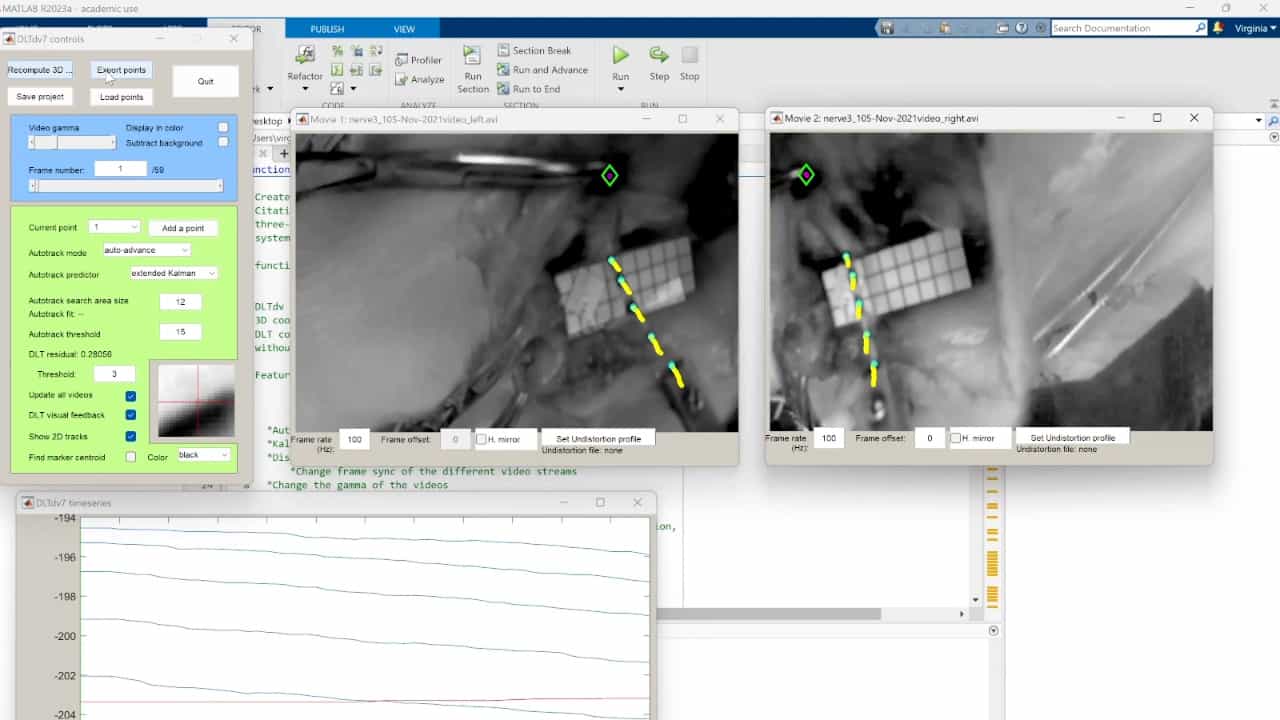
Stereo-Imaging System DLT Calibration to Capture 3D In Situ Displacements of Stretched Peripheral Nerves
Published on: January 12, 2024
 08:27
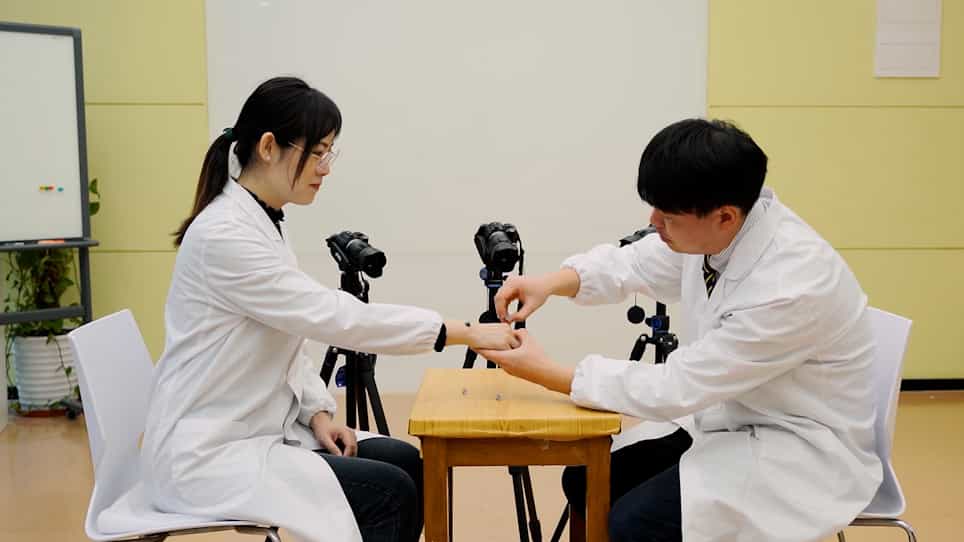
Three-Dimensional Finger Motion Tracking during Needling: A Solution for the Kinematic Analysis of Acupuncture Manipulation
Published on: October 28, 2021
Related Concept Videos
 01:10
Relative Motion Analysis - Acceleration
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:10
Computed Tomography
The technique was invented in the 1970s and is based on the principle that as X-rays pass through the body, they are absorbed or reflected at different levels. In the technique, a patient lies on a motorized platform while a computerized axial tomography (CAT) scanner rotates...