Kinectrack: 3D Pose Estimation Using a Projected Dense Dot Pattern
Related Experiment Video
Updated: Apr 4, 2026
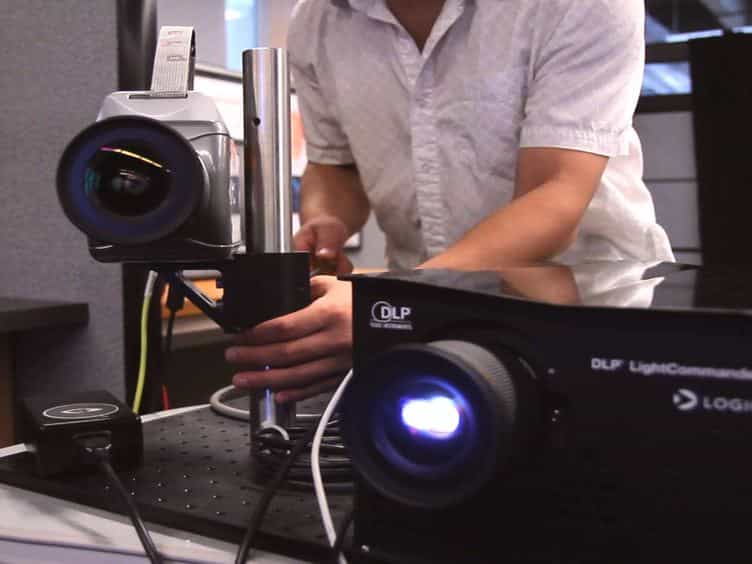
High-resolution, High-speed, Three-dimensional Video Imaging with Digital Fringe Projection Techniques
Published on: December 3, 2013

Abstract:
Kinectrack is a novel approach to six-DoF tracking that provides agile real-time pose estimation using only commodity hardware. The dot pattern emitter and IR camera components of the standard Kinect device are separated to allow the emitter to roam freely relative to a fixed camera. The six-DoF pose of the emitter component is recovered by matching the dense dot pattern observed by the camera to a pre-captured reference image. A novel matching technique is introduced to obtain the dense dot pattern correspondences efficiently in wide- and adaptive-baseline scenarios that requires only a small subset of the full dense dot pattern to fall within the field of view of the fixed camera. An auto-calibration process is proposed in order to obtain the intrinsic parameters of the fixed camera and the internal dot pattern reference image of the emitter. The system simultaneously recovers the six-DoF pose of the emitter device and the piecewise planar 3D scene structure. Kinectrack provides a low-cost method for tracking an object without any on-board computation, with small size and only simple electronics. This paper extends the original ISMAR 2012 submission, including a demonstration of robust pose tracking for AR and examples of matching in planar and non-planar scenes.
More Related Videos
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
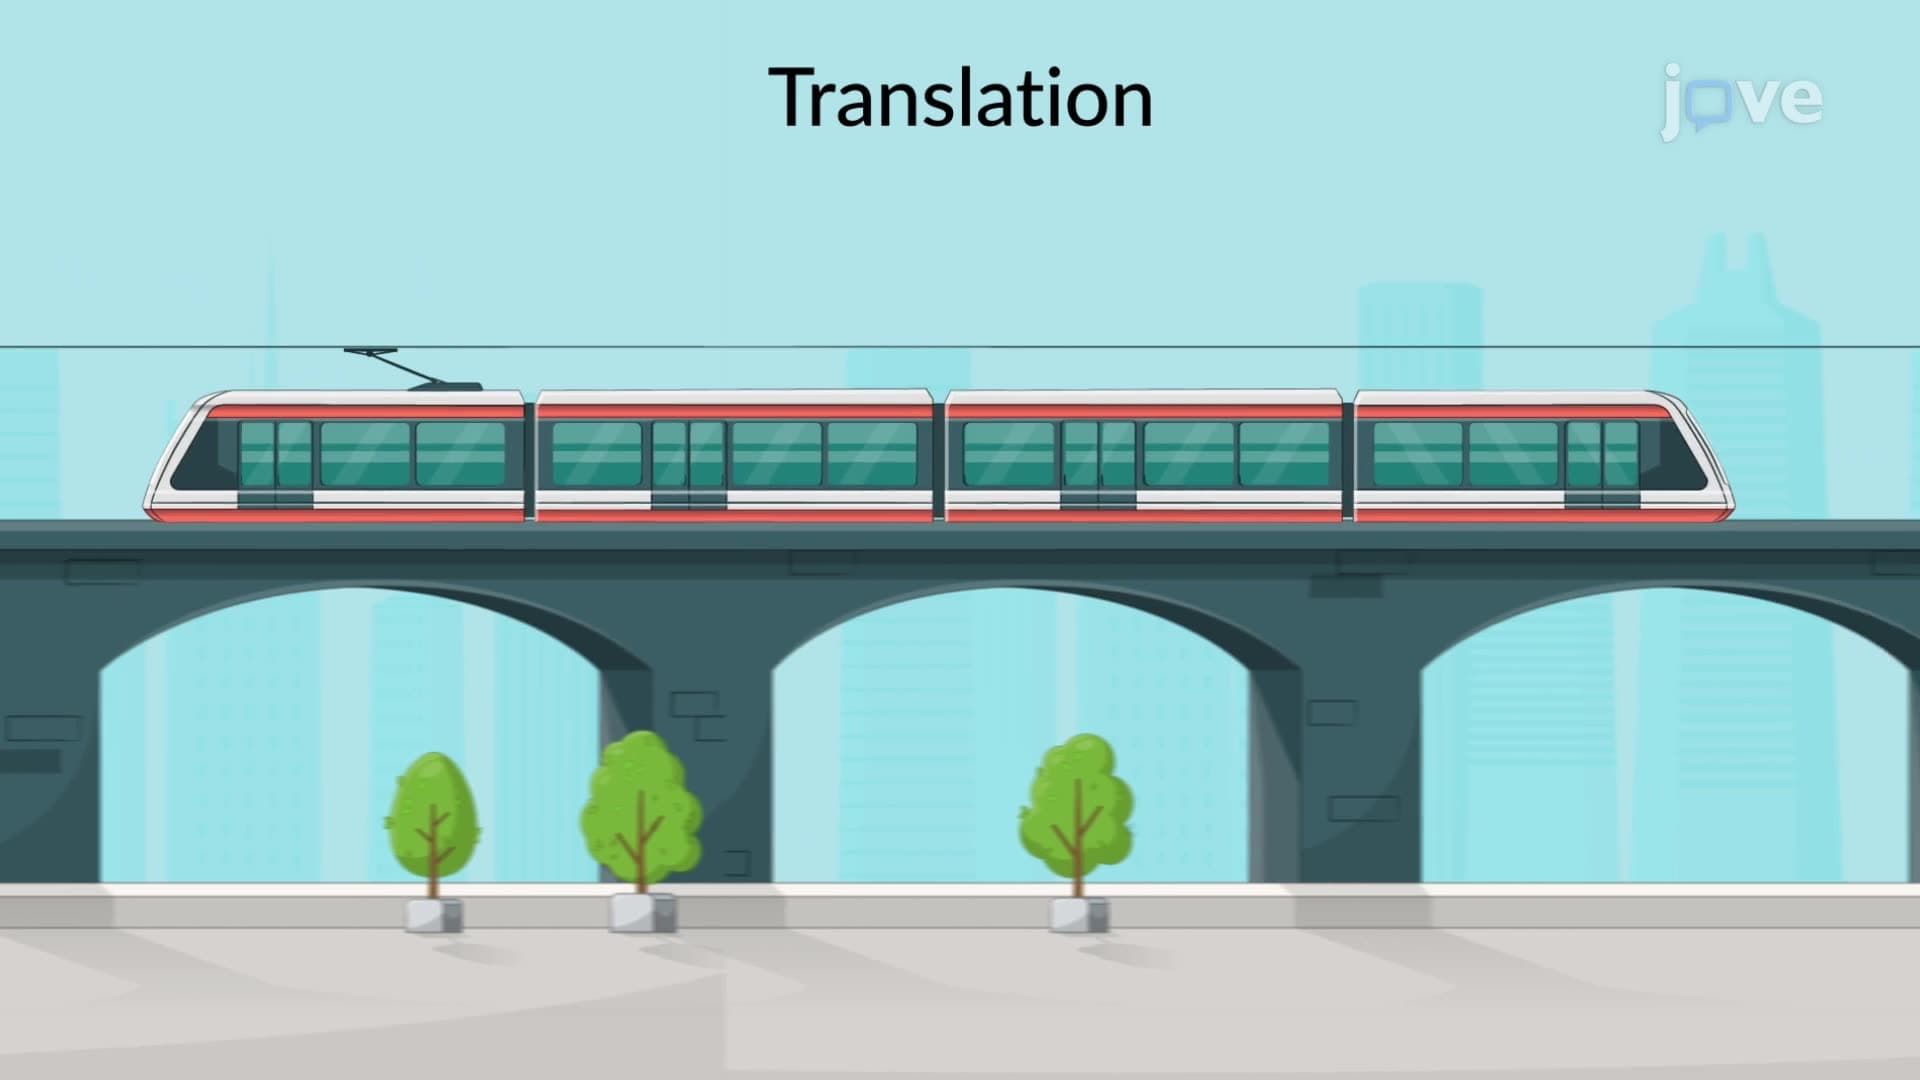
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...