Related Experiment Video
Updated: Apr 3, 2026


Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015
Buckling of Elastomeric Beams Enables Actuation of Soft Machines
Dian Yang1,2, Bobak Mosadegh1,3, Alar Ainla1
1Department of Chemistry and Chemical Biology, Harvard University, 12 Oxford Street, Cambridge, MA, 02138, USA.

Abstract:
Soft, pneumatic actuators that buckle when interior pressure is less than exterior provide a new mechanism of actuation. Upon application of negative pneumatic pressure, elastic beam elements in these actuators undergo reversible, cooperative collapse, and generate a rotational motion. These actuators are inexpensive to fabricate, lightweight, easy to control, and safe to operate. They can be used in devices that manipulate objects, locomote, or interact cooperatively with humans.


Related Concept Videos
 01:19
Members Made of Elastoplastic Material
As the bending moment...
 01:19
Plastic Deformations
 01:18
Residual Stresses in Bending
 01:23
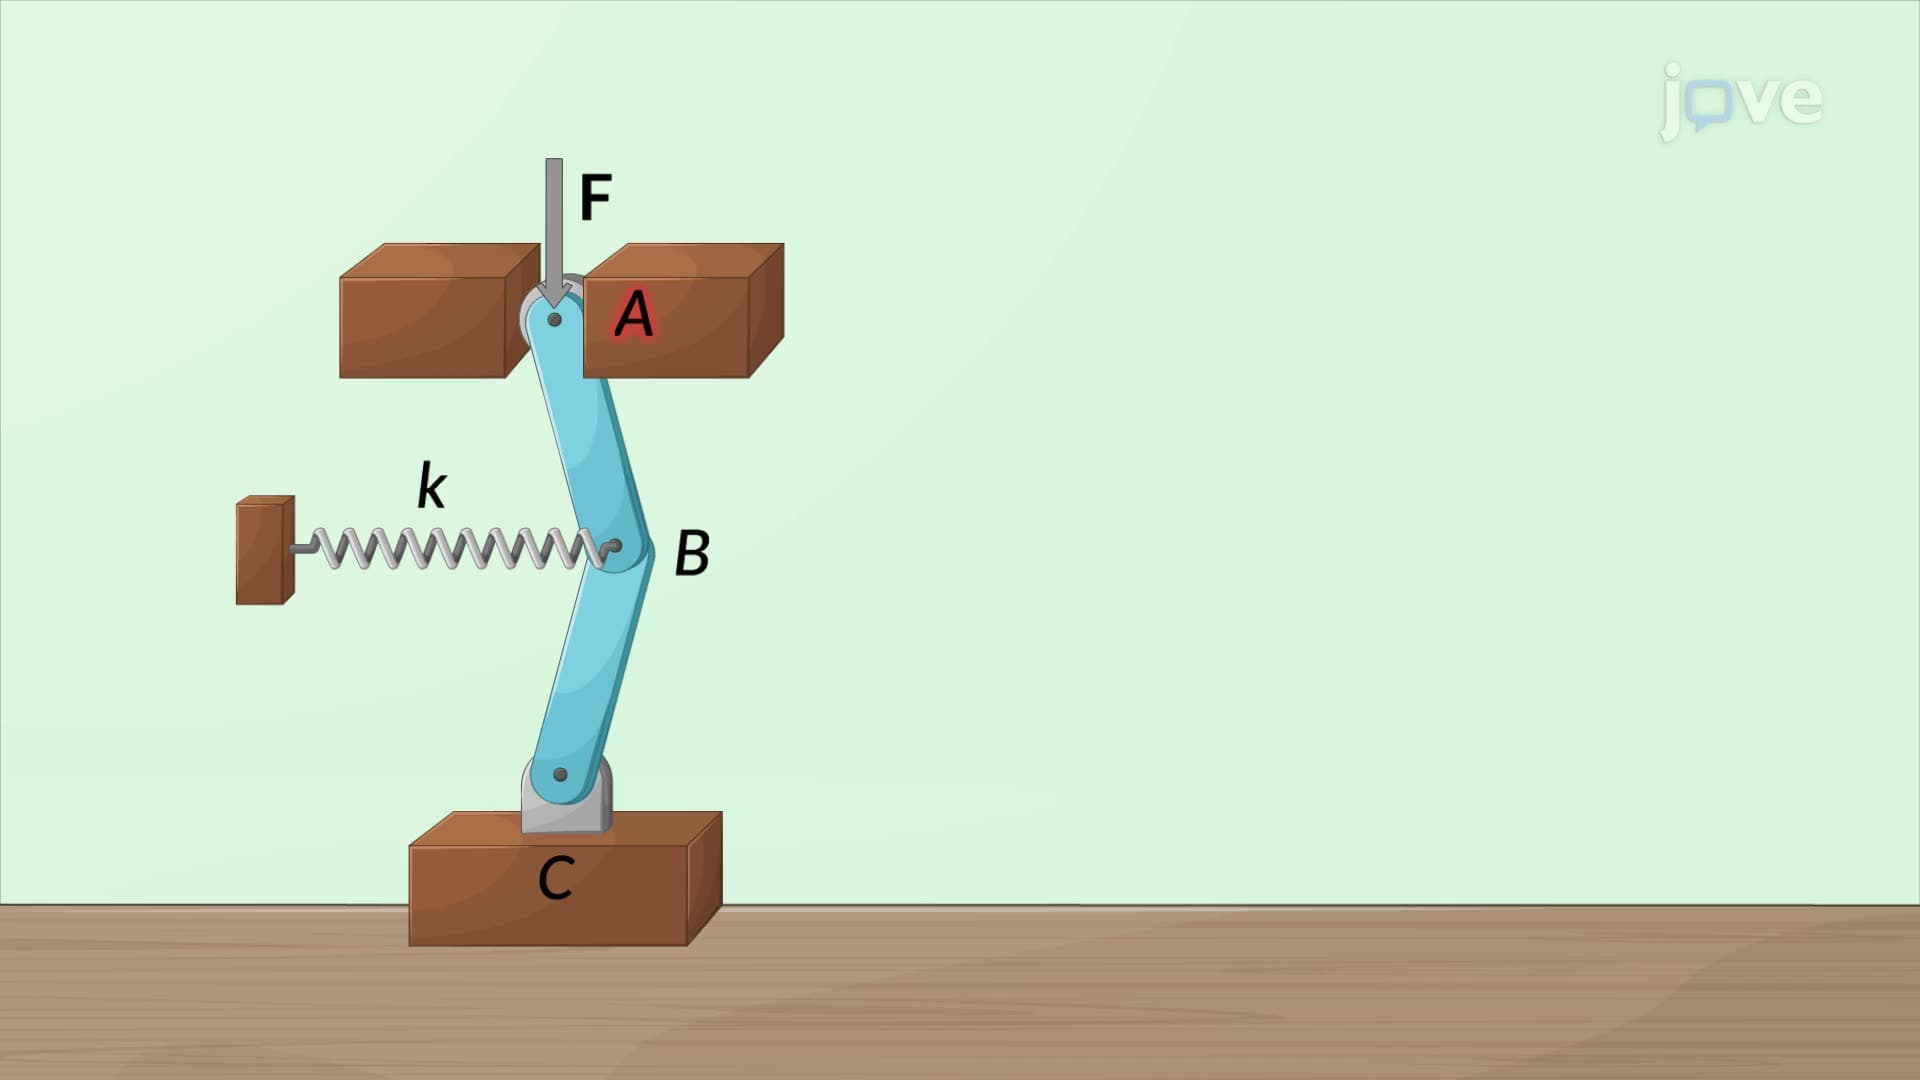
Euler's Formula to Columns: Problem Solving
The system comprises two vertical rigid bars, AB and BC, of...
 01:23
Equation of the Elastic Curve
Consider a cantilever beam with a point load at its free end (for instance, a diving board). When analyzing beam deflection with small slopes, the shape of the beam's elastic curve becomes key. The governing equation for this analysis involves the bending moment and the beam's flexural rigidity,...
 01:15
Relation between Poisson's ratio, Modulus of Elasticity and Modulus of Rigidity