Related Experiment Video
Updated: Apr 3, 2026
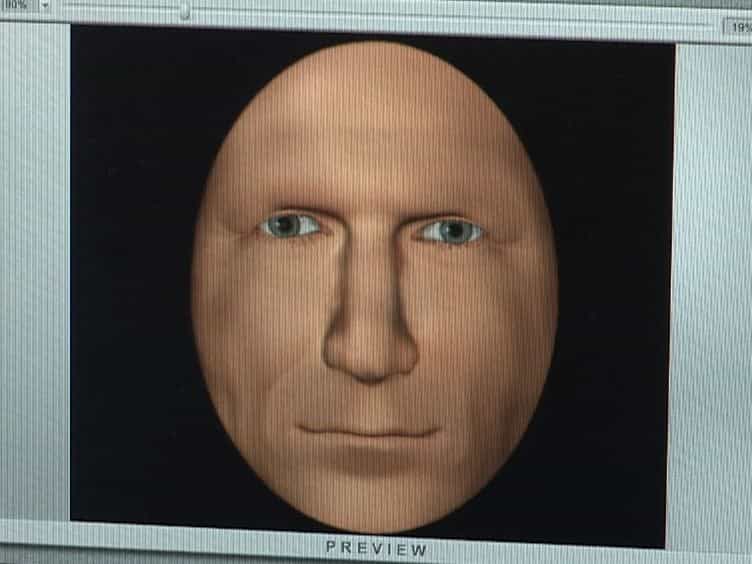

Perceptual and Category Processing of the Uncanny Valley Hypothesis' Dimension of Human Likeness: Some Methodological Issues
Published on: June 3, 2013
Navigating a social world with robot partners: A quantitative cartography of the Uncanny Valley
Maya B Mathur1, David B Reichling2
1Quantitative Sciences Unit, Stanford University, United States.

Abstract:
Android robots are entering human social life. However, human-robot interactions may be complicated by a hypothetical Uncanny Valley (UV) in which imperfect human-likeness provokes dislike. Previous investigations using unnaturally blended images reported inconsistent UV effects. We demonstrate an UV in subjects' explicit ratings of likability for a large, objectively chosen sample of 80 real-world robot faces and a complementary controlled set of edited faces. An "investment game" showed that the UV penetrated even more deeply to influence subjects' implicit decisions concerning robots' social trustworthiness, and that these fundamental social decisions depend on subtle cues of facial expression that are also used to judge humans. Preliminary evidence suggests category confusion may occur in the UV but does not mediate the likability effect. These findings suggest that while classic elements of human social psychology govern human-robot social interaction, robust UV effects pose a formidable android-specific problem.

Related Concept Videos
 01:28
Automatic Processing and Automatic Social Behavior
 01:29
Introducing Social Perception
 01:13
Nonconscious Mimicry
 01:30
Social Foundations of Self IV: Self in Digital Communication
 02:16
Stereotype Content Model
 01:20
Social Foundations of Self II: The Generalized Other