Related Experiment Video
Updated: Apr 2, 2026


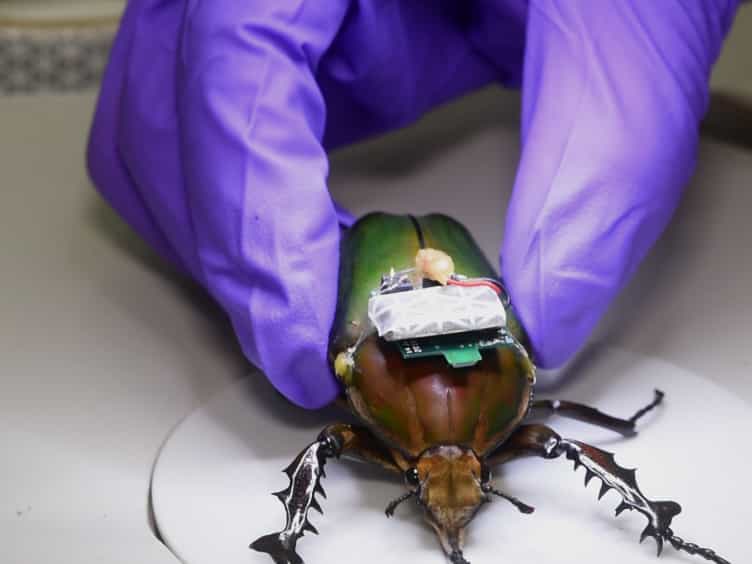
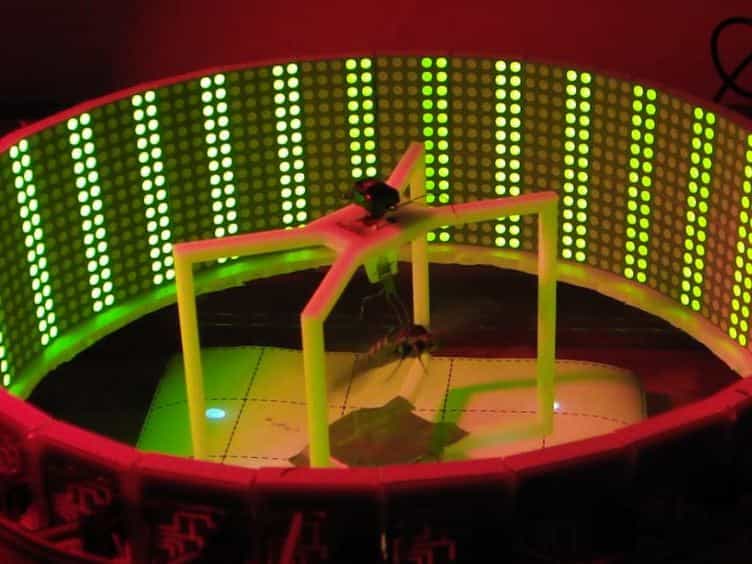
Insect-controlled Robot: A Mobile Robot Platform to Evaluate the Odor-tracking Capability of an Insect
Published on: December 19, 2016
Hovering and forward flight of the hawkmoth Manduca sexta: trim search and 6-DOF dynamic stability characterization
Joong-Kwan Kim1, Jong-Seob Han, Jun-Seong Lee
1Department of Aerospace Engineering, KAIST, 291 Daehak-ro, Yuseong-gu, Daejeon, Korea.

Abstract:
We show that the forward flight speed affects the stability characteristics of the longitudinal and lateral dynamics of a flying hawkmoth; dynamic modal structures of both the planes of motion are altered due to variations in the stability derivatives. The forward flight speed u e is changed from 0.00 to 1.00 m s(-1) with an increment of 0.25 m s(-1). (The equivalent advance ratio is 0.00 to 0.38; the advance ratio is the ratio of the forward flight speed to the average wing tip speed.) As the flight speed increases, for the longitudinal dynamics, an unstable oscillatory mode becomes more unstable. Also, we show that the up/down (w(b)) dynamics become more significant at a faster flight speed due to the prominent increase in the stability derivative Z(u) (up/down force due to the forward/backward velocity). For the lateral dynamics, the decrease in the stability derivative L(v) (roll moment due to side slip velocity) at a faster flight speed affects a slightly damped stable oscillatory mode, causing it to become more stable; however, the t(half) (the time taken to reach half the amplitude) of this slightly damped stable oscillatory mode remains relatively long (∼12T at u(e) = 1 m s(-1); T is wingbeat period) compared to the other modes of motion, meaning that this mode represents the most vulnerable dynamics among the lateral dynamics at all flight speeds. To obtain the stability derivatives, trim conditions for linearization are numerically searched to find the exact trim trajectory and wing kinematics using an algorithm that uses the gradient information of a control effectiveness matrix and fully coupled six-degrees of freedom nonlinear multibody equations of motion. With this algorithm, trim conditions that consider the coupling between the dynamics and aerodynamics can be obtained. The body and wing morphology, and the wing kinematics used in this study are based on actual measurement data from the relevant literature. The aerodynamic model of the flapping wings of a hawkmoth is based on the blade element theory, and the necessary aerodynamic coefficients, including the lift, drag and wing pitching moment, are experimentally obtained from the results of previous work by the authors.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:11
Buoyancy and Stability for Submerged and Floating Bodies
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...