Related Experiment Video
Updated: Mar 31, 2026
10:07
Measurement of Dynamic Scapular Kinematics Using an Acromion Marker Cluster to Minimize Skin Movement Artifact
Published on: February 10, 2015
20.2K
The Motion of the Local Group with Respect to the 15,000 km/s Abell Cluster Frame
1Kitt Peak National Observatory NOAO, P.O. Box 26732 Tucson, AZ 85726Space Telescope Science Institute 3700 San Martin Drive Baltimore, MD 21218.
Annals of the New York Academy of Sciences
|October 16, 2015

Abstract
No abstract available in PubMed .
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
1.1K
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
1.1K
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
1000
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
1000
 01:10
Relative Motion Analysis - Acceleration
1.0K
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
1.0K
 01:24
Absolute Motion Analysis- General Plane Motion
703
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
703
 01:22
Non-uniform Circular Motion
10.2K
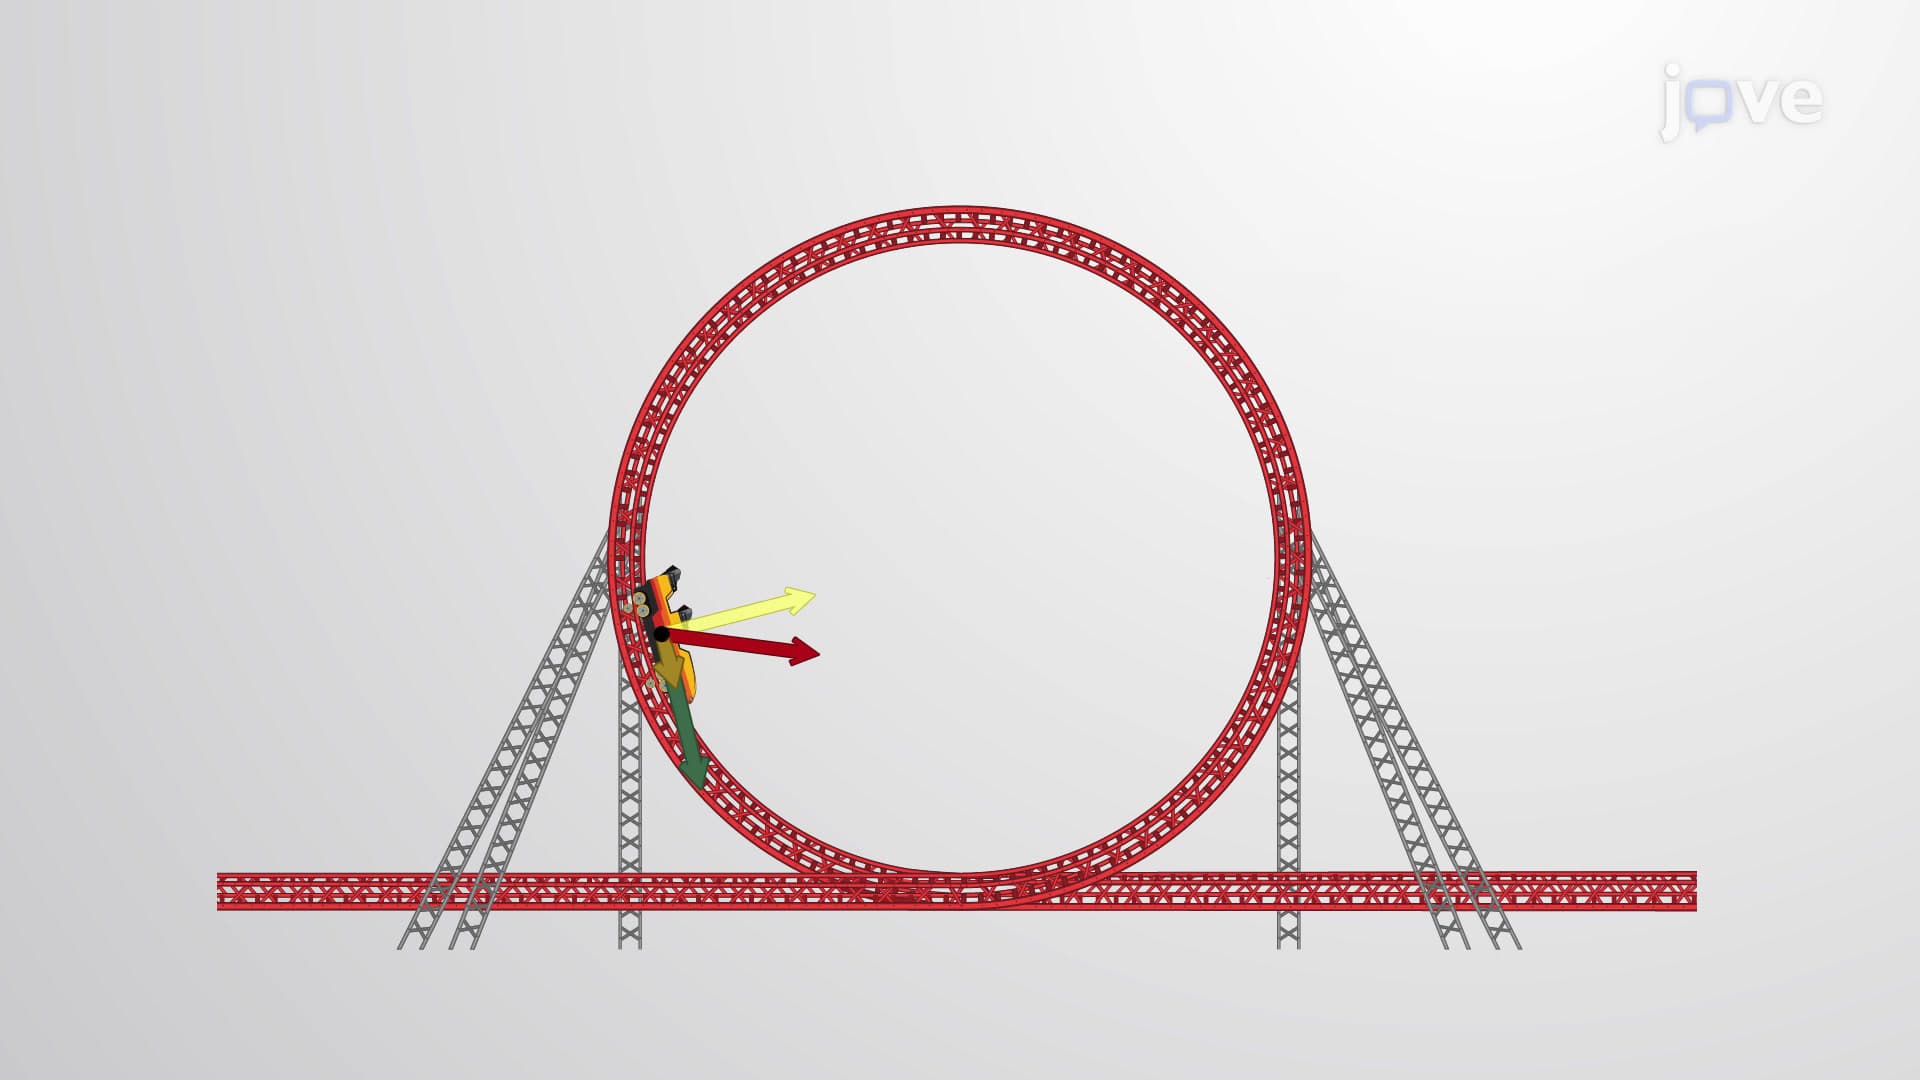
In uniform circular motion, the particle executing circular motion has a constant speed, and the circle is at a fixed radius. However, not all circular motion occurs at a constant speed. A particle can travel in a circle and speed up or slow down, showing an acceleration in the direction of motion. In that case, the motion is called non-uniform circular motion, and an additional acceleration is introduced, which is in the direction tangential to the circle.
For example, such...
For example, such...
10.2K
 01:03
Inertial Frames of Reference
9.9K
Newton’s first law is usually considered to be a statement about reference frames. It provides a method for identifying a special type of reference frame: the inertial reference frame. In principle, we can make the net force on a body zero. If its velocity relative to a given frame is constant, then that frame is said to be inertial. So, by definition, an inertial reference frame is a reference frame where Newton's first law holds valid. Newton's first law applies to objects with...
9.9K