Related Experiment Video
Updated: Mar 31, 2026

Magnetic Tweezers for the Measurement of Twist and Torque
Published on: May 19, 2014
Multi-sensor calibration of low-cost magnetic, angular rate and gravity systems
Markus Lüken1, Berno J E Misgeld2, Daniel Rüschen3
1Philips Chair for Medical Information Technology, RWTH Aachen University, Pauwelsstrasse 20, Aachen 52074, Germany. lueken@hia.rwth-aachen.de.

Abstract:
We present a new calibration procedure for low-cost nine degrees-of-freedom (9DOF) magnetic, angular rate and gravity (MARG) sensor systems, which relies on a calibration cube, a reference table and a body sensor network (BSN). The 9DOF MARG sensor is part of our recently-developed "Integrated Posture and Activity Network by Medit Aachen" (IPANEMA) BSN. The advantage of this new approach is the use of the calibration cube, which allows for easy integration of two sensor nodes of the IPANEMA BSN. One 9DOF MARG sensor node is thereby used for calibration; the second 9DOF MARG sensor node is used for reference measurements. A novel algorithm uses these measurements to further improve the performance of the calibration procedure by processing arbitrarily-executed motions. In addition, the calibration routine can be used in an alignment procedure to minimize errors in the orientation between the 9DOF MARG sensor system and a motion capture inertial reference system. A two-stage experimental study is conducted to underline the performance of our calibration procedure. In both stages of the proposed calibration procedure, the BSN data, as well as reference tracking data are recorded. In the first stage, the mean values of all sensor outputs are determined as the absolute measurement offset to minimize integration errors in the derived movement model of the corresponding body segment. The second stage deals with the dynamic characteristics of the measurement system where the dynamic deviation of the sensor output compared to a reference system is Sensors 2015, 15 25920 corrected. In practical validation experiments, this procedure showed promising results with a maximum RMS error of 3.89°.
More Related Videos

Related Concept Videos
 01:12
Measuring Acceleration Due to Gravity
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
 01:12
Instrument Calibration
Analytical Balance Calibration
An analytical balance measures mass and requires regular calibration to...
 01:02
Gyroscope
 01:19
Magnetic Declination
 01:24
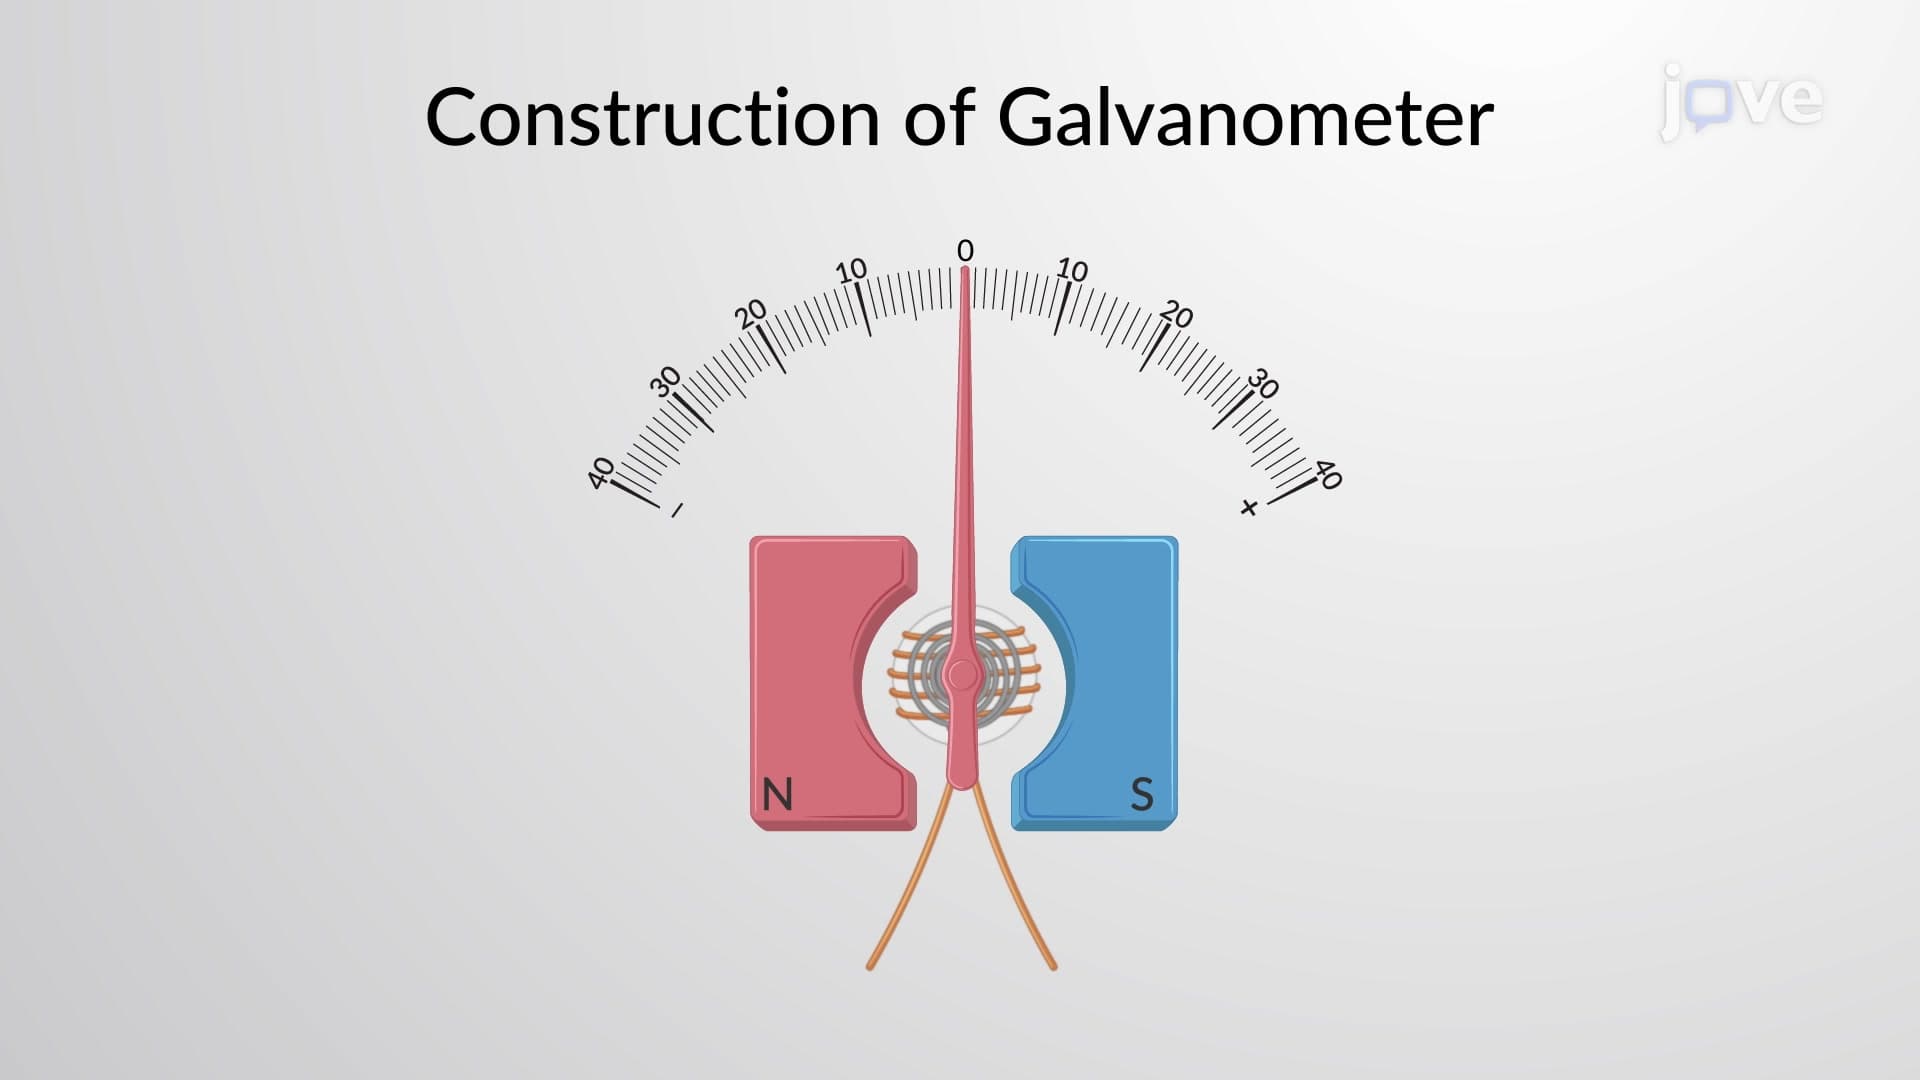
Galvanometer
The galvanometer consists of two concave-shaped permanent magnets, providing a uniform radial magnetic field in the annular region. In the center, a pivoted coil of fine copper wire is placed in the uniform...
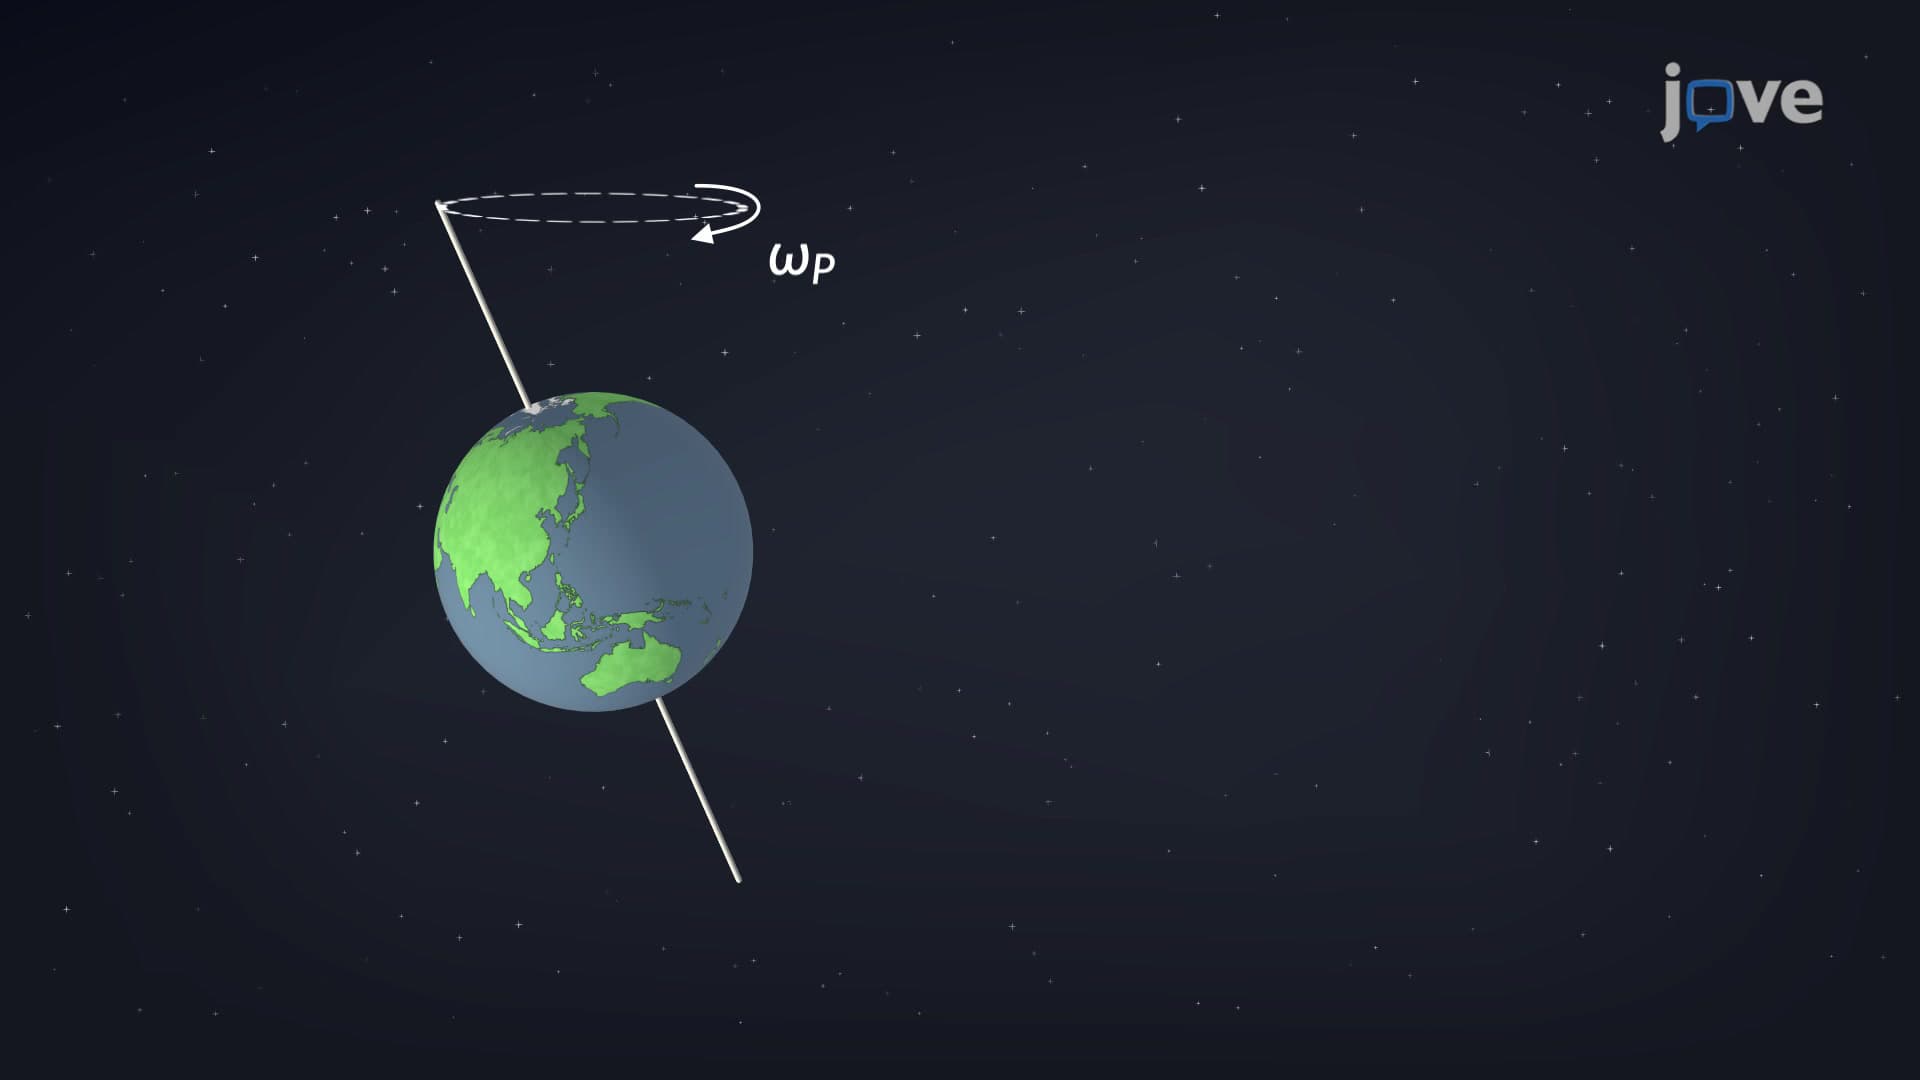 01:24
Gyroscope: Precession