Adaptive estimation of hand movement trajectory in an EEG based brain-computer interface system
Related Experiment Video
Updated: Mar 31, 2026
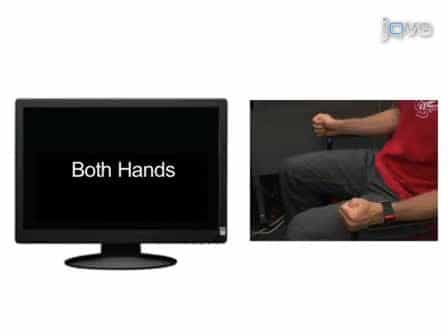
Using an EEG-Based Brain-Computer Interface for Virtual Cursor Movement with BCI2000
Published on: July 29, 2009
Neethu Robinson1, Cuntai Guan2, A P Vinod1
1School of Computer Engineering, Nanyang Technological University, Singapore.

Objective:
The various parameters that define a hand movement such as its trajectory, speed, etc, are encoded in distinct brain activities. Decoding this information from neurophysiological recordings is a less explored area of brain-computer interface (BCI) research. Applying non-invasive recordings such as electroencephalography (EEG) for decoding makes the problem more challenging, as the encoding is assumed to be deep within the brain and not easily accessible by scalp recordings.
Approach:
EEG based BCI systems can be developed to identify the neural features underlying movement parameters that can be further utilized to provide a detailed and well defined control command set to a BCI output device. A real-time continuous control is better suited for practical BCI systems, and can be achieved by continuous adaptive reconstruction of movement trajectory than discrete brain activity classifications. In this work, we adaptively reconstruct/estimate the parameters of two-dimensional hand movement trajectory, namely movement speed and position, from multi-channel EEG recordings. The data for analysis is collected by performing an experiment that involved center-out right-hand movement tasks in four different directions at two different speeds in random order. We estimate movement trajectory using a Kalman filter that models the relation between brain activity and recorded parameters based on a set of defined predictors. We propose a method to define these predictor variables that includes spatial, spectral and temporally localized neural information and to select optimally informative variables.
Main Results:
The proposed method yielded correlation of (0.60 ± 0.07) between recorded and estimated data. Further, incorporating the proposed predictor subset selection, the correlation achieved is (0.57 ± 0.07, p < 0.004) with significant gain in stability of the system, as well as dramatic reduction in number of predictors (76%) for the savings of computational time.
Significance:
The proposed system provides a real time movement control system using EEG-BCI with control over movement speed and position. These results are higher and statistically significant compared to existing techniques in EEG based systems and thus promise the applicability of the proposed method for efficient estimation of movement parameters and for continuous motor control.
More Related Videos
 11:25
Simultaneous Scalp Electroencephalography EEG, Electromyography EMG, and Whole-body Segmental Inertial Recording for Multi-modal Neural Decoding
Published on: July 26, 2013
 08:15
Capturing Dynamic Finger Gesturing with High-resolution Surface Electromyography and Computer Vision
Published on: March 28, 2025