Related Experiment Video
Updated: Mar 31, 2026
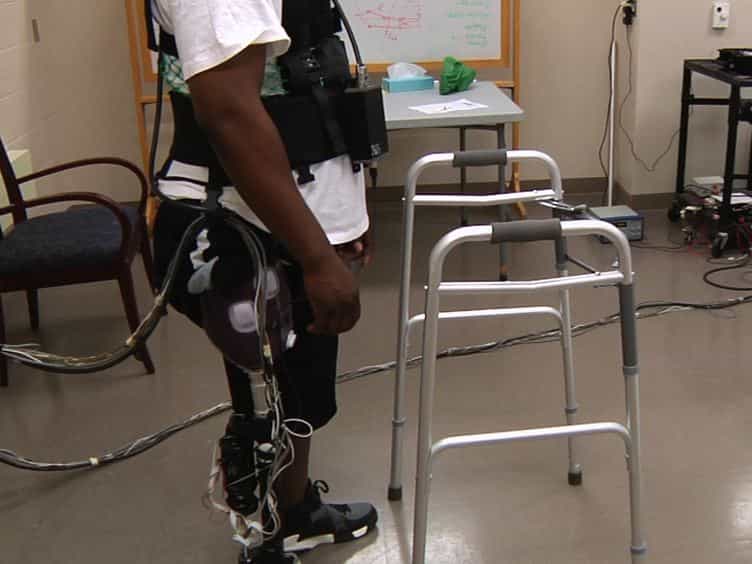
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
Phase coordination and phase-velocity relationship in metameric robot locomotion
Hongbin Fang1, Suyi Li, K W Wang
1School of Aerospace Engineering and Applied Mechanics, Tongji University, Shanghai 200092, People's Republic of China. Department of Mechanical Engineering, University of Michigan, Ann Arbor, MI 48105, USA.

Abstract:
This research proposes a new approach for the control of metameric robot locomotion via phase coordination. Unlike previous studies where global wave-like rules were pre-specified to construct the actuation sequence of segments, this phase coordination method generates robot locomotion by assigning the actuation phase differences between adjacent segments without any global prerequisite rules. To effectively coordinate the phase differences, different symmetry properties are introduced. Optimization is then carried out on various symmetrically coordinated phase-difference patterns to maximize the average steady-state velocity of the robot. It is shown that the maximum average velocity is always achieved when the reflectional symmetry is included in the phase-difference pattern, and the identical-phase-difference (IPD) pattern is preferred for implementation because it reduces the number of independent phase variables to only one without significant loss in locomotion performance. Extensive analytical investigations on the IPD pattern reveal the relationship between the average locomotion velocity and some important parameters. Theoretical findings on the relationship between the average velocity and the phase difference in the IPD pattern are verified via experimental investigations on an 8-segment earthworm-like metameric robot prototype. Finally, this paper reveals an interesting result that the optimized phase-difference pattern can naturally generate peristalsis waves in metameric robot locomotion without global prerequisite wave-like rules.


Related Concept Videos
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:22
Phase-lead and Phase-lag Controllers
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
 01:10
Relative Motion Analysis - Acceleration
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...
 01:15
Kinematic Equations: Problem Solving