Related Experiment Video
Updated: Mar 31, 2026
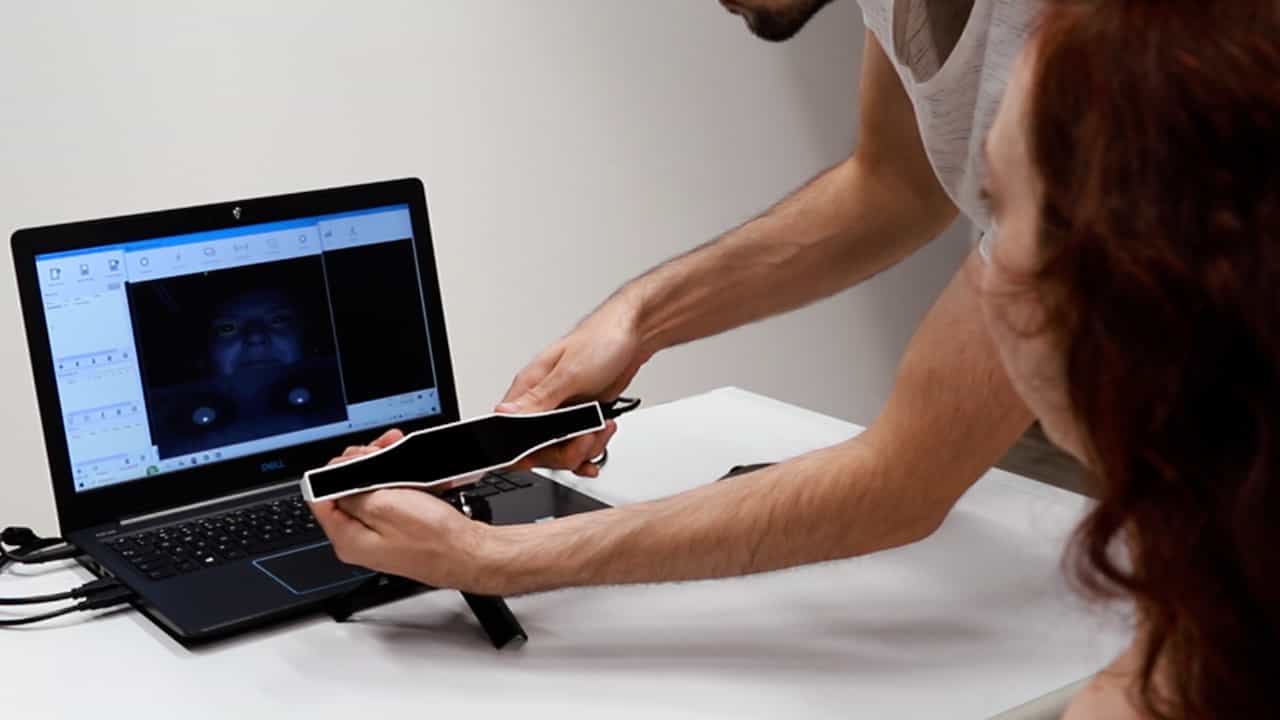

Author Spotlight: Insights into the Analysis of Human Interaction with 3D Virtual Objects
Published on: October 18, 2024
A Novel Multi-Purpose Matching Representation of Local 3D Surfaces: A Rotationally Invariant, Efficient, and Highly

Abstract:
In this paper, a novel approach to local 3D surface matching representation suitable for a range of 3D vision applications is introduced. Local 3D surface patches around key points on the 3D surface are represented by 2D images such that the representing 2D images enjoy certain characteristics which positively impact the matching accuracy, robustness, and speed. First, the proposed representation is complete, in the sense, there is no information loss during their computation. Second, the 3DoF 2D representations are strictly invariant to all the 3DoF rotations. To optimally avail surface information, the sensitivity of the representations to surface information is adjustable. This also provides the proposed matching representation with the means to optimally adjust to a particular class of problems/applications or an acquisition technology. Each 2D matching representation is a sequence of adjustable integral kernels, where each kernel is efficiently computed from a triple of precise 3D curves (profiles) formed by intersecting three concentric spheres with the 3D surface. Robust techniques for sampling the profiles and establishing correspondences among them were devised. Based on the proposed matching representation, two techniques for the detection of key points were presented. The first is suitable for static images, while the second is suitable for 3D videos. The approach was tested on the face recognition grand challenge v2.0, the 3D twins expression challenge, and the Bosphorus data sets, and a superior face recognition performance was achieved. In addition, the proposed approach was used in object class recognition and tested on a Kinect data set.
Related Concept Videos
 01:23
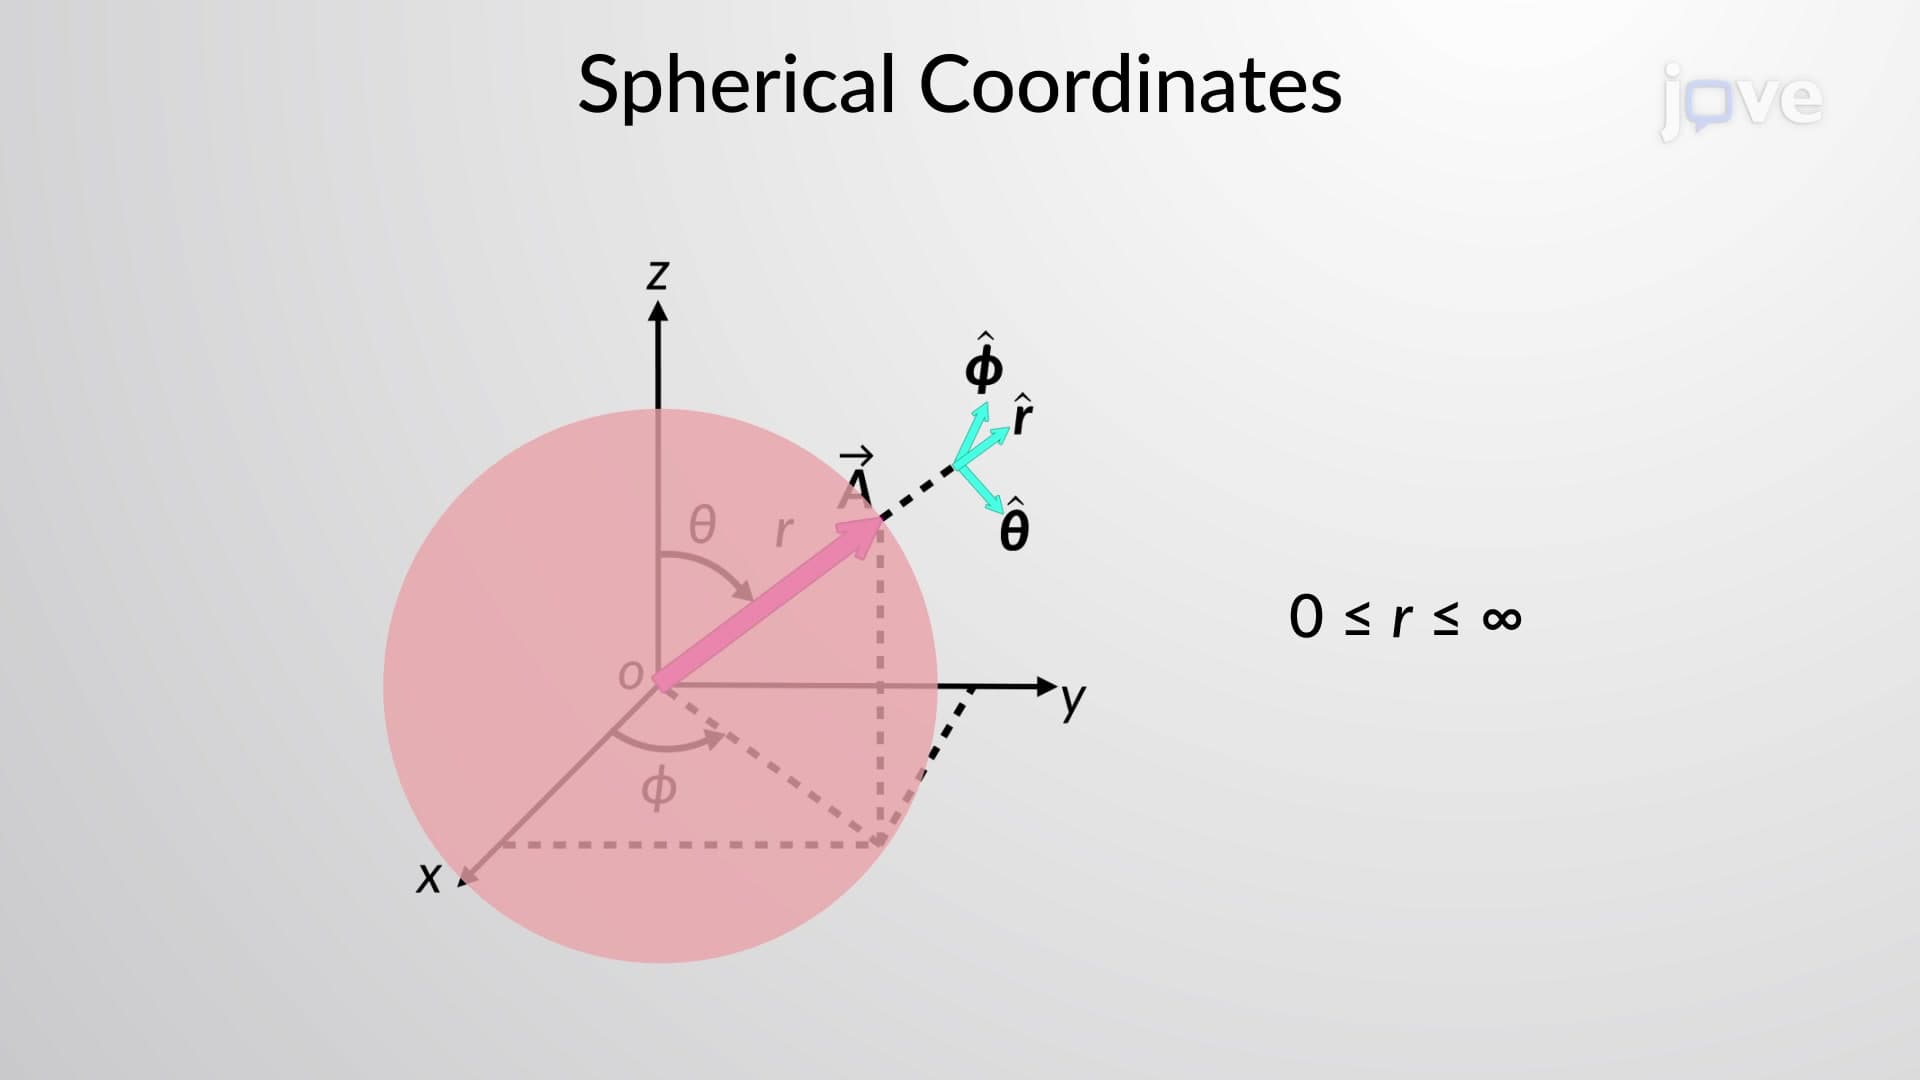
Spherical Coordinates
 01:27
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:29
Area of a Surface of Revolution
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:27
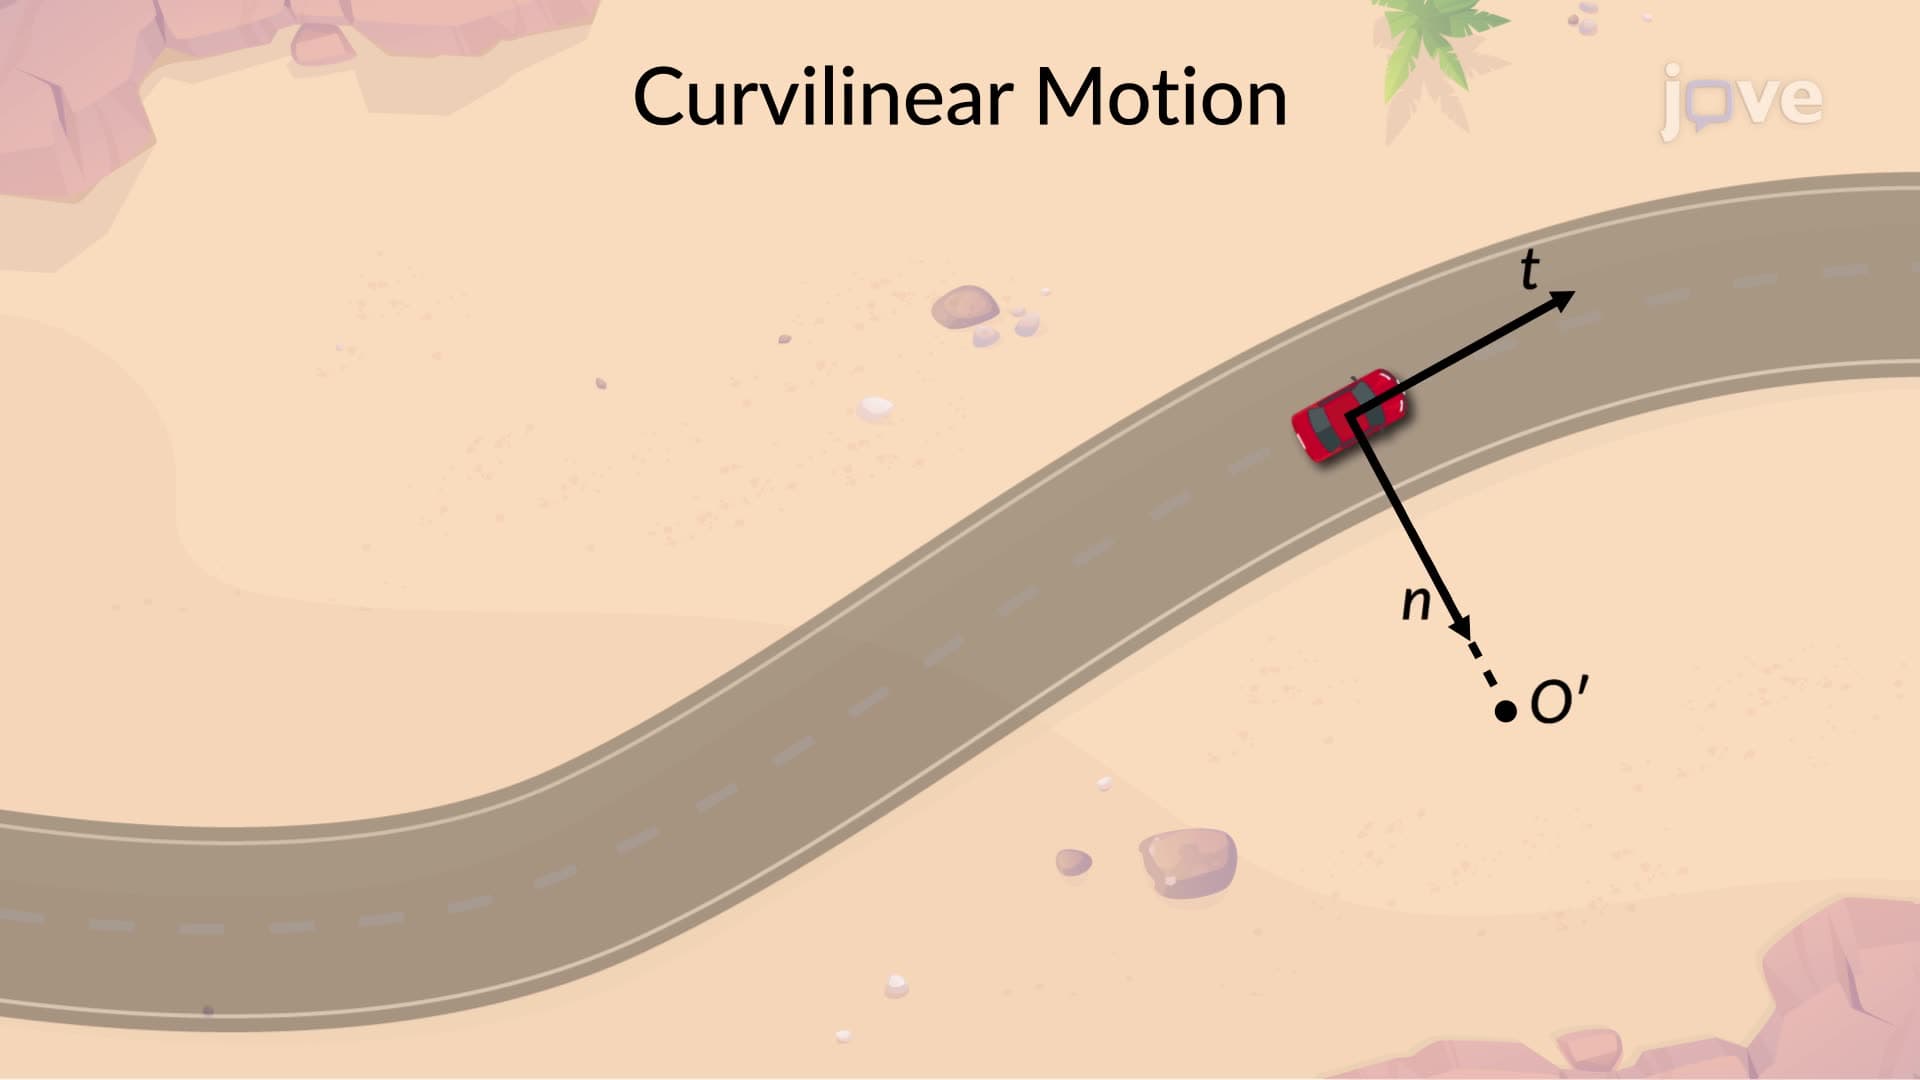
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...