Learning dynamic control of body roll orientation
Related Experiment Video
Updated: Mar 30, 2026

Method to Measure Tone of Axial and Proximal Muscle
Published on: December 14, 2011
Vivekanand Pandey Vimal1,2, James R Lackner3,4,5, Paul DiZio3,4,5
1Ashton Graybiel Spatial Orientation Laboratory, MS 033, Brandeis University, Waltham, MA, 02245-9110, USA. somde@brandeis.edu.

Abstract:
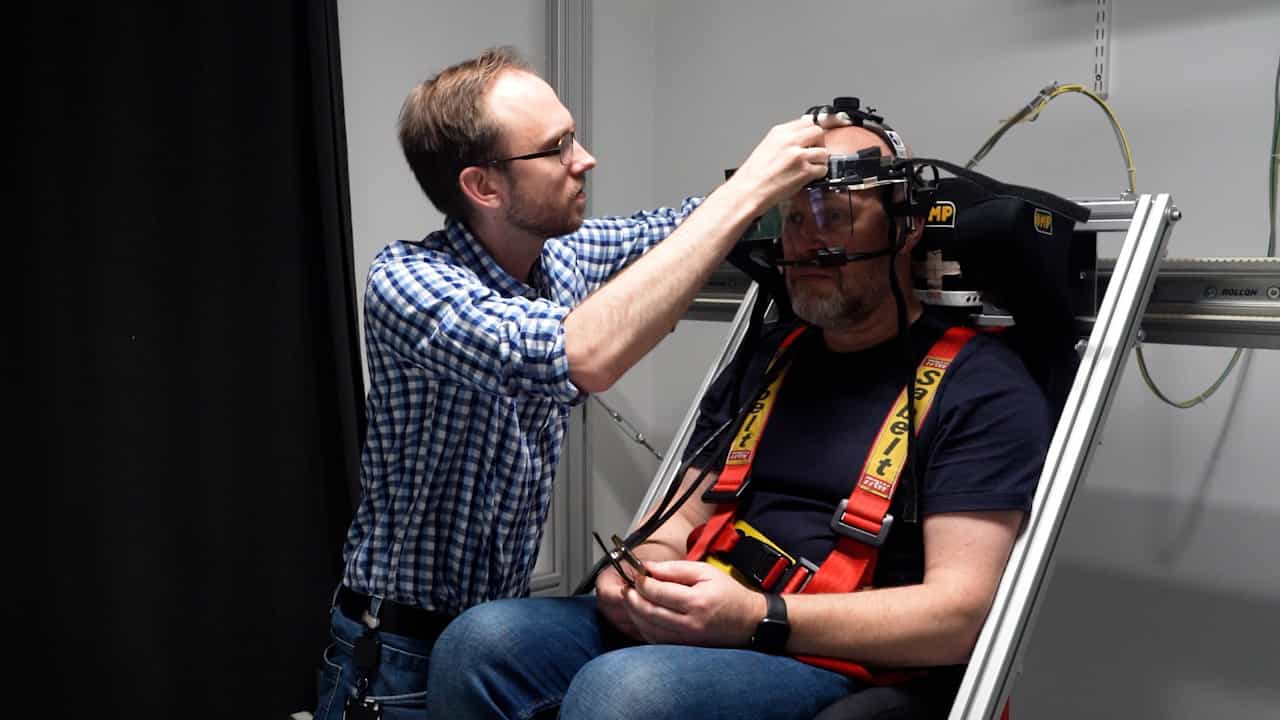
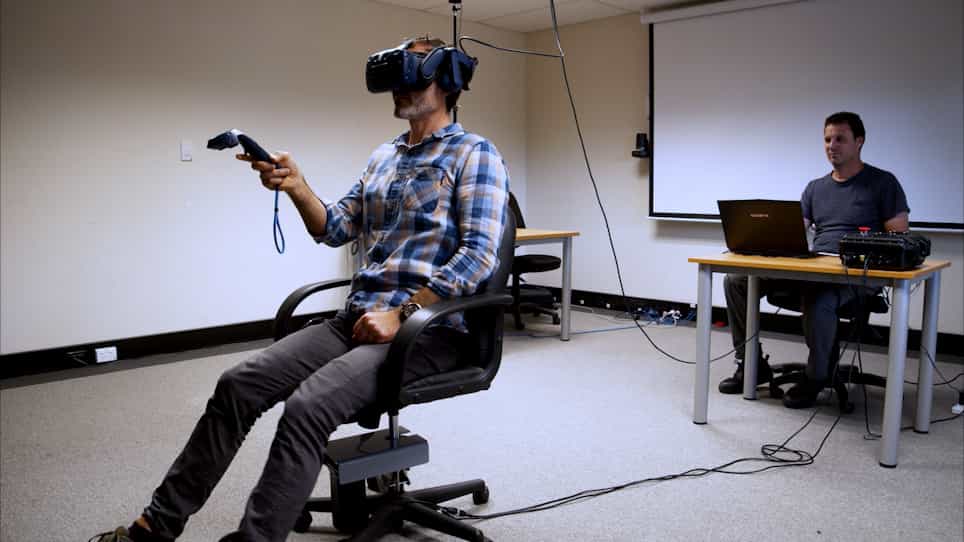
Our objective was to examine how the control of orientation is learned in a task involving dynamically balancing about an unstable equilibrium point, the gravitational vertical, in the absence of leg reflexes and muscle stiffness. Subjects (n = 10) used a joystick to set themselves to the gravitational vertical while seated in a multi-axis rotation system (MARS) device programmed with inverted pendulum dynamics. The MARS is driven by powerful servomotors and can faithfully follow joystick commands up to 2.5 Hz with a 30-ms latency. To make the task extremely difficult, the pendulum constant was set to 600°/s(2). Each subject participated in five blocks of four trials, with a trial ending after a cumulative 100 s of balancing, excluding reset times when a subject lost control. To characterize performance and learning, we used metrics derived from joystick movements, phase portraits (joystick deflections vs MARS position and MARS velocity vs angular position), and stabilogram diffusion functions. We found that as subjects improved their balancing performance, they did so by making fewer destabilizing joystick movements and reducing the number and duration of joystick commands. The control strategy they acquired involved making more persistent short-term joystick movements, waiting longer before making changes to ongoing motion, and only intervening intermittently.
Related Concept Videos
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:17
Rolling Resistance: Problem Solving
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
 01:14
Rolling With Slipping
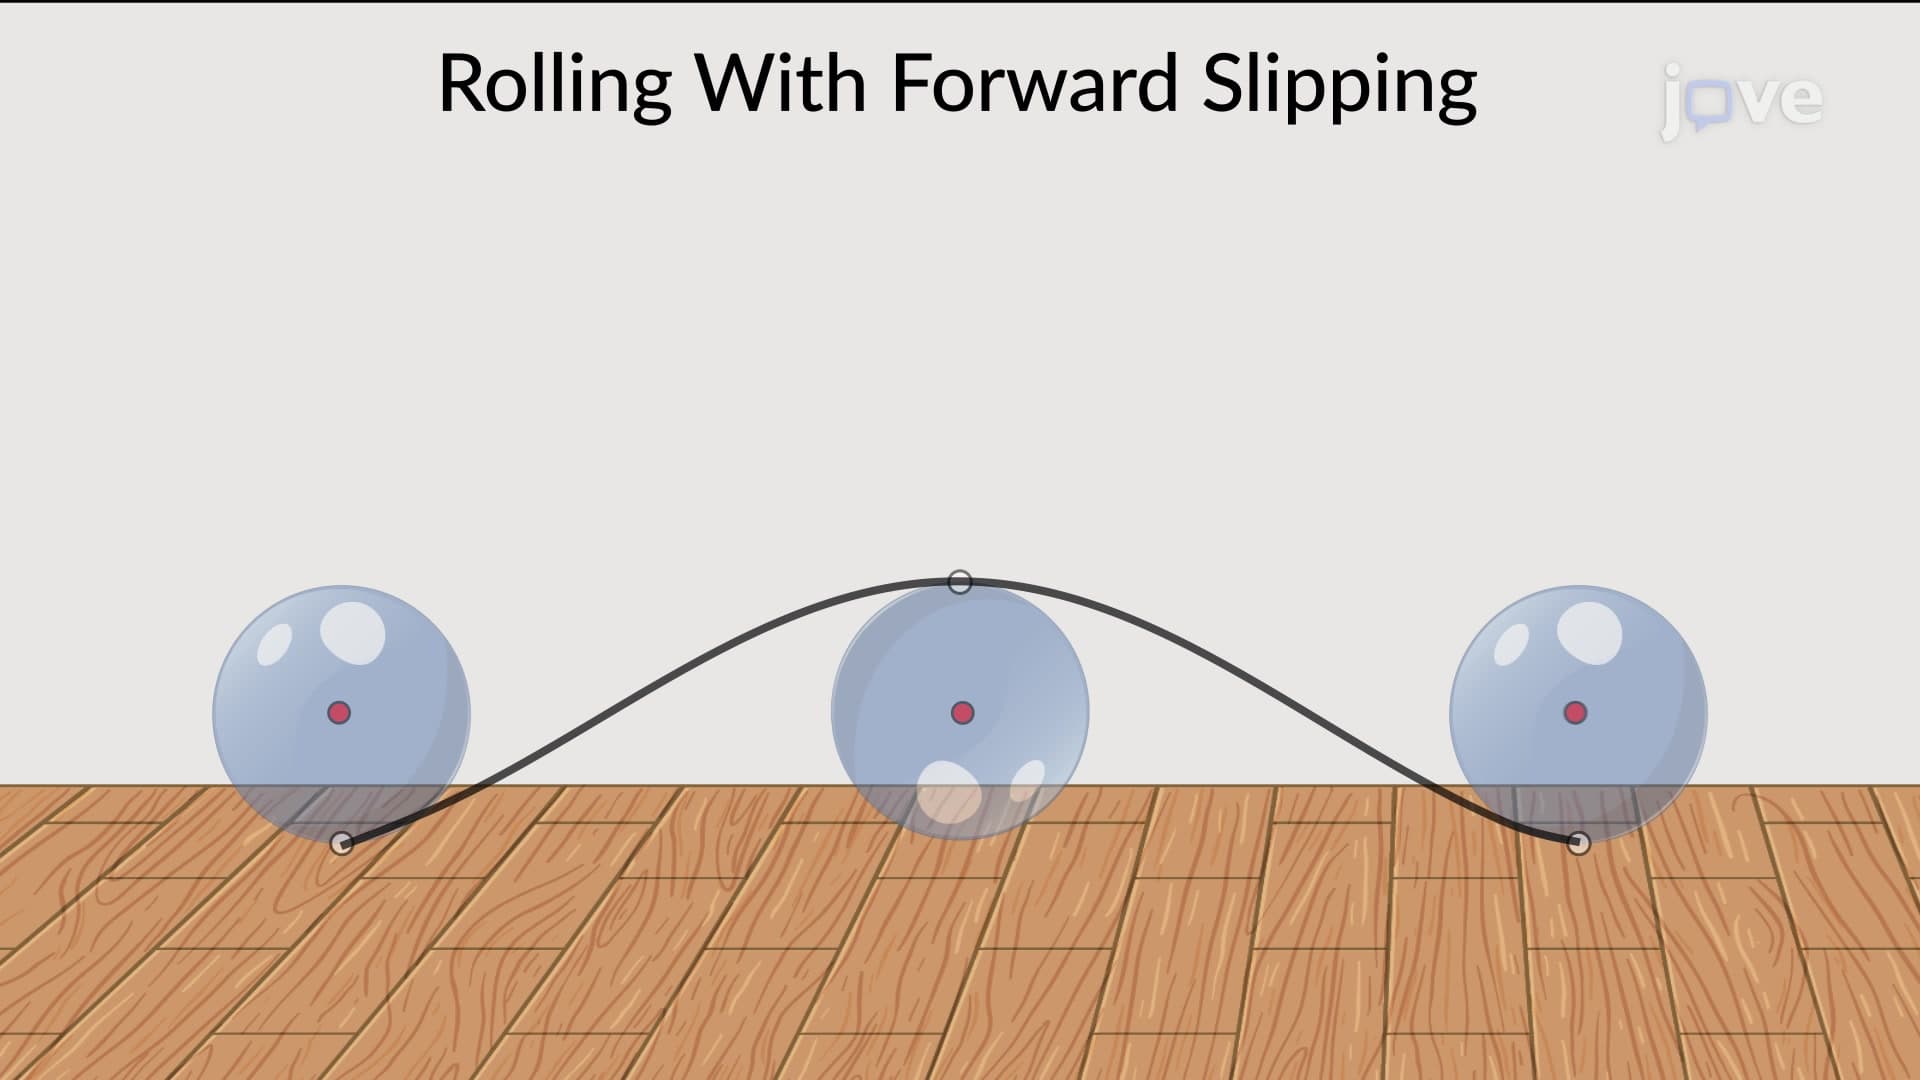
An object's rolling motion is characterized by its rotation around its axis, while linear motion refers to the object's translational motion along a surface. Frictional forces can...
 01:37
Rotation with Constant Angular Acceleration - I
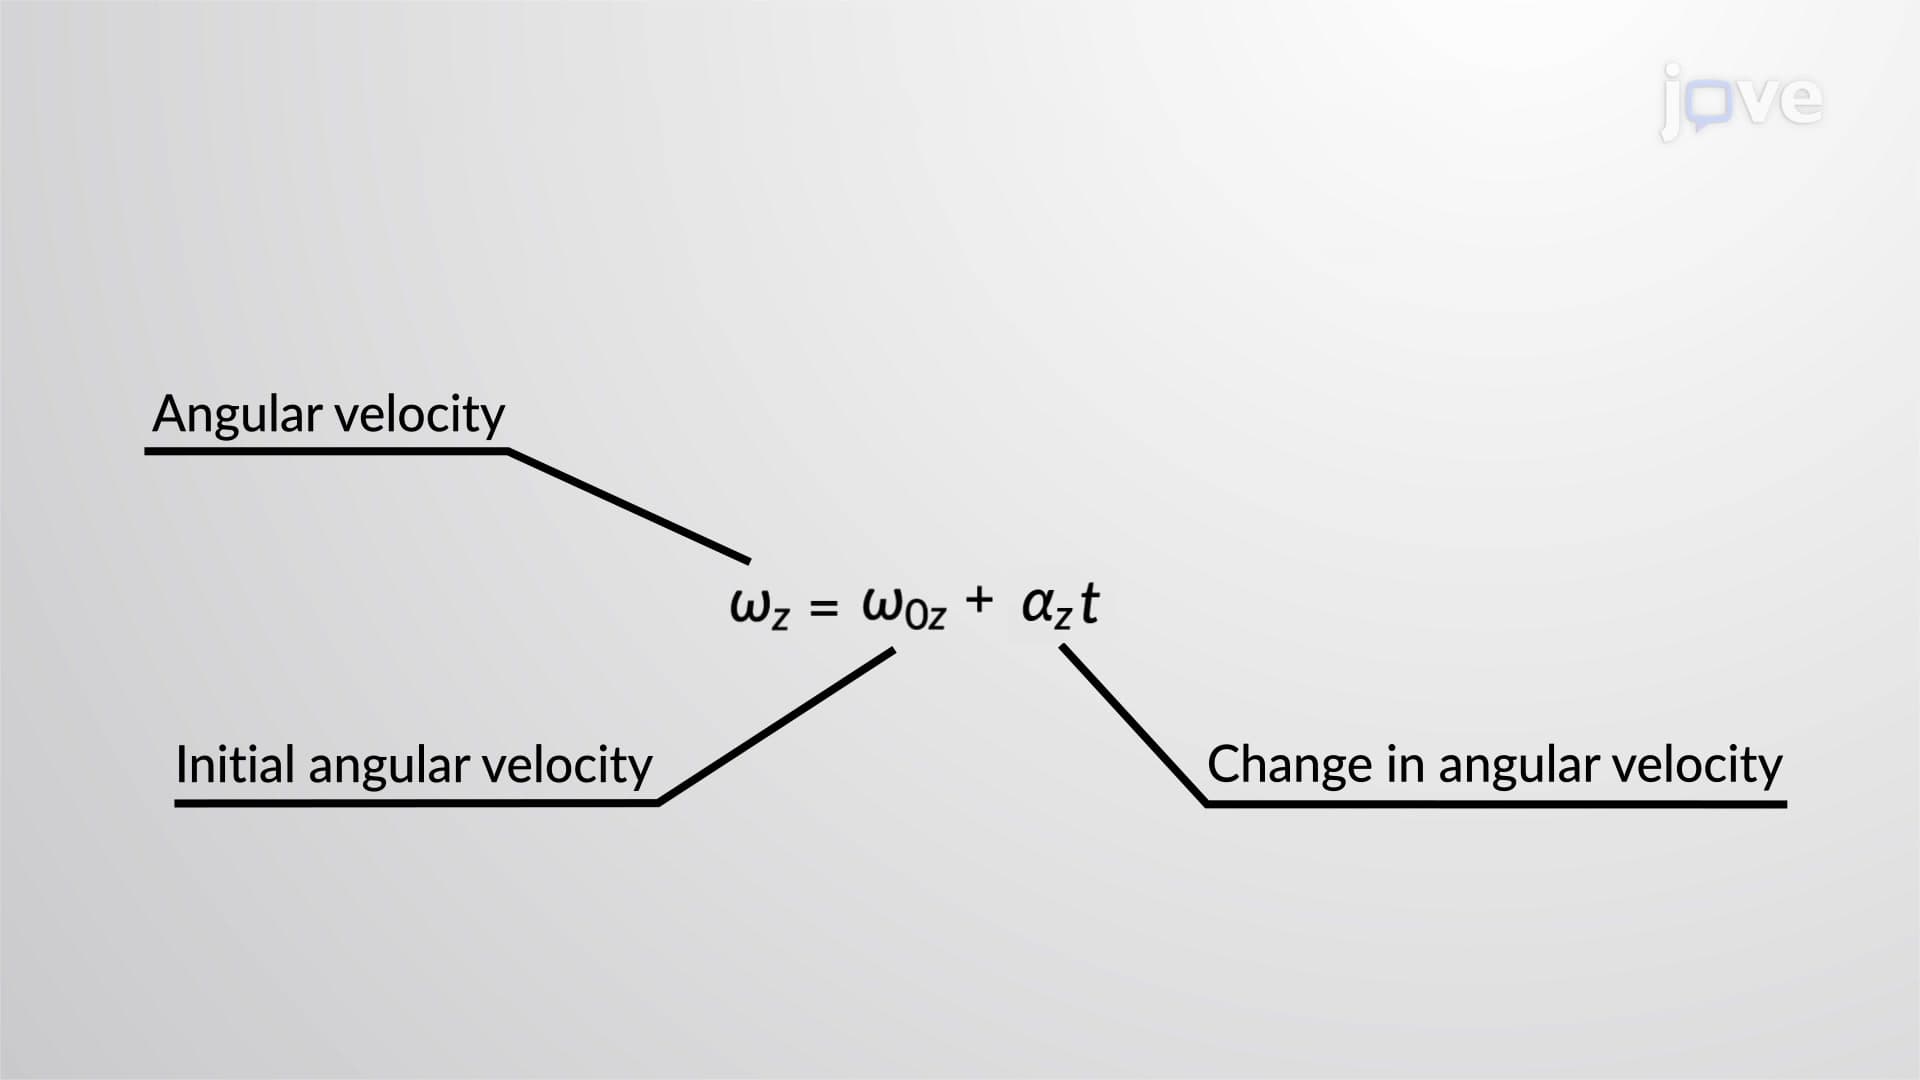
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...
 01:16
Rotation with Constant Angular Acceleration - II
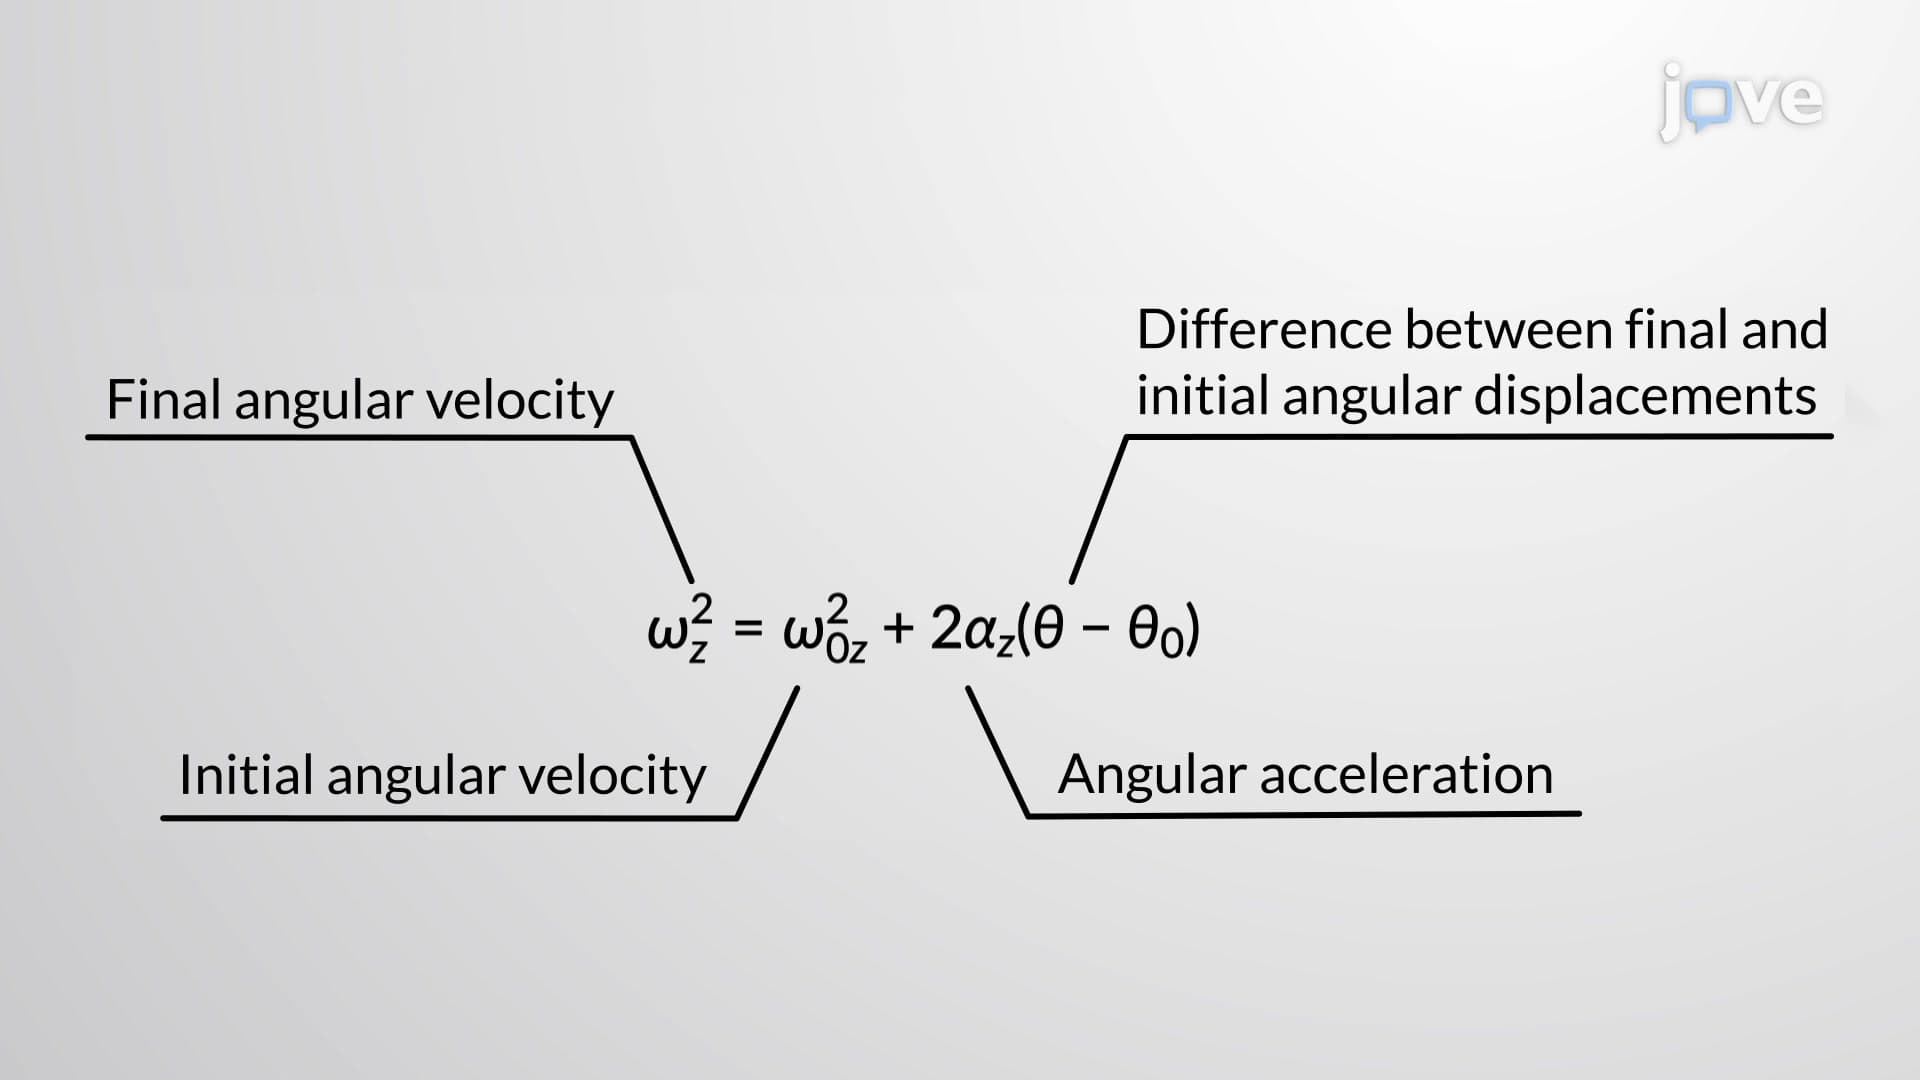
The first...