Kinematic Model-Based Pedestrian Dead Reckoning for Heading Correction and Lower Body Motion Tracking
Related Experiment Video
Updated: Mar 30, 2026
Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
Min Su Lee1, Hojin Ju2, Jin Woo Song3
1Department of Mechanical and Aerospace Engineering, Automation and Systems Research Institute, Seoul National University, Seoul 151-744, Korea. mandu46@snu.ac.kr.

Abstract:
In this paper, we present a method for finding the enhanced heading and position of pedestrians by fusing the Zero velocity UPdaTe (ZUPT)-based pedestrian dead reckoning (PDR) and the kinematic constraints of the lower human body. ZUPT is a well known algorithm for PDR, and provides a sufficiently accurate position solution for short term periods, but it cannot guarantee a stable and reliable heading because it suffers from magnetic disturbance in determining heading angles, which degrades the overall position accuracy as time passes. The basic idea of the proposed algorithm is integrating the left and right foot positions obtained by ZUPTs with the heading and position information from an IMU mounted on the waist. To integrate this information, a kinematic model of the lower human body, which is calculated by using orientation sensors mounted on both thighs and calves, is adopted. We note that the position of the left and right feet cannot be apart because of the kinematic constraints of the body, so the kinematic model generates new measurements for the waist position. The Extended Kalman Filter (EKF) on the waist data that estimates and corrects error states uses these measurements and magnetic heading measurements, which enhances the heading accuracy. The updated position information is fed into the foot mounted sensors, and reupdate processes are performed to correct the position error of each foot. The proposed update-reupdate technique consequently ensures improved observability of error states and position accuracy. Moreover, the proposed method provides all the information about the lower human body, so that it can be applied more effectively to motion tracking. The effectiveness of the proposed algorithm is verified via experimental results, which show that a 1.25% Return Position Error (RPE) with respect to walking distance is achieved.
More Related Videos
 11:06
A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
 09:32
Subject-specific Musculoskeletal Model for Studying Bone Strain During Dynamic Motion
Published on: April 11, 2018
Related Concept Videos
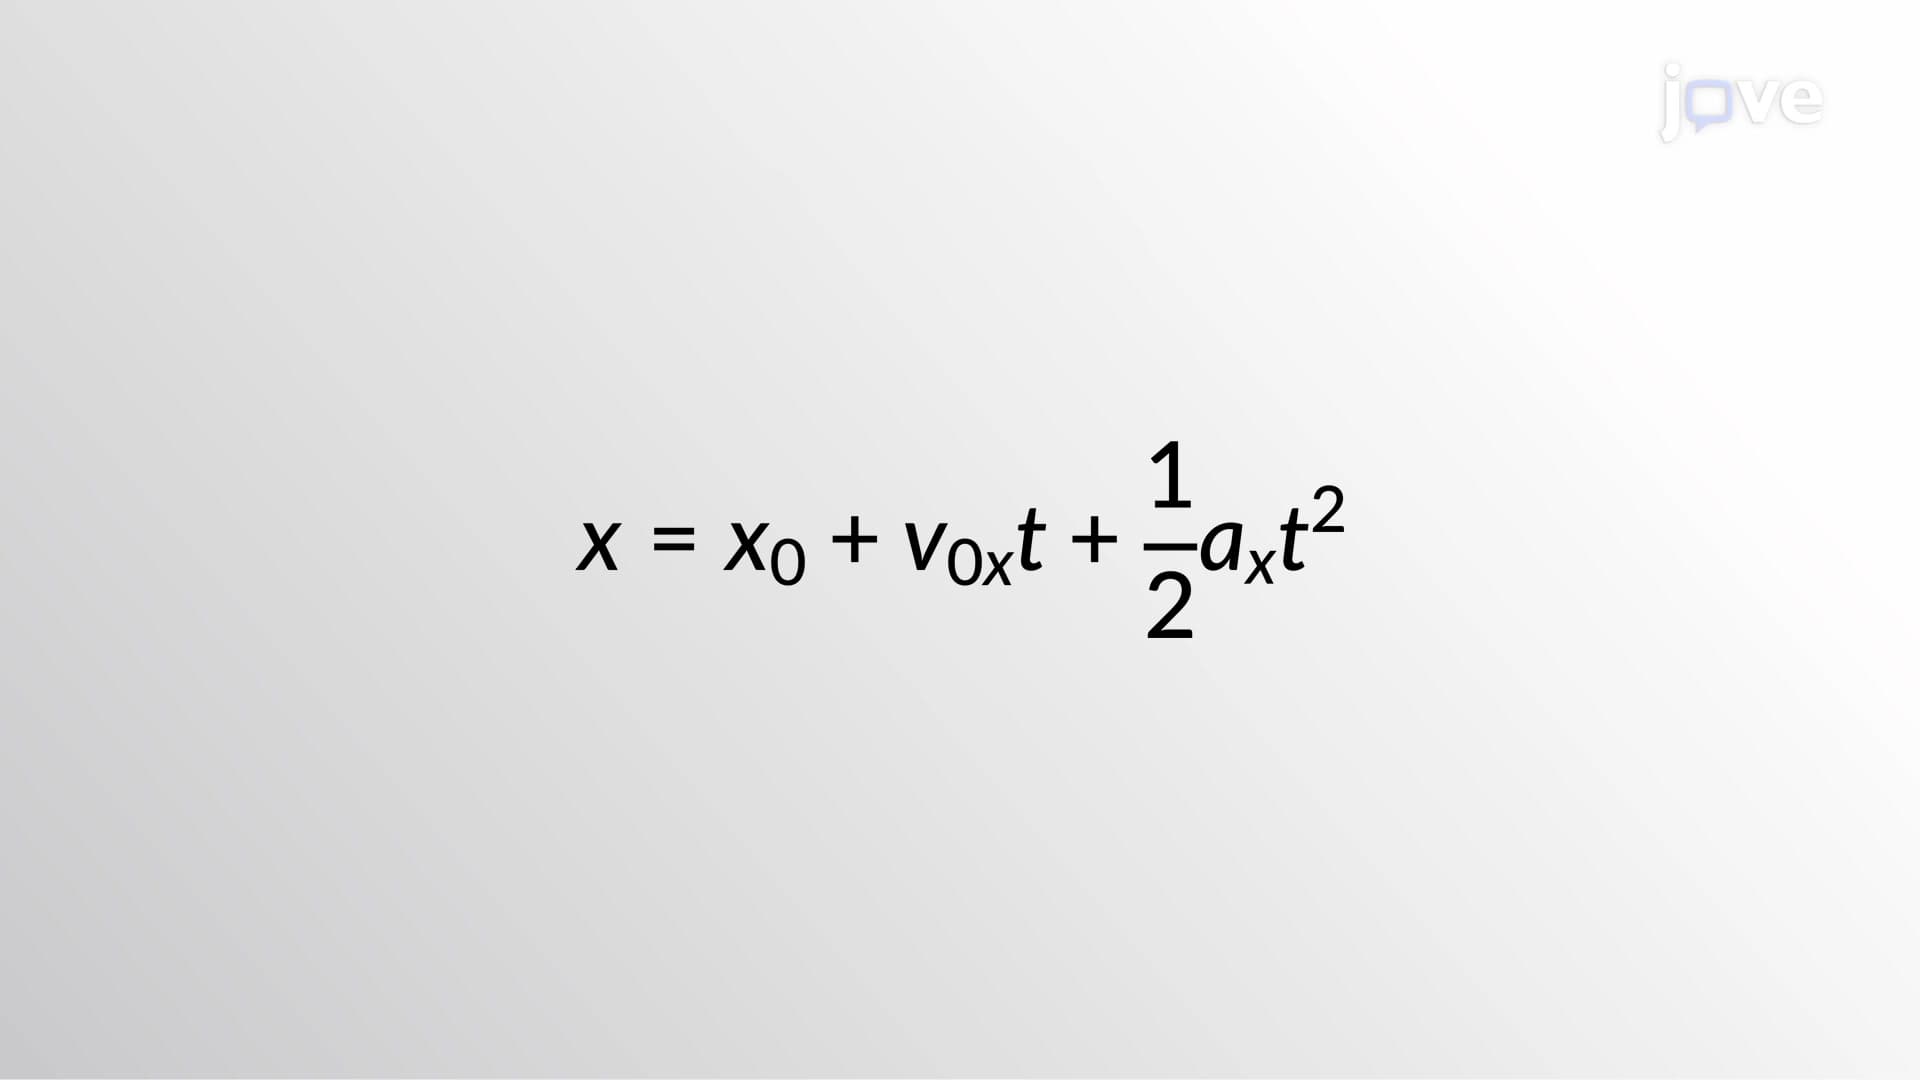 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:15
Kinematic Equations: Problem Solving
 01:26
Kinematic Equations - I
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...