Related Experiment Video
Updated: Mar 30, 2026
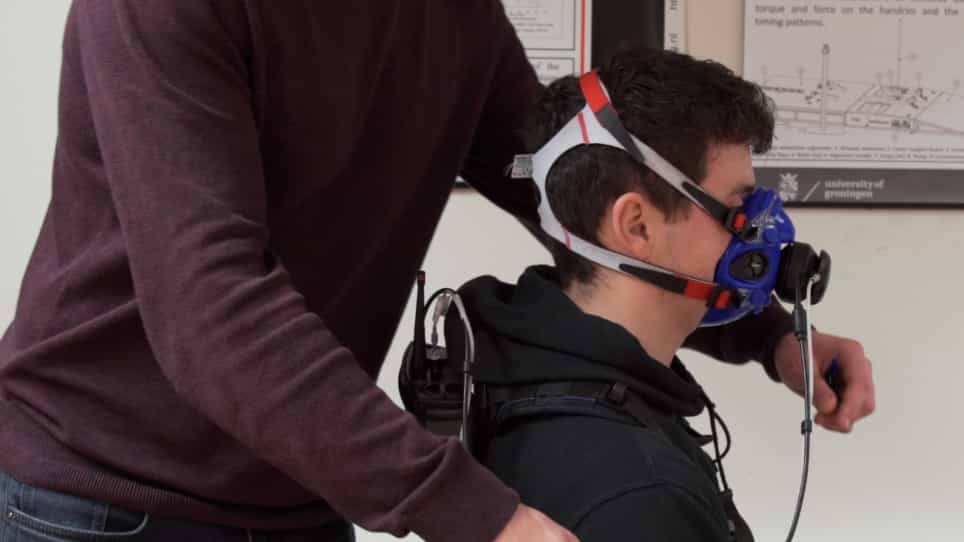

Determining and Controlling External Power Output During Regular Handrim Wheelchair Propulsion
Published on: February 5, 2020
Participatory design and validation of mobility enhancement robotic wheelchair
Brandon Daveler1, Benjamin Salatin, Garrett G Grindle
1Department of Rehabilitation Science and Technology, University of Pittsburgh, Pittsburgh, PA; and.

Abstract:
The design of the mobility enhancement robotic wheelchair (MEBot) was based on input from electric powered wheelchair (EPW) users regarding the conditions they encounter when driving in both indoor and outdoor environments that may affect their safety and result in them becoming immobilized, tipping over, or falling out of their wheelchair. Phase I involved conducting a participatory design study to understand the conditions and barriers EPW users found to be difficult to drive in/over. Phase II consisted of creating a computer-aided design (CAD) prototype EPW to provide indoor and outdoor mobility that addressed these conditions with advanced applications. Phase III involved demonstrating the advanced applications and gathering feedback from end users about the likelihood they would use the advanced applications. The CAD prototype incorporated advanced applications, including self-leveling, curb climbing, and traction control, that addressed the challenging conditions and barriers discussed with EPW users (n = 31) during the participatory design study. Feedback of the CAD design and applications in phase III from end users (n = 12) showed a majority would use self-leveling (83%), traction control (83%), and curb climbing (75%). The overall design of MEBot received positive feedback from EPW users. However, these opinions will need to be reevaluated through user trials as the design advances.
More Related Videos
 04:49
Author Spotlight: Enhancing Post-Stroke Upper Limb Rehabilitation with Robotic Technologies for Improved Motor Recovery and Functional Outcomes
Published on: September 6, 2024
 06:44
Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020