Related Experiment Video
Updated: Mar 29, 2026
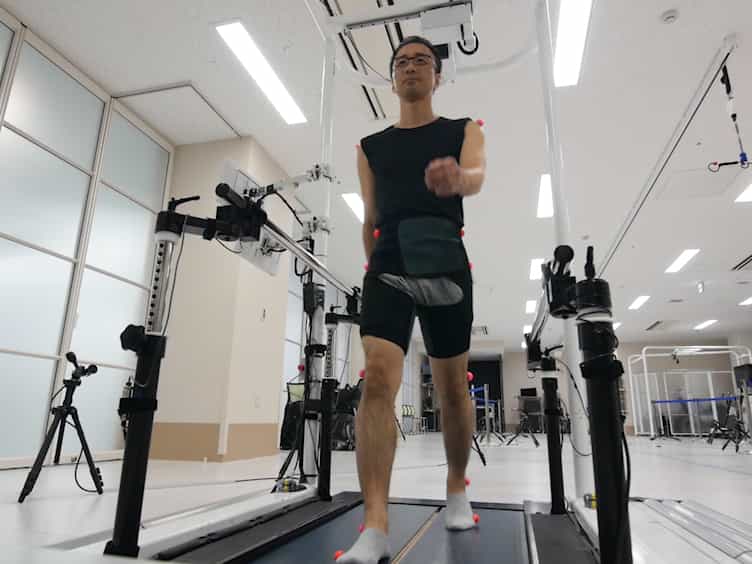
Clinical-oriented Three-dimensional Gait Analysis Method for Evaluating Gait Disorder
Published on: March 4, 2018
Modelling of the toe trajectory during normal gait using circle-fit approximation
Juan Fang1,2, Kenneth J Hunt3, Le Xie2
1Jiangsu Key Laboratory of Advanced Food Manufacturing Equipment and Technology (Jiangnan University), Wuxi City, 214122, Jiangsu Province, China.

Abstract:
This work aimed to validate the approach of using a circle to fit the toe trajectory relative to the hip and to investigate linear regression models for describing such toe trajectories from normal gait. Twenty-four subjects walked at seven speeds. Best-fit circle algorithms were developed to approximate the relative toe trajectory using a circle. It was detected that the mean approximation error between the toe trajectory and its best-fit circle was less than 4 %. Regarding the best-fit circles for the toe trajectories from all subjects, the normalised radius was constant, while the normalised centre offset reduced when the walking cadence increased; the curve range generally had a positive linear relationship with the walking cadence. The regression functions of the circle radius, the centre offset and the curve range with leg length and walking cadence were definitively defined. This study demonstrated that circle-fit approximation of the relative toe trajectories is generally applicable in normal gait. The functions provided a quantitative description of the relative toe trajectories. These results have potential application for design of gait rehabilitation technologies.
More Related Videos
 08:24
Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
 06:35
Using Gold-standard Gait Analysis Methods to Assess Experience Effects on Lower-limb Mechanics During Moderate High-heeled Jogging and Running
Published on: September 14, 2017
Related Concept Videos
 01:26
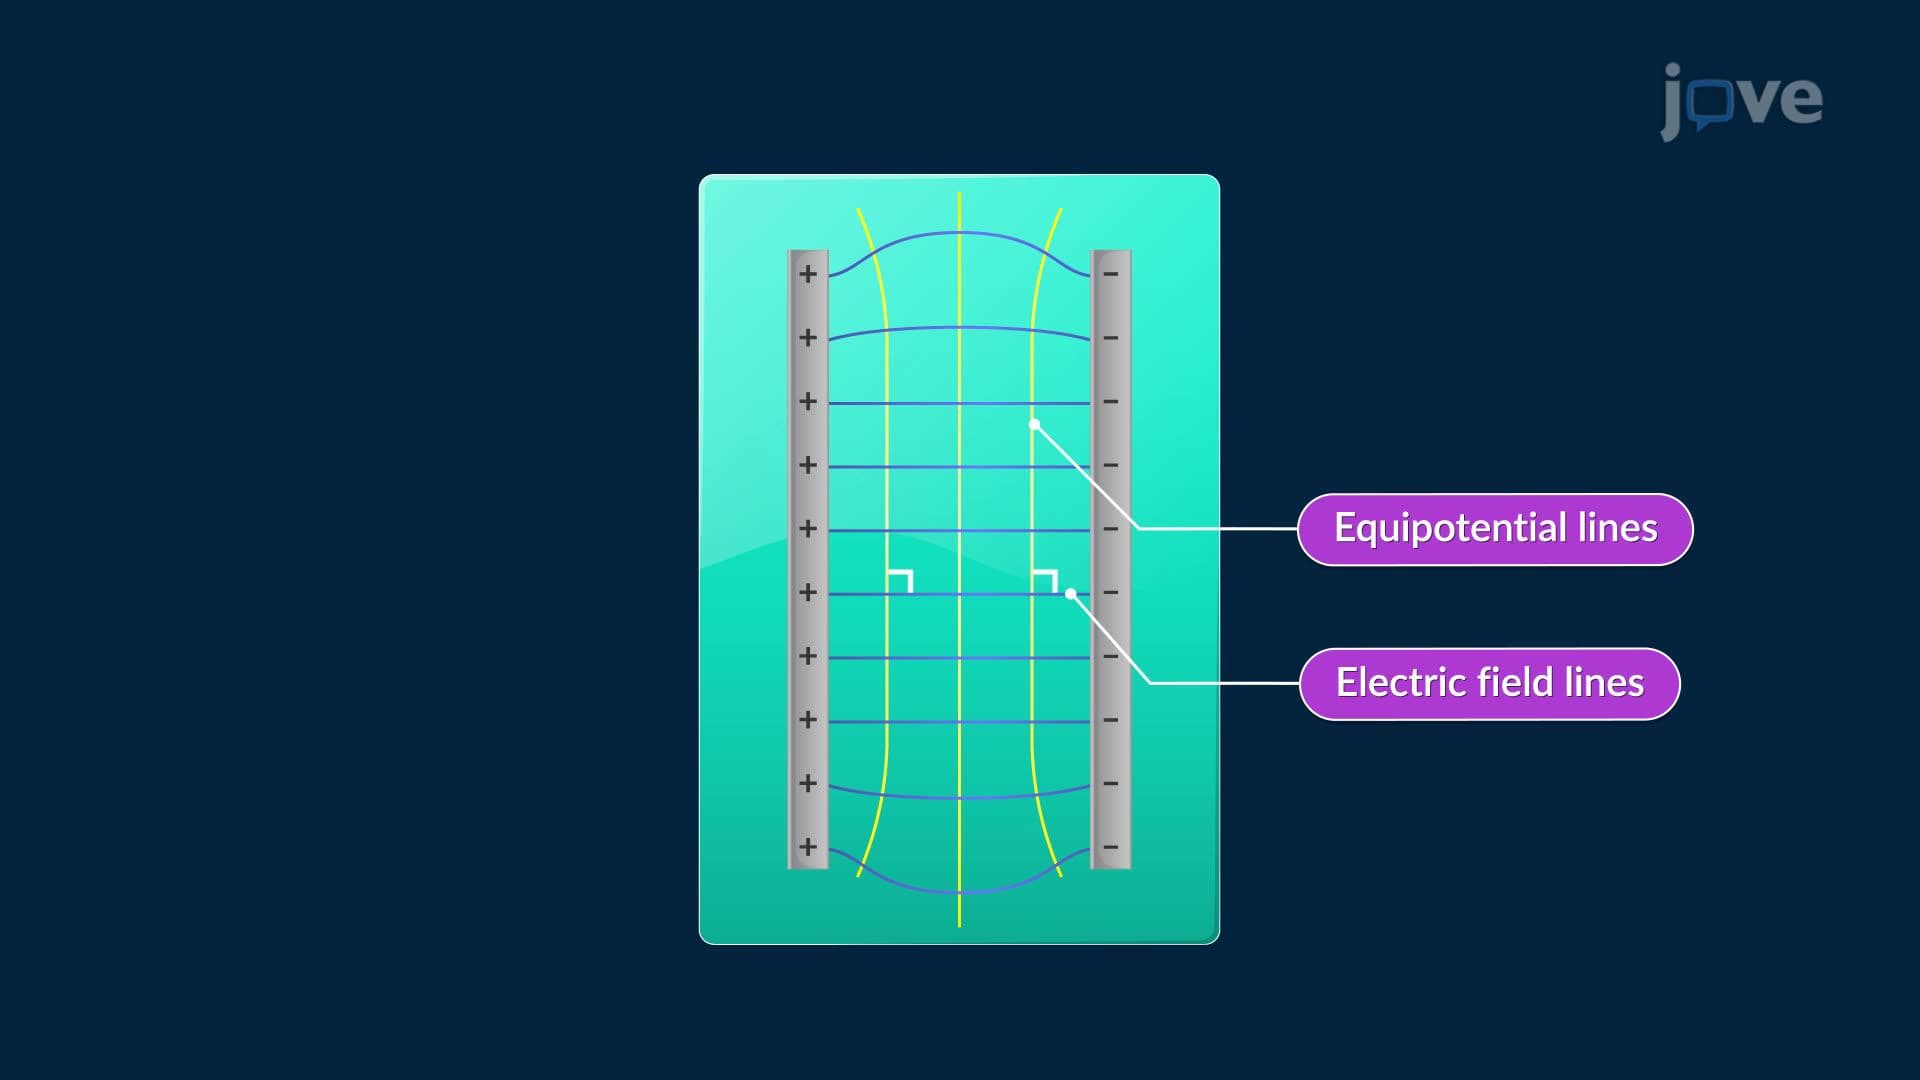
Orthogonal Trajectories
 01:15
Kinematic Equations: Problem Solving
 01:10
Deformation in a Circular Shaft
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
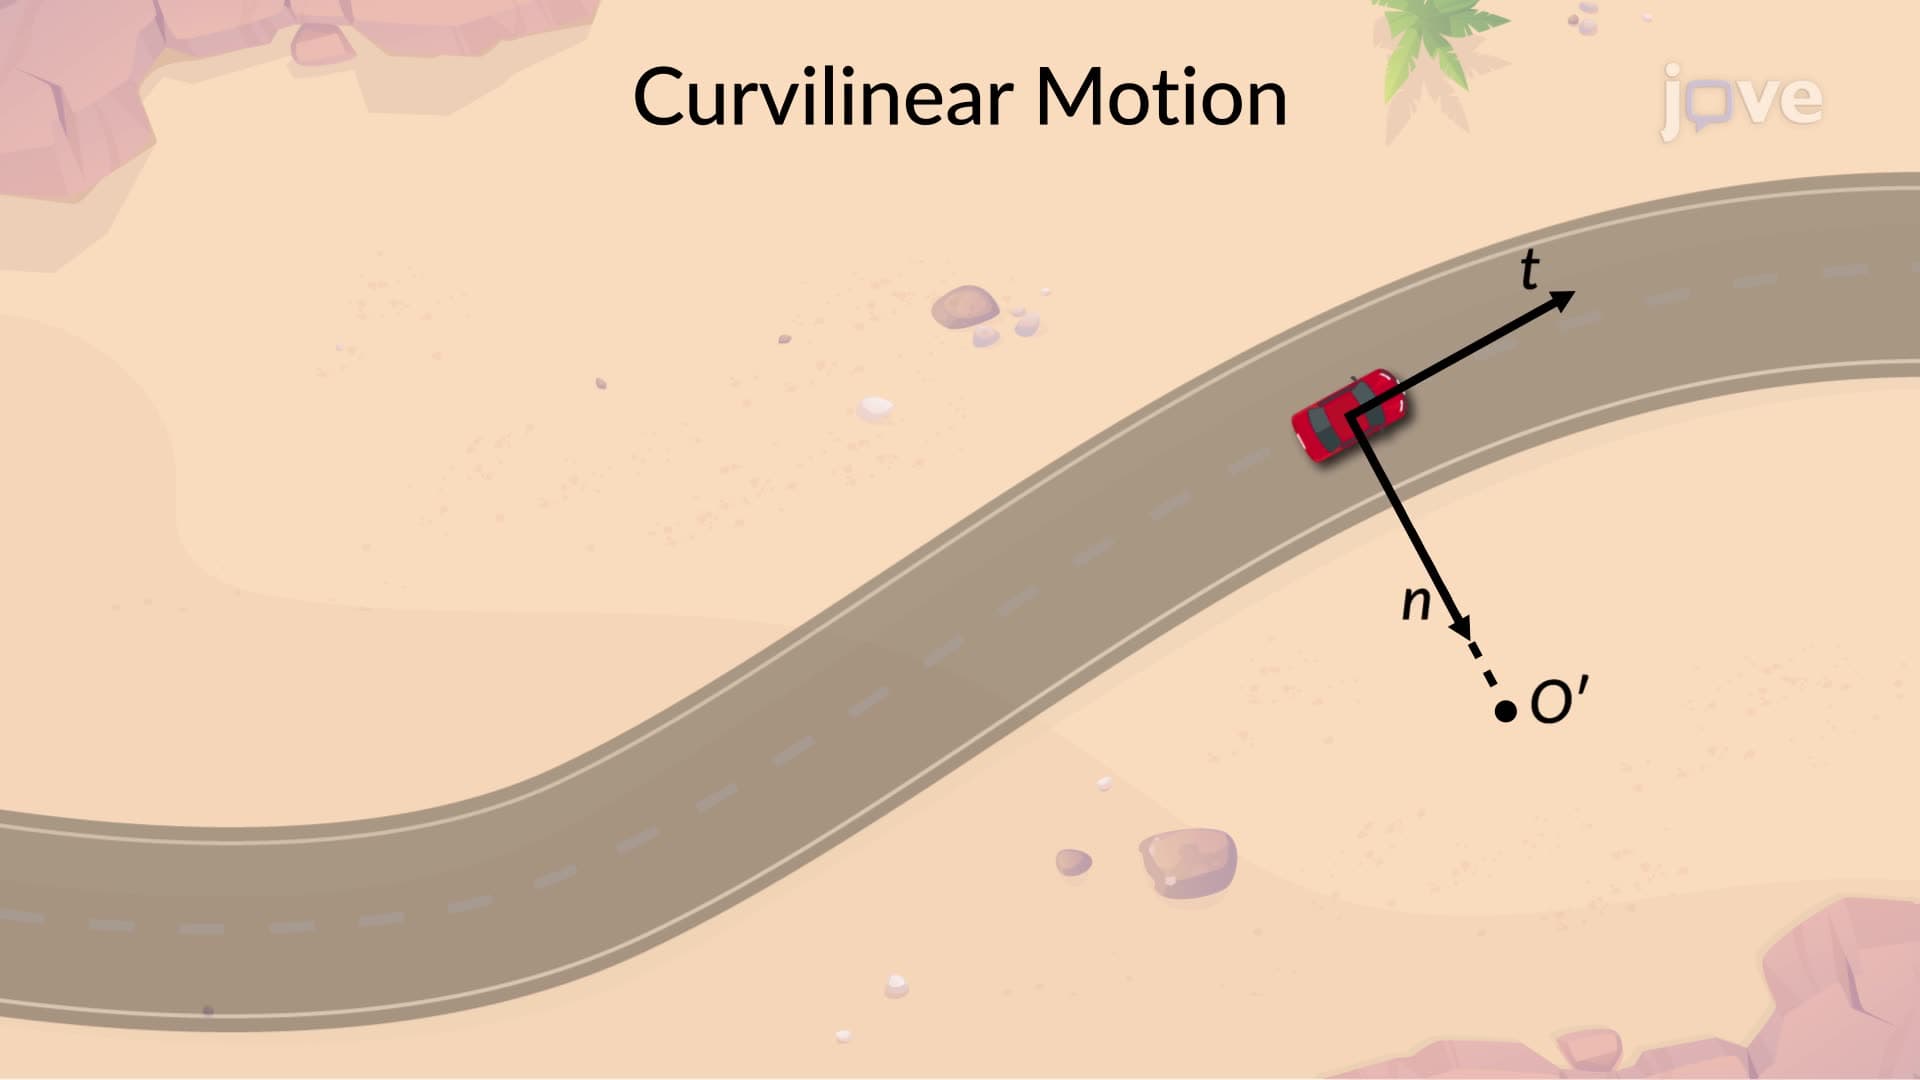 01:27
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...