Related Experiment Video
Updated: Mar 29, 2026
Home-Based Monitor for Gait and Activity Analysis
Published on: August 8, 2019
Fourier-based integration of quasi-periodic gait accelerations for drift-free displacement estimation using inertial
Angelo Maria Sabatini1, Gabriele Ligorio2, Andrea Mannini3
1The BioRobotics Institute, Scuola Superiore Sant'Anna, Viale Rinaldo Piaggio, 34, 56025, Pontedera, Pisa, Italy. sabatini@sssup.it.

Background:
In biomechanical studies Optical Motion Capture Systems (OMCS) are considered the gold standard for determining the orientation and the position (pose) of an object in a global reference frame. However, the use of OMCS can be difficult, which has prompted research on alternative sensing technologies, such as body-worn inertial sensors.
Methods:
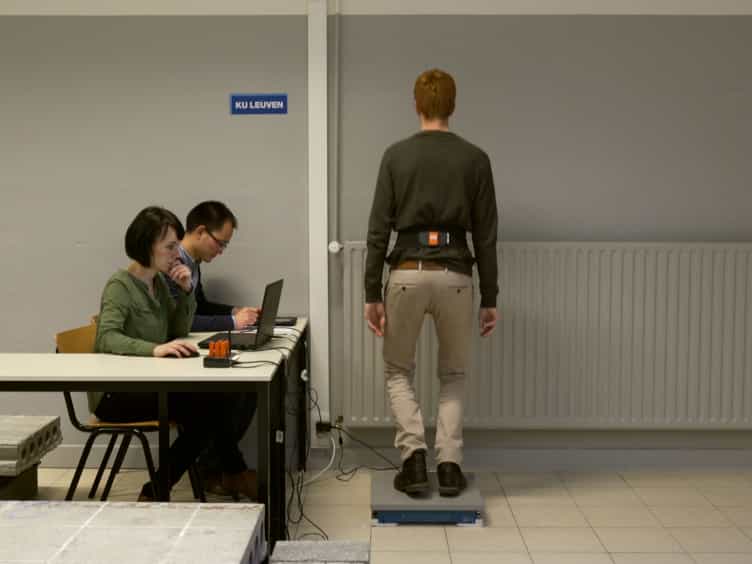
We developed a drift-free method to estimate the three-dimensional (3D) displacement of a body part during cyclical motions using body-worn inertial sensors. We performed the Fourier analysis of the stride-by-stride estimates of the linear acceleration, which were obtained by transposing the specific forces measured by the tri-axial accelerometer into the global frame using a quaternion-based orientation estimation algorithm and detecting when each stride began using a gait-segmentation algorithm. The time integration was performed analytically using the Fourier series coefficients; the inverse Fourier series was then taken for reconstructing the displacement over each single stride. The displacement traces were concatenated and spline-interpolated to obtain the entire trace.
Results:
The method was applied to estimate the motion of the lower trunk of healthy subjects that walked on a treadmill and it was validated using OMCS reference 3D displacement data; different approaches were tested for transposing the measured specific force into the global frame, segmenting the gait and performing time integration (numerically and analytically). The width of the limits of agreements were computed between each tested method and the OMCS reference method for each anatomical direction: Medio-Lateral (ML), VerTical (VT) and Antero-Posterior (AP); using the proposed method, it was observed that the vertical component of displacement (VT) was within ±4 mm (±1.96 standard deviation) of OMCS data and each component of horizontal displacement (ML and AP) was within ±9 mm of OMCS data.
Conclusions:
Fourier harmonic analysis was applied to model stride-by-stride linear accelerations during walking and to perform their analytical integration. Our results showed that analytical integration based on Fourier series coefficients was a useful approach to accurately estimate 3D displacement from noisy acceleration data.
More Related Videos
Related Concept Videos
 01:10
Relative Motion Analysis - Acceleration
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:12
Measuring Acceleration Due to Gravity
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
 01:29
Distance Problem
 01:34
Velocity and Position by Graphical Method
 01:03
Inertial Frames of Reference