Related Experiment Video
Updated: Mar 27, 2026
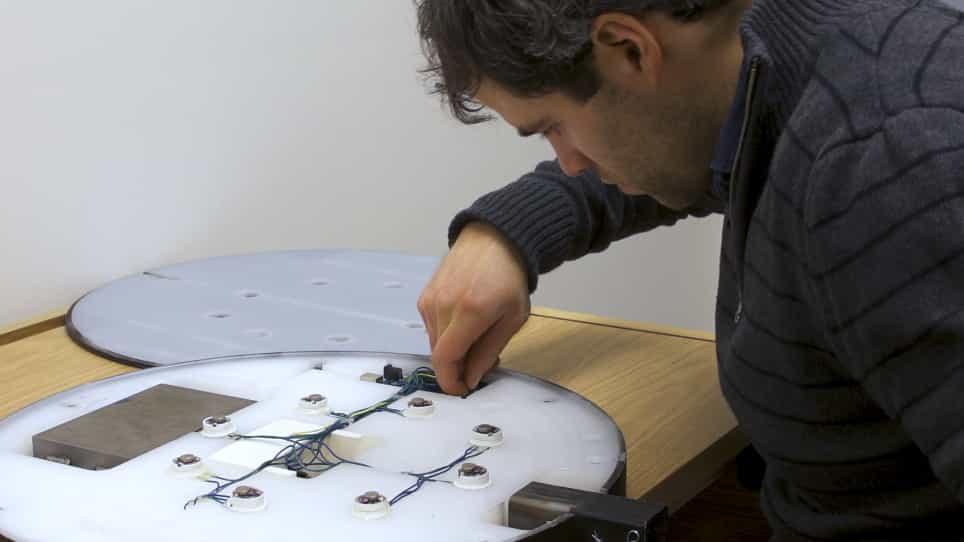

A Vibrotactile Feedback Device for Seated Balance Assessment and Training
Published on: January 20, 2019
Design and evaluation of a seat orientation controller during uneven terrain driving
Jorge Candiotti1, Hongwu Wang1, Cheng-Shiu Chung1
1Department of Rehabilitation Sciences and Technology, School of Health and Rehabilitation Sciences, University of Pittsburgh, United States.

Abstract:
Electric powered wheelchairs (EPWs) are essential devices for people with disabilities as aids for mobility and quality of life improvement. However, the design of currently available common EPWs is still limited and makes it challenging for the users to drive in both indoor and outdoor environments such as uneven surfaces, steep hills, or cross slopes, making EPWs susceptible to loss of stability and at risk for falls. An alternative wheel-legged robotic wheelchair, "MEBot", was designed to improve the safety and mobility of EPW users in both indoor and outdoor environments. MEBot is able to elevate its six wheels using pneumatic actuators, as well to detect changes in the seat angle using a gyroscope and accelerometer. This capability enables MEBot to provide sensing for a dynamic self-leveling seat application that can maintain the center of mass within the boundaries of the wheelchair, thereby, improving EPW safety. To verify the effectiveness of the application, MEBot was tested on a motion platform with six degrees of freedom to simulate different slopes that could be experienced by the EPW in outdoor environments. The results demonstrate the robustness of the application to maintain the wheelchair seat in a horizontal reference against changes in the ground angle.
More Related Videos
 07:40
Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:19
Root-Locus Method
This system can be represented by a block...
 01:17
Rolling Resistance: Problem Solving
 01:19
Design Example: Maintaining Level of an Embankment
 01:24
PI Controller: Design