Related Experiment Video
Updated: Mar 26, 2026


Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Stability analysis of autonomous space systems in the presence of large disturbances: A Lyapunov-based constrained
1Department of Control Engineering, Faculty of Electrical Engineering, South Tehran Branch, Islamic Azad University (IAU), No. 209, North Iranshahr St., P.O. Box 11365/4435, Tehran, Iran.

Abstract:
The research addresses a Lyapunov-based constrained control strategy to deal with the autonomous space system in the presence of large disturbances. The aforementioned autonomous space system under control is first represented through a dynamics model and subsequently the proposed control strategy is fully investigated with a focus on the three-axis detumbling and the corresponding pointing mode control approaches. The three-axis detumbling mode control approach is designed to deal with the unwanted angular rates of the system to be zero, while the saturations of the actuators are taken into consideration. Moreover, the three-axis pointing mode control approach is designed in the similar state to deal with the rotational angles of the system to be desirable. The contribution of the research is mathematically made to propose a control law in connection with a new candidate of Lyapunov function to deal with the rotational angles and the related angular rates of the present autonomous space system with respect to state-of-the-art. A series of experiments are carried out to consider the efficiency of the proposed control strategy, as long as a number of benchmarks are realized in the same condition to verify and guarantee the strategy performance in both modes of control approaches.


Related Concept Videos
 01:28
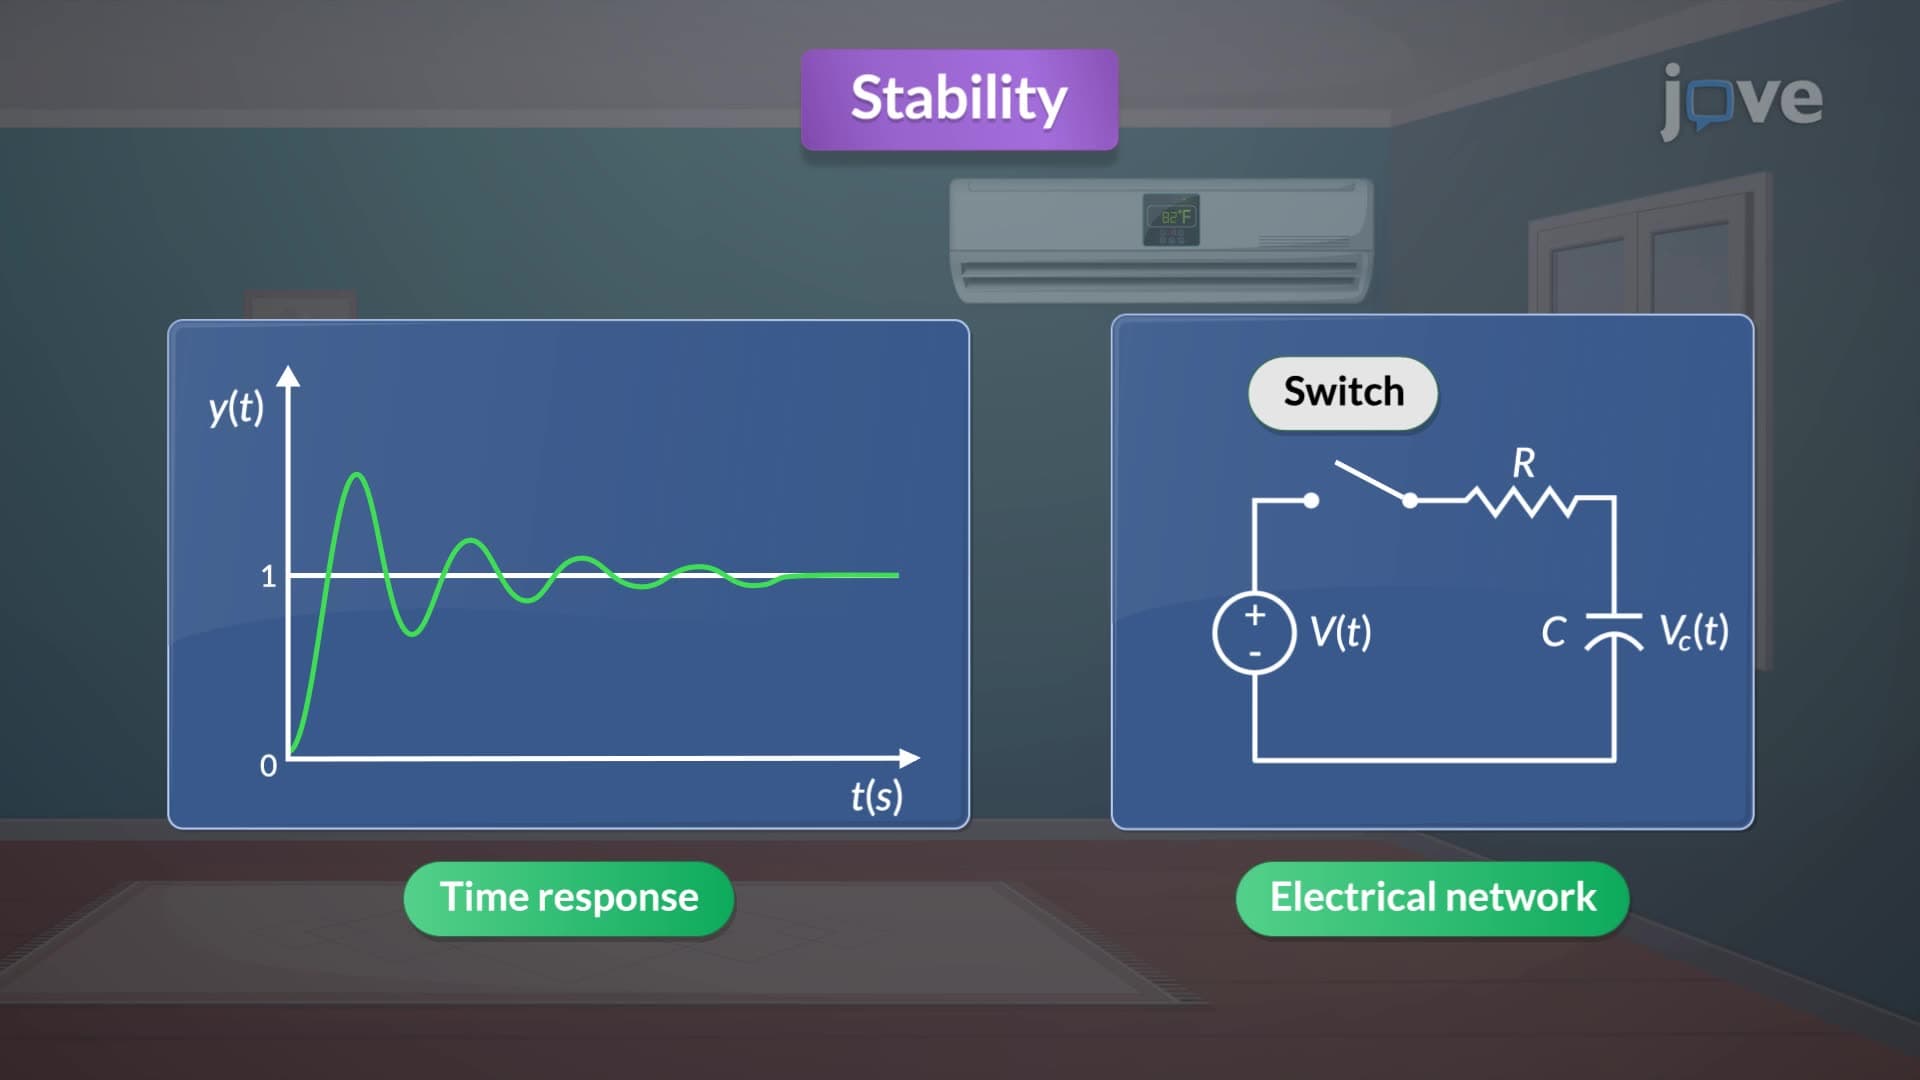
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:13
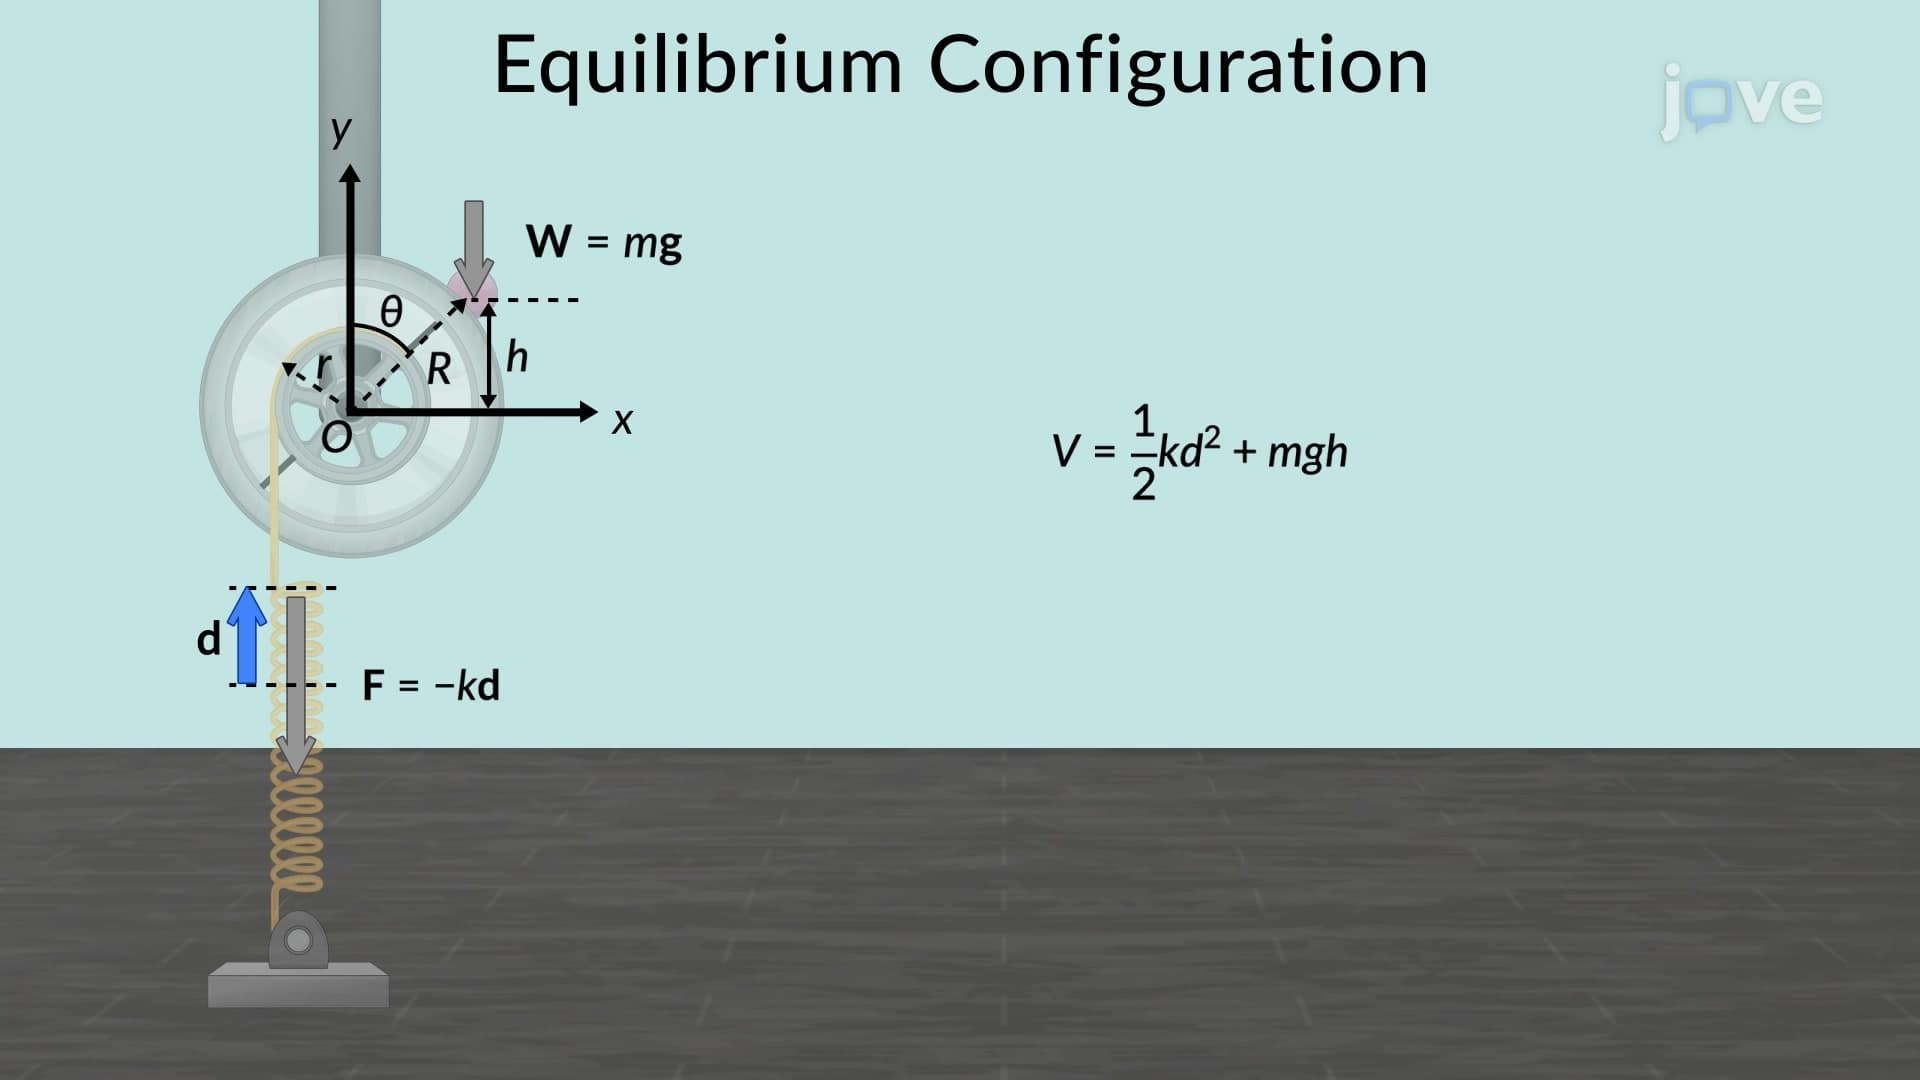
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:27
State Space Representation
Consider an RLC circuit, a...