Related Experiment Video
Updated: Mar 26, 2026


Simulation of Human-induced Vibrations Based on the Characterized In-field Pedestrian Behavior
Published on: April 13, 2016
Delay Estimation Using Instantaneous Frequency and Phase Difference--Simulation Study

Abstract:
We propose a time-domain delay estimator that takes the slope of the best fit line crossing the origin in the instantaneous frequency-phase difference plane as the delay estimate. This formulation differs from existing phase-based estimators in two respects. First, we find the instantaneous frequency at all individual sample points, including large and abrupt spikes caused by destructive interference in the coherent scattering process. This differs from Loupas which finds a smoothed-out center frequency estimate within an observation window. We show that under high signal-to-noise ratio (SNR), the information from these spikes can be properly used. Second, we show that error ought to be considered as the deviation of the phase difference from the best fit line rather than deviation from the averaged phase difference. Without considering instantaneous frequency, phase-based estimators make the following two errors: samples with phase difference far away from the center frequency need not be errors as they naturally have large phase difference when their instantaneous frequency is large; samples with phase difference close to the center frequency may in fact be errors if their instantaneous frequency is large. We derive the Gauss-Markov least-squares best fit line and then propose an iterative variant that removes samples from the line-fitting process if its deviation from the best fit line is sufficiently large. The iterative version can reduce the effect of aliasing for larger delays and also further reduce the root-mean-square error (RMSE) of the estimate. Simulation studies using various bandwidth, SNR, and delay parameters indicate that iterative phase least squares (PLS) begins to outperform correlation phase Loupas at between SNR of 30 dB (for larger bandwidths and larger delays) and 60 dB (for smaller bandwidths and smaller delays). As SNR increases, iterative PLS can reach a 30- to 50-dB increase in performance over correlation phase Loupas with respect to RMSE in the most favorable conditions.

Related Concept Videos
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...
 01:20
Frequency Response of a Circuit
The transfer function is pivotal in characterizing how these circuits react to various frequencies, facilitating a profound understanding of their behavior. An essential parameter is the time constant, signifying the...
 01:24
Properties of DTFT I
The linearity property of DTFTs is fundamental. If two discrete-time signals are multiplied by constants a and b respectively, and then combined to...
 01:10
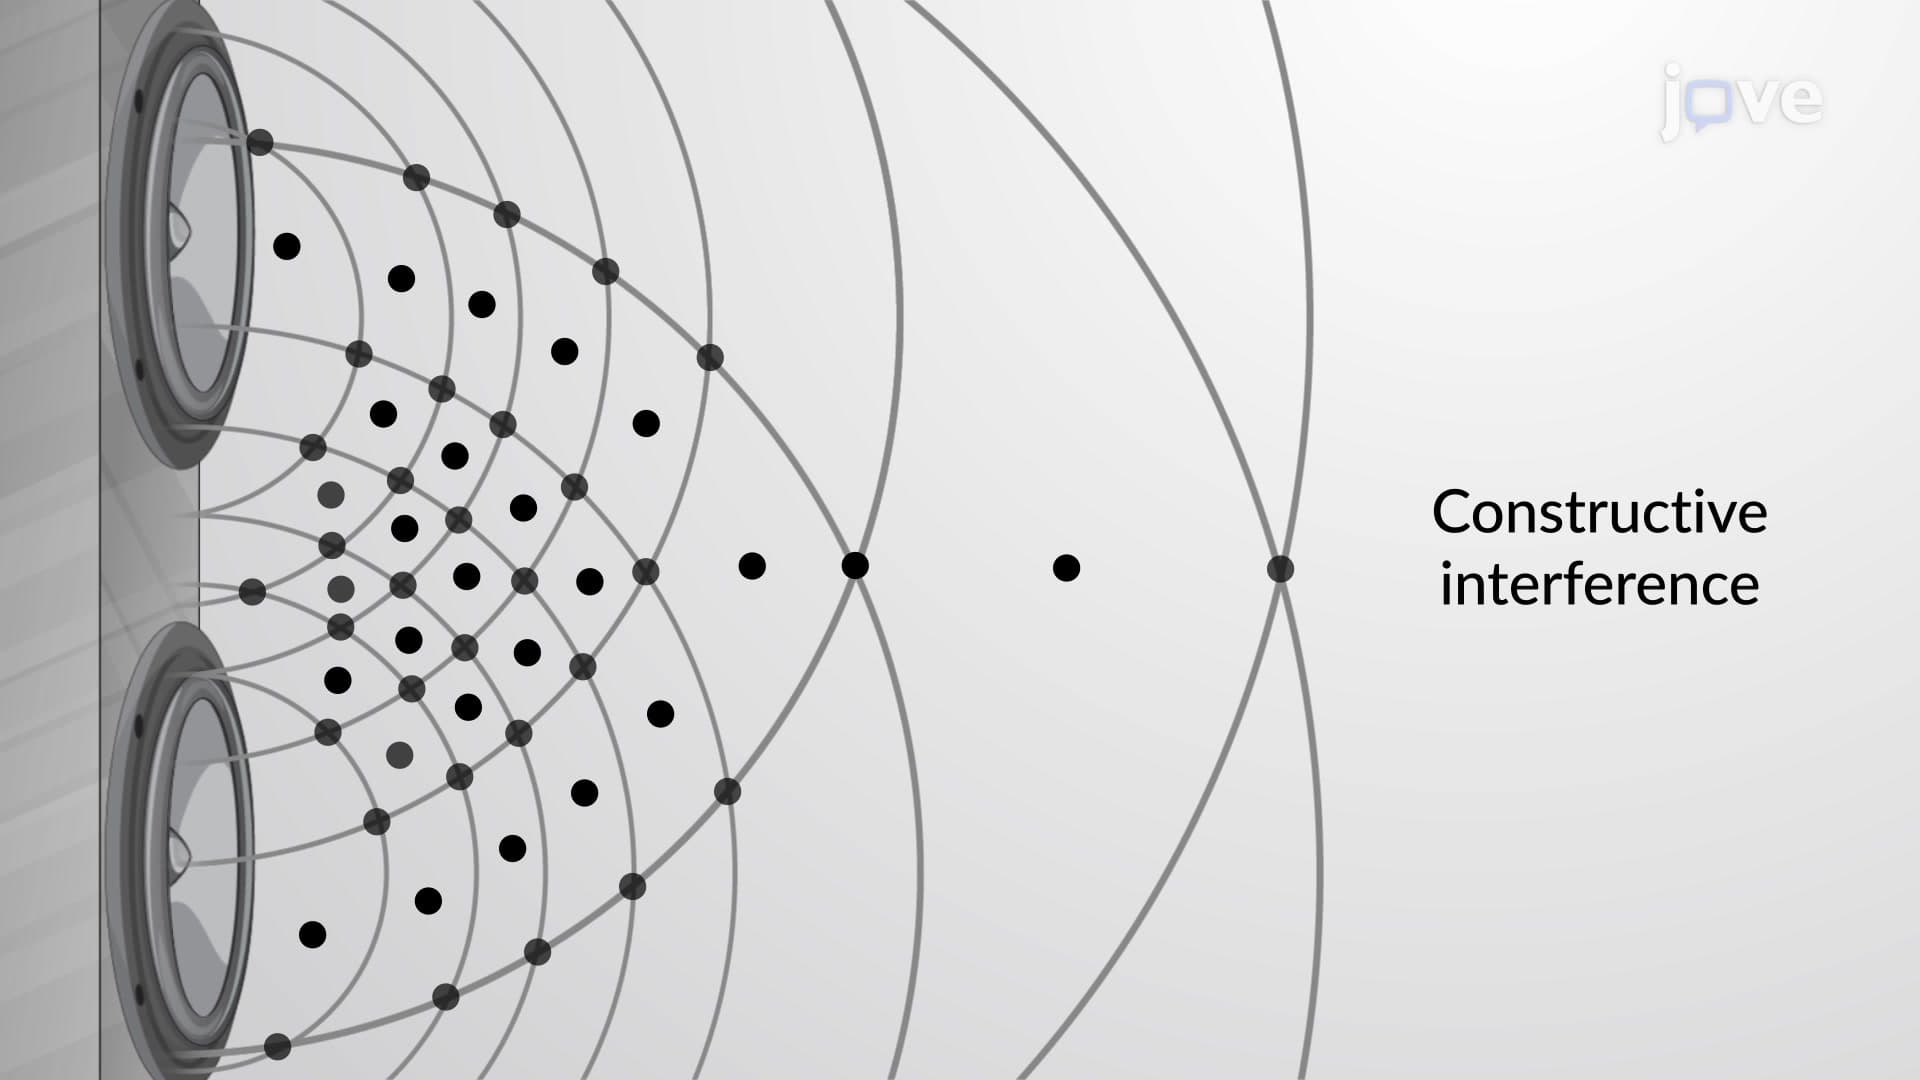
Interference: Path Lengths
Two special sources may be considered when they are in phase. This can be easily achieved by feeding the two sources from the same source. An example would be synchronizing the two speakers by feeding them with the same source, such as the sound waves produced by a tuning fork. This setup ensures that the two sources have the same frequency and are...
 01:22
Phase-lead and Phase-lag Controllers