Innovative approach in the development of computer assisted algorithm for spine pedicle screw placement
Related Experiment Video
Updated: Mar 25, 2026
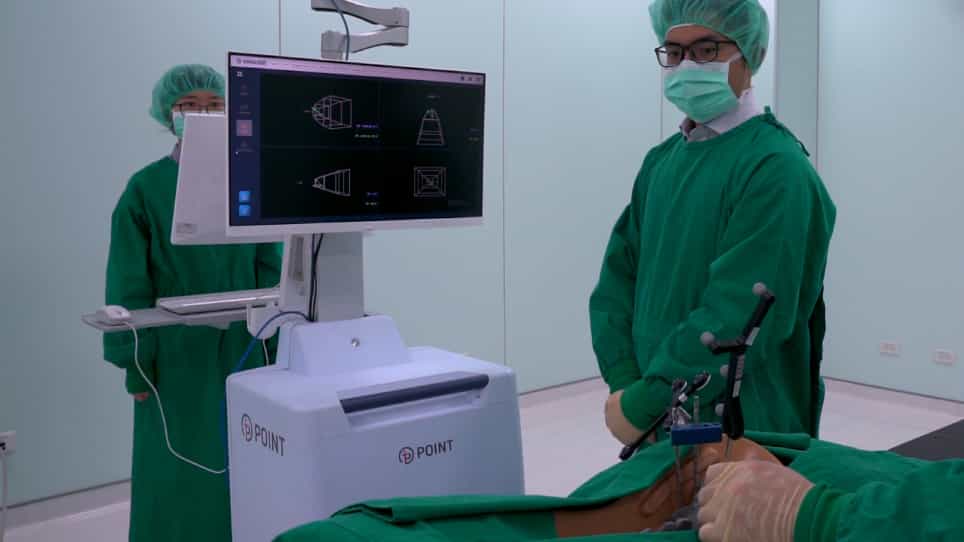
A Spine Robotic-Assisted Navigation System for Pedicle Screw Placement
Published on: May 11, 2020
Giovanni F Solitro1, Farid Amirouche2
1Department of Orthopaedics, University of Illinois at Chicago, 835 S. Wolcott Ave., Room E270, Chicago, IL 60612, USA .

Abstract:
Pedicle screws are typically used for fusion, percutaneous fixation, and means of gripping a spinal segment. The screws act as a rigid and stable anchor points to bridge and connect with a rod as part of a construct. The foundation of the fusion is directly related to the placement of these screws. Malposition of pedicle screws causes intraoperative complications such as pedicle fractures and dural lesions and is a contributing factor to fusion failure. Computer assisted spine surgery (CASS) and patient-specific drill templates were developed to reduce this failure rate, but the trajectory of the screws remains a decision driven by anatomical landmarks often not easily defined. Current data shows the need of a robust and reliable technique that prevents screw misplacement. Furthermore, there is a need to enhance screw insertion guides to overcome the distortion of anatomical landmarks, which is viewed as a limiting factor by current techniques. The objective of this study is to develop a method and mathematical lemmas that are fundamental to the development of computer algorithms for pedicle screw placement. Using the proposed methodology, we show how we can generate automated optimal safe screw insertion trajectories based on the identification of a set of intrinsic parameters. The results, obtained from the validation of the proposed method on two full thoracic segments, are similar to previous morphological studies. The simplicity of the method, being pedicle arch based, is applicable to vertebrae where landmarks are either not well defined, altered or distorted.