Related Experiment Video
Updated: Mar 24, 2026
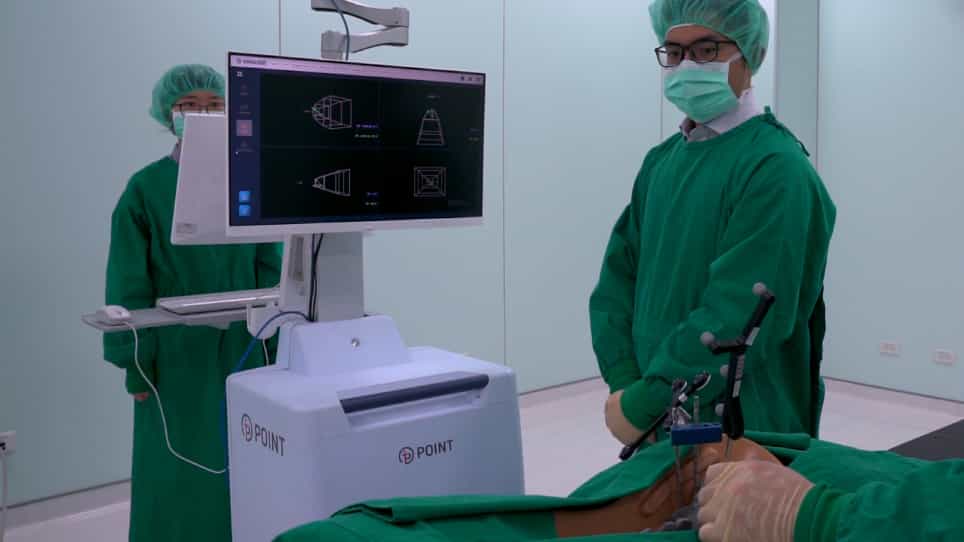
A Spine Robotic-Assisted Navigation System for Pedicle Screw Placement
Published on: May 11, 2020
Accuracy and postoperative assessment of pedicle screw placement during scoliosis surgery with computer-assisted
Wei Tian1, Cheng Zeng1, Yan An1
1Beijing Jishuitan Hospital, Beijing, China.

Background:
Accurate insertion of pedicle screws in scoliosis patients is a challenge for surgeons. Computer-assisted navigation techniques might help improve the accuracy of screw placement, thereby avoiding complications. Thus, the objective of this present work is to compare the accuracy and postoperative assessment of pedicle screw placement in scoliosis patients using a computer-assisted navigation technique and using a conventional free-hand method.
Methods:
A search of the PubMed, Cochrane, and Web of Science databases was executed. In vivo comparative studies that assessed the accuracy and postoperative evaluation of pedicle screw placement in scoliosis patients with or without navigation techniques were chosen and analyzed.
Results:
The accuracy of pedicle screw insertion was significantly increased when using the navigation system, although the average operative time and correction rate was not significantly different from that with non-navigated surgery.
Conclusion:
The navigation technique improves the accuracy of pedicle screw placement during scoliosis surgery without prolonging the operative time or decreasing the deformity correction effect. Copyright © 2016 John Wiley & Sons, Ltd.