Related Experiment Video
Updated: Mar 24, 2026


An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
Online Kinematic and Dynamic-State Estimation for Constrained Multibody Systems Based on IMUs
José Luis Torres-Moreno1, José Luis Blanco-Claraco2, Antonio Giménez-Fernández3
1Department of Engineering, Automatic Control, Robotics and Mechatronics Research Group, University of Almería, Agrifood Campus of International Excellence (ceiA3), CIESOL, Joint Center University of Almería-CIEMAT, Almería 04120, Spain. jltmoreno@ual.es.

Abstract:
This article addresses the problems of online estimations of kinematic and dynamic states of a mechanism from a sequence of noisy measurements. In particular, we focus on a planar four-bar linkage equipped with inertial measurement units (IMUs). Firstly, we describe how the position, velocity, and acceleration of all parts of the mechanism can be derived from IMU signals by means of multibody kinematics. Next, we propose the novel idea of integrating the generic multibody dynamic equations into two variants of Kalman filtering, i.e., the extended Kalman filter (EKF) and the unscented Kalman filter (UKF), in a way that enables us to handle closed-loop, constrained mechanisms, whose state space variables are not independent and would normally prevent the direct use of such estimators. The proposal in this work is to apply those estimators over the manifolds of allowed positions and velocities, by means of estimating a subset of independent coordinates only. The proposed techniques are experimentally validated on a testbed equipped with encoders as a means of establishing the ground-truth. Estimators are run online in real-time, a feature not matched by any previous procedure of those reported in the literature on multibody dynamics.


Related Concept Videos
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
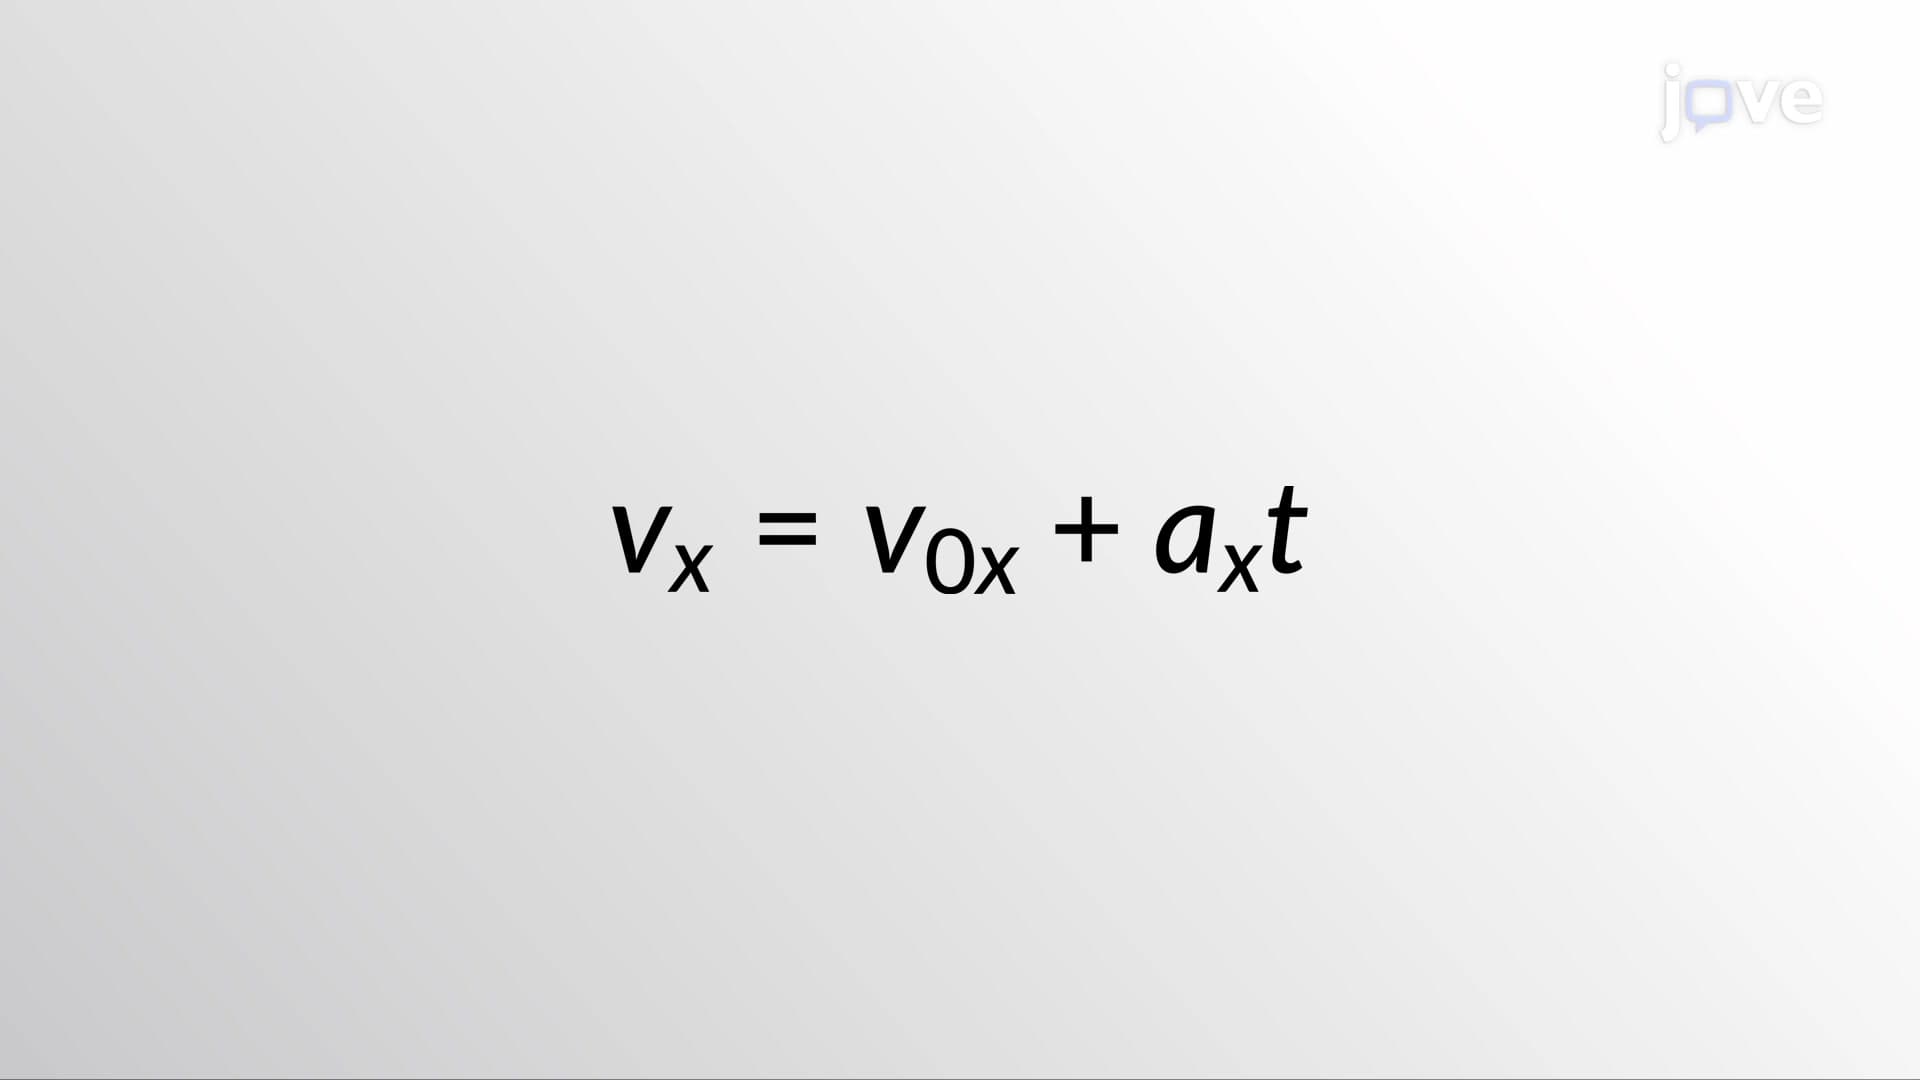 01:26
Kinematic Equations - I
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:15
Kinematic Equations: Problem Solving
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...