Related Experiment Video
Updated: Mar 24, 2026
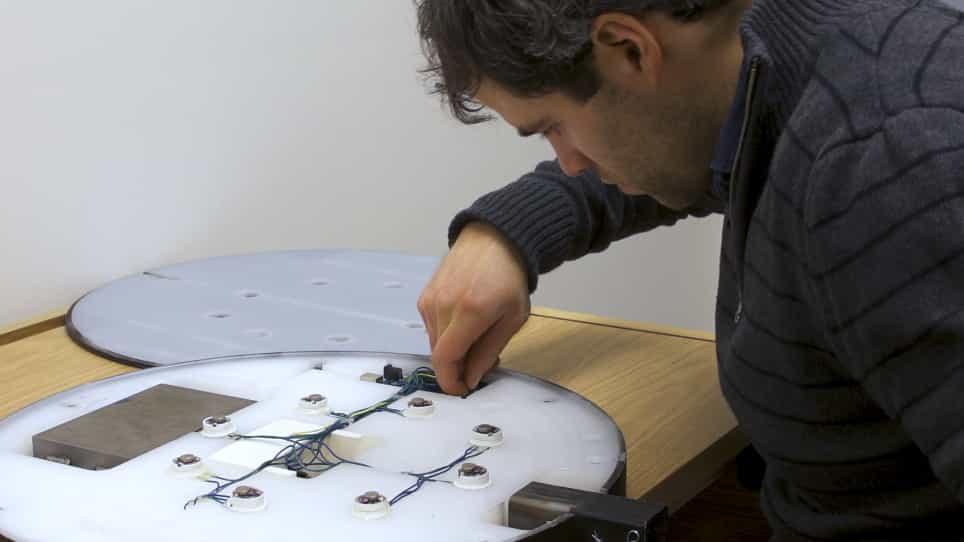

A Vibrotactile Feedback Device for Seated Balance Assessment and Training
Published on: January 20, 2019
Training Toddlers Seated on Mobile Robots to Steer Using Force-Feedback Joystick

Abstract:
The broader goal of our research is to train infants with special needs to safely and purposefully drive a mobile robot to explore the environment. The hypothesis is that these impaired infants will benefit from mobility in their early years and attain childhood milestones, similar to their healthy peers. In this paper, we present an algorithm and training method using a force-feedback joystick with an "assist-as-needed" paradigm for driving training. In this "assist-as-needed" approach, if the child steers the joystick outside a force tunnel centered on the desired direction, the driver experiences a bias force on the hand. We show results with a group study on typically developing toddlers that such a haptic guidance algorithm is superior to training with a conventional joystick. We also provide a case study on two special needs children, under three years old, who learn to make sharp turns during driving, when trained over a five-day period with the force-feedback joystick using the algorithm.
More Related Videos

Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Rolling Resistance: Problem Solving