Related Experiment Video
Updated: Mar 23, 2026
Emergency Undocking in Robotic Surgery: A Simulation Curriculum
Published on: May 20, 2018
Initial experiences with RoSS surgical simulator in residency training: a validity and model analysis
Marc Colaco1, Adrian Balica2, Daniel Su3
1Department of Urology, Robert Wood Johnson Medical School, 675 Hoes Lane, Piscataway, NJ, 08854, USA. colacoma@umdnj.edu.

Abstract:
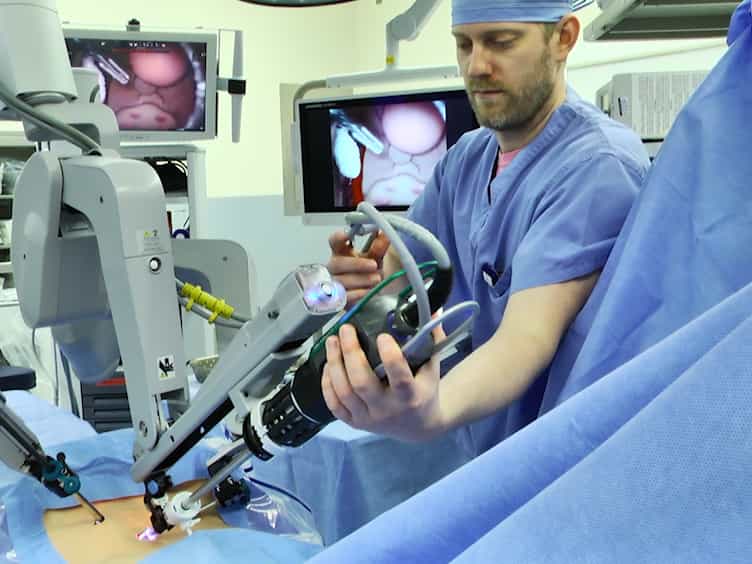
Robotic surgery is an important new tool in many surgical procedures, and training curriculums must adapt to this new technology. Robotic surgical simulators have been developed as a means of providing training without the inherent risks of actual surgery. The purpose of this study is to evaluate the construct validity of the RoSS surgical simulator by correlating simulator performance with amount of time in training and to create a performance model in which time in training is a parameter. A total of eight residents with varying amounts of training were given access to the RoSS surgical simulator and were evaluated on performance of a simulated surgical task. This data was then used to create Akaike information criteria to compare goodness of fit. Participants were also given a questionnaire as to their experience with the simulator and their feelings about the use of simulators in training. Training time and performance within the simulator were shown to have a linear relationship. Correlations were high, with R (2) values of 0.95, 0.94, and 0.86 for each of the three performance metrics. Likelihood ratios were similarly high at 4.25 × 10(9), 10,950, and 362. Participant opinion showed that residents feel that robotic training is an important part of their education and that the simulator is an effective supplement. The RoSS surgical simulator accurately corresponds to training level and is a valid evaluation tool of training experience. These findings are encouraging for the use of robotic simulators in surgical training.