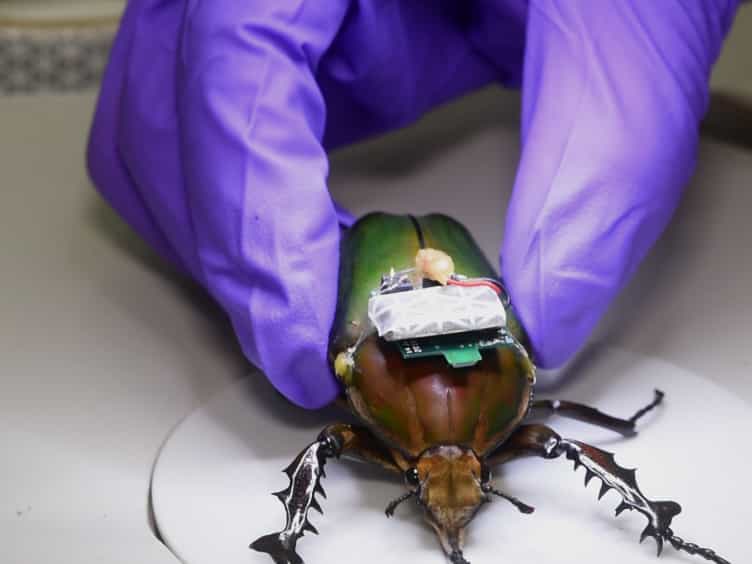
Insect-computer hybrid legged robot with user-adjustable speed, step length and walking gait
Related Experiment Video
Updated: Mar 23, 2026
Studying the Neural Basis of Adaptive Locomotor Behavior in Insects
Published on: April 13, 2011
Feng Cao1, Chao Zhang1, Hao Yu Choo1
1School of Mechanical and Aerospace Engineering, Nanyang Technological University, Singapore.

Abstract:
We have constructed an insect-computer hybrid legged robot using a living beetle (Mecynorrhina torquata; Coleoptera). The protraction/retraction and levation/depression motions in both forelegs of the beetle were elicited by electrically stimulating eight corresponding leg muscles via eight pairs of implanted electrodes. To perform a defined walking gait (e.g., gallop), different muscles were individually stimulated in a predefined sequence using a microcontroller. Different walking gaits were performed by reordering the applied stimulation signals (i.e., applying different sequences). By varying the duration of the stimulation sequences, we successfully controlled the step frequency and hence the beetle's walking speed. To the best of our knowledge, this paper presents the first demonstration of living insect locomotion control with a user-adjustable walking gait, step length and walking speed.