Sequential Non-Rigid Structure from Motion Using Physical Priors
Related Experiment Video
Updated: Mar 23, 2026
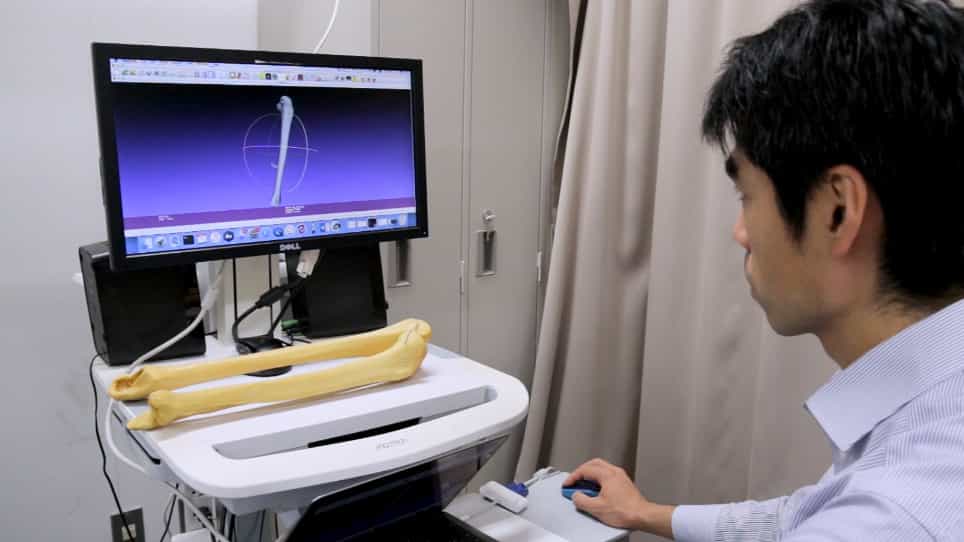
Four-Dimensional CT Analysis Using Sequential 3D-3D Registration
Published on: November 23, 2019

Abstract:
We propose a new approach to simultaneously recover camera pose and 3D shape of non-rigid and potentially extensible surfaces from a monocular image sequence. For this purpose, we make use of the Extended Kalman Filter based Simultaneous Localization And Mapping (EKF-SLAM) formulation, a Bayesian optimization framework traditionally used in mobile robotics for estimating camera pose and reconstructing rigid scenarios. In order to extend the problem to a deformable domain we represent the object's surface mechanics by means of Navier's equations, which are solved using a Finite Element Method (FEM). With these main ingredients, we can further model the material's stretching, allowing us to go a step further than most of current techniques, typically constrained to surfaces undergoing isometric deformations. We extensively validate our approach in both real and synthetic experiments, and demonstrate its advantages with respect to competing methods. More specifically, we show that besides simultaneously retrieving camera pose and non-rigid shape, our approach is adequate for both isometric and extensible surfaces, does not require neither batch processing all the frames nor tracking points over the whole sequence and runs at several frames per second.

Related Concept Videos
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...