Related Experiment Video
Updated: Mar 22, 2026


Age-dependent Dynamics of Locomotion in Caenorhabditis elegans: A Lyapunov Exponent Analysis
Published on: September 23, 2025
L1/ℓ1-Gain analysis and synthesis of Markovian jump positive systems with time delay
Junfeng Zhang1, Xudong Zhao2, Fubo Zhu3
1Institute of Information and Control, Hangzhou Dianzi University, Hangzhou 310018, China.

Abstract:
This paper is concerned with stability analysis and control synthesis of Markovian jump positive systems with time delay. The notions of stochastic stability with L1- and ℓ1-gain performances are introduced for continuous- and discrete-time contexts, respectively. Using a stochastic copositive Lyapunov function, sufficient conditions for the stability with L1/ℓ1-gain performance of the systems are established. Furthermore, mode-dependent controllers are designed to achieve the stabilization with L1/ℓ1-gain of the resulting closed-loop systems. All proposed conditions are formulated in terms of linear programming. Numerical examples are provided to verify the effectiveness of the findings of theory.
Related Concept Videos
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:21
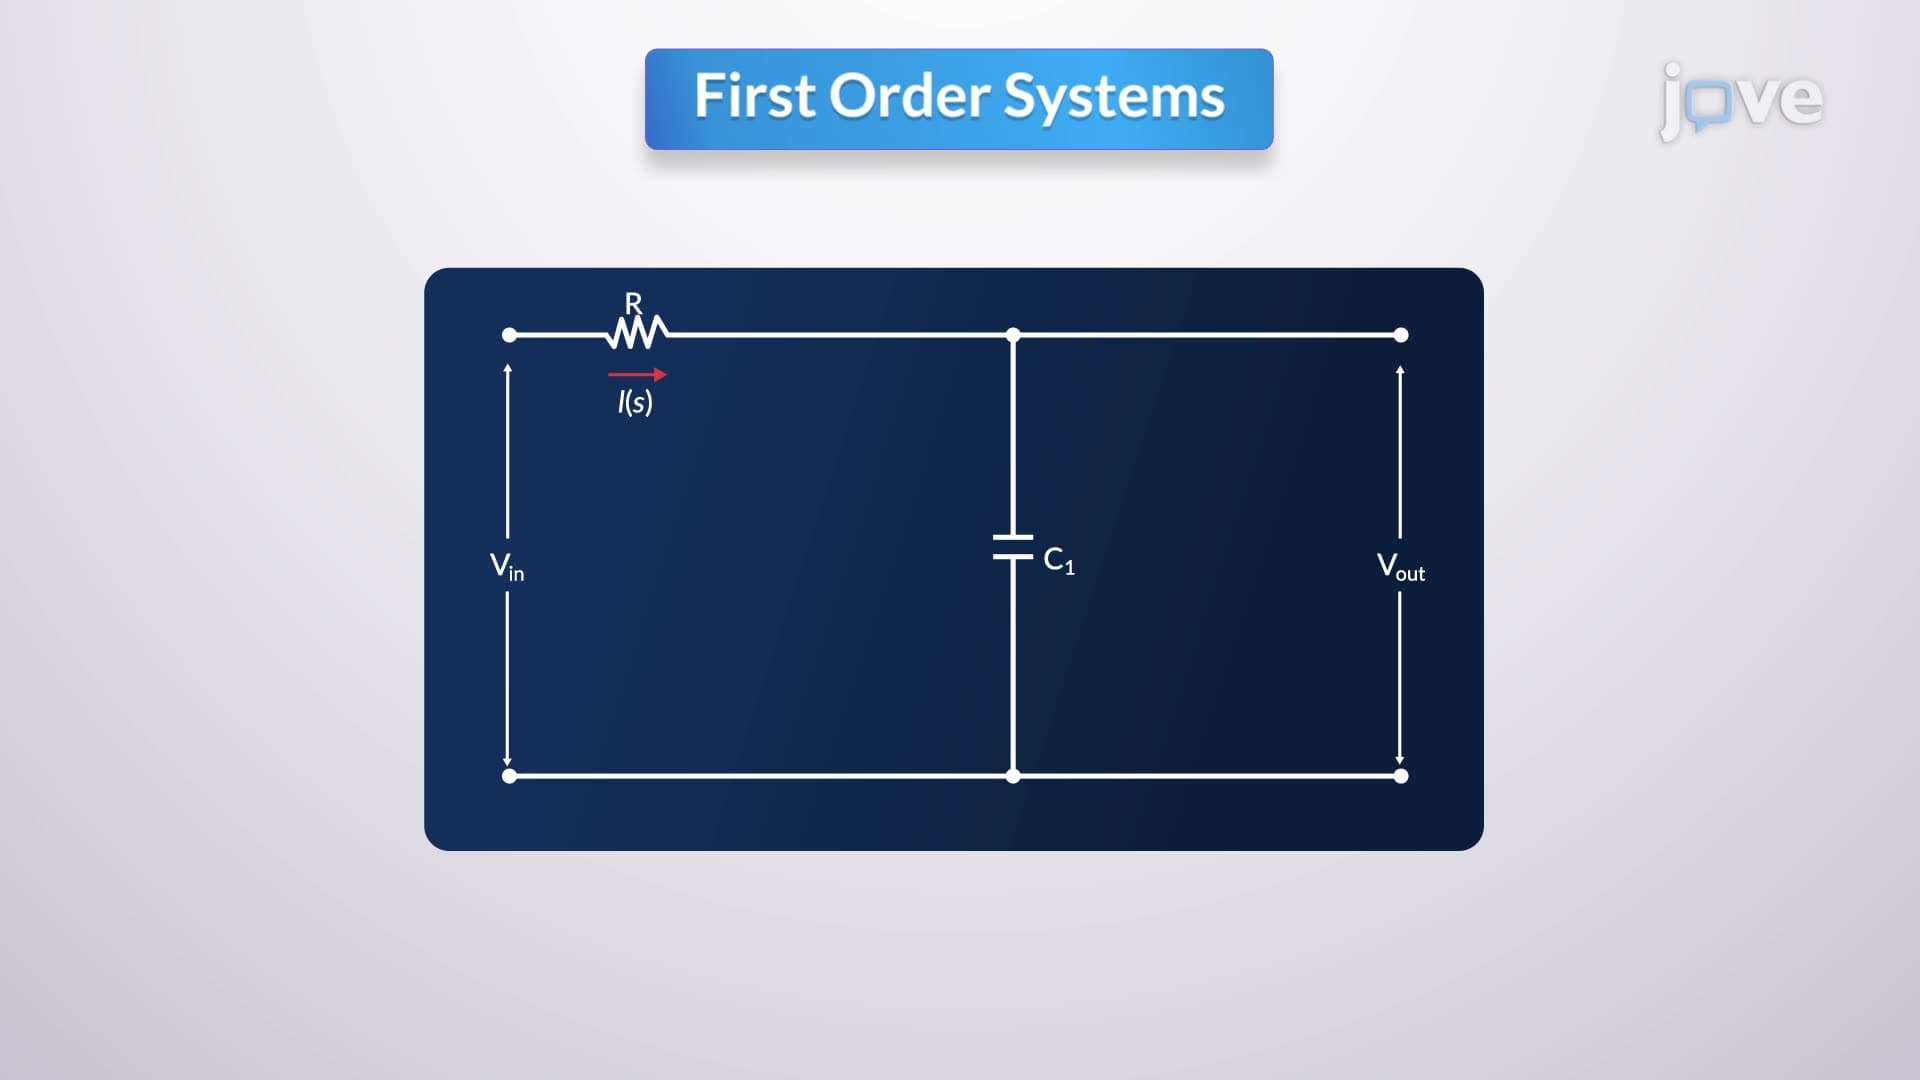
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:22
Basic Continuous Time Signals
The unit step function, denoted u(t), is zero for negative time values and one for positive time values, exhibiting a discontinuity at t=0. This function often represents abrupt changes, such as the step voltage introduced when turning a car's...
 01:16
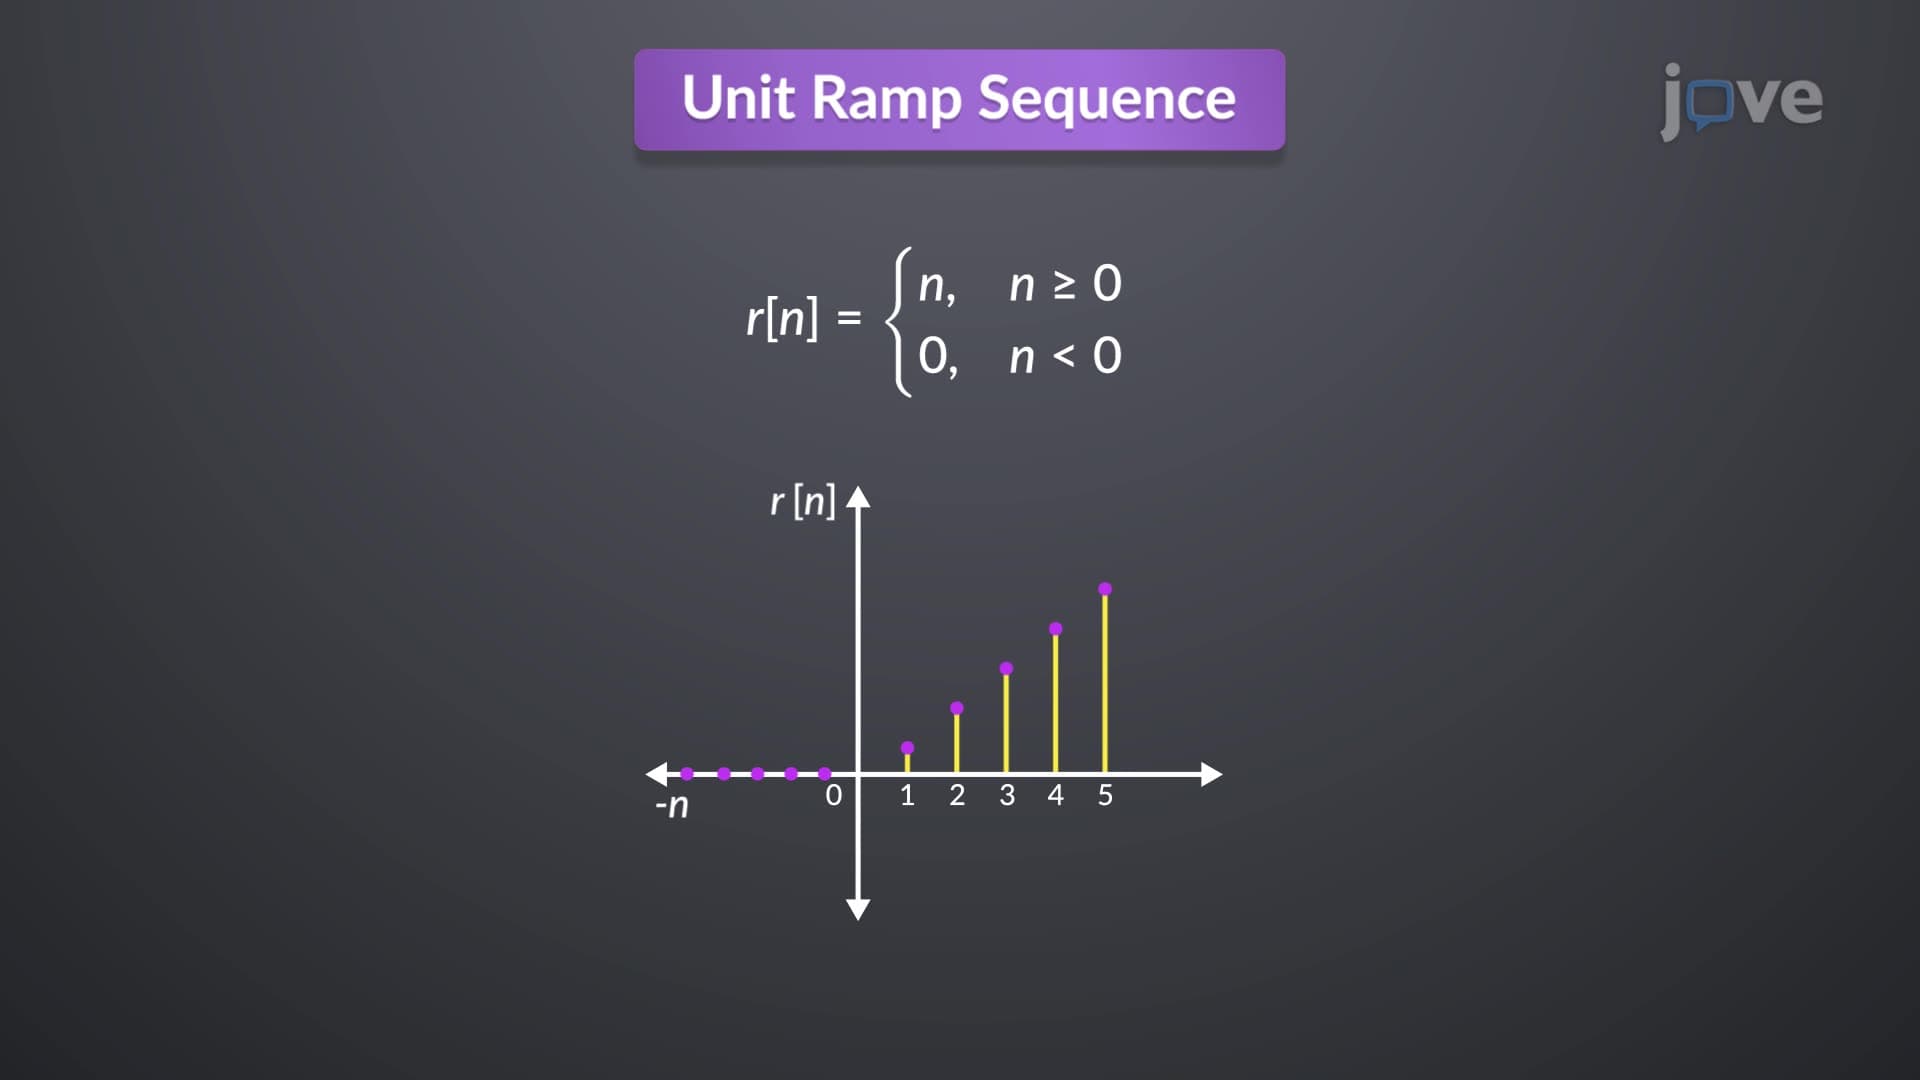
Basic Discrete Time Signals
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is the...
 01:23
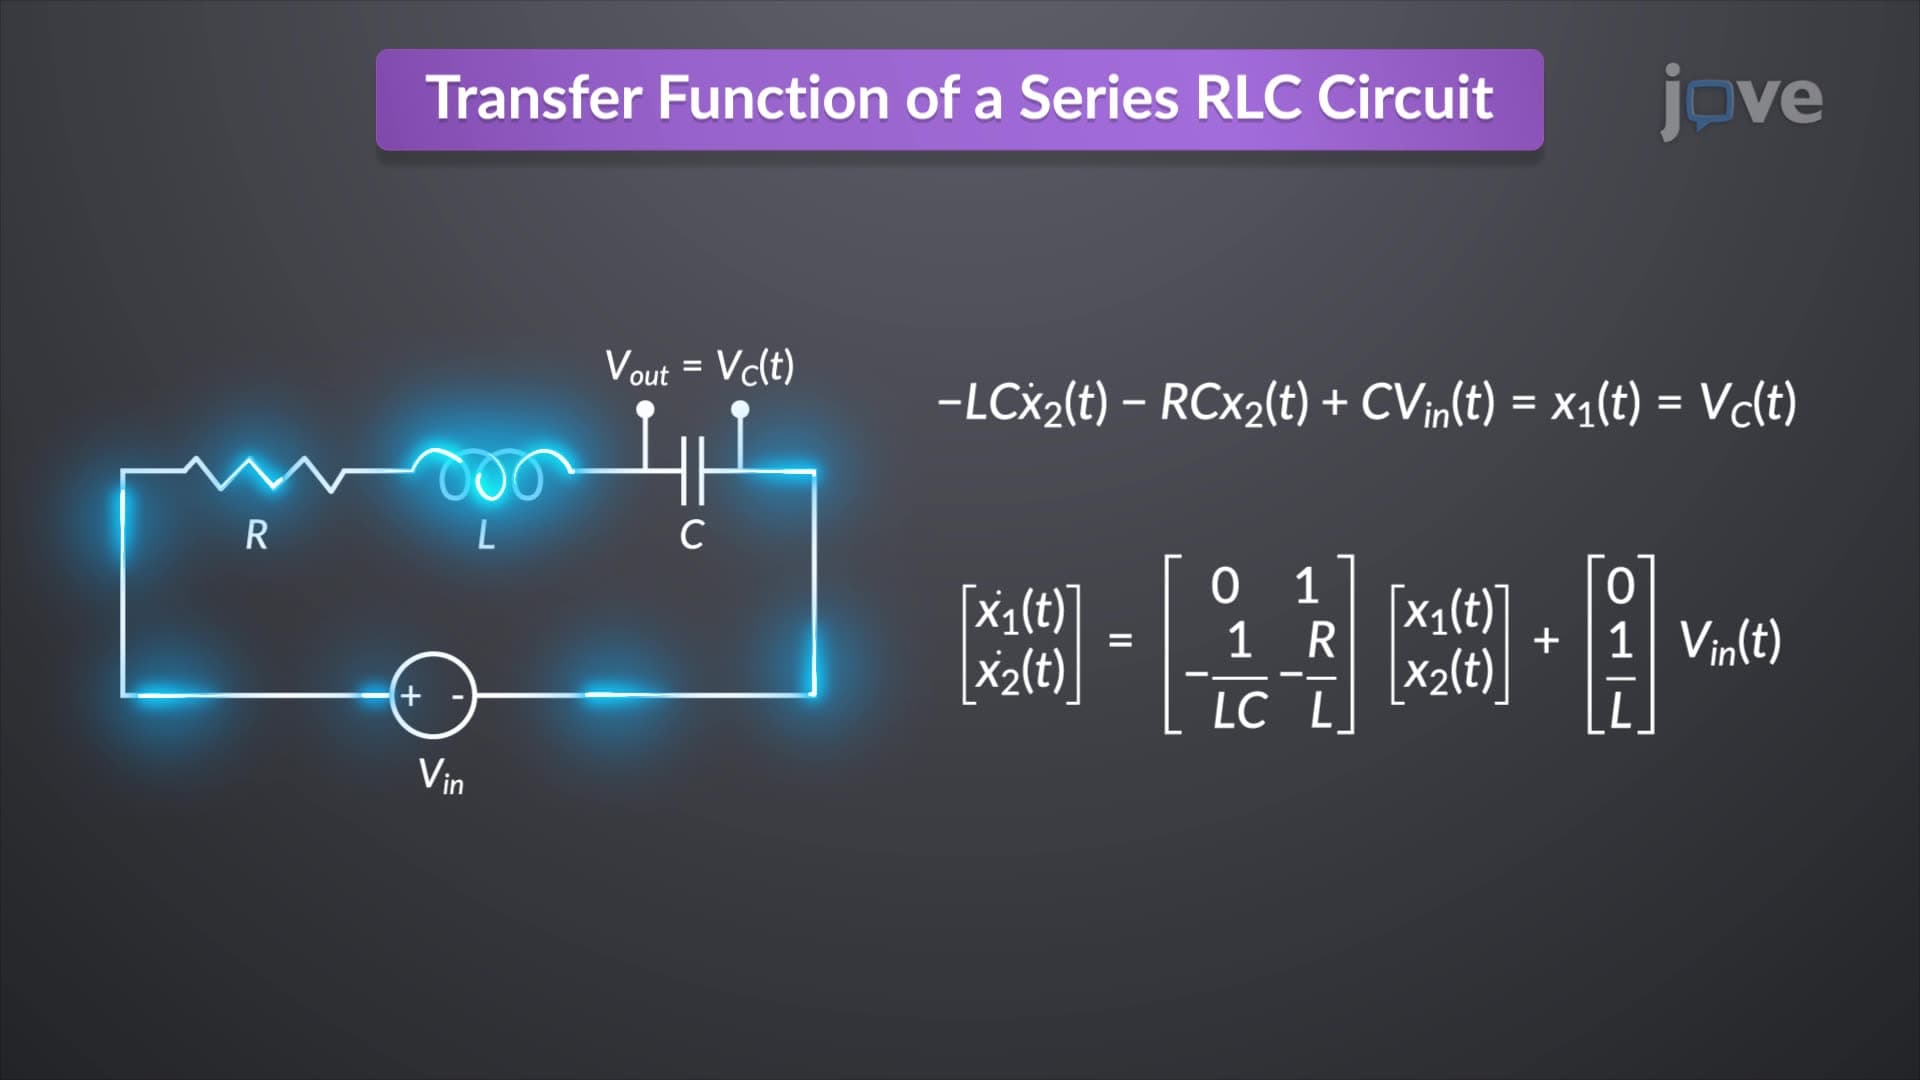
Transfer Function to State Space
In an RLC...