Related Experiment Video
Updated: Mar 18, 2026

Fabrication of Soft Pneumatic Network Actuators with Oblique Chambers
Published on: August 17, 2018
Pneumatic Variable Series Elastic Actuator
Hao Zheng1, Molei Wu1, Xiangrong Shen1
1Department of Mechanical Engineering, The University of Alabama, 359 H. M. Comer Hall, Box 870276, Tuscaloosa, AL 35487-0276.

Abstract:
Inspired by human motor control theory, stiffness control is highly effective in manipulation and human-interactive tasks. The implementation of stiffness control in robotic systems, however, has largely been limited to closed-loop control, and suffers from multiple issues such as limited frequency range, potential instability, and lack of contribution to energy efficiency. Variable-stiffness actuator represents a better solution, but the current designs are complex, heavy, and bulky. The approach in this paper seeks to address these issues by using pneumatic actuator as a variable series elastic actuator (VSEA), leveraging the compressibility of the working fluid. In this work, a pneumatic actuator is modeled as an elastic element with controllable stiffness and equilibrium point, both of which are functions of air masses in the two chambers. As such, for the implementation of stiffness control in a robotic system, the desired stiffness/equilibrium point can be converted to the desired chamber air masses, and a predictive pressure control approach is developed to control the timing of valve switching to obtain the desired air mass while minimizing control action. Experimental results showed that the new approach in this paper requires less expensive hardware (on-off valve instead of proportional valve), causes less control action in implementation, and provides good control performance by leveraging the inherent dynamics of the actuator.
Related Concept Videos
 01:03
Application of Pascal's Law
Hydraulic systems are used to operate automotive brakes, hydraulic jacks, and numerous other mechanical systems. We can derive a relationship between the forces in a simple hydraulic system...
 01:24
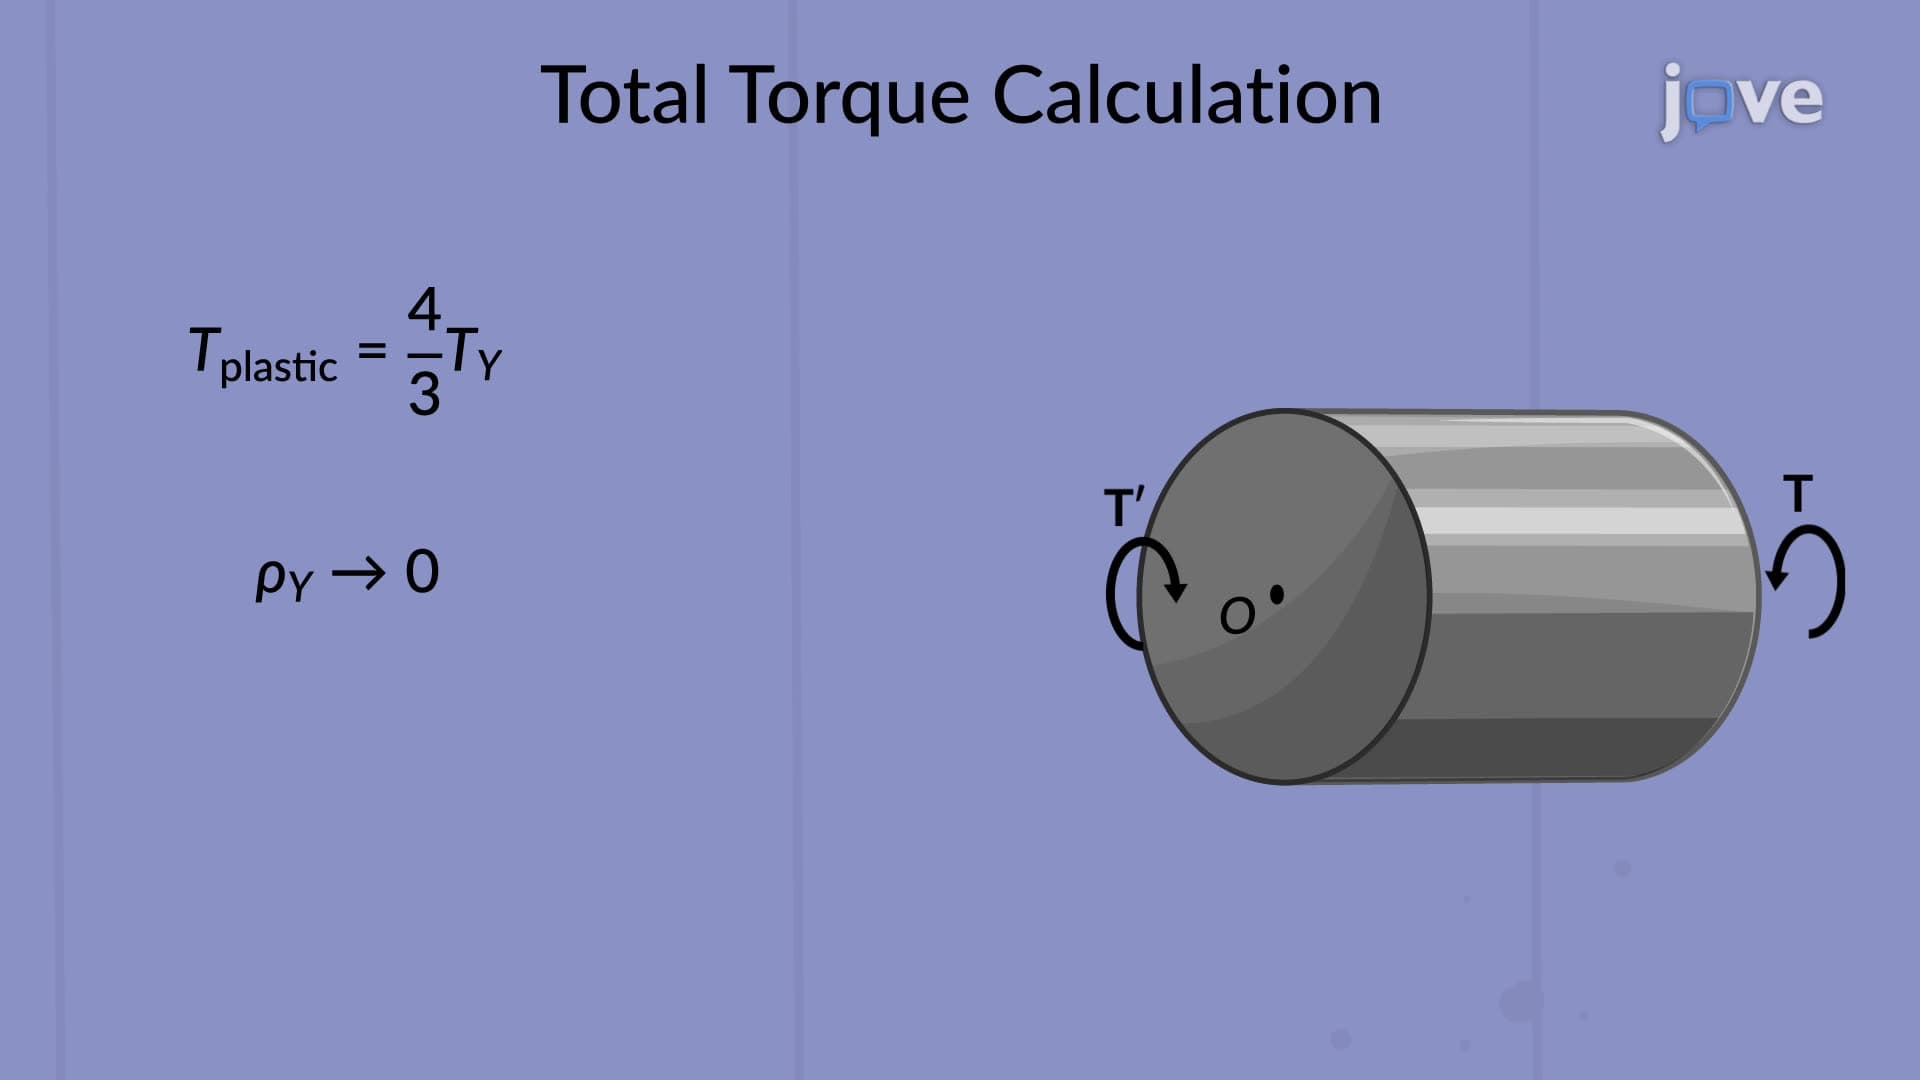
Circular Shafts - Elastoplastic Materials
As torque on the...
 01:01
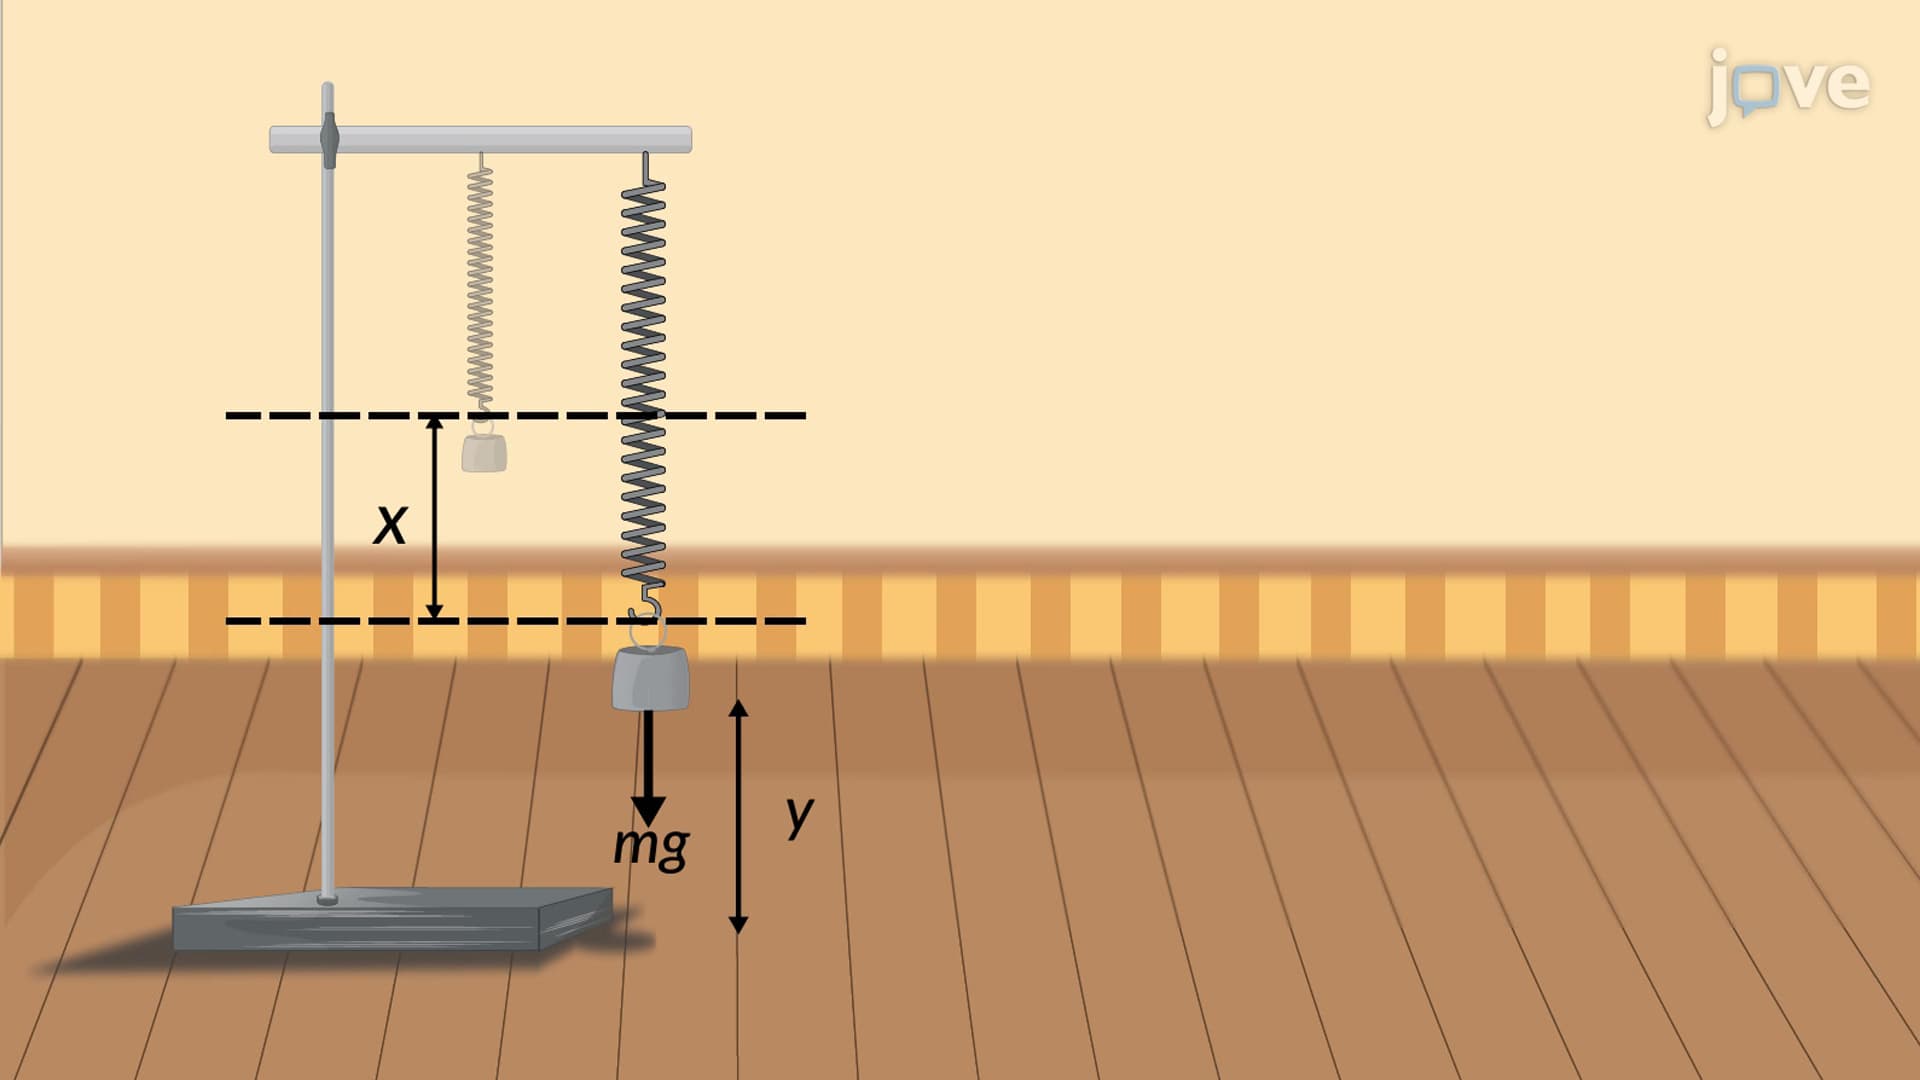
Elastic Potential Energy
Potential energy is also associated with the elastic force exerted by an ideal spring. The work done by this force can be represented as a change in the elastic potential energy of the spring. Thus, the work done by a perfectly elastic spring, in one dimension, depends...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:14
Ventilatory Modes
There are three ventilatory modes: full support, partial support, and spontaneous. These are described below.
Full Support Modes
Full support modes include controlled mechanical ventilation, continuous mandatory...
 01:19
Members Made of Elastoplastic Material
As the bending moment...