Robust observer-based absolute stabilization for Lur'e singularly perturbed systems with state delay
Related Experiment Video
Updated: Mar 17, 2026

Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
1School of Mathematics and Statistics, Zhoukou Normal University, Zhoukou 466001, China; Center for Applied and Multidisciplinary Mathematics, Department of Mathematics, East China Normal University, Shanghai 200241, China.

Abstract:
This paper is concerned with the problem of robust observer-based absolute stabilization for Lur'e singularly perturbed time-delay systems. The aim is to design a suitable observer-based feedback control law such that the resulting closed-loop system is absolutely stable. First, a full-order state observer is constructed. Based on the linear matrix inequality (LMI) technique, a delay-dependent sufficient condition is presented such that the observer error system is absolutely stable. Then, for observer-based feedback control, by introducing some slack matrices, a sufficient condition for input-to-state stability (ISS) of the closed-loop system with regard to the observer error is presented. Thus, the absolute stabilization of the closed-loop system can be guaranteed based on the ISS property. In addition, the criteria presented are both independent of the small parameter and the upper bound for the absolute stability can be obtained in a workable algorithm. Finally, two numerical examples are provided to illustrate the effectiveness of the developed methods.
More Related Videos
 06:44
Age-dependent Dynamics of Locomotion in Caenorhabditis elegans: A Lyapunov Exponent Analysis
Published on: September 23, 2025
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:28
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
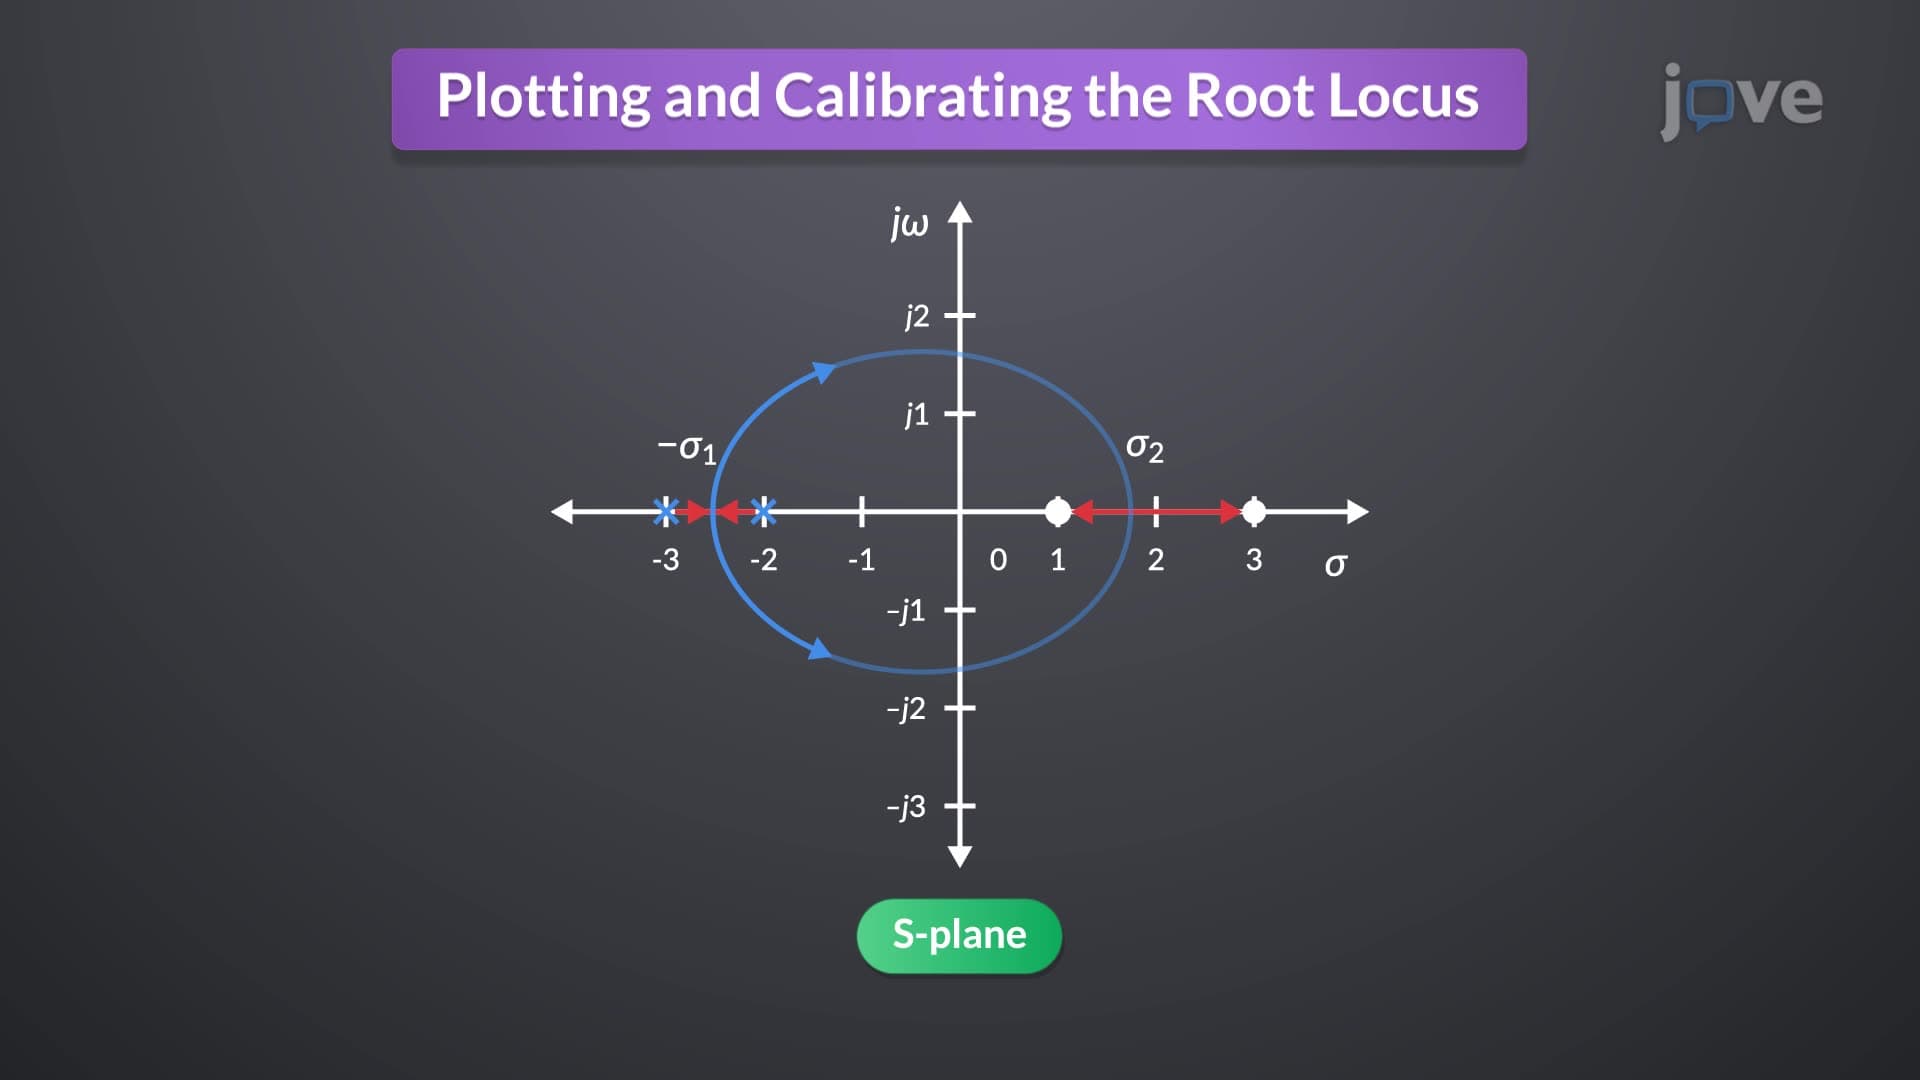 01:19
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
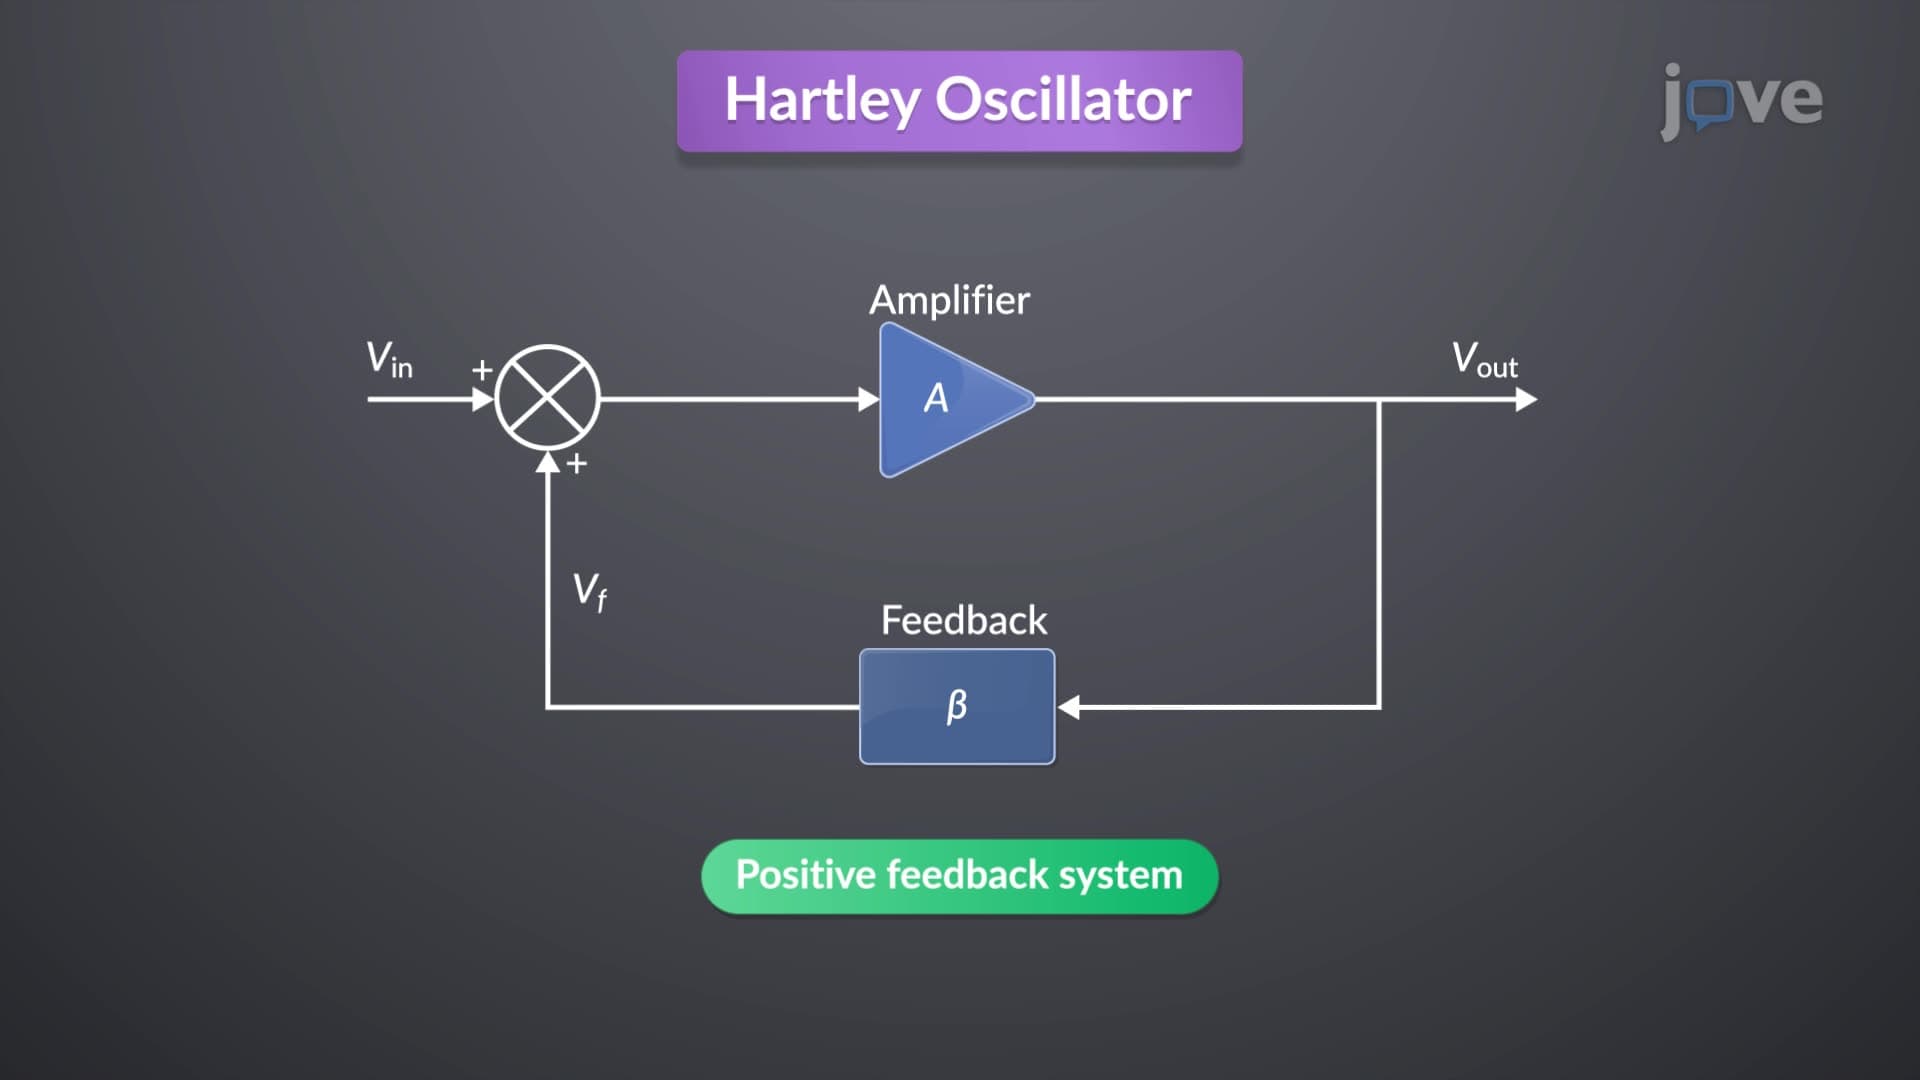 01:23
Root Loci for Positive-Feedback Systems
The construction rules for the root locus in positive feedback systems are similar to those in...