Related Experiment Video
Updated: Mar 16, 2026
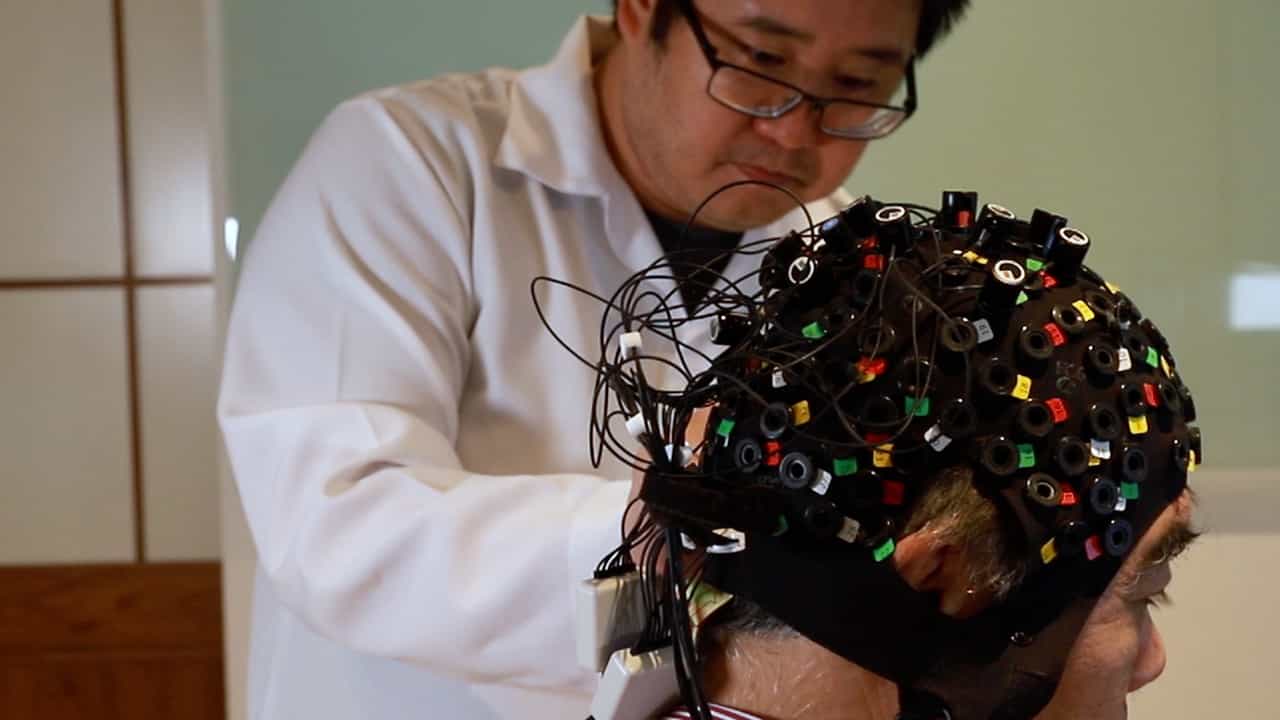

Author Spotlight: Assessing Brain Activity in Robotic-Assisted Lower Limb Rehabilitation Using fNIRS
Published on: June 7, 2024
Human-like compliant locomotion: state of the art of robotic implementations
Diego Torricelli1, Jose Gonzalez, Maarten Weckx
1Neural Rehabilitation Group, Cajal Institute, Spanish National Research Council (CSIC), Avda Doctor Arce, 37, E-28002 Madrid, Spain.

Abstract:
This review paper provides a synthetic yet critical overview of the key biomechanical principles of human bipedal walking and their current implementation in robotic platforms. We describe the functional role of human joints, addressing in particular the relevance of the compliant properties of the different degrees of freedom throughout the gait cycle. We focused on three basic functional units involved in locomotion, i.e. the ankle-foot complex, the knee, and the hip-pelvis complex, and their relevance to whole-body performance. We present an extensive review of the current implementations of these mechanisms into robotic platforms, discussing their potentialities and limitations from the functional and energetic perspectives. We specifically targeted humanoid robots, but also revised evidence from the field of lower-limb prosthetics, which presents innovative solutions still unexploited in the current humanoids. Finally, we identified the main critical aspects of the process of translating human principles into actual machines, providing a number of relevant challenges that should be addressed in future research.


