Related Experiment Video
Updated: Mar 15, 2026

Force and Position Control in Humans - The Role of Augmented Feedback
Published on: June 19, 2016
Feedforward compensation for novel dynamics depends on force field orientation but is similar for the left and right
Eva-Maria Reuter1,2, Ross Cunnington2,3, Jason B Mattingley2,3
1School of Human Movement and Nutrition Sciences, The University of Queensland, Brisbane, Queensland, Australia; e.reuter@uq.edu.au.

Abstract:
There are well-documented differences in the way that people typically perform identical motor tasks with their dominant and the nondominant arms. According to Yadav and Sainburg's (Neuroscience 196: 153-167, 2011) hybrid-control model, this is because the two arms rely to different degrees on impedance control versus predictive control processes. Here, we assessed whether differences in limb control mechanisms influence the rate of feedforward compensation to a novel dynamic environment. Seventy-five healthy, right-handed participants, divided into four subsamples depending on the arm (left, right) and direction of the force field (ipsilateral, contralateral), reached to central targets in velocity-dependent curl force fields. We assessed the rate at which participants developed predictive compensation for the force field using intermittent error-clamp trials and assessed both kinematic errors and initial aiming angles in the field trials. Participants who were exposed to fields that pushed the limb toward ipsilateral space reduced kinematic errors more slowly, built up less predictive field compensation, and relied more on strategic reaiming than those exposed to contralateral fields. However, there were no significant differences in predictive field compensation or kinematic errors between limbs, suggesting that participants using either the left or the right arm could adapt equally well to novel dynamics. It therefore appears that the distinct preferences in control mechanisms typically observed for the dominant and nondominant arms reflect a default mode that is based on habitual functional requirements rather than an absolute limit in capacity to access the controller specialized for the opposite limb.
More Related Videos
 11:44
Real-Time DC-dynamic Biasing Method for Switching Time Improvement in Severely Underdamped Fringing-field Electrostatic MEMS Actuators
Published on: August 15, 2014
 08:24
Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
Related Concept Videos
 01:20
Two-Dimensional Force System
 01:30
Three-Dimensional Force System
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:05
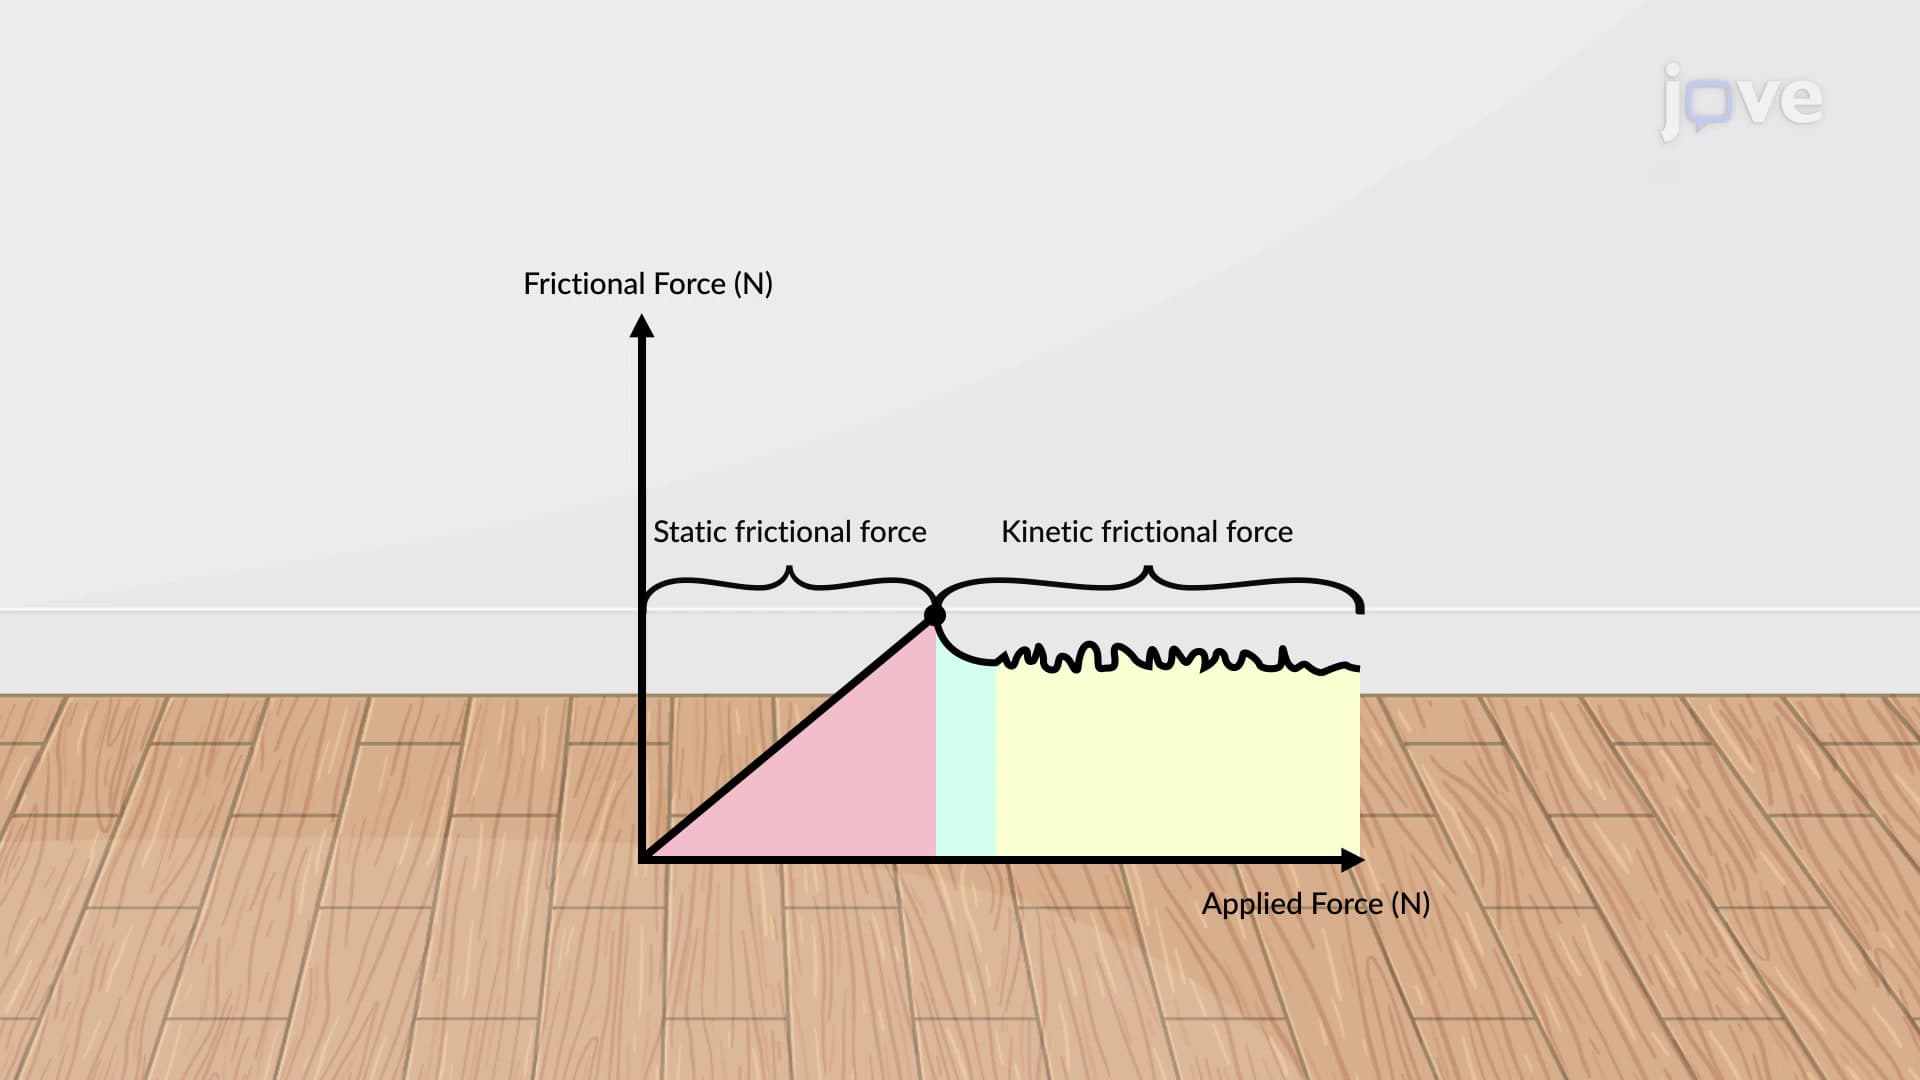
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...