An optimal velocity for online limb-target regulation processes?
Related Experiment Video
Updated: Mar 15, 2026
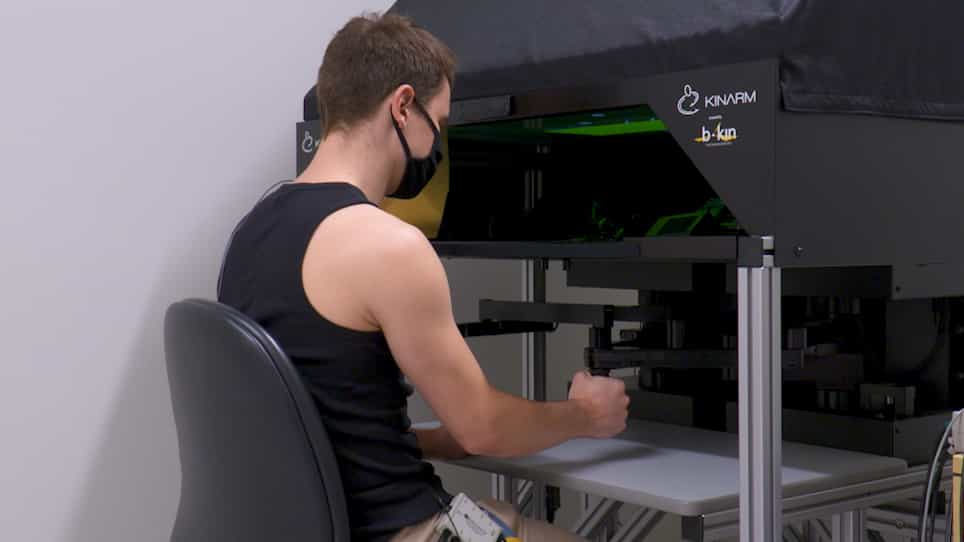
An Emerging Target Paradigm to Evoke Fast Visuomotor Responses on Human Upper Limb Muscles
Published on: August 25, 2020
Luc Tremblay1,2,3, Valentin A Crainic4, John de Grosbois4
1Faculty of Kinesiology and Physical Education, University of Toronto, Toronto, ON, Canada. luc.tremblay@utoronto.ca.

Abstract:
The utilization of visual information for the control of ongoing voluntary limb movements has been investigated for more than a century. Recently, online sensorimotor processes for the control of upper-limb reaches were hypothesized to include a distinct process related to the comparison of limb and target positions (i.e., limb-target regulation processes: Elliott et al. in Psychol Bull 136:1023-1044. doi: 10.1037/a0020958 , 2010). In the current study, this hypothesis was tested by presenting participants with brief windows of vision (20 ms) when the real-time velocity of the reaching limb rose above selected velocity criteria. One experiment tested the perceptual judgments of endpoint bias (i.e., under- vs. over-shoot), and another experiment tested the shifts in endpoint distributions following an imperceptible target jump. Both experiments revealed that limb-target regulation processes take place at an optimal velocity or "sweet spot" between movement onset and peak limb velocity (i.e., 1.0 m/s with the employed movement amplitude and duration). In contrast with pseudo-continuous models of online control (e.g., Elliott et al. in Hum Mov Sci 10:393-418. doi: 10.1016/0167-9457(91)90013-N , 1991), humans likely optimize online limb-target regulation processes by gathering visual information at a rather limited period of time, well in advance of peak limb velocity.

Related Concept Videos
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:18
Velocity of an Object
 01:12
Average Velocity
 01:12
Average and Instantaneous Velocity Vectors
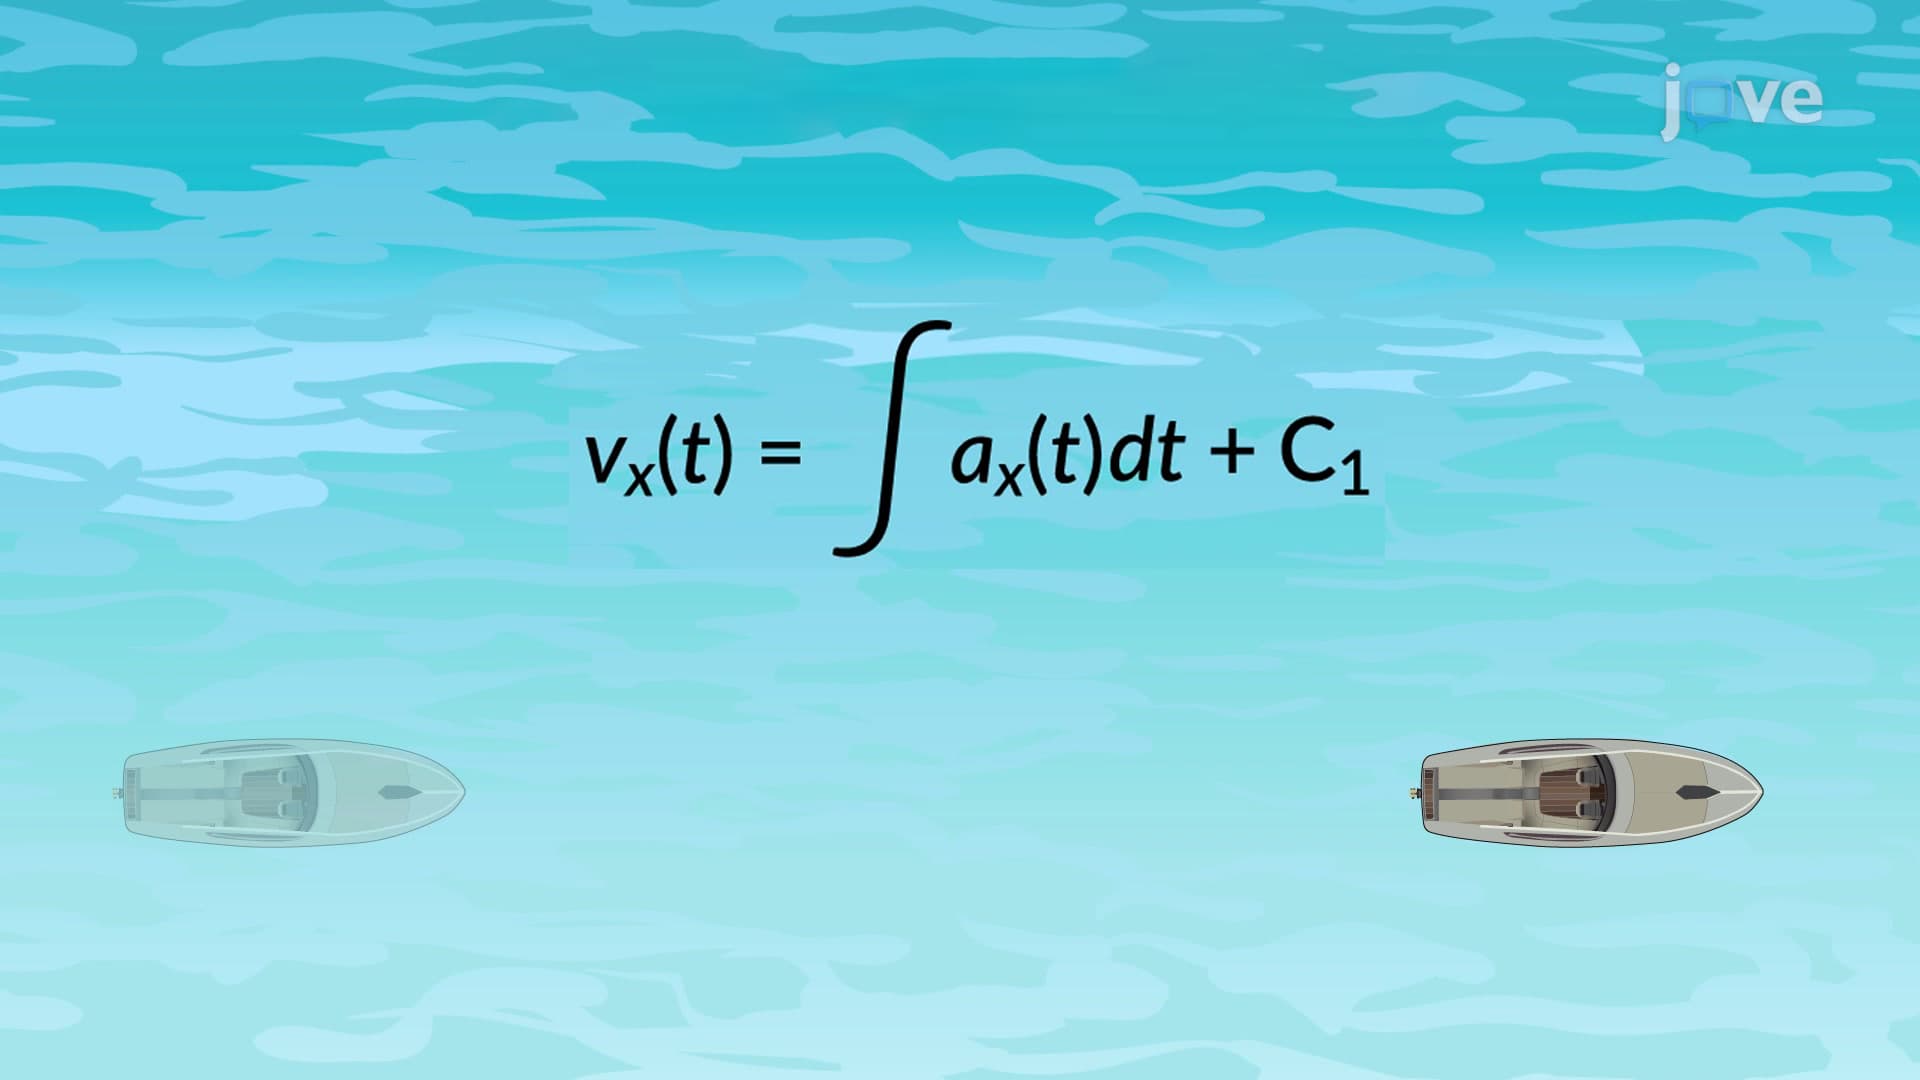 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...